
学习法典嵌入式,用于与局部线性转换无监督的形状对应
IEEE transactions on pattern analysis and machine intelligence
|September 5, 2023

概括
本研究介绍了一种新的无监督方法,用于使用修改的局部线性嵌入 (LLE) 算法进行形状对应学习. 该方法通过学习邻居保护嵌入式并将它们与线性转换对齐,从而实现准确的点云对应.
科学领域:
- 计算机视觉 计算机视觉
- 机器学习 机器学习
- 计算几何学的计算几何学
背景情况:
- 形状对应对于3D形状分析和操纵至关重要.
- 现有的方法通常需要监督或与复杂的形状变化作斗争.
- 局部线性嵌入 (LLE) 是一种以前未被应用于形状对应的维度减小技术.
研究的目的:
- 开发一种新的无监督的方法来学习点云之间的形状对应.
- 适应经典的局部线性嵌入 (LLE) 算法来完成形状对应的任务.
- 为了实现各种3D形状的准确和强大的密度对应.
主要方法:
- 利用一个新的LLE启发的点云重建目标,用于社区保护嵌入.
- 实施一个端到端可学习的框架,用于嵌入提取和转换估计.
- 使用分歧测量,对重建形状和目标形状的概率密度函数进行对齐.
- 强制嵌入到正规空间中的规范化和最近邻居对应搜索.
主要成果:
- 拟议的方法可以在点云数据上实现准确的形状对应.
- 对基准数据集的最先进方法进行了明显的改进.
- 成功应用于人类和非人类形状对应任务.
- 受LLE启发的嵌入和对齐策略被证明是有效的.
结论:
- 基于LLE的新方法为形状对应提供了一个强大的无监督解决方案.
- 该方法提供了准确和强大的对应,优于现有技术.
- 这项工作为在3D形状分析中应用缩小维度技术开辟了新的途径.
相关概念视频
 01:23
Curvilinear Motion: Rectangular Components
483
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
483
 01:12
Transformation of Plane Strain
190
When analyzing elongated structures like bars subjected to uniformly distributed loads, it is essential to understand the transformation of plane strain when coordinate axes are rotated. This transformation helps to assess how material deformation characteristics vary with orientation, which is crucial in materials science and structural engineering.
Under plane strain conditions, typical for members where one dimension significantly exceeds the others, deformations and resultant strains are...
Under plane strain conditions, typical for members where one dimension significantly exceeds the others, deformations and resultant strains are...
190
 01:16
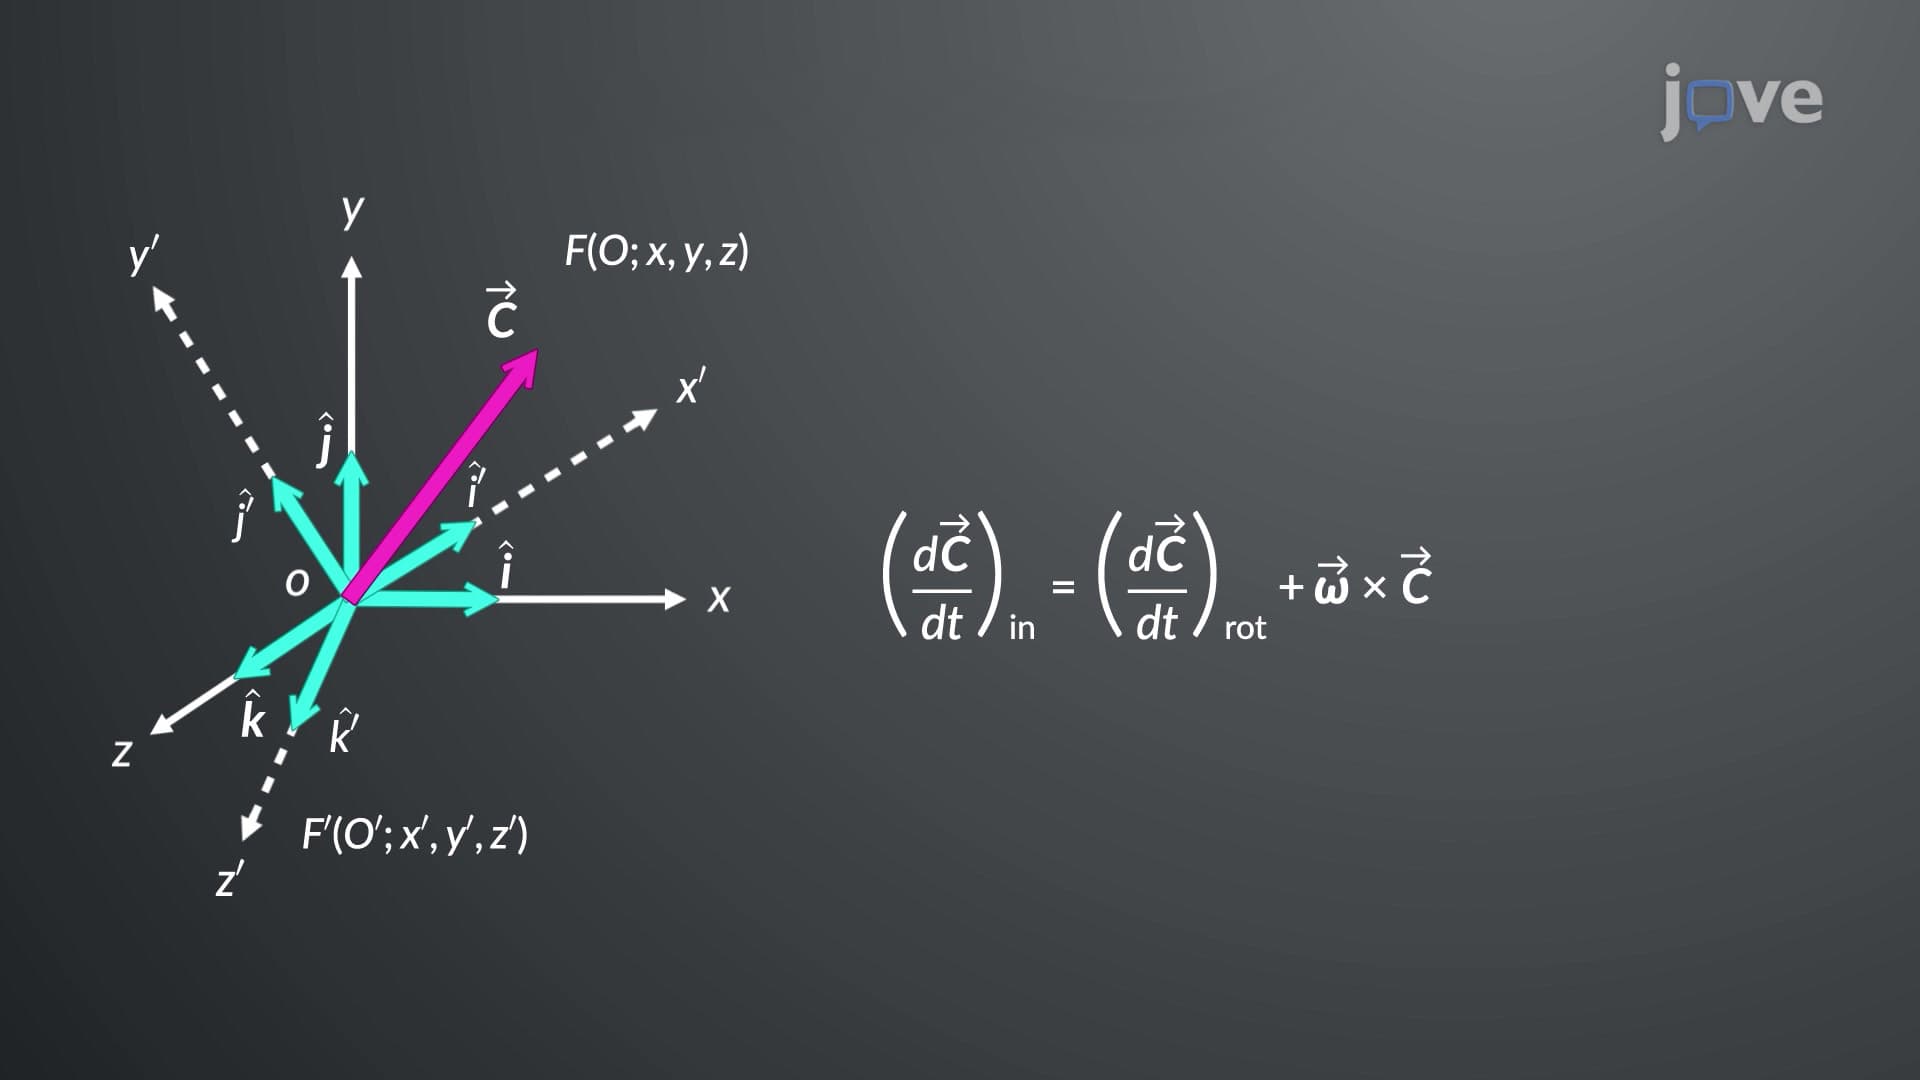
Vector Transformation in Rotating Coordinate Systems
1.6K
Consider a vector rotating about an axis with an angular velocity, such that its tip sweeps a circular path.
1.6K
 01:20
Calibration Curves: Linear Least Squares
1.4K
A calibration curve is a plot of the instrument's response against a series of known concentrations of a substance. This curve is used to set the instrument response levels, using the substance and its concentrations as standards. Alternatively, or additionally, an equation is fitted to the calibration curve plot and subsequently used to calculate the unknown concentrations of other samples reliably.
For data that follow a straight line, the standard method for fitting is the linear...
For data that follow a straight line, the standard method for fitting is the linear...
1.4K
 01:27
Curvilinear Motion: Normal and Tangential Components
421
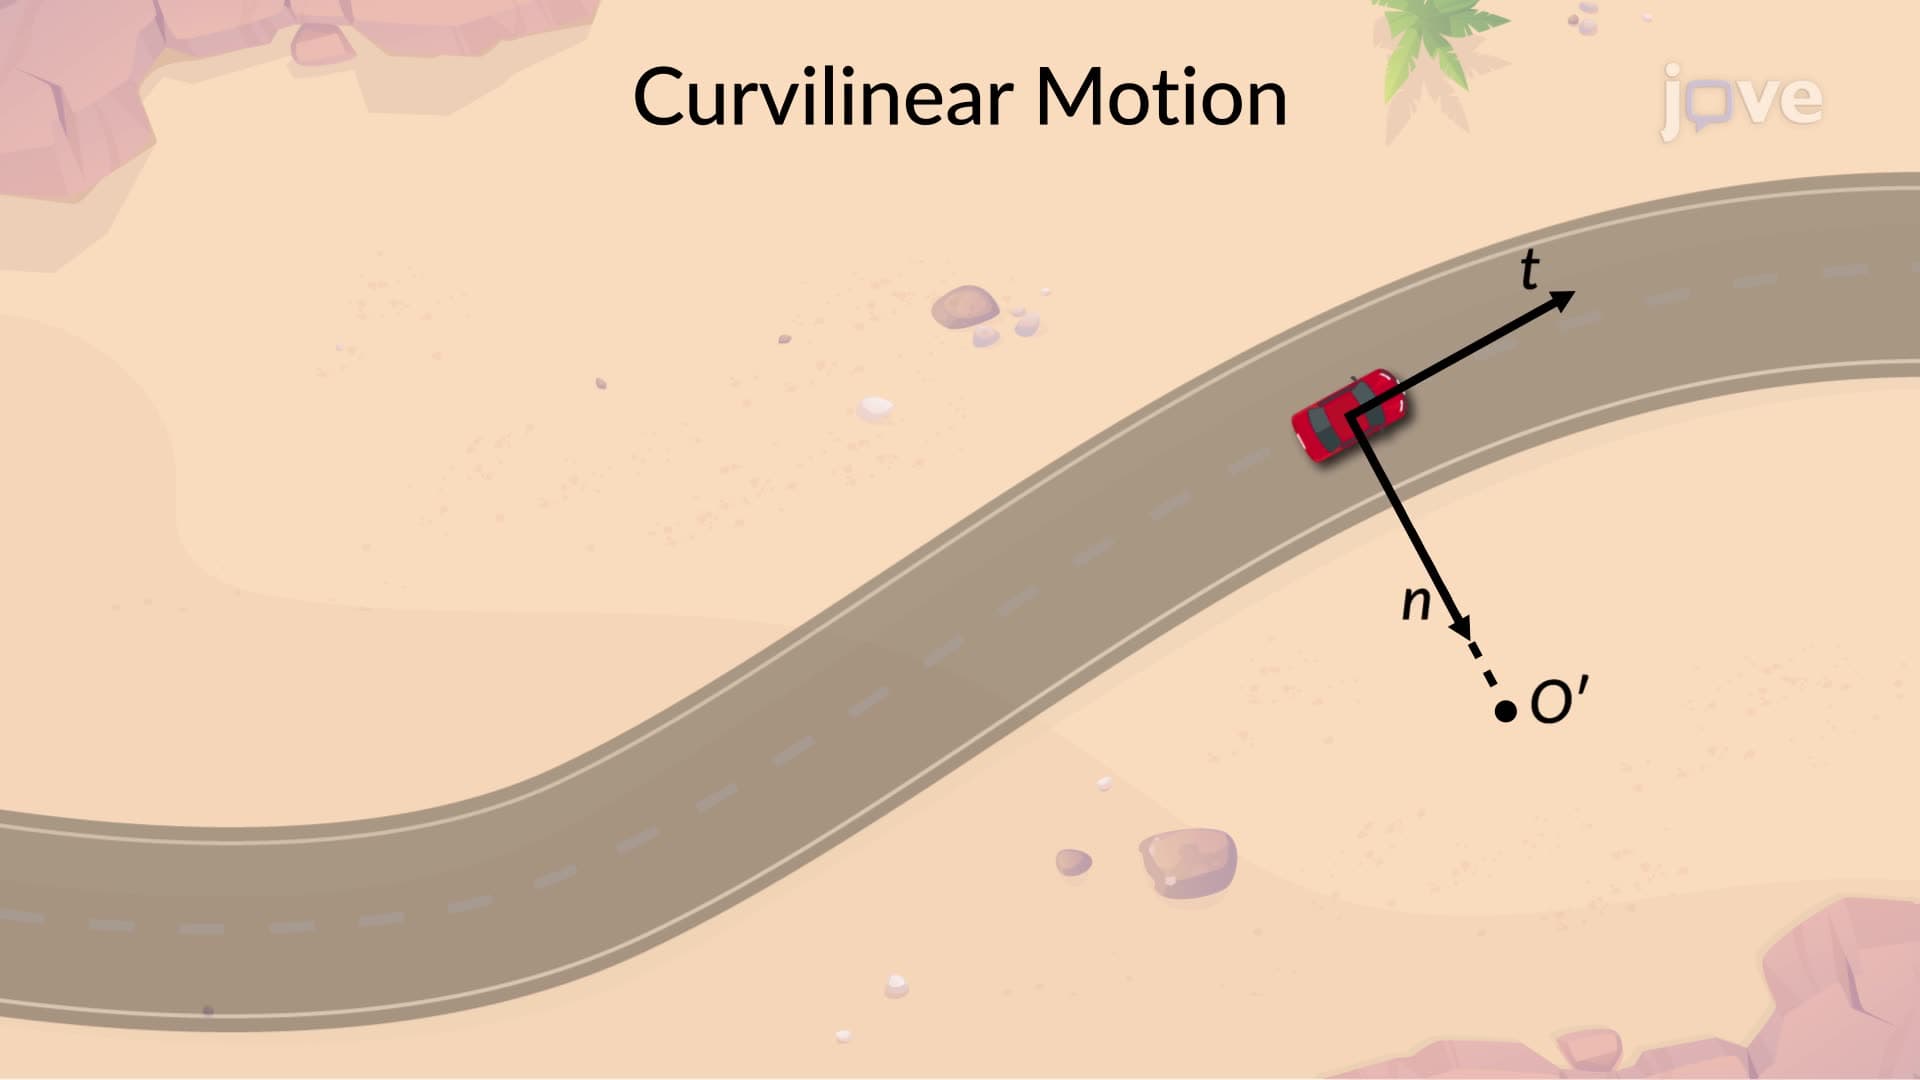
When a car traverses a curved road, its motion can be elucidated by breaking it down into tangential and normal components. The car-centric coordinates attached to the vehicle move with it.
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
421
 01:26
Cartesian Form for Vector Formulation
667
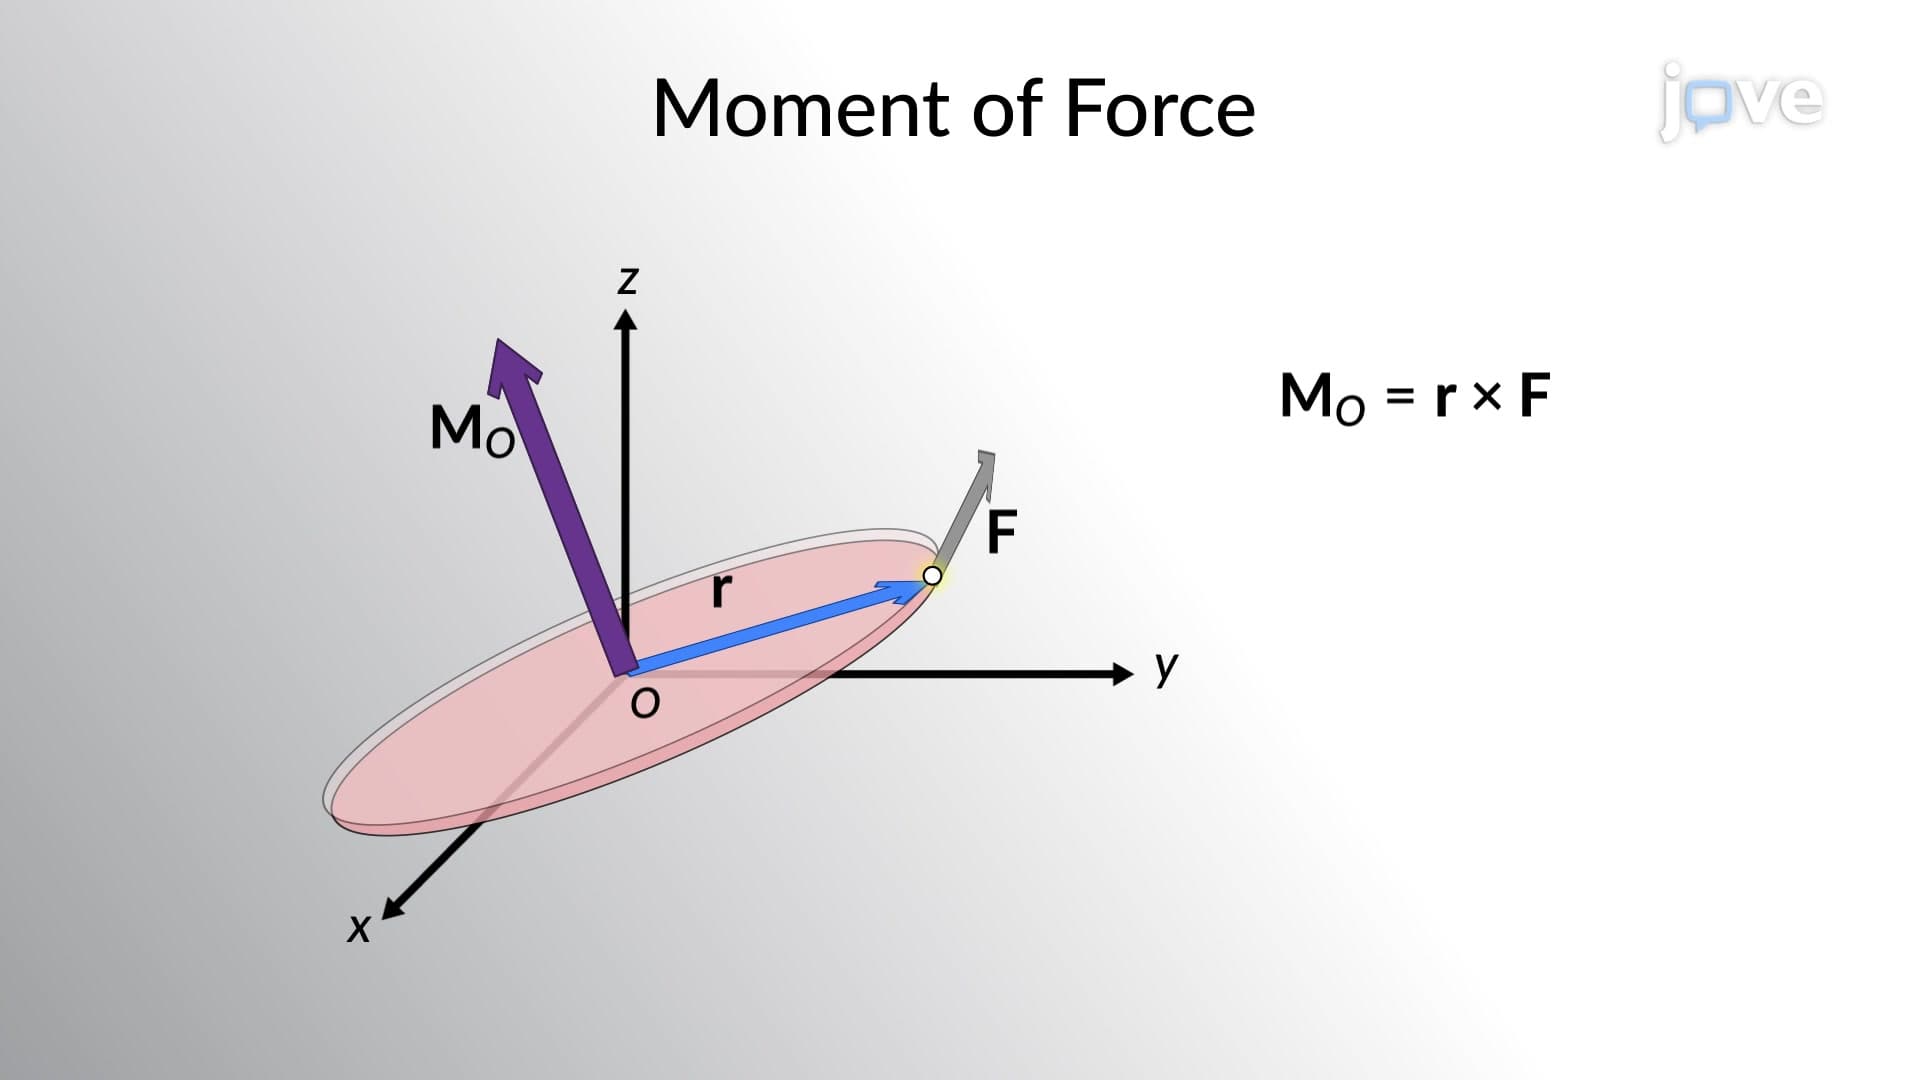
The Cartesian form for vector formulation is a process to calculate the moment of force using the position and force vectors. The moment of force is defined as the cross-product of these vectors, making it a vector quantity. The Cartesian form of the position and force vectors involves unit vectors, which can be used to express the cross-product in determinant form.
667