
在平行行走过程中对地面反应力的三维分析与十字骨位移相关
Amany E Abd-Eltawab1,2, Asmaa M Elbandrawy3,4, Heba B Ghanem5,6
1Department of Physical Therapy and Health Rehabilitation, Faculty of Applied Medical Sciences, Jouf University, P. O. Box 2014 Sakaka, KSA.
International journal of health sciences
|September 11, 2023

概括
走路时的圣骨位移与行走阶段和性别的地面反应力 (GRF) 有着多种相关性. 雄性在中期姿势中表现出前后后的GRF相关性,而雌性在早期和晚期姿势中表现出垂直的GRF相关性.
科学领域:
- 生物力学 生物力学
- 人类运动分析 人类运动分析
- 整形外科 整形外科 整形外科
背景情况:
- 了解十字骨位移及其与地面反应力 (GRF) 的关系对于分析步态力学至关重要.
- 运动期间生物机械反应的性别特异性差异尚未完全阐明.
研究的目的:
- 为了确定在平行行走时的部位移和GRF之间的关联.
- 为了确定由GRF影响最大的特定步行周期子阶段.
- 为了研究影响GRF的阴骨配置的性别变化.
主要方法:
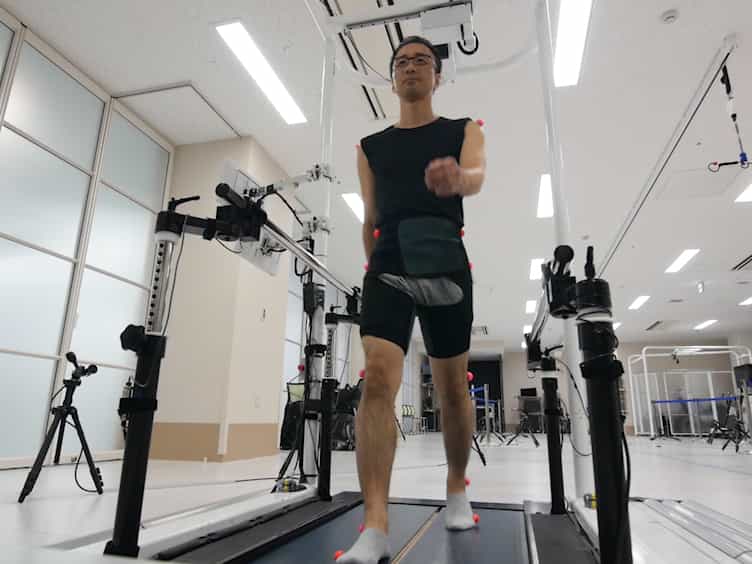
- 利用运动分析系统 (MAS) 和力板捕获40名健康大学生的动力学和动力学数据.
- 同步MAS和力板数据用于三维 (3D) 分析角位移和力.
- 在三个方向上测量了十字骨的角度移位.
主要成果:
- 雌性在早期和晚期的姿势阶段显示了垂直GRF和十字骨位移之间的正相关性.
- 雄性在中期和晚期的姿势阶段与垂直GRF呈现出正相关性.
- 只有在男性中观察到在中间位置的前后后方向的正相关性.
结论:
- 针对干部和下肢肌肉的力量训练可以增强男性和女性的旋转肌肉力量.
- 建议在力量训练期间专注于男性的干部曲器和延伸器,特别是运动员.
- 这些有针对性的干预措施可能有助于减少体育伤害的发生率.
更多相关视频

相关概念视频
 01:30
Three-Dimensional Force System
2.1K
In mechanical engineering, a three-dimensional force system is a system of forces acting in three dimensions, with forces applied along the x, y, and z coordinate axes. The three-dimensional force system is an important concept in mechanical engineering, as it allows engineers to understand and analyze the behavior of objects and structures in three dimensions. By understanding the forces acting on a system, engineers can design more efficient and effective mechanical systems that can withstand...
2.1K
 01:30
Three-Dimensional Force System:Problem Solving
691
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
691