速度地图成像没有球形偏差
相关实验视频
Updated: Nov 6, 2026
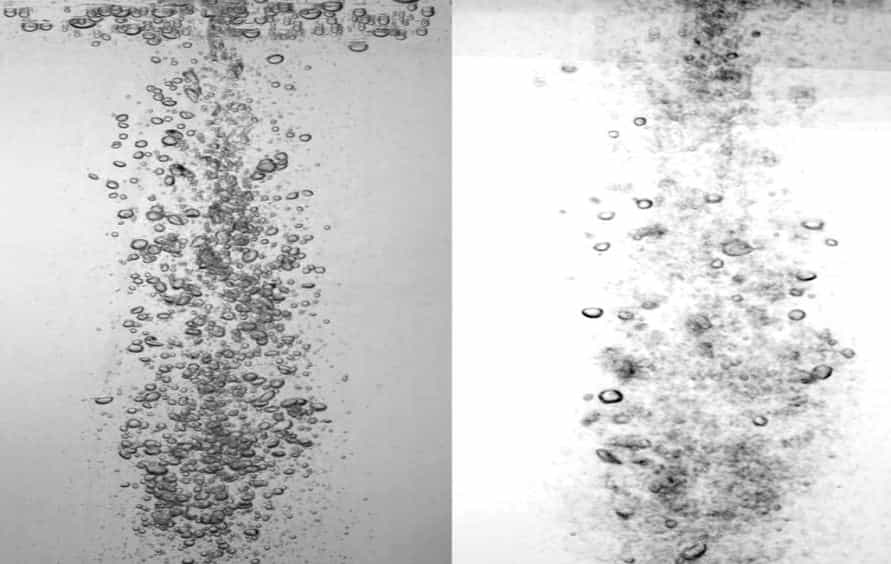
14:25
Determining 3D Flow Fields via Multi-camera Light Field Imaging
Published on: March 6, 2013
16.7K
Yehuda Ben-Shabo1, Adeliya Kurbanov1, Claus Dieter Schröter2
1Department of Physics and Institute of Nanotechnology and Advanced Materials, Bar-Ilan University, Ramat-Gan 5290002, Israel. yonitoker@gmail.com.
Physical chemistry chemical physics : PCCP
|September 13, 2023

概括
本研究介绍了无偏差速度图像成像 (VMI) 的分析推导. 这种技术增强了带电粒子的动能测量,使反应显微镜等先进仪器能够进行精确的分析.
科学领域:
- 原子和分子物理 原子和分子物理
- 实验物理实验物理学
- 物理化学 物理化学
背景情况:
- 速度图像成像 (VMI) 对于确定带电粒子动能至关重要.
- 离子光学中的球形偏差限制了VMI的接受体积和分辨率.
- 目前的VMI技术由于光学偏差而面临挑战.
研究的目的:
- 通过分析推导出一种没有球形偏差的速度图像绘制方法.
- 通过在冷储存环 (CSR) 中使用反应显微镜来演示无偏差VMI的实现.
- 探索这种形式主义在位置成像和混合模式成像中的应用.
主要方法:
- 分析推导VMI光学以消除球形偏差.
- 使用反应显微镜实现衍生技术.
- 使用SIMION模拟来建模电子束聚焦和探测器点大小.
主要成果:
- 开发了一个分析框架,用于无偏差的速度图像绘制.
- 模拟证实,8厘米宽的电子束可以聚焦到0.1毫米的点.
- 该方法适用于位置成像和联合位置/速度地图成像.
结论:
- 无偏差的VMI显著提高了动能测量的分辨率和精度.
- 开发的技术与先进的实验设置兼容,例如冷储存环中的反应显微镜.
- 这项工作扩展了VMI的功能,用于详细的粒子分析.
相关概念视频
 01:34
Velocity and Position by Graphical Method
Velocity and position can be calculated from the known function of acceleration as a function of time. The total area under the acceleration-time graph and the velocity-time graph gives the change in velocity and position, respectively. In the case of an airplane, its acceleration is tracked using the inertial navigation system. The pilot provides the input of the airplane's initial position and velocity before takeoff. The inertial navigation system then uses the acceleration data to calculate...
 01:12
Average and Instantaneous Velocity Vectors
To calculate other physical quantities in kinematics, the time variable must be introduced. The time variable not only allows us to state where an object is (its position) during its motion, but also how fast it’s moving. The speed at which an object is moving is given by the rate at which the position changes with time. For each position, a particular time is assigned. If the details of the motion at each instant are not important, the rate is usually expressed as the average velocity v. This...
 01:11
Relative Velocity in Two Dimensions
Relative velocity is the velocity of an object as observed from a particular reference frame, or the velocity of one reference frame with respect to another reference frame. The concept of relative velocity can be used to describe motion in two dimensions. Consider a particle P and two reference frames S and S′. The position of the origin of S′ as measured in S is , the position of P as measured in S′ is , and the position of P as measured in S is , which can be evaluated by utilizing vector...
 01:24
Relative Motion Analysis - Velocity
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:27
Curvilinear Motion: Polar Coordinates
In polar coordinates, the motion of a particle follows a curvilinear path. The radial coordinate symbolized as 'r,' extends outward from a fixed origin to the particle, while the angular coordinate, 'θ,' measured in radians, represents the counterclockwise angle between a fixed reference line and the radial line connecting the origin to the particle.
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...