

使用基于CNN的深度学习进行连续关节速度估计,用于日常生活活动的多DoF假肢手腕
Zixia Meng1,2, Jiyeon Kang1,3,4
1Mechanical and Aerospace Engineering, School of Engineering and Applied Sciences, University at Buffalo, Buffalo, NY, United States.
Frontiers in neurorobotics
|September 25, 2023

概括
这项研究引入了一种新的肌电控制系统,用于使用表面电肌图 (sEMG) 和快速训练策略的假肢手腕. 该系统提高了日常活动的控制精度,提高了假肢的功能.
科学领域:
- 生物医学工程 生物医学工程
- 机器人技术 机器人技术 机器人技术
- 康复技术 康复技术 康复技术
背景情况:
- 假肢的肌电控制使用表面电肌图 (sEMG) 进行意图检测.
- 当前的模型往往因为训练孤立的运动而失败,而不是反映现实生活活动.
- 假肢控制受到手臂姿势,活动持续时间和个人习惯的挑战.
研究的目的:
- 为多度自由度 (DoF) 假肢手臂开发一种新的手腕控制系统.
- 直接将sEMG信号映射到联合速度以进行直观的控制.
- 引入"快速培训"战略,以适应新用户和现实环境.
主要方法:
- 专注于旋转-俯卧和射箭投运动 (DTM).
- 开发了一个系统,将sEMG映射到多DoF手腕关节速度.
- 在24名参与者身上使用根平均平方误差 (RMSE) 和皮尔森相关性来评估表现.
主要成果:
- 射箭投动作任务显示RMSE较低 (例如,子:6.68度/秒),而不是俯仰-俯仰 (例如,灯泡:43.98度/秒).
- "快速培训"战略将平均RMSE降低了35%.
- "快速培训"战略使得皮尔森的平均相关性在任务之间增加了40%.
结论:
- 拟议的控制系统有效地将sEMG映射到假肢手腕运动中.
- "快速培训"战略提高了对现实世界假肢使用的适应性和稳定性.
- 这种方法提高了多DoF假肢手腕的性能和可用性.


相关概念视频
 01:24
One-Degree-of-Freedom System
506
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
506
 01:09
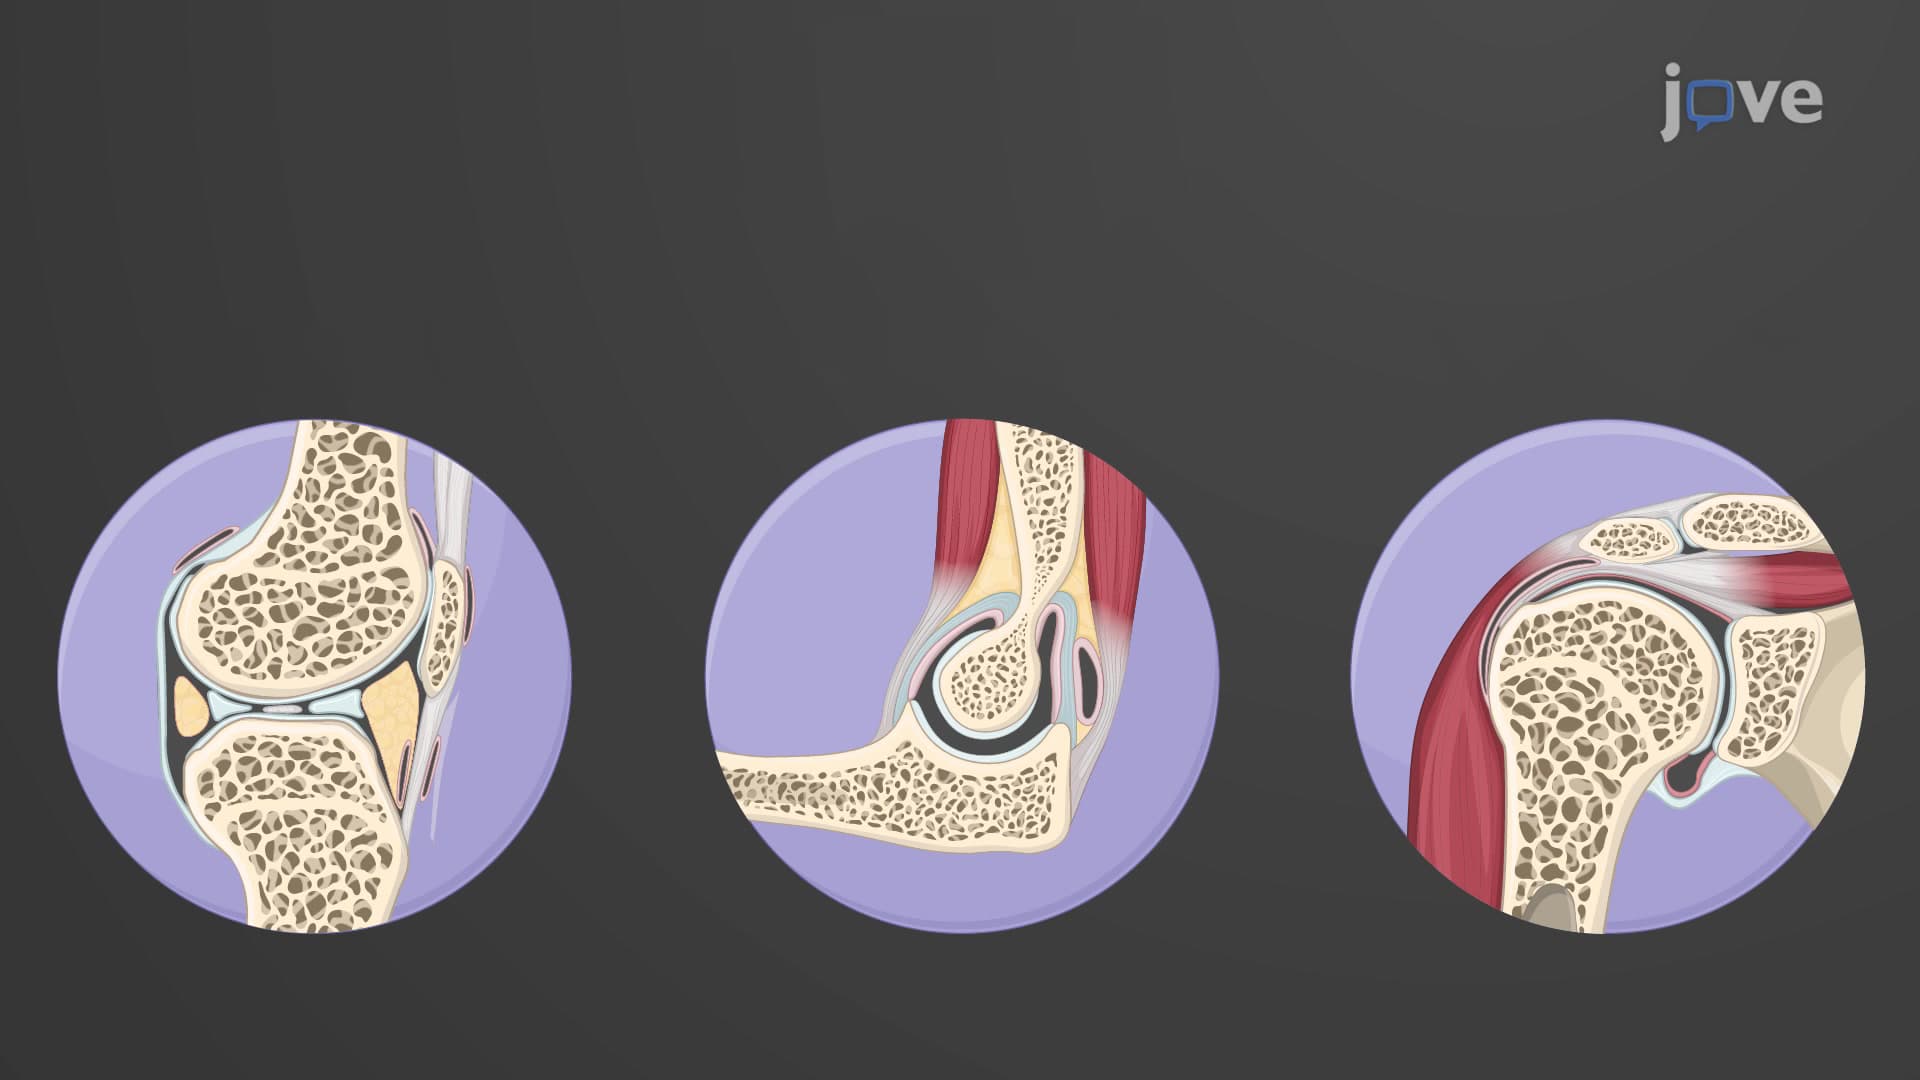
Functional Classification of Joints
4.2K
Functional Classification of Joints
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An...
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An...
4.2K
 01:24
Relative Motion Analysis - Velocity
385
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
385
 01:15
Bones of the Upper Limb: Ulna
2.2K
The ulna and radius are parallel bones of the antebrachium or the forearm. The ulna lies medially and consists of a bony tip called the olecranon process at its proximal end. This hook-like projection articulates with the olecranon fossa of the humerus and forms the "hinged" ulnohumeral part of the elbow joint. This joint facilitates forearm extension and flexion while preventing its hyperextension. Similarly, the coronoid process, another bony projection on the proximal/anterior side...
2.2K
 01:15
Torque Free Motion
507
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
507