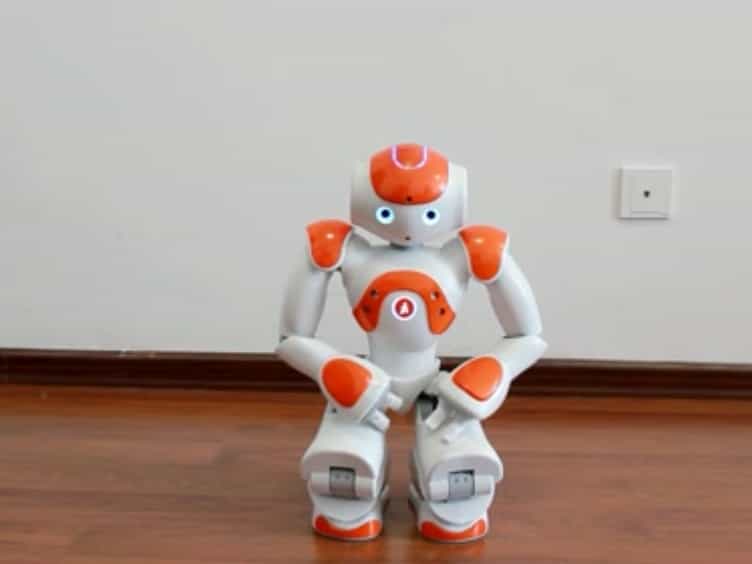
为RELAX高负载协作机器人提供统一的多式联接口
Luca Muratore1, Arturo Laurenzi1, Alessio De Luca1,2
1Humanoids and Human-Centered Mechatronics Research Line, Istituto Italiano di Tecnologia (IIT), Via Morego 30, 16163 Genova, Italy.
Sensors (Basel, Switzerland)
|September 28, 2023

概括
本研究介绍了RELAX,这是一款具有高有效载荷臂和统一多式联网接口的移动协作机器人,用于有效的人机协作 (HRC). 该系统可在现实场景中实现高效的控制和任务完成.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 人与机器人的交互
- 控制系统 控制系统
背景情况:
- 人机协作 (HRC) 对于复杂的任务至关重要.
- 现有的系统往往缺乏高相互作用力和多样化的控制输入的灵活性.
- 移动协作机器人需要直观的界面来实现现实应用.
研究的目的:
- 为了引入RELAX移动协同机器人系统.
- 为了呈现一个新的统一的多式联络接口来指挥cobot.
- 评估系统在协作任务中的有效性.
主要方法:
- 开发一个定制的高负载机器人手臂 (RELAX).
- 整合了一个多式联网接口,结合了物理交互,超宽带 (UWB) 传感,GUI,口语和手势控制.
- 通过真实场景进行评估,涉及导航,避难障碍和高负载运输任务.
主要成果:
- 多式联网接口有效地整合了各种输入方式.
- 操作人员可以准确有效地控制RELAX cobot.
- 复杂的合作任务成功完成.
结论:
- 拟议的多式联运框架显著提高了人机协作能力.
- 随着其先进的界面,RELAX移动协同机器人适合要求的现实世界HRC任务.
- 这种方法促进了生产力的人与机器人的团队合作.

相关概念视频
 01:06
Virtual Work for a System of Connected Rigid Bodies
403
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
403
 01:30
Three-Dimensional Force System:Problem Solving
686
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
686
 01:24
One-Degree-of-Freedom System
506
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
506
 01:22
Mechanical Systems
225
Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically...
225
 01:30
Three-Dimensional Force System
2.1K
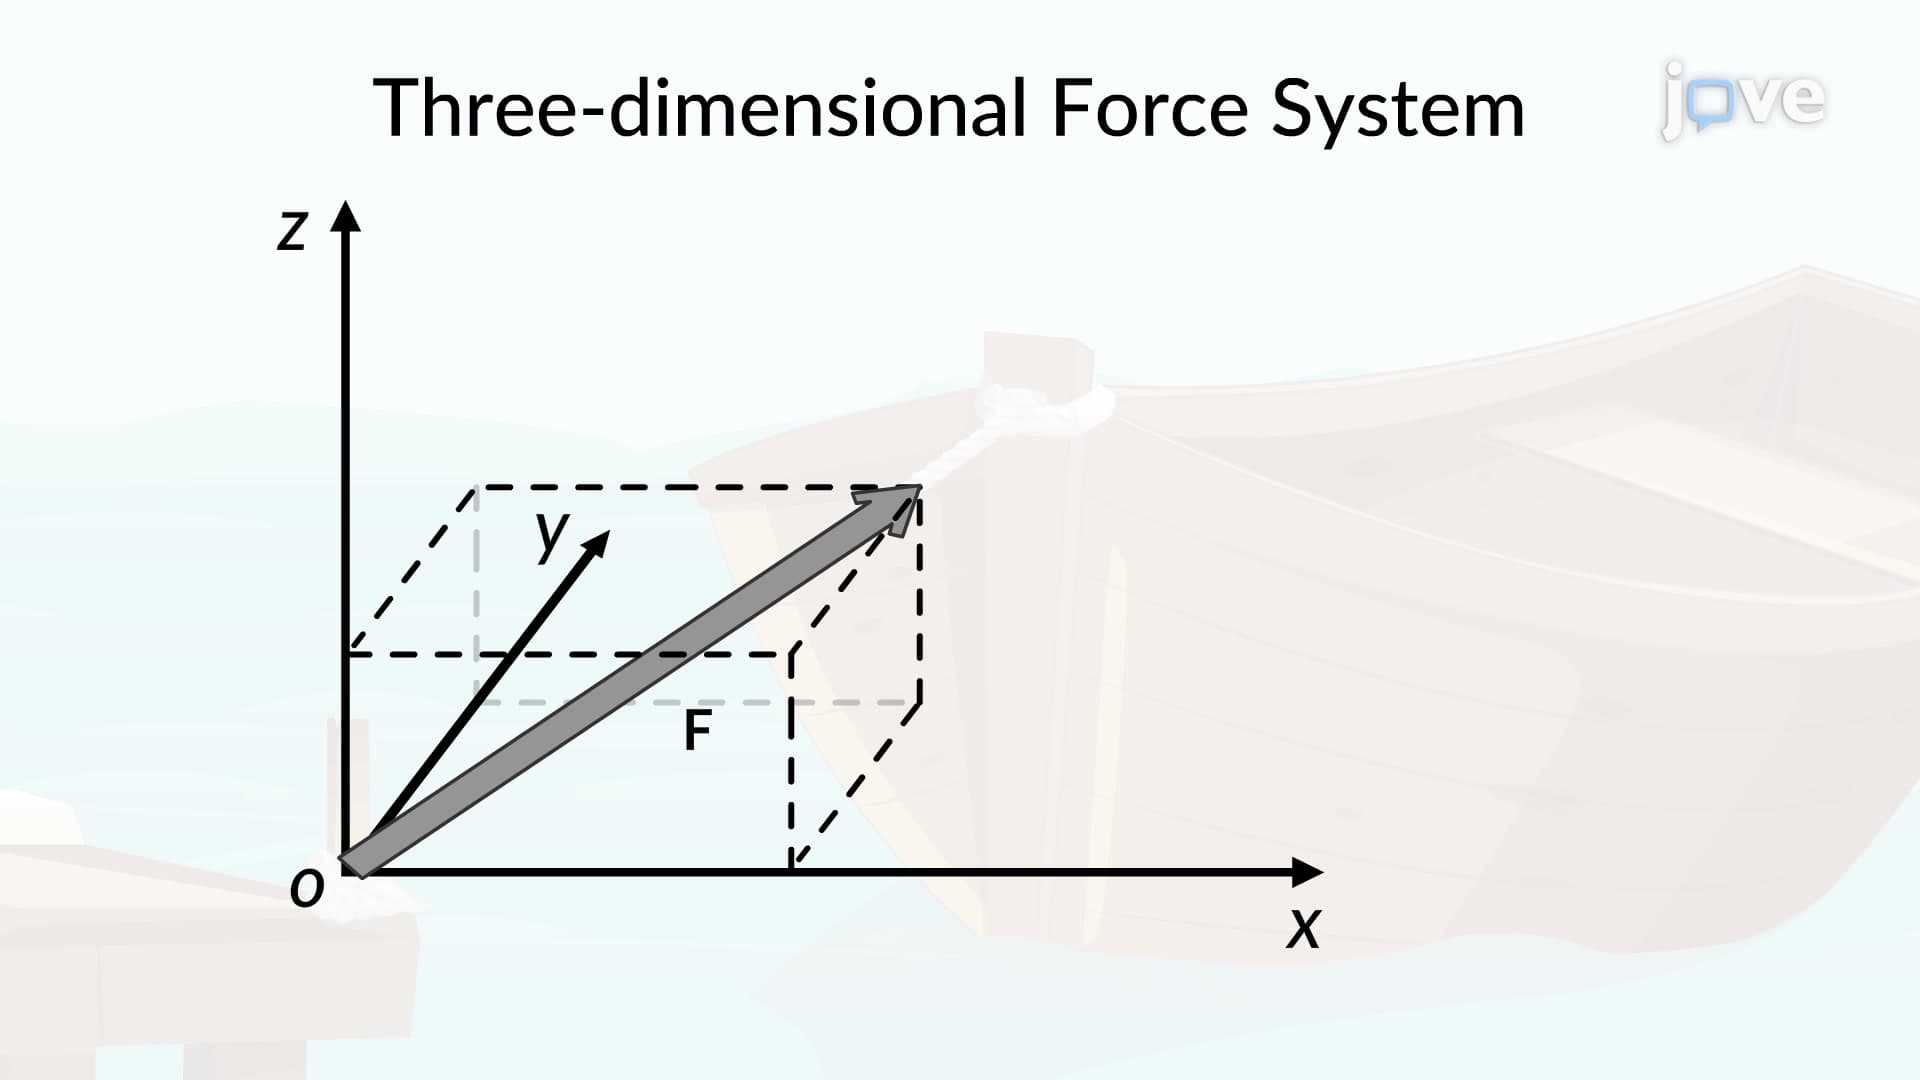
In mechanical engineering, a three-dimensional force system is a system of forces acting in three dimensions, with forces applied along the x, y, and z coordinate axes. The three-dimensional force system is an important concept in mechanical engineering, as it allows engineers to understand and analyze the behavior of objects and structures in three dimensions. By understanding the forces acting on a system, engineers can design more efficient and effective mechanical systems that can withstand...
2.1K
 01:22
Multi-input and Multi-variable systems
122
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
122