
准确的视觉同步定位和映射 (SLAM) 与周边视图监视器 (AVM) 扭曲错误使用加权的通用代最近点 (GICP)
Yangwoo Lee1, Minsoo Kim1, Joonwoo Ahn2
1Dynamic Robotic Systems (DYROS) Lab, Graduate School of Convergence Science and Technology, Seoul National University, Seoul 08826, Republic of Korea.

本研究介绍了一种基于Around View Monitor (AVM) 的可视同步定位和映射 (SLAM) 系统,用于自动停车. 这种新的方法纠正了AVM扭曲错误,大大提高了车辆定位的准确性.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算机视觉 计算机视觉
- 自主系统 自主系统
背景情况:
- 准确的车辆姿势估计对于自动停车系统至关重要.
- 基于周围视图监视器 (AVM) 的视觉同时定位和映射 (SLAM) 适合停车,因为其成本效益和适合动态移动.
- 由于摄像头校准不准确而导致的AVM扭曲错误会降低现实世界的SLAM性能.
研究的目的:
- 开发基于AVM的视觉SLAM方法,对自动停车的AVM扭曲错误具有稳定性.
- 提高车辆定位在充满挑战的停车环境中的可靠性和准确性.
主要方法:
- 开发了一个深度学习网络,以基于AVM扭曲权重停车线特征.
- 三维 (3D) 光检测和测距 (LiDAR) 数据和停车场指南用于培训数据生成.
- 训练网络的输出被集成到加权的通用代最接近点 (GICP) 算法中,用于本地化.
主要成果:
- 拟议的方法证明了对AVM扭曲错误的稳定性.
- 与现有的基于AVM的视觉SLAM方法相比,定位错误平均减少了39%.
- 该系统有效地处理车辆快速旋转和在停车场景中常见的来回运动.
结论:
- 展示的基于AVM的视觉SLAM系统为自动停车提供了更高的准确性和稳定性.
- 基于深度学习的权重机制有效地减轻了AVM扭曲错误的影响.
- 这种方法提高了可靠的自动停车在现实世界中条件的可行性.
更多相关视频
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 07:12
Development of a Gaze-Contingent Display Framework Designed for Perceptual and Oculomotor Research with Simulated Central Vision Loss
Published on: April 11, 2025
相关概念视频
 01:28
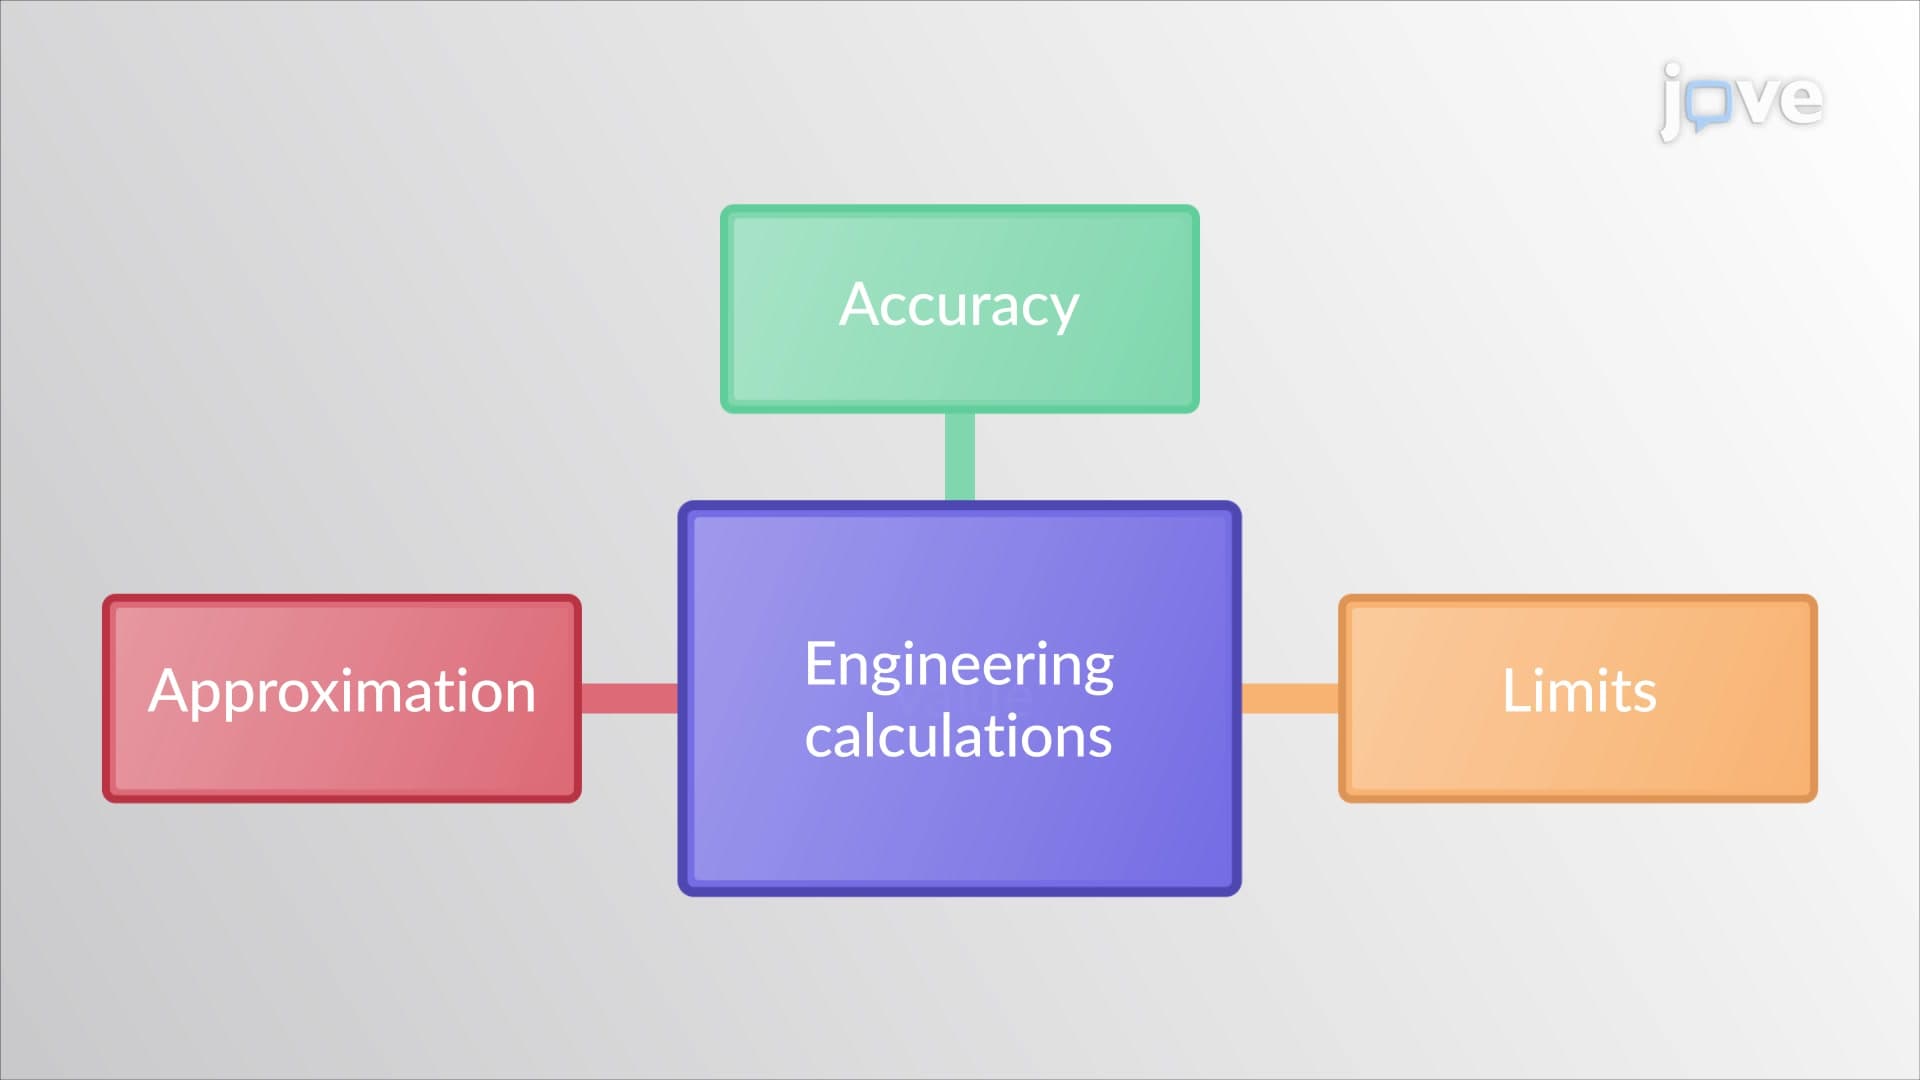
Accuracy, limits, and approximation
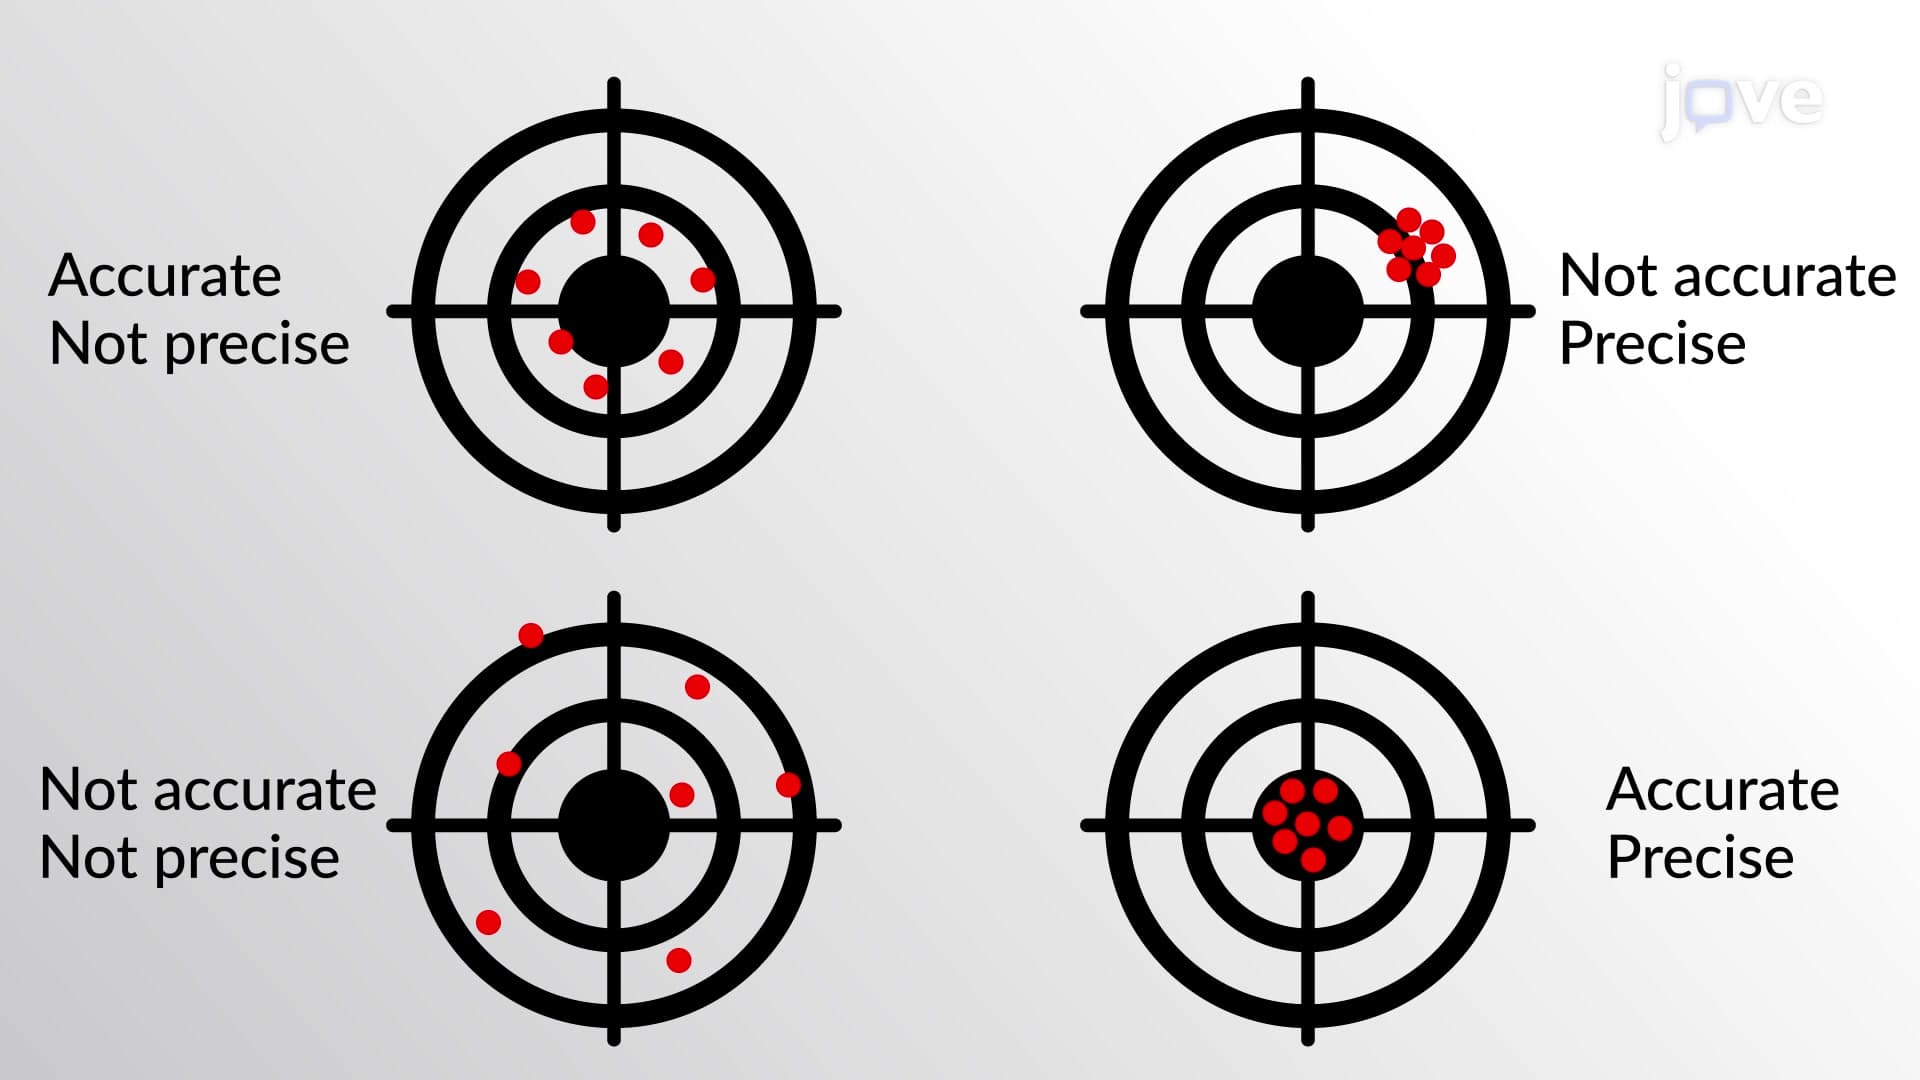
Accuracy is defined as the closeness of the measured value to the true or actual value. In engineering mechanics, repeated measurements are taken during theoretical or experimental analyses to ensure that the result is precise and accurate.
The accuracy of any solution is based on the...
 01:13
Mean Absolute Deviation
Let us consider a dataset containing the number of unsold cupcakes in five shops: 10, 15, 8, 7, and 10. Initially, calculate the sample mean. Then calculate the deviation, or the difference, between each data value and the mean. Next, the absolute values of these deviations are added and divided by the sample size to...
 01:52
Accuracy and Precision
 01:00
Detection of Gross Error: The Q Test