
一种高效的spline技术用于解决时间分数整微分方程
Muhammad Abbas1, Sadia Aslam1, Farah Aini Abdullah2
1Department of Mathematics, University of Sargodha, Sargodha 40100, Pakistan.
Heliyon
|October 9, 2023

概括
本研究介绍了一种扩展立方B线 (ExCuBS) 方法,用于解决分数局部整微分方程. 这种新的方法为复杂的数学模型提供了稳定和融合的数值解决方案.
科学领域:
- 数字分析 数字分析
- 应用数学 应用数学 应用数学
- 计算科学 计算科学
背景情况:
- 在数学中,分线曲线对于近似复杂结构至关重要.
- 分数局部整微分方程 (FPIDE) 模拟各种现象,但难以解决.
- 弱单核 (SK) 在这些方程中带来了额外的复杂性.
研究的目的:
- 开发一个数值方法来解决非线性分数局部整微分方程 (FPIDE) 与弱奇点内核 (SK).
- 为了利用扩展立方B-spline (ExCuBS) 函数和一个新的二次导数近似.
主要方法:
- 使用扩展立方B线 (ExCuBS) 函数对空间分数导数进行分离.
- 使用卡普托有限差异方案的时间分数导数的分离.
- 为了提高准确性,实施了一种新的二次导数近似法.
主要成果:
- 拟议的ExCuBS方法证明了解决FPIDE的稳定性和趋同性.
- 通过ExCuBS方法获得的数值解与现有文献进行验证.
- 该方法有效地接近曲线设计中的复杂结构.
结论:
- 扩展立方B线 (ExCuBS) 方法提供了一种强大而准确的技术,用于用SK解决非线性FPIDE.
- 该研究证实了拟议的数值方案的稳定性和收性.
- 这种方法为研究人员提供了一个有价值的工具,他们致力于小数微积分及其应用.
相关概念视频
 01:21
Linear Approximation in Time Domain
87
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
87
 01:16
Properties of Laplace Transform-II
206
Time differentiation, convolution, integration, and periodicity are fundamental concepts in analyzing functions and signals over time. Each concept provides a unique perspective on how functions evolve, interact, and repeat, offering essential tools for various scientific and engineering applications.
Time differentiation involves analyzing the rate of change of a function over time. Mathematically, it is the derivative of a function with respect to time. This concept can be likened to tracking...
Time differentiation involves analyzing the rate of change of a function over time. Mathematically, it is the derivative of a function with respect to time. This concept can be likened to tracking...
206
 01:24
Difference Equation Solution using z-Transform
307
The z-transform is a powerful tool for analyzing practical discrete-time systems, often represented by linear difference equations. Solving a higher-order difference equation requires knowledge of the input signal and the initial conditions up to one term less than the order of the equation.
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
307
 01:22
Basic Continuous Time Signals
218
Basic continuous-time signals include the unit step function, unit impulse function, and unit ramp function, collectively referred to as singularity functions. Singularity functions are characterized by discontinuities or discontinuous derivatives.
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
218
 01:20
Discrete-Time Fourier Series
282
The Discrete-Time Fourier Series (DTFS) is a fundamental concept in signal processing, serving as the discrete-time counterpart to the continuous-time Fourier series. It allows for the representation and analysis of discrete-time periodic signals in terms of their frequency components. Unlike its continuous counterpart, which utilizes integrals, the calculation of DTFS expansion coefficients involves summations due to the discrete nature of the signal.
For a discrete-time periodic signal x[n]...
For a discrete-time periodic signal x[n]...
282
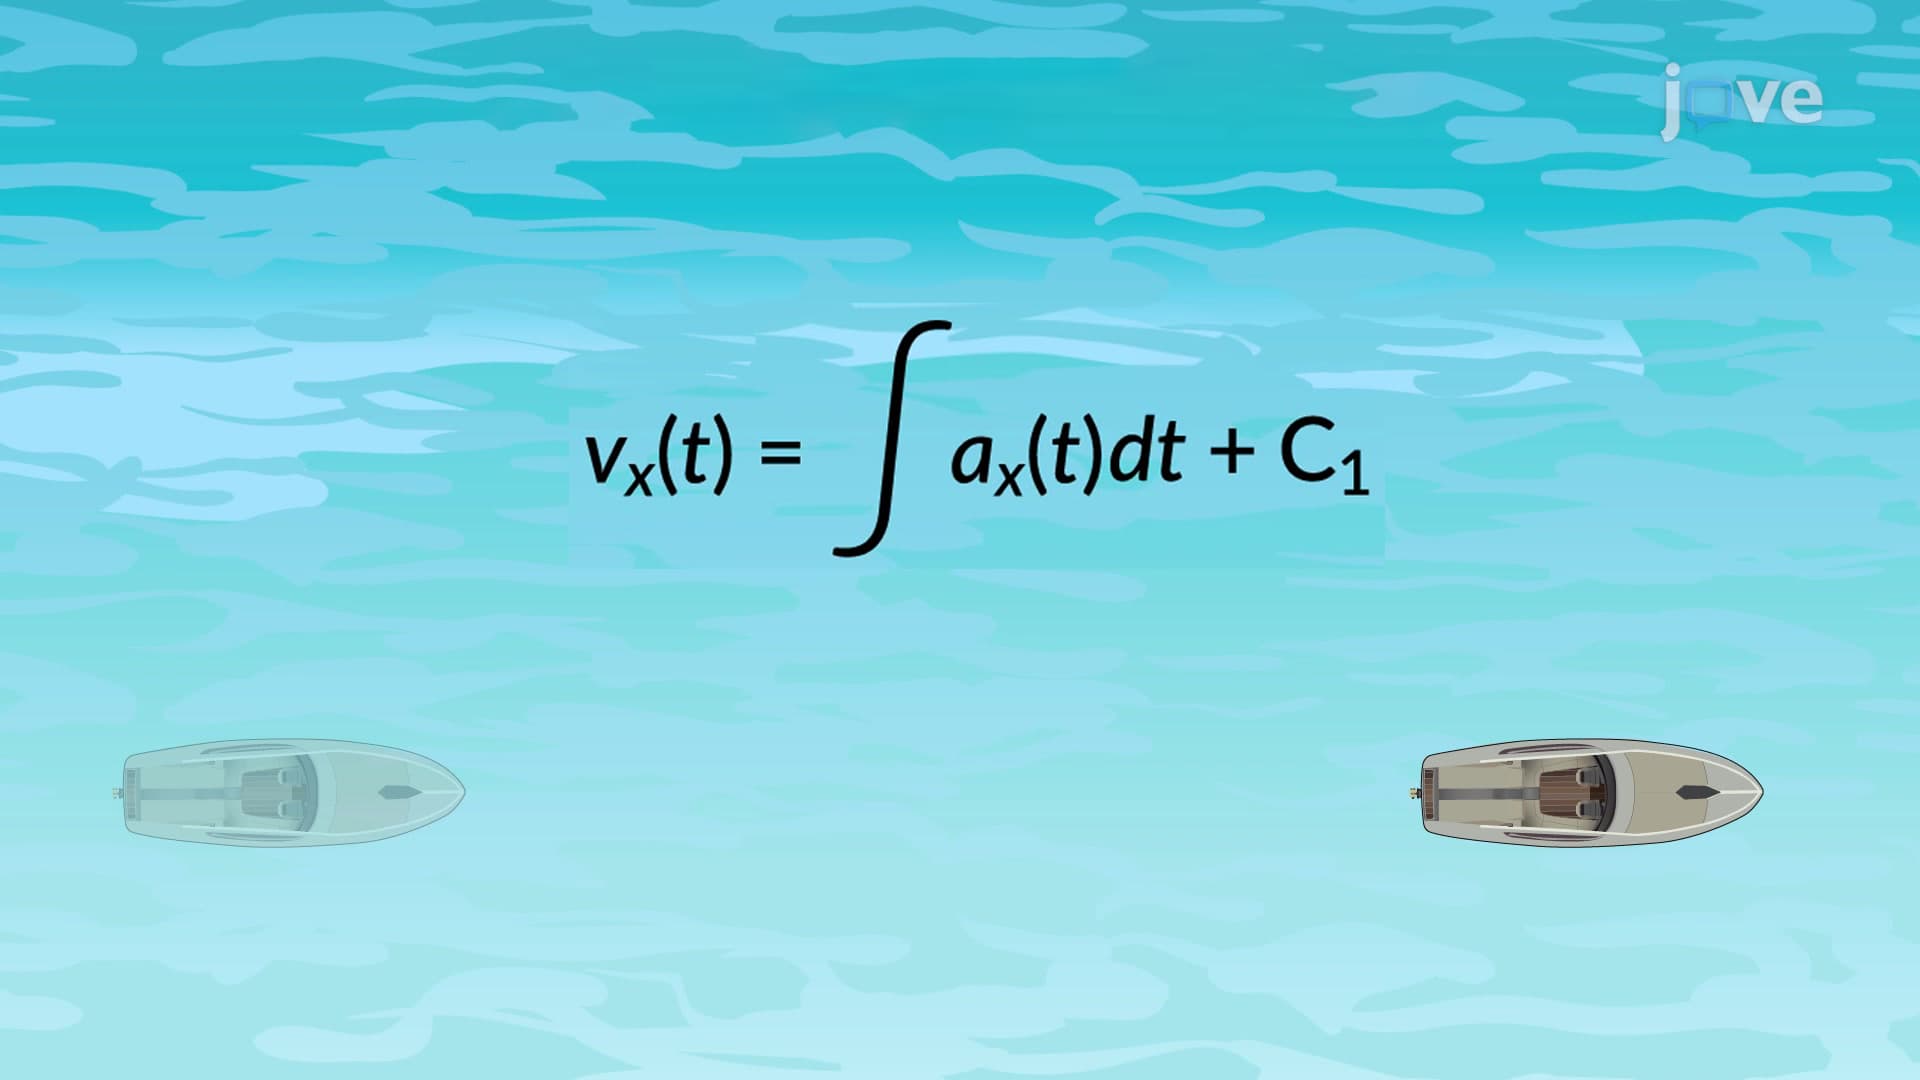 01:13
Velocity and Position by Integral Method
6.1K
If acceleration as a function of time is known, then velocity and position functions can be derived using integral calculus. For constant acceleration, the integral equations refer to the first and second kinematic equations for velocity and position functions, respectively.
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
6.1K