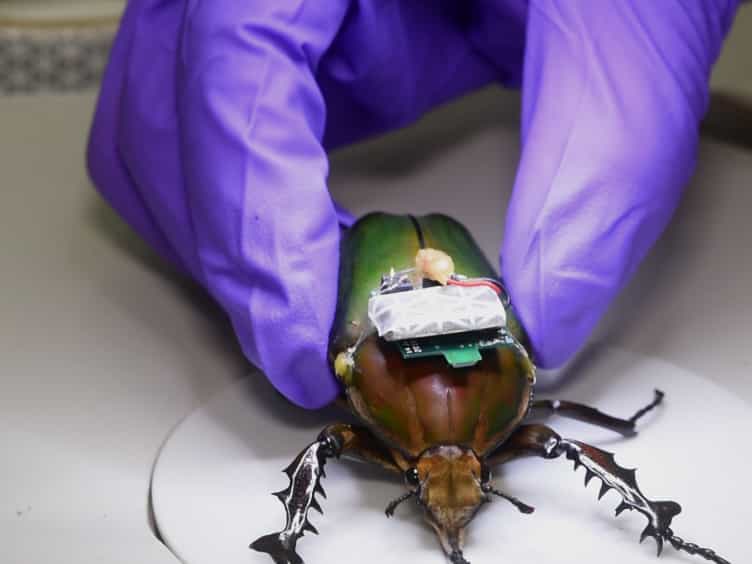

在网络攻击的情况下,四旋翼直升机的轨迹跟踪控制
1School of Automation, Hubei University of Science and Technology, Xianning, 437100, China.
ISA transactions
|October 9, 2023

概括
本研究介绍了一种安全的轨迹跟踪方法,用于面临无线网络攻击的四旋翼. 编码解码方法 (EDA) 增强了攻击检测并减少了错误,确保了更安全的无人机导航.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 网络安全 网络安全
背景情况:
- 四旋翼直升机在无线轨迹传输期间容易受到网络攻击.
- 未知但有限 (UBB) 噪声会影响系统性能和状态估计.
- 确保安全和准确的轨迹跟踪对于自动驾驶系统至关重要.
研究的目的:
- 在网络攻击和UBB噪音下调查四旋翼的安全轨迹跟踪.
- 开发一种编码解码方法 (EDA),以改进攻击检测.
- 设计一个区域位的未知输入观察者 (ZUIO) 进行强大的状态估计.
主要方法:
- 编码解码方法 (EDA) 被设计为单调和连续的功能.
- 开发了一个zonotopic未知输入观察器 (ZUIO) 来处理UBB噪音.
- 控制器和观察者的收益通过最小化zonotope P半径来优化.
主要成果:
- 该EDA显著提高了攻击检测率 (DR).
- EDA参数影响DR和跟踪错误.
- 尽管有UBB噪音,ZUIO有效地估计了直升机状态.
- 数字示例证实了EDA增加DR和降低错误报警率 (FAR) 的能力.
结论:
- 拟议的EDA增强了四旋翼机对轨迹攻击的安全性.
- 在存在UBB噪声时,ZUIO提供了可靠的状态估计.
- 优化EDA参数可以平衡攻击检测和跟踪性能.
更多相关视频


相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
226
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
226
 01:24
Gyroscope: Precession
4.1K
Precession can be demonstrated effectively through a spinning top. If a spinning top is placed on a flat surface near the surface of the Earth at a vertical angle and is not spinning, it will fall over due to the force of gravity producing a torque acting on its center of mass. However, if the top is spinning on its axis, it precesses about the vertical direction, rather than topple over due to this torque. Precessional motion is a combination of a steady circular motion of the axis and the...
4.1K
 01:24
One-Degree-of-Freedom System
495
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
495
 01:02
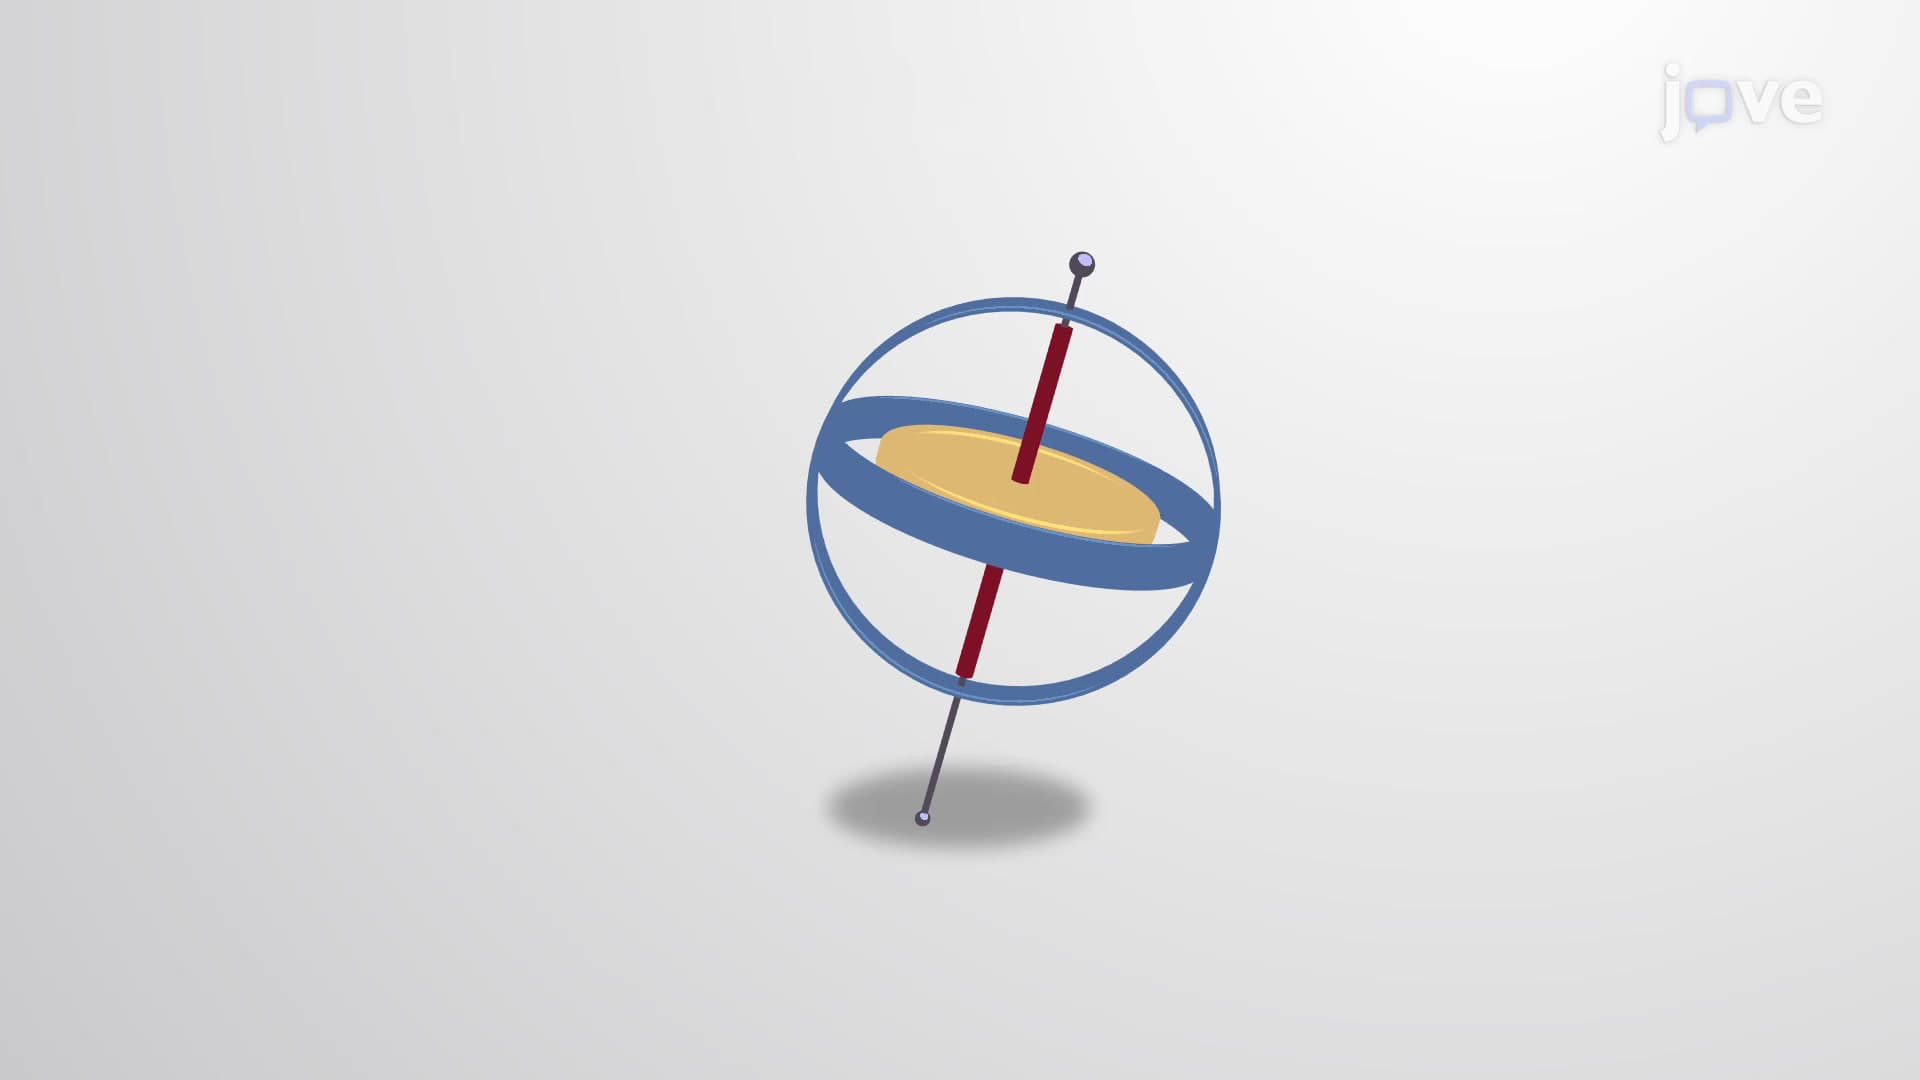
Gyroscope
3.0K
A gyroscope is defined as a spinning disk in which the axis of rotation is free to assume any orientation. When spinning, the orientation of the spin axis is unaffected by the orientation of the body that encloses it. The body or vehicle enclosing the gyroscope can be moved from place to place, while the orientation of the spin axis remains the same. This makes gyroscopes very useful in navigation, especially where magnetic compasses cannot be used, such as in crewed and crewless spacecraft,...
3.0K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
408
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
408
 01:26
Errors in Global Positioning System
49
Global Positioning System (GPS) technology has revolutionized navigation and positioning, but its accuracy is often compromised by various errors. These errors, stemming from environmental, satellite, and receiver-related factors, require careful mitigation to ensure reliable performance across applications.Atmospheric ErrorsGPS signals travel through the Earth’s ionosphere and troposphere, introducing delays which affect accuracy. The ionosphere is strongly influenced by charged particles,...
49