

非线性时间延迟多代理系统的分布式控制:混合和约束冲动方法
IEEE transactions on cybernetics
|October 11, 2023

概括
本研究探讨了具有通信限制和时间延迟的多代理系统中的冲动共识. 一个新的事件触发的冲动控制协议通过减少通信频率,同时防止Zeno行为来提高效率.
科学领域:
- 控制系统工程 控制系统工程
- 网络化系统 网络化系统
- 机器人技术 机器人技术 机器人技术
背景情况:
- 多代理系统面临的挑战是通信限制和时间延迟.
- 在有限的带宽和和条件下达成共识是复杂的.
- 现有的协议可能无法优化通信效率.
研究的目的:
- 调查和约束下多剂系统的冲动共识.
- 开发一种新的控制协议,以提高通信效率.
- 确保达成共识,同时避免Zeno行为和减少通信频率.
主要方法:
- 提出了一种新的控制协议,将事件触发策略和一般冲动控制结合起来.
- 由于通信带宽有限,考虑了全局和部分和限制.
- 利用理论分析来得出达成共识的充分条件.
主要成果:
- 在全球和部分和约束下,获得了实现冲动共识的足够条件.
- 拟议的协议有效地减少了通信频率.
- 成功避免了Zeno的行为.
结论:
- 这种新型事件触发脉冲控制协议对于具有通信限制和时间延迟的多代理系统是有效的.
- 通过模拟示例验证理论发现.
- 这种方法提高了网络控制系统的通信效率.


相关概念视频
 01:07
Time-Domain Interpretation of PD Control
135
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
135
 01:26
Feedback control systems
319
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
319
 01:59
Solution Equilibrium and Saturation
18.7K
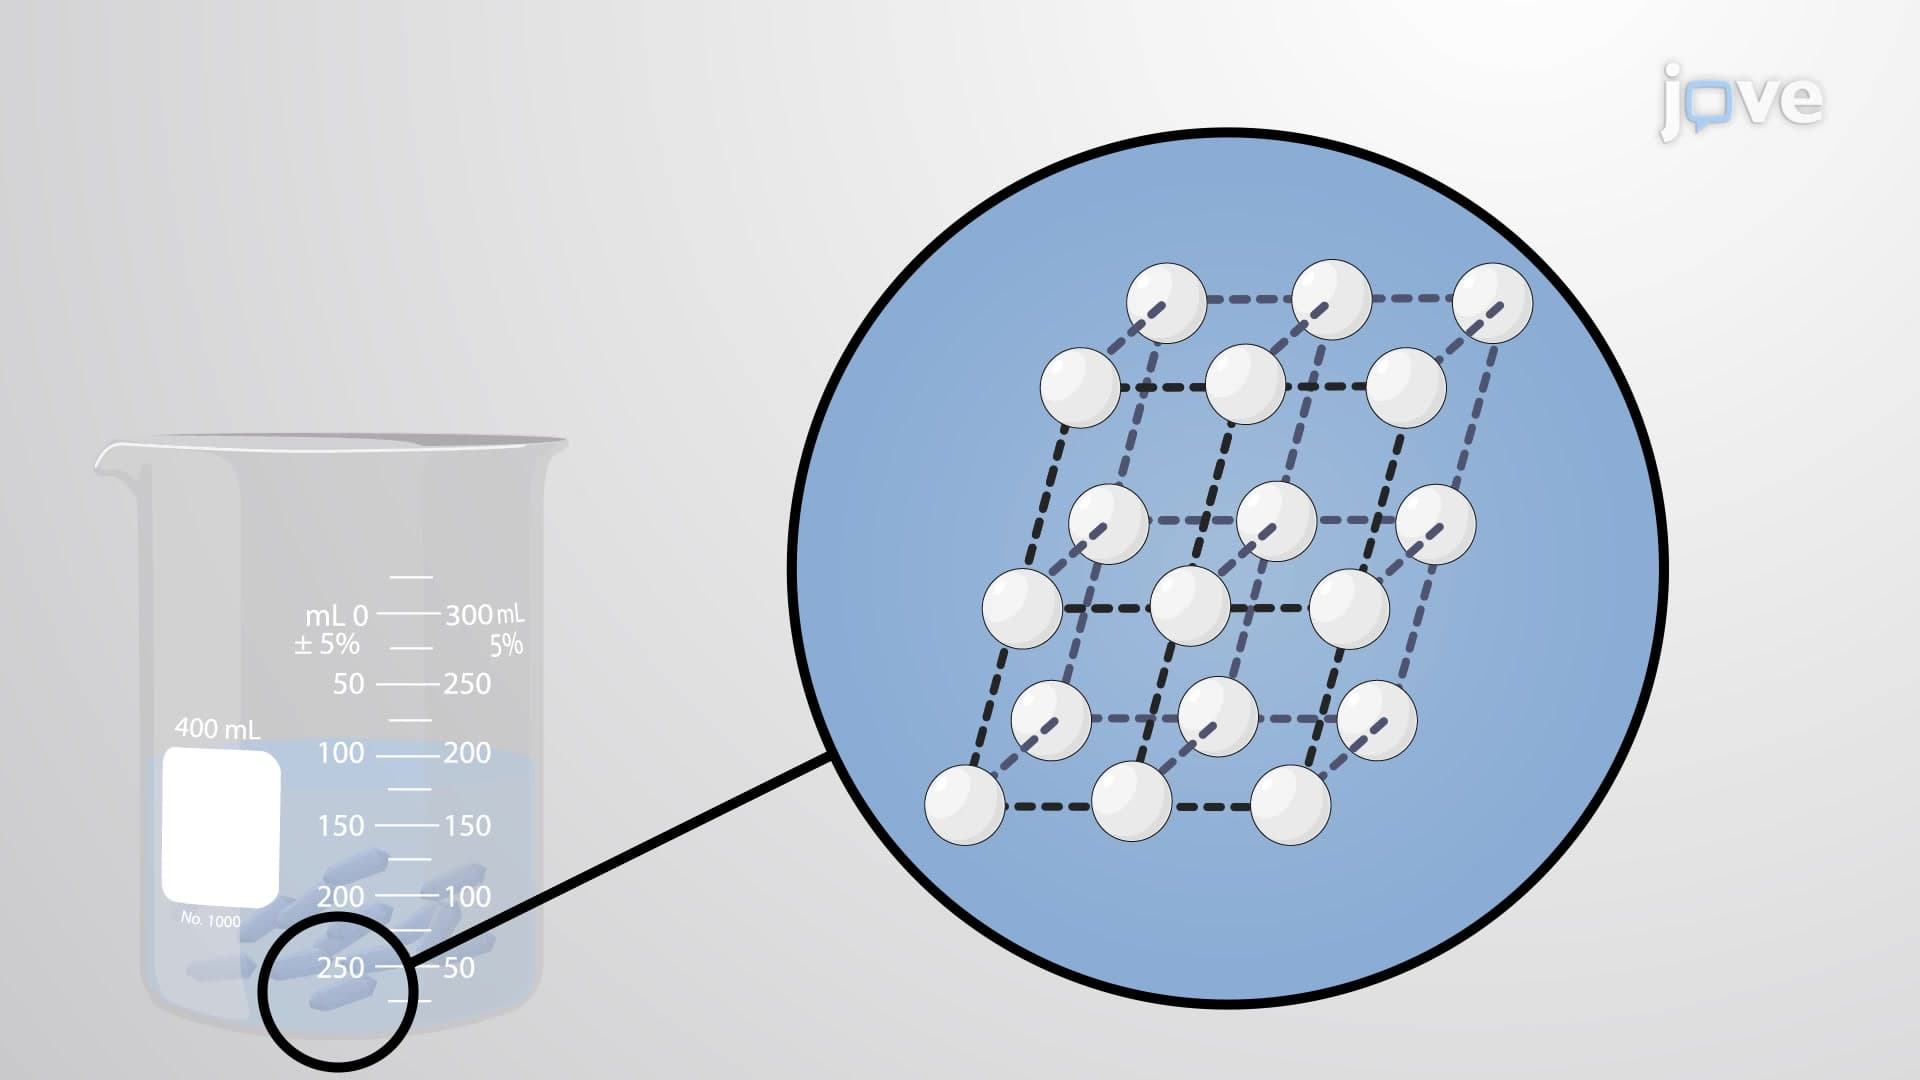
Imagine adding a small amount of sugar to a glass of water, stirring until all the sugar has dissolved, and then adding a bit more. You can repeat this process until the sugar concentration of the solution reaches its natural limit, a limit determined primarily by the relative strengths of the solute-solute, solute-solvent, and solvent-solvent attractive forces. You can be certain that you have reached this limit because, no matter how long you stir the solution, undissolved sugar remains. The...
18.7K
 01:22
Multi-input and Multi-variable systems
111
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
111
 01:24
BIBO stability of continuous and discrete -time systems
408
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
408
 01:26
PD Controller: Design
256
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
256