PLMP - 在完整的多视图可见性中的点线最小问题
IEEE transactions on pattern analysis and machine intelligence
|October 16, 2023

概括
研究人员对计算机视觉中的30个最小问题进行了分类,用于使用校准相机进行3D重建. 这些问题涉及点和线,复杂性随着视图数量的增加而增加,在图像匹配中提供了实际应用.
科学领域:
- 计算机视觉 计算机视觉
- 计算几何学的计算几何学
- 机器人技术 机器人技术 机器人技术
背景情况:
- 最小问题是几何计算机视觉的基础,定义了场景重建的最简单的配置.
- 了解这些问题对于强大的3D重建和摄像头校准至关重要.
研究的目的:
- 通过校准的透视摄像头观察到的点和线条的安排,提供所有最小问题的完整分类.
- 要确定这些最小问题所涉及的最大数量的摄像头,点和线.
主要方法:
- 利用度数计数和符号/数字验证来识别和验证最小的问题.
- 分析了视图数和最小问题的复杂性 (代数度) 之间的关系.
主要成果:
- 确定了总共30个独特的最小问题.
- 确定的上限:对于超过6个摄像头,5个点或6条线路,没有最小问题.
- 描述了每个最小问题的代数度 (解决方案数),表示它们的难度.
结论:
- 该研究提出了一个全面的目录的最小问题在多视图几何学.
- 一些新发现的低代数度的最小问题为现实世界的应用提供了实用优势,如图像匹配和3D重建.
相关概念视频
 01:21
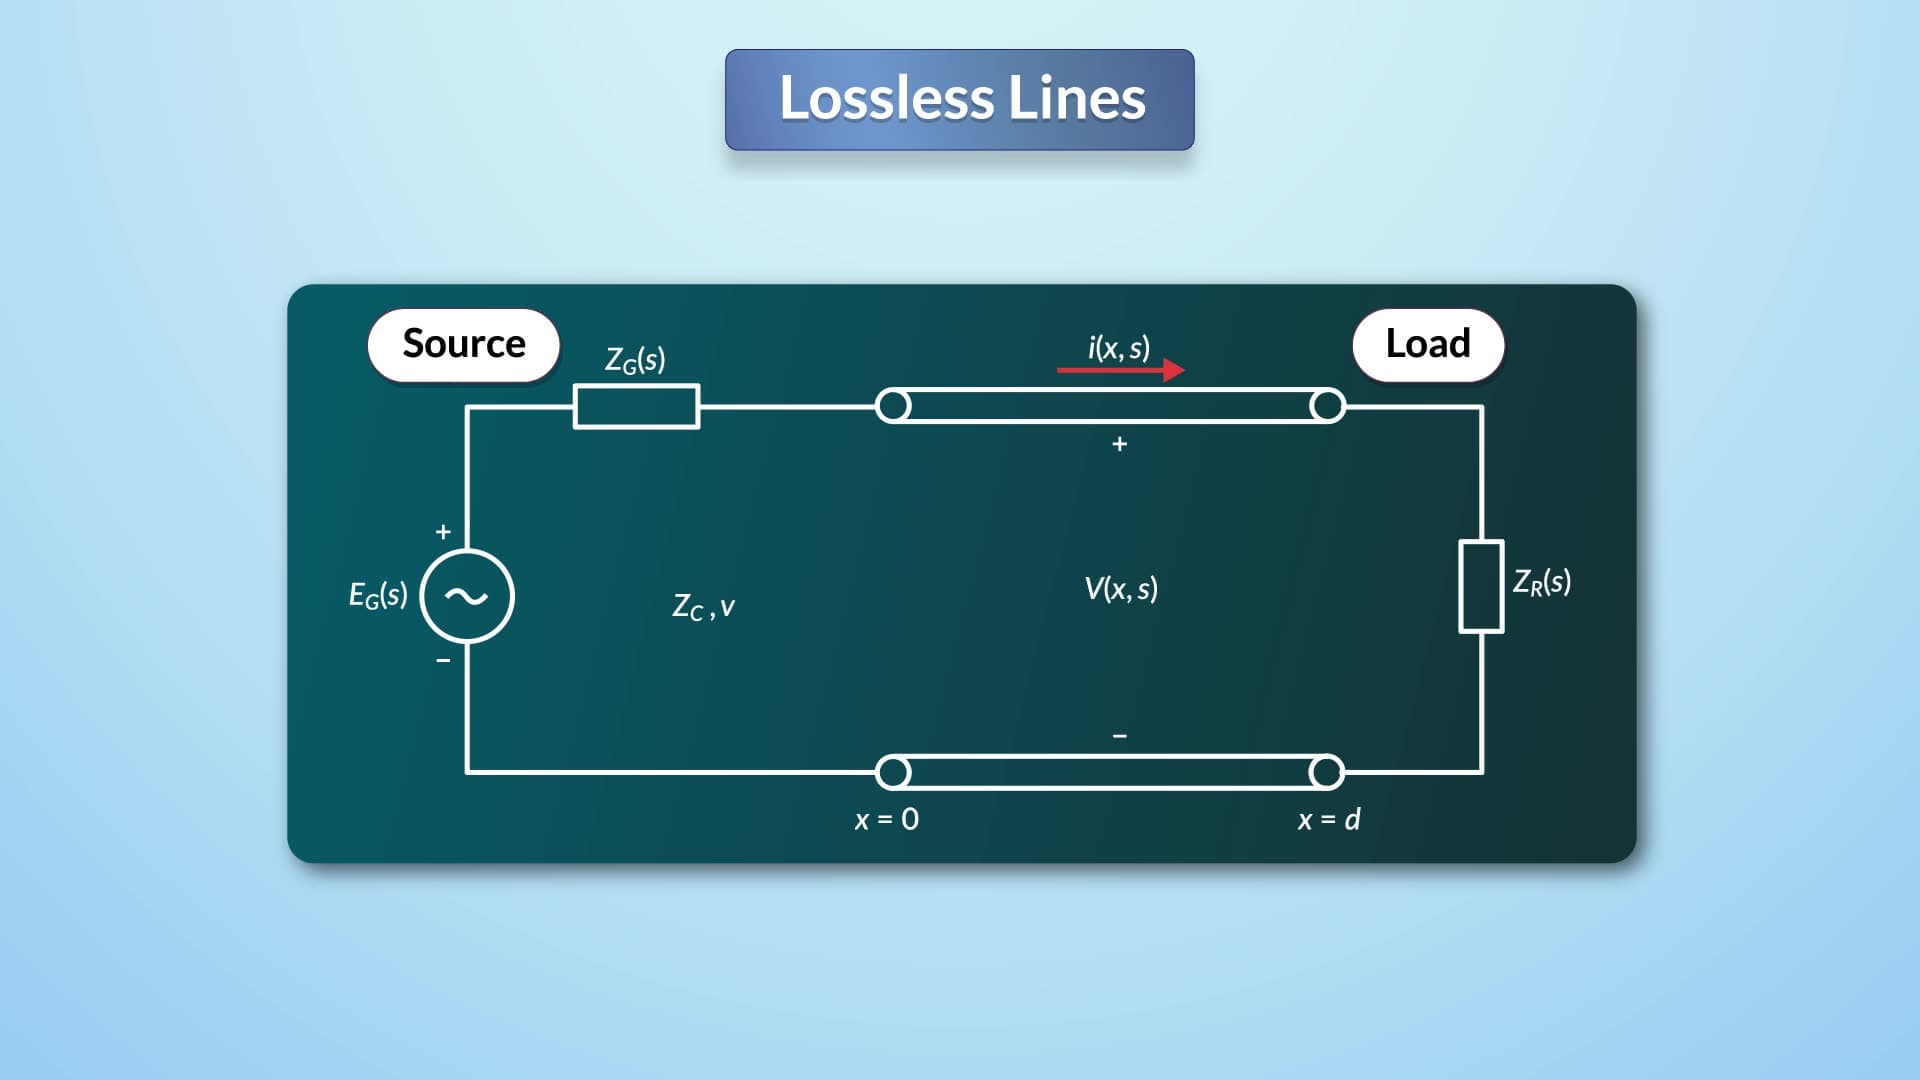
Boundary Conditions: Lossless Lines
99
Consider a single-phase, two-wire, lossless transmission line terminated by an impedance at the receiving end and a source with Thevenin voltage and impedance at the sending end. The line, with length, has a surge impedance and wave velocity determined by the line's inductance and capacitance.
At the receiving end, the boundary condition states that the voltage equals the product of the receiving-end impedance and current. This relationship is expressed as a function of the incident and...
At the receiving end, the boundary condition states that the voltage equals the product of the receiving-end impedance and current. This relationship is expressed as a function of the incident and...
99
 01:06
Collisions in Multiple Dimensions: Problem Solving
4.2K
In multiple dimensions, the conservation of momentum applies in each direction independently. Hence, to solve collisions in multiple dimensions, we should write down the momentum conservation in each direction separately. To help understand collisions in multiple dimensions, consider an example.
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
4.2K
 01:29
Sight Distance in a Vertical Curve
54
Sight distance on vertical curves is critical in roadway design. It ensures drivers can see far enough ahead to identify and respond to hazards effectively. This directly impacts safety, driver comfort, and the overall efficiency of the transportation network.Vertical curves are classified into crest and sag curves based on their geometry. For crest curves, sight distance is determined by the line of sight between a driver's eye and a small object on the road's surface. Design parameters for...
54
 01:18
Uniform Depth Channel Flow: Problem Solving
70
To calculate the flow rate for a trapezoidal channel, first, identify the bottom width, side slope, and flow depth of the channel. The cross-sectional area (A) corresponding to the depth of flow (y), channel bottom width (B), and side slope (θ) is determined by:Next, calculate the wetted perimeter, which includes the bottom width and the sloped side lengths in contact with the water. Using the values of the cross-sectional area and the wetted perimeter, determine the hydraulic radius by...
70
 01:15
Depth Perception and Spatial Vision
681
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
681
 01:18
Reducing Line Loss
156
In a three-phase circuit, line loss is an indicator of energy dissipated as heat due to the resistance of transmission lines. To address this, incorporating transformers into the system—a step-up transformer at the source and a step-down transformer at the load—is a strategic solution. Two three-phase transformers are introduced to improve this.
With a step-up transformer at the source, the voltage is increased, thereby reducing the current in the transmission lines since power loss...
With a step-up transformer at the source, the voltage is increased, thereby reducing the current in the transmission lines since power loss...
156