

概括
这项研究引入了一种新的空间载体边缘解调技术,使用状态空间建模进行精确的相位估计. 与现有方法相比,该方法提高了噪声的稳定性和准确性.
科学领域:
- 光学和光子学 在光学和光子学.
- 信号处理 信号处理
- 计量学 计量学 计量学
背景情况:
- 精确的相位估计在光学计量学和干扰计量学中至关重要.
- 现有的边缘解调技术经常与噪音和复杂的背景变化作斗争.
- 状态空间建模为动态系统估计提供了一个强大的框架.
研究的目的:
- 提出一种新的空间载体边缘解调技术,用于增强相位估计.
- 为了同时估计边缘背景强度,载波频率和相方程组件.
- 评估拟议方法的性能与既有技术相比.
主要方法:
- 一种状态空间建模方法用于相位估计.
- 扩展的卡尔曼波器用于状态估计.
- 在状态向量内实现了边缘参数的同时估计.
主要成果:
- 拟议的技术证明了噪声强度的提高.
- 与传统方法相比,相位估计的准确性大大提高.
- 模拟和实验结果都验证了该方法的有效性.
结论:
- 状态空间建模方法为空间载体边缘解调提供了有效的解决方案.
- 基于卡尔曼波器的扩展方法在杂的环境中提供了卓越的性能.
- 这种技术提高了光学测量应用中的相位估计精度.
相关概念视频
 01:27
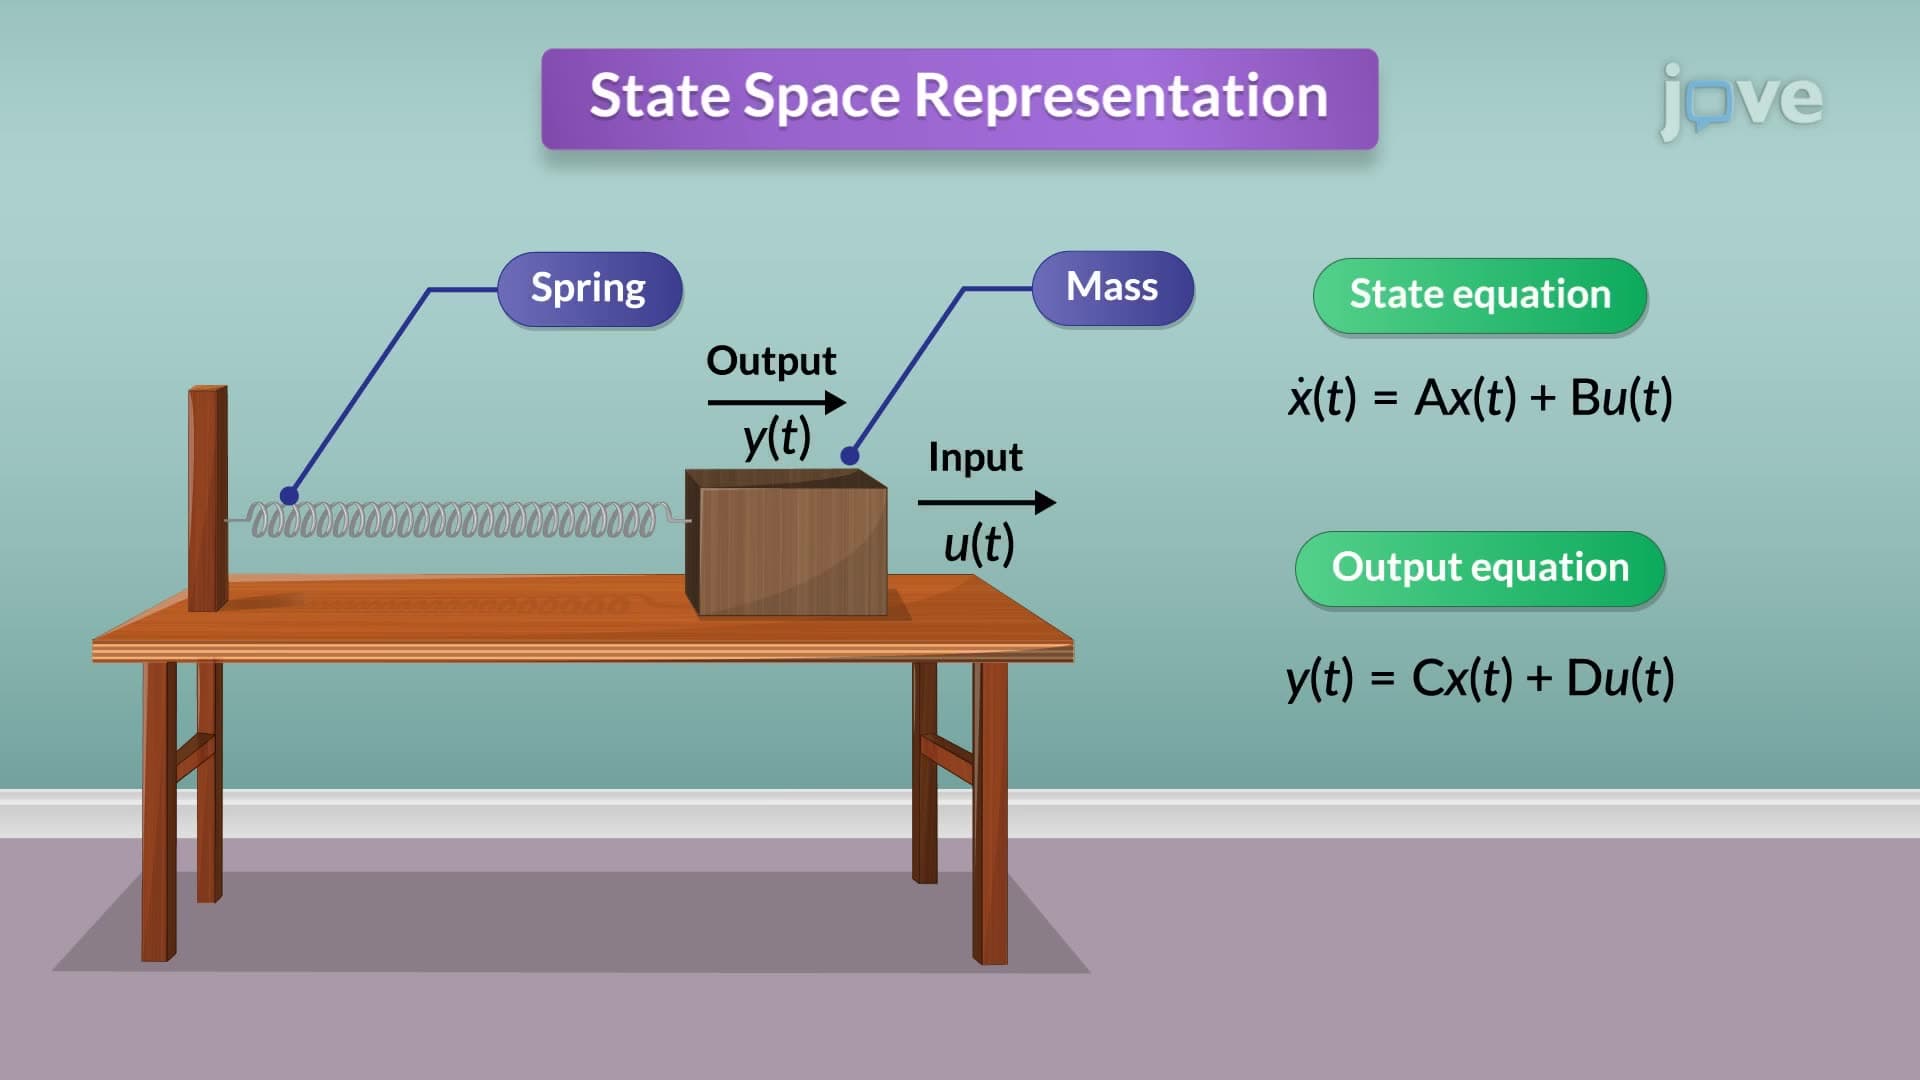
State Space Representation
214
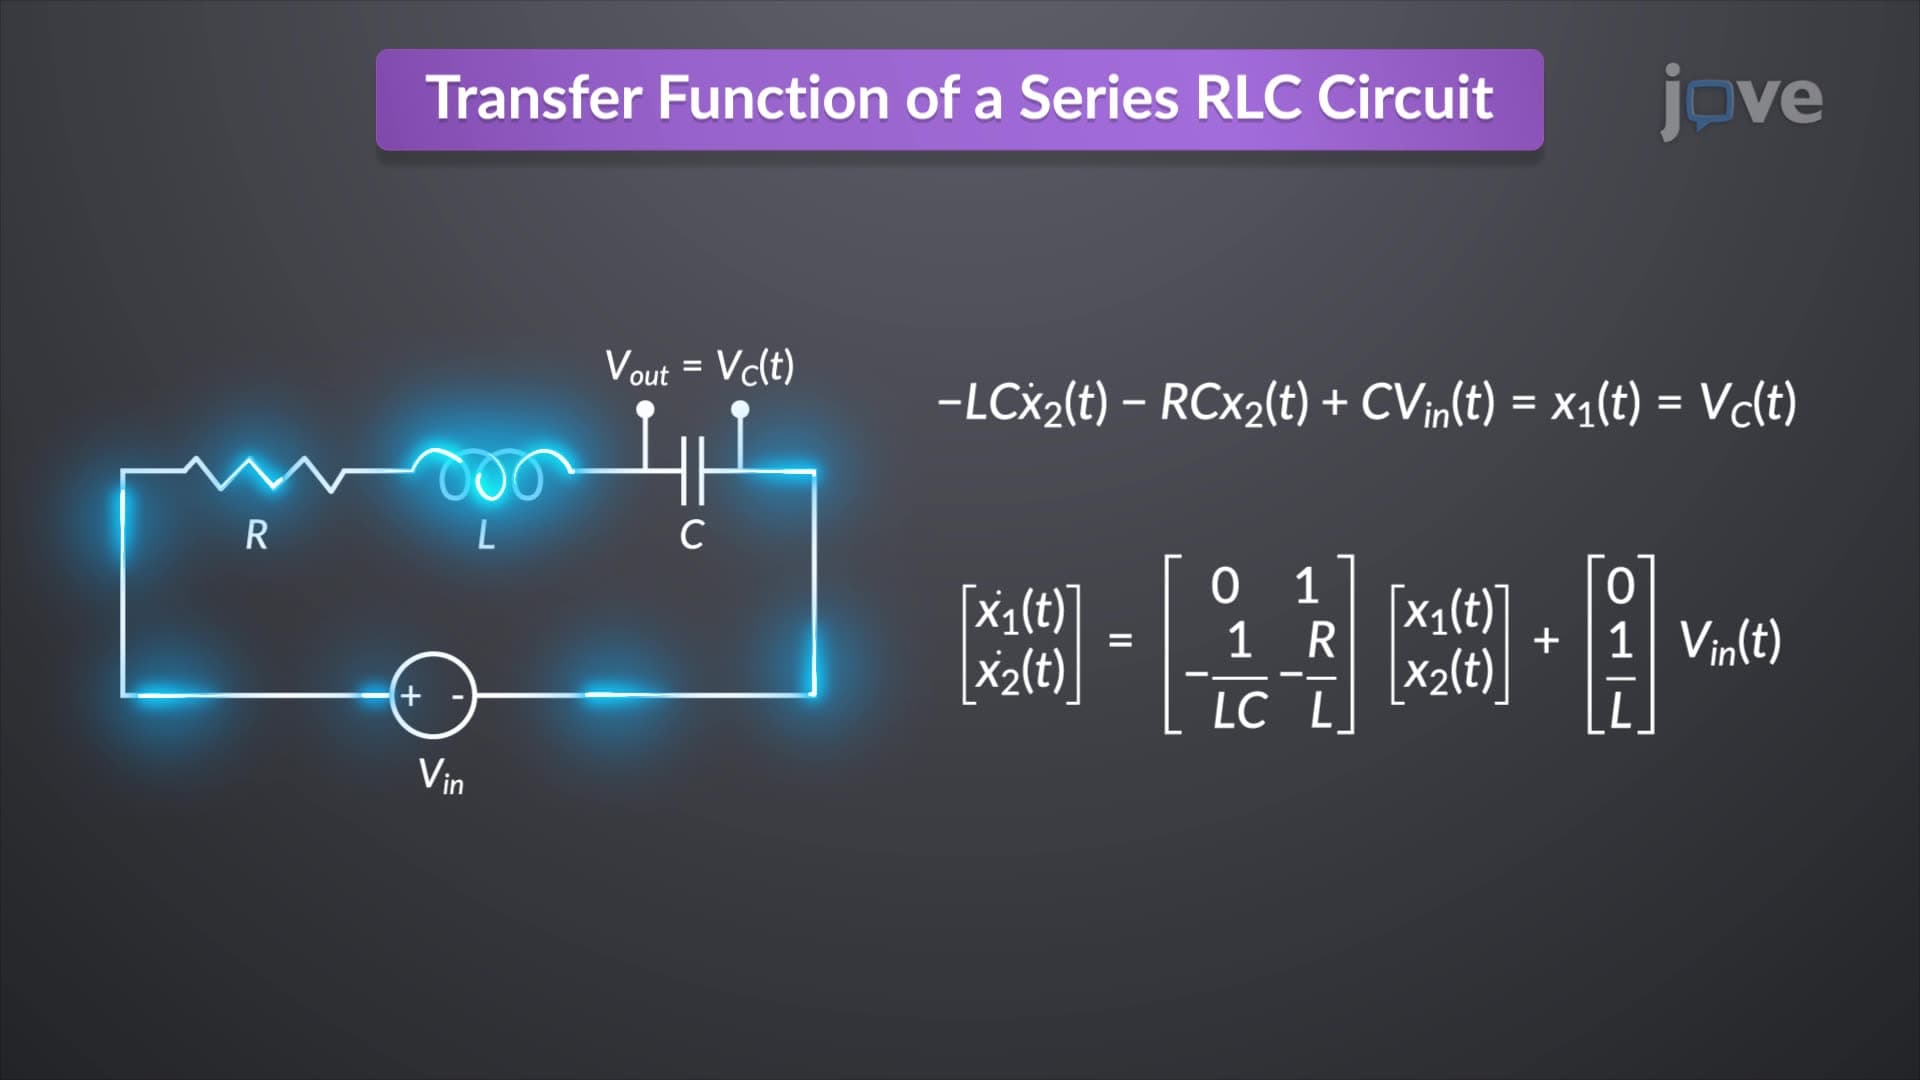
The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Consider an RLC circuit, a...
214
 01:21
State Space to Transfer Function
215
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
215
 01:23
Transfer Function to State Space
271
State-space representation is a powerful tool for simulating physical systems on digital computers, necessitating the conversion of the transfer function into state-space form. Consider an nth-order linear differential equation with constant coefficients, like those encountered in an RLC circuit. The state variables are selected as the output and its n−1 derivatives. Differentiating these variables and substituting them back into the original equation produces the state equations.
In an...
In an...
271
 01:21
Linear Approximation in Time Domain
85
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
85
 01:20
Discrete-Time Fourier Series
280
The Discrete-Time Fourier Series (DTFS) is a fundamental concept in signal processing, serving as the discrete-time counterpart to the continuous-time Fourier series. It allows for the representation and analysis of discrete-time periodic signals in terms of their frequency components. Unlike its continuous counterpart, which utilizes integrals, the calculation of DTFS expansion coefficients involves summations due to the discrete nature of the signal.
For a discrete-time periodic signal x[n]...
For a discrete-time periodic signal x[n]...
280
 01:10
Interference: Path Lengths
1.3K
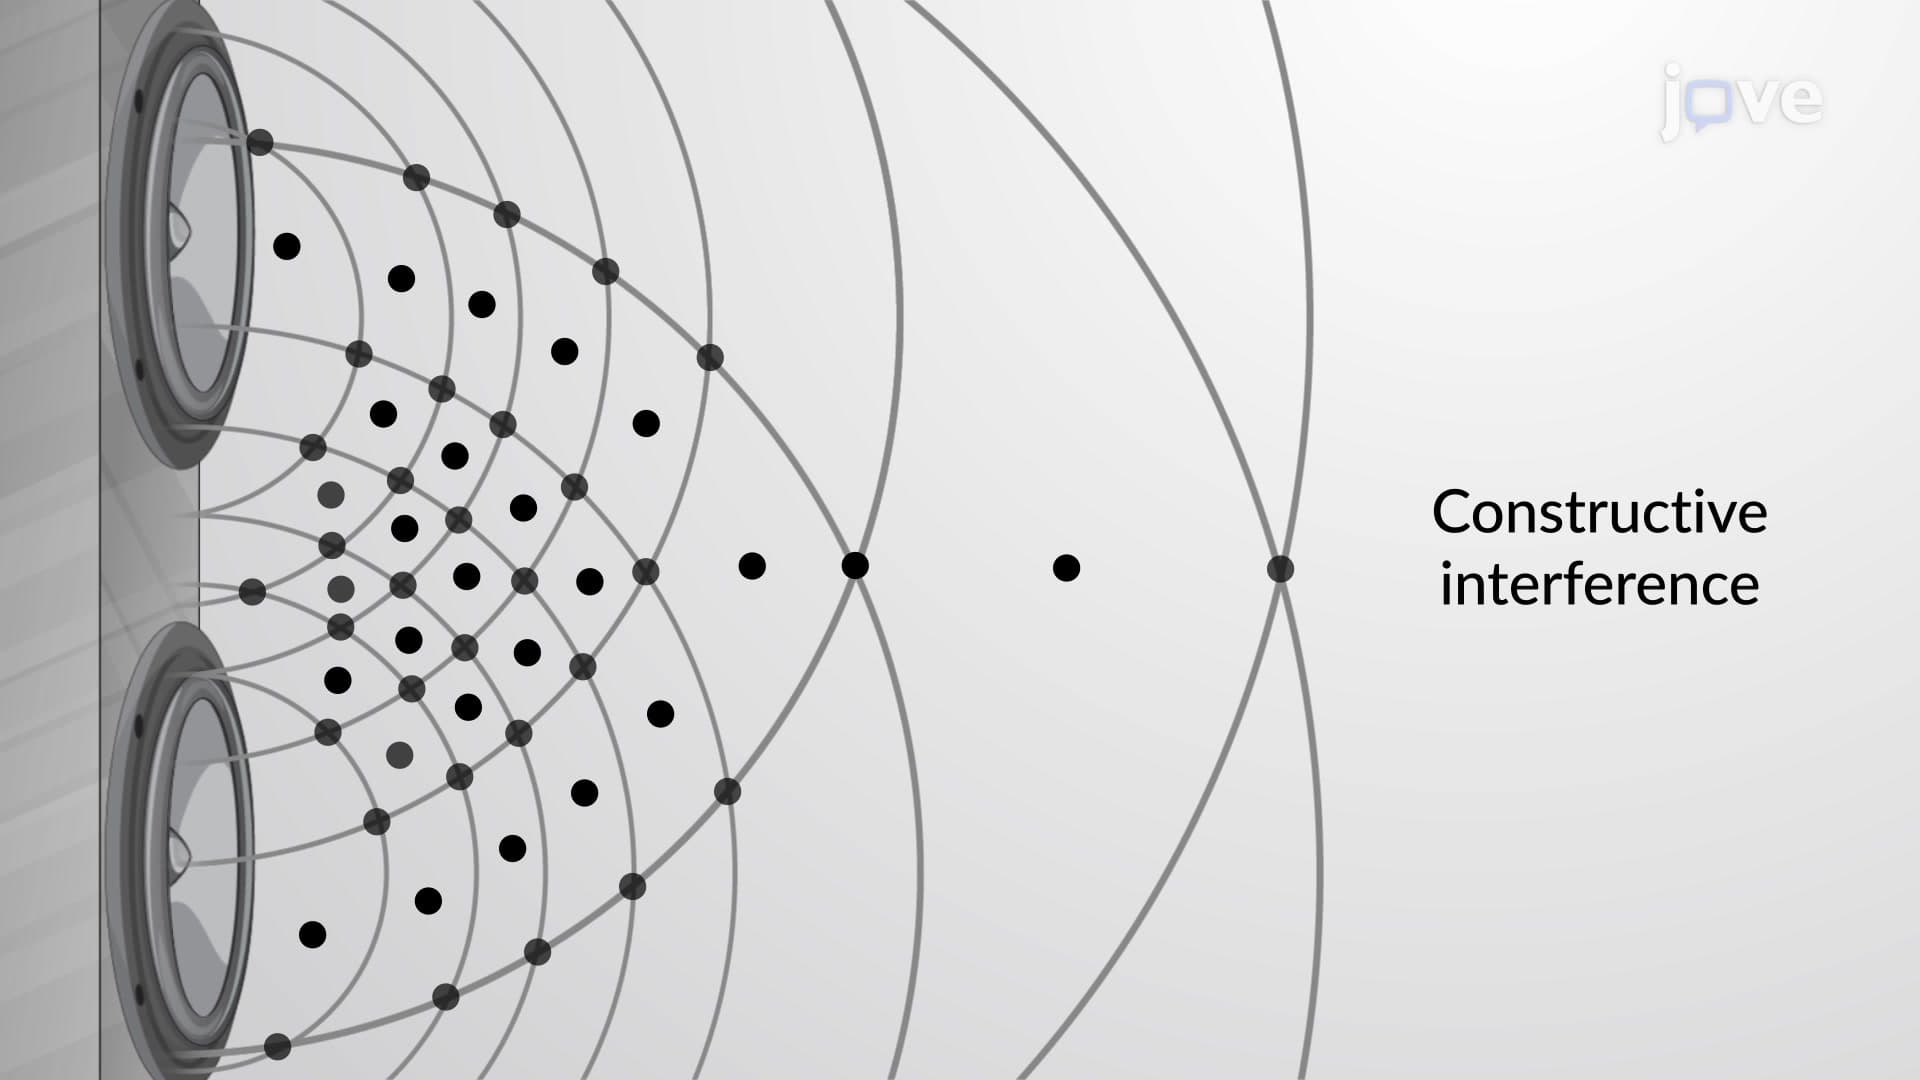
Consider two sources of sound, that may or may not be in phase, emitting waves at a single frequency, and consider the frequencies to be the same.
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
1.3K