用时间延迟识别布尔控制网络的识别
Tiantian Mu1, Jun-E Feng1, Biao Wang2
1School of Mathematics, Shandong University, No. 27 Shanda South Road, Jinan, PR China.
ISA transactions
|October 21, 2023

概括
本研究介绍了使用Cheng产品识别时间延迟布尔网络 (TBN) 和时间延迟布尔控制网络 (TBCN) 的方法. 介绍了算法来确定网络参数和结构,增强系统分析.
科学领域:
- 系统生物学 系统生物学
- 控制理论 控制理论
- 网络科学 网络科学
背景情况:
- 布尔网络 (BNs) 被广泛用于模拟复杂的生物系统.
- 时间延迟布尔网络 (TBNs) 和时间延迟布尔控制网络 (TBCNs) 引入了对准确建模至关重要的时间动态.
- 从输入输出数据中识别这些网络的结构和参数对于理解系统行为至关重要.
研究的目的:
- 开发用于识别时间延迟布尔网络 (TBNs) 和时间延迟布尔控制网络 (TBCNs) 的新方法.
- 建立基于系统可观测性的TBNs和TBCNs的识别标准.
- 介绍选择延迟参数和重建这些网络的内部结构的算法.
主要方法:
- 使用成产品进行网络分析.
- 根据允许的输入-输出序列来定义可识别性.
- 设计延迟参数选择和子系统分解的算法.
- 应用可观察性标准来进行结构性识别.
主要成果:
- 为TBNs和TBCNs提供了可识别性的正式定义.
- 开发了两个算法来选择适当的延迟参数.
- 可识别性标准是使用可观察性概念来推导的.
- 介绍了构建流程,以确定内部网络结构.
结论:
- 提出的方法为识别TBN和TBCN提供了一种可行的方法.
- 开发的算法和标准有助于更深入地了解动态网络属性.
- 插图示例证实了所介绍的识别技术的有效性.

相关概念视频
 01:26
Feedback control systems
319
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
319
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
89
Phase-lead controllers are commonly used in various control systems to enhance response speed and stability. Adjusting the brightness on a television screen offers a practical example of phase-lead control. When contrast is enhanced, a phase-lead controller is employed. Mathematically, phase-lead control is identified when the first parameter is smaller than the second.
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
89
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
101
Phase-lag controllers are widely used in control systems to improve stability and reduce steady-state errors. A dimmer switch controlling the brightness of a light bulb serves as a practical example of phase-lag control, gradually adjusting the bulb's brightness. Mathematically, phase-lag control or low-pass filtering is represented when the factor 'a' is less than 1.
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
101
 01:23
Linear time-invariant Systems
264
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
264
 01:21
Transfer Function in Control Systems
522
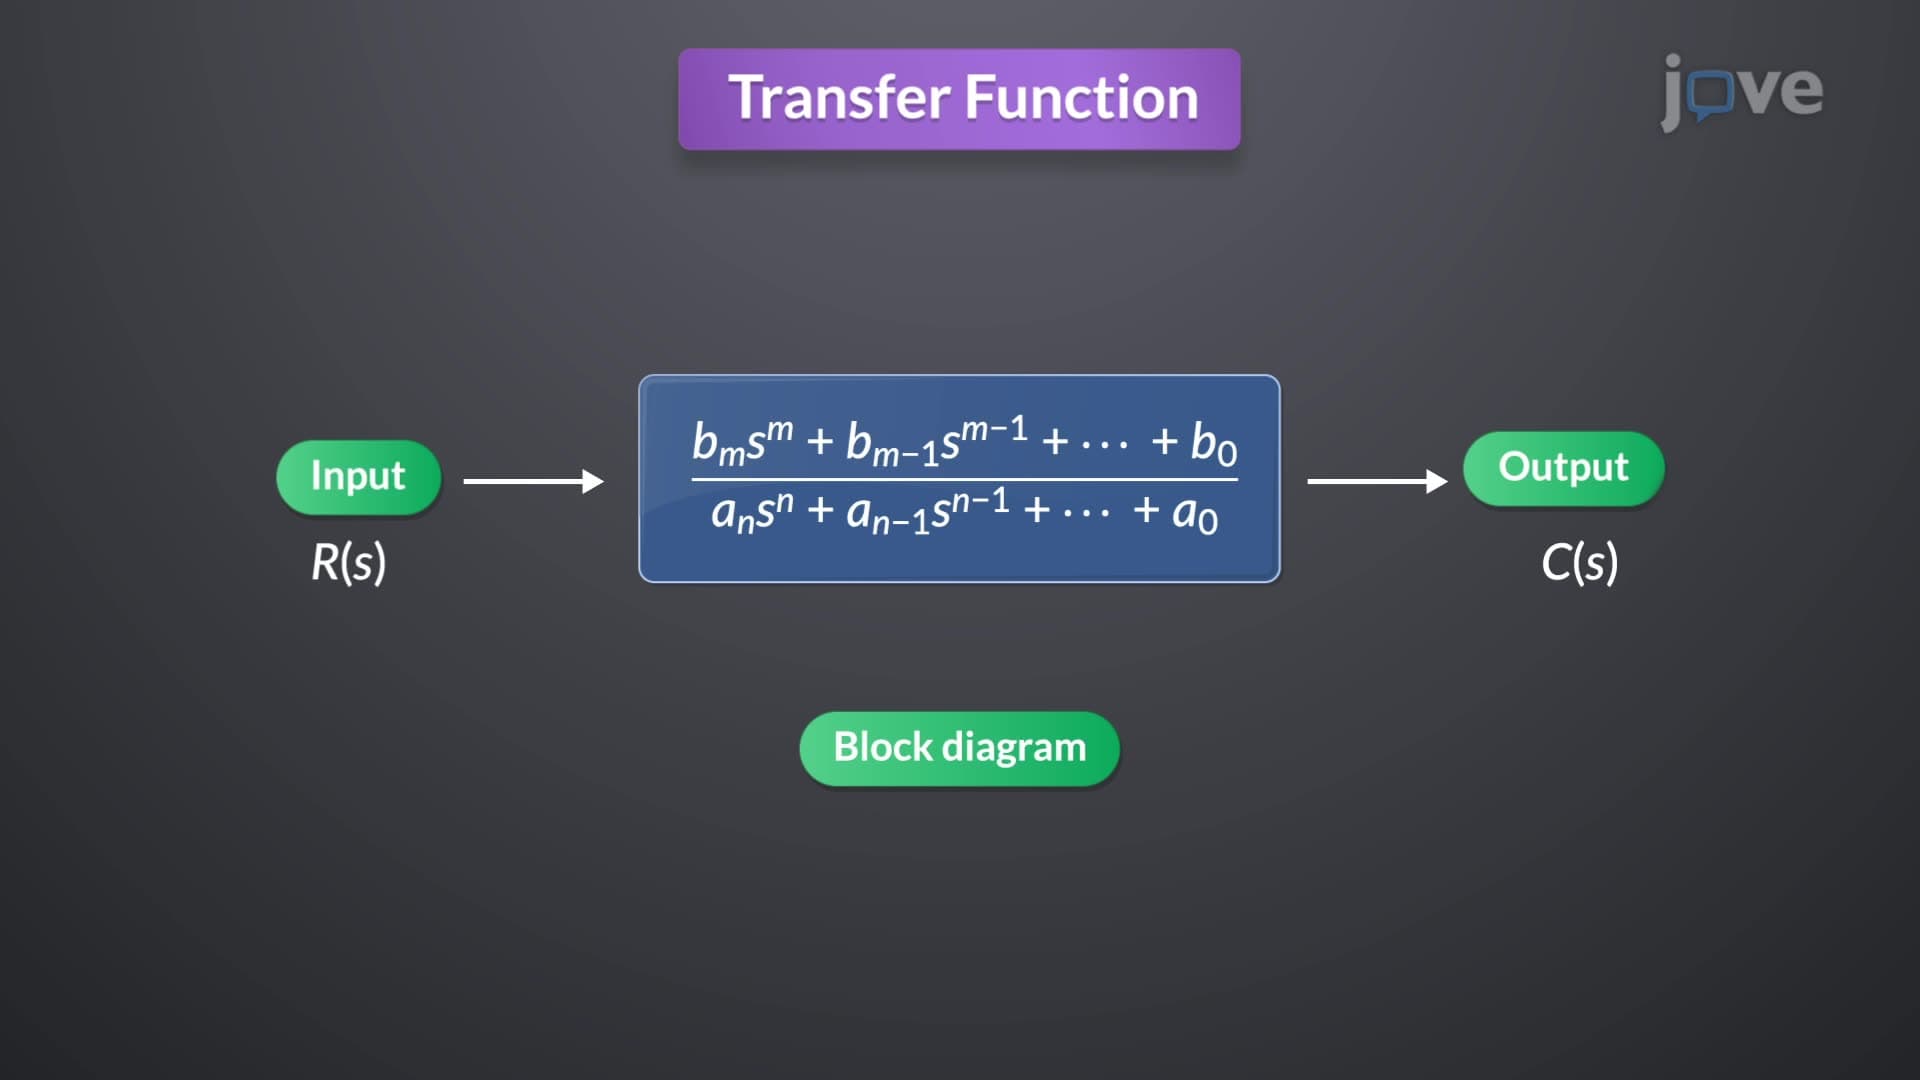
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
522
 01:31
Classification of Systems-II
150
Continuous-time systems have continuous input and output signals, with time measured continuously. These systems are generally defined by differential or algebraic equations. For instance, in an RC circuit, the relationship between input and output voltage is expressed through a differential equation derived from Ohm's law and the capacitor relation,
150