

一种基于网络摄像头的机器学习方法,用于三维运动范围评估
Xiaoye Michael Wang1, Derek T Smith2, Qin Zhu2
1Faculty of Kinesiology and Physical Education, University of Toronto, Toronto, ON, Canada.
PloS one
|October 23, 2023

概括
使用网络摄像头的新机器学习方法提供了一种可靠的方法,可以远程测量关节运动范围 (ROM). 这项技术可以改善有限的人身医疗服务的患者的物理治疗可访问性.
科学领域:
- 生物医学工程 生物医学工程
- 康复技术 康复技术 康复技术
- 医疗保健中的机器学习
背景情况:
- 关节运动范围 (ROM) 对于物理治疗评估至关重要.
- 传统的仪使用需要专门的培训,并限制患者远程访问.
- 目前的方法为个人有限的个人医疗保健服务提供障碍.
研究的目的:
- 引入和评估一种基于机器学习的新方法,用于使用网络摄像机技术评估联合运动范围 (ROM).
- 为ROM测量提供远程可访问的解决方案.
- 为了确定这种创新的方法的可靠性和有效性.
主要方法:
- 开发了一种机器学习模型,通过网络摄像头来评估关节运动范围 (ROM).
- 来自网络摄像头的ROM测量与基于黄金标准标记器的光学运动捕捉系统进行了比较.
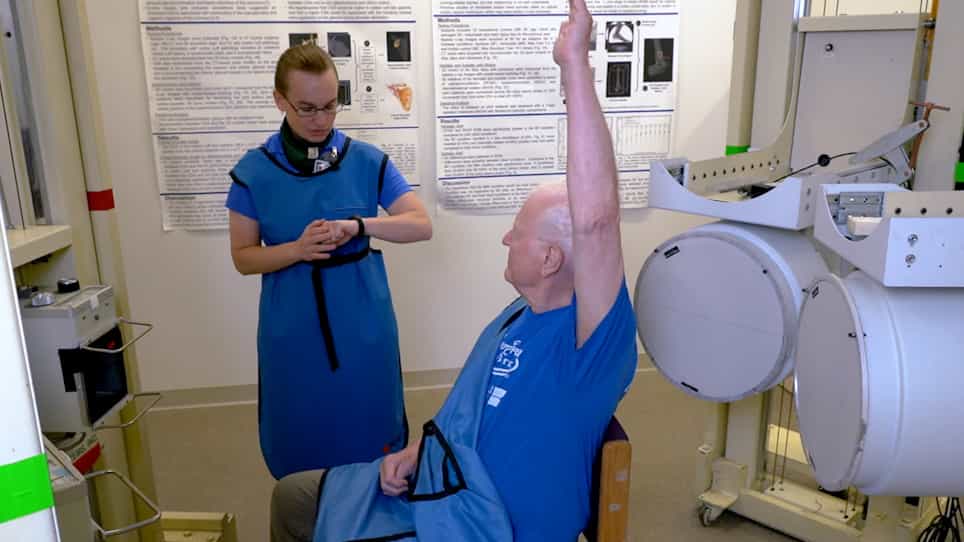
- 在25名健康成年人中,评估了各种关节的可靠性,包括部,脊柱和四肢.
主要成果:
- 基于网络摄像头的系统对大多数关节表现出高的测试-重新测试可靠性,具有相当大的到几乎完美的类内相关系数.
- 关节间的可靠性在一些关节中是相当的,几乎是完美的,但在其他关节中则较低,例如肩膀和肘部曲.
- 观察到的差异可能是由于系统在峰值运动时对关节定位的敏感性.
结论:
- 拟议的基于网络摄像头的方法显示了高的测试复试和测试者之间的可靠性,为ROM评估提供了可行的替代方案.
- 这项技术可以增强临床实践,并促进物理治疗和康复的远程实施.
- 它通过实现远程联合运动范围评估来解决物理治疗中的可访问性挑战.

相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
471
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
471
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
407
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
407