生物灵感软机器人用于深海勘探
Guorui Li1,2,3, Tuck-Whye Wong4,5, Benjamin Shih6
1Qingdao Innovation and Development Base, Harbin Engineering University, Qingdao, China. grli@hrbeu.edu.cn.
Nature communications
|November 5, 2023

概括
受深海生物的启发,研究人员正在开发用于海洋探索的软机器人. 这些生物灵感的机器可以克服极端压力和恶劣的条件,为深海研究提供新的解决方案.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 海洋生物学 海洋生物学
- 生物模拟学是一种生物模拟学.
背景情况:
- 深海对探索提出了极端的环境挑战,包括高压,低温和黑暗.
- 传统的深海勘探车辆需要重型,耐压结构,限制其机动性和设计.
- 深海生物已经发展出独特的适应性,在没有严格的保护的情况下在这些恶劣环境中壮成长.
研究的目的:
- 探索设计策略和生物灵感软机器人深海勘探的最新进展.
- 解决与开发能够在极端深海条件下工作的机器人相关的挑战.
- 突出软机器人的潜力,使深海的深度探索和操作成为可能.
主要方法:
- 研究深海物种的适应压力的形式和独特的推进方法.
- 分析深海生物的感觉系统和执行机制.
- 检查软机器人系统中功率输送和压力弹性策略.
主要成果:
- 灵感来自深海生物的软机器人可以轻便紧,避免需要重压容器.
- 生物灵感设计为极端环境中的执行,传感和运动提供了新的解决方案.
- 这些软机器人展示了多功能能力的潜力,包括在恶劣条件下进行勘探和操作.
结论:
- 生物灵感软机器人为克服深海勘探挑战提供了一个有希望的途径.
- 深海生物的独特适应性为设计弹性和高效的水下机器人提供了蓝图.
- 这些进展为深度深海研究和运营的游戏变革解决方案铺平了道路.


相关概念视频
 01:11
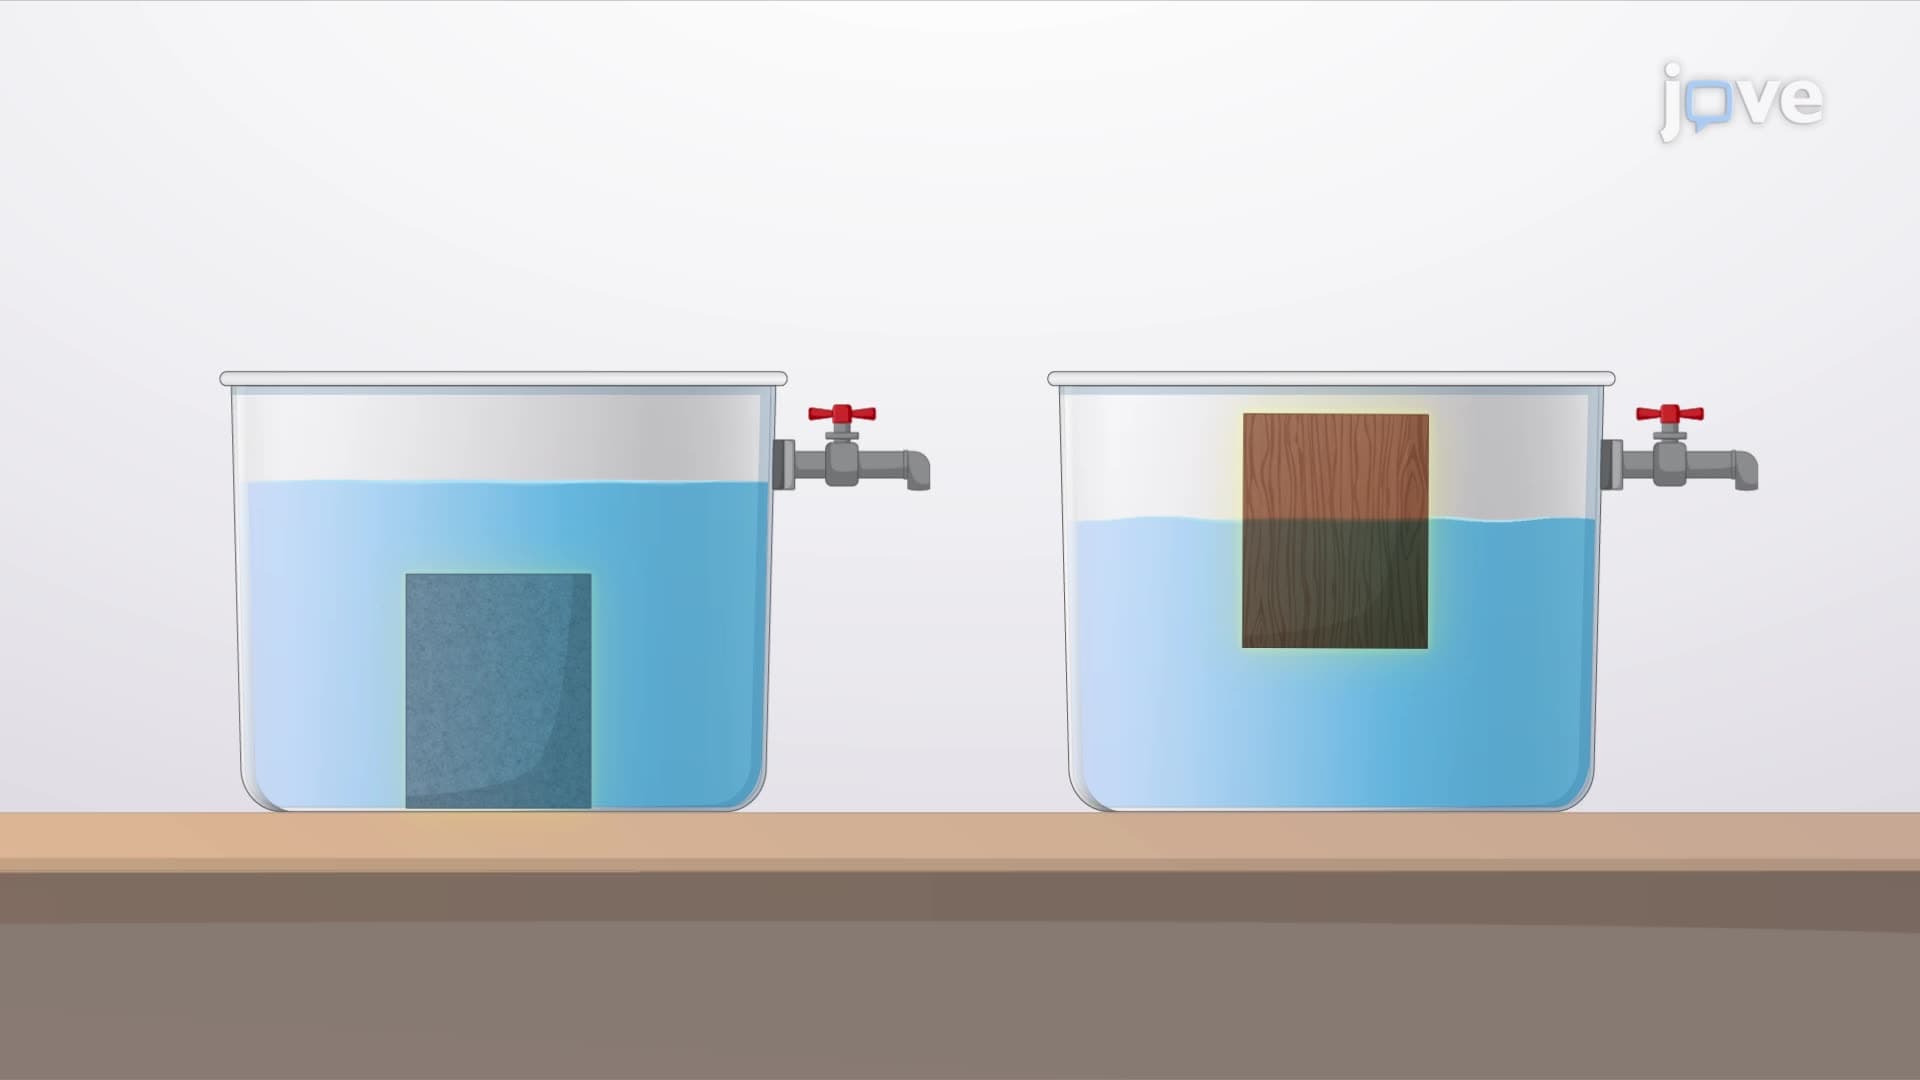
Buoyancy and Stability for Submerged and Floating Bodies
In fluid mechanics, buoyancy and stability are key concepts for understanding the behavior of submerged and floating bodies. When a stationary body is fully or partially submerged in a fluid, the fluid exerts a force on the body known as the buoyant force. This force acts vertically upward through a point called the center of buoyancy, which is the center of the displaced fluid volume. According to Archimedes' principle, the magnitude of the buoyant force is equal to the weight of the fluid...
 01:18
Deep Sea Microbial Ecology
The deep ocean and its underlying sediments represent vast, largely unexplored microbial habitats that extend far beyond the sunlit photic zone. The photic (euphotic) zone typically spans the upper ~100–200 meters of pelagic waters in the open ocean, but its depth varies geographically and seasonally, where sufficient light supports photosynthetic life. Below this lies the deep sea, spanning roughly 1000–6000 meters (bathypelagic to abyssal zones), with deeper hadal trenches extending beyond...