稳定的奥恩斯坦 - 乌伦贝克系统在瓦瑟斯坦距离中的厄尔戈迪性极限与切线稳定性的应用
Gerardo Barrera1, Michael A Högele2
1Department of Mathematics and Statistics, University of Helsinki, P.O. Box 68, Pietari Kalmin katu 5, FI-00014 Helsinki, Finland.
Chaos (Woodbury, N.Y.)
|November 17, 2023

概括
这项研究证明了切断稳定性,或突然的热化,多维的赫维茨稳定的奥恩斯坦-乌伦贝克系统与莱维噪声. 这些发现适用于像合振荡器和布朗旋转器这样的复杂系统.
科学领域:
- 随机过程 随机过程
- 数学物理 数学物理
- 埃尔戈迪克理论 埃尔戈迪克理论
背景情况:
- 奥恩斯坦-乌伦贝克系统是物理现象建模的基础.
- 莱维噪声引入了超越标准布朗运动的复杂动态.
- 了解系统稳定对于预测长期行为至关重要.
研究的目的:
- 为了建立一个广泛的类型的随机系统的切断稳定性 (突然热化).
- 为了分析由一般的多维Hurwitz稳定的Ornstein-Uhlenbeck过程驱动的系统,使用Lévy噪声.
- 将稳定性分析扩展到不规则的系统和网络.
主要方法:
- 使用定量的ergodicity极限 (下方和上方).
- 利用瓦瑟斯坦-坎托罗维奇-鲁宾斯坦距离的偏移线性属性.
- 将这些方法应用于各种系统,包括雅科比链和合振荡器.
主要成果:
- 对于具有Lévy噪声的通用多维Hurwitz稳定的Ornstein-Uhlenbeck系统,证明了切断稳定性.
- 提供了稳定性证明所必不可少的定量ergodicity极限.
- 将分析扩展到不规则系统,如雅科比链和合波器网络.
结论:
- 切线稳定性是这些复杂的随机系统的强大特征.
- 已建立的方法为分析类似系统提供了强大的框架.
- 这些发现对理解非高斯噪声的物理模型中的热化有意义.
相关概念视频
 01:24
BIBO stability of continuous and discrete -time systems
401
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
401
 01:04
Oscillations about an Equilibrium Position
5.4K
Stability is an important concept in oscillation. If an equilibrium point is stable, a slight disturbance of an object that is initially at the stable equilibrium point will cause the object to oscillate around that point. For an unstable equilibrium point, if the object is disturbed slightly, it will not return to the equilibrium point. There are three conditions for equilibrium points—stable, unstable, and half-stable. A half-stable equilibrium point is also unstable, but is named so...
5.4K
 01:28
Stability
129
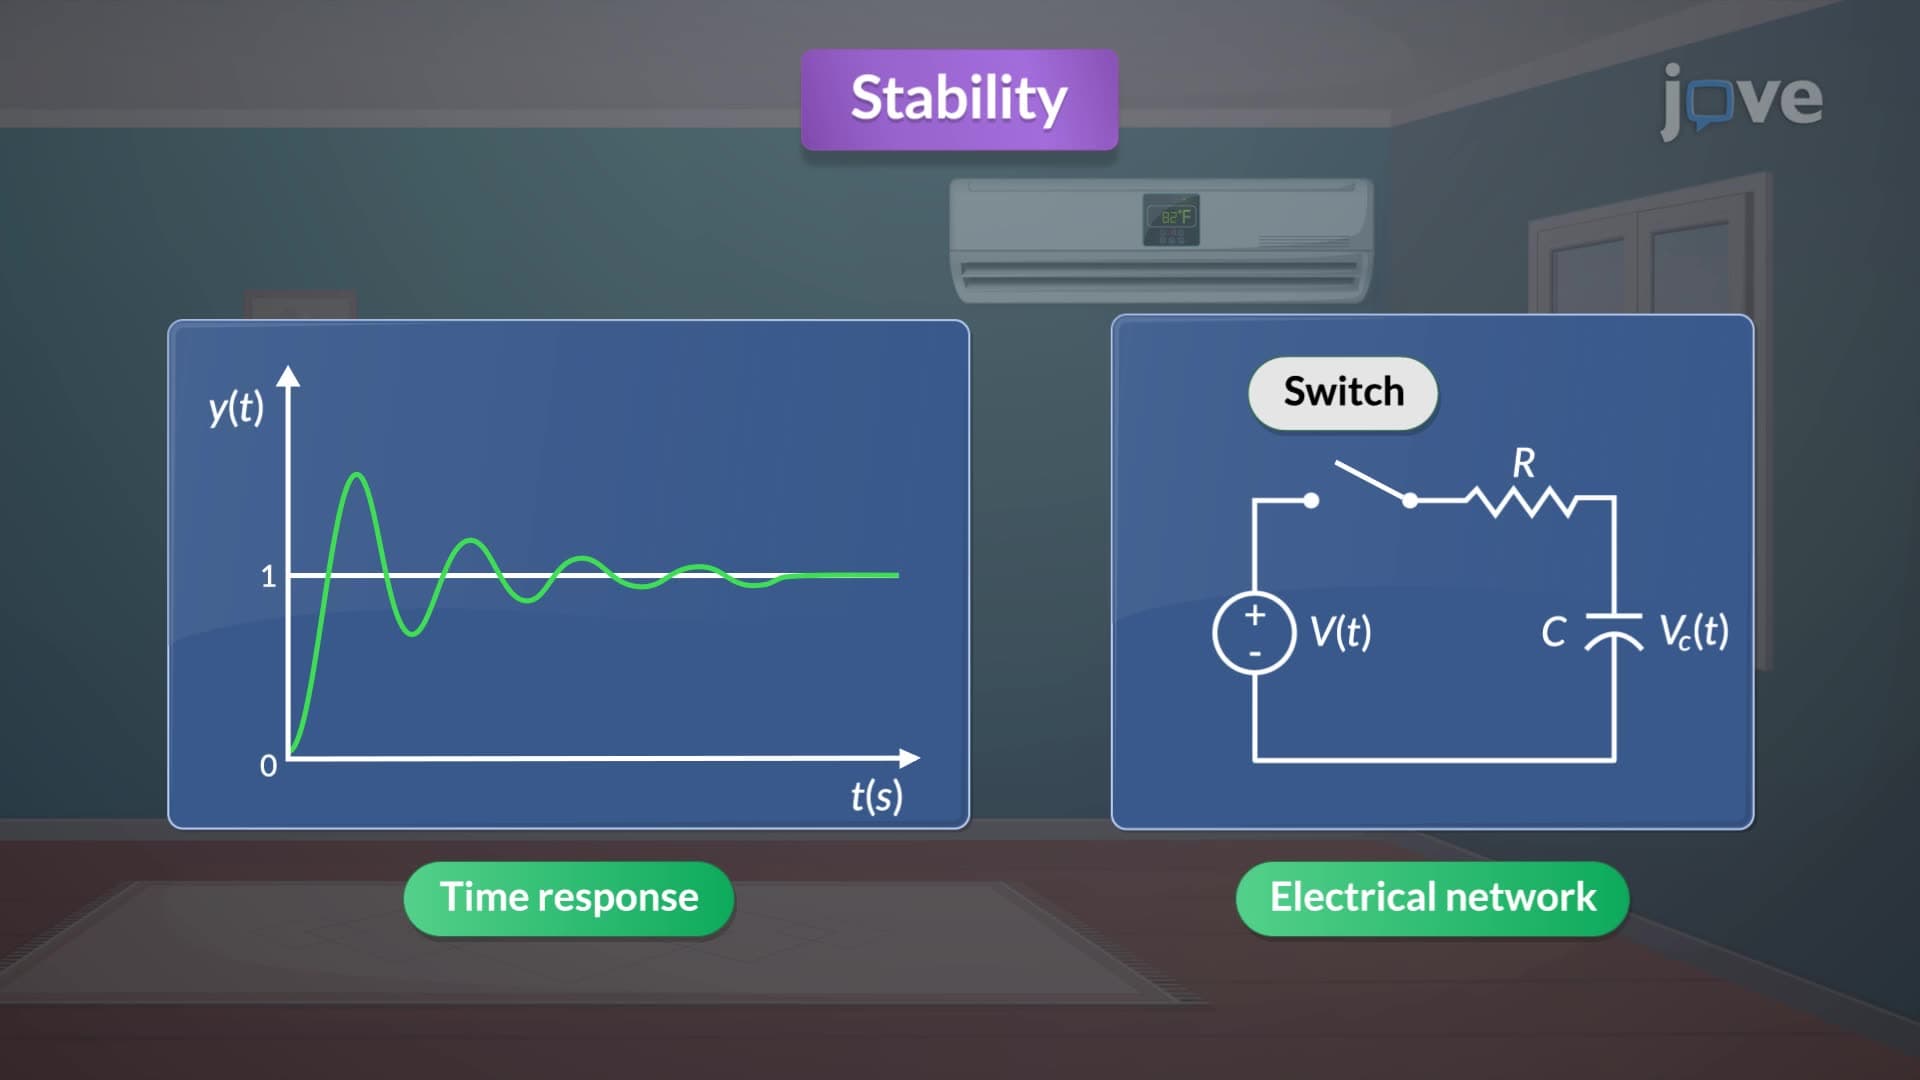
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
129
 01:24
Pole and System Stability
301
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
301
 01:23
Stability of Equilibrium Configuration
449
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
449
 01:18
Second Order systems II
114
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
114