
深入探讨鸟视觉的魔鬼:一个审查,评估和配方
IEEE transactions on pattern analysis and machine intelligence
|November 17, 2023

概括
这项调查探讨了自动驾驶的鸟类视图 (BEV) 感知,解决了3D重建和多传感器融合方面的挑战. 它为增强的BEV系统提供了实际指导和未来研究方向.
科学领域:
- 计算机视觉 计算机视觉
- 自主驾驶系统 自主驾驶系统
- 机器人技术 机器人技术 机器人技术
背景情况:
- 传统的自动驾驶感知依赖于前方/视角视图,限制了多传感器集成.
- 复杂的传感器配置需要统一的特征表示来实现强大的感知.
- 鸟视图 (BEV) 提供了一个直观的,融合友好的,并准备计划的场景表示.
研究的目的:
- 为自动驾驶汽车的 BEV 感知提供了最近的进展的全面审查.
- 分析BEV感知核心挑战的解决方案,包括3D重建和注释.
- 为改善BEV系统提供实用见解和未来研究方向.
主要方法:
- 审查关于BEV感知技术的最新文献.
- 对视图转换和3D信息重建方法的分析.
- 检查传感器融合策略和多源数据管道配方.
主要成果:
- 确定BEV感知中的关键挑战:3D重建,地面真相获取,管道设计和传感器适应性.
- 从学术界和工业界对这些挑战的各种解决方案进行深入分析.
- 呈现系统设计和实际指导方针,以提高BEV感知性能.
结论:
- BEV感知对于先进的自动驾驶至关重要,它能够直观地理解场景,并与规划模块无集成.
- 解决3D重建,数据融合和传感器通用化的挑战是释放BEV充分潜力的关键.
- 这项调查为研究人员和从业人员提供了宝贵的资源,指导未来在BEV感知发展方面的努力.
相关概念视频
 01:15
Depth Perception and Spatial Vision
677
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
677
 01:24
Vision
53.5K
Vision is the result of light being detected and transduced into neural signals by the retina of the eye. This information is then further analyzed and interpreted by the brain. First, light enters the front of the eye and is focused by the cornea and lens onto the retina—a thin sheet of neural tissue lining the back of the eye. Because of refraction through the convex lens of the eye, images are projected onto the retina upside-down and reversed.
53.5K
 01:28
Perception
470
Perception is a fundamental psychological process that enables individuals to organize, interpret, and consciously experience sensory information. This process is crucial for understanding and interacting with the world around us. It includes both bottom-up and top-down processing, each playing a distinct role in how we perceive our environment.
Bottom-up processing begins at the sensory level, where receptors detect external environmental stimuli. These could include the tactile sensation of...
Bottom-up processing begins at the sensory level, where receptors detect external environmental stimuli. These could include the tactile sensation of...
470
 01:20
Parallel Processing
156
The brain processes sensory information rapidly due to parallel processing, which involves sending data across multiple neural pathways at the same time. This method allows the brain to manage various sensory qualities, such as shapes, colors, movements, and locations, all concurrently. For instance, when observing a forest landscape, the brain simultaneously processes the movement of leaves, the shapes of trees, the depth between them, and the various shades of green. This enables a quick and...
156
 01:21
Gestalt Principles of Perception
315
Gestalt principles provide a framework for understanding how humans perceive objects as unified wholes within their context. These principles are essential in explaining the cognitive processes that make sense of complex visual stimuli by organizing them into coherent groups. One fundamental principle is proximity, which posits that objects located close to each other are perceived as a collective group. For instance, when dots are positioned near one another, the visual system interprets them...
315
 01:26
Visual System
589
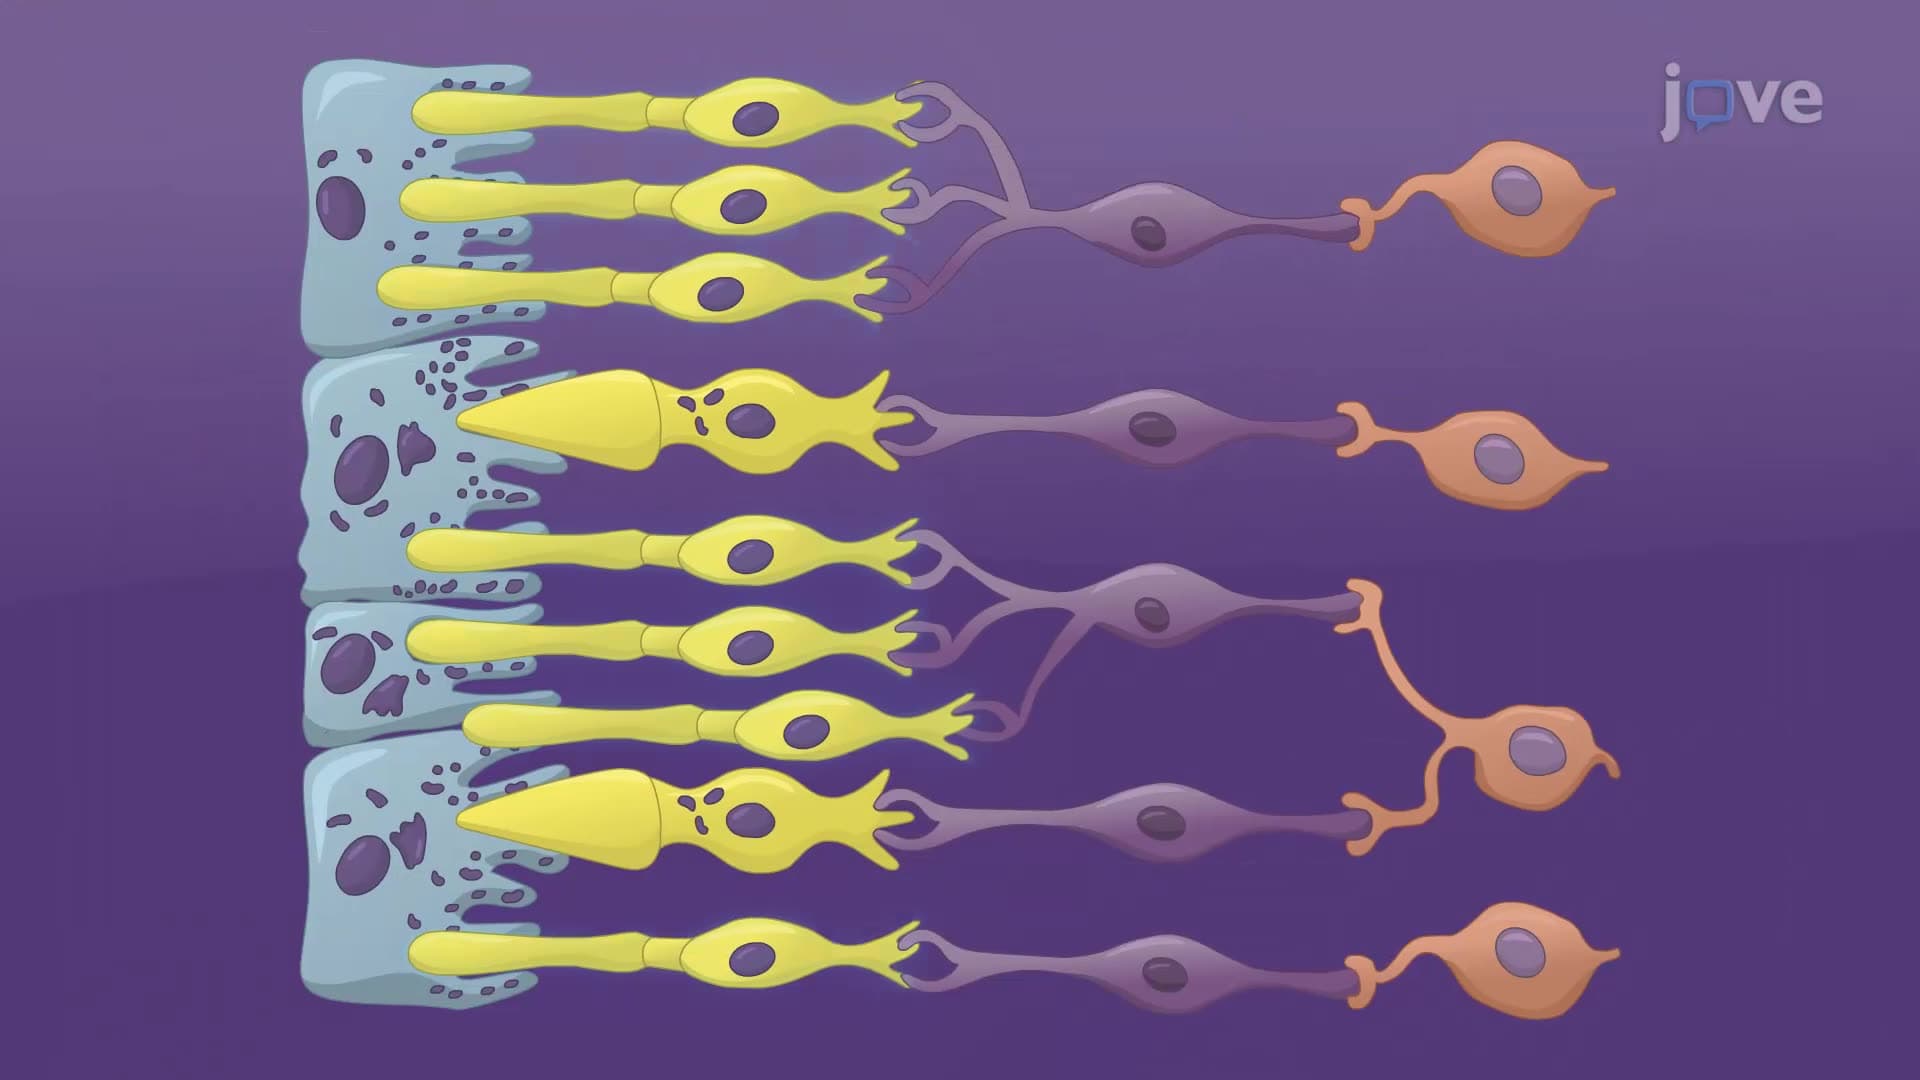
Light enters the eye through the cornea, a transparent, dome-shaped surface covering the surface of the eyeball that helps to direct and focus incoming light. This light is then channeled toward the pupil, an adjustable opening whose size is controlled by the iris. The iris, a pigmented muscle, regulates the amount of light entering the eye by contracting or dilating the pupil, thereby ensuring optimal light levels for clear vision.
Once through the pupil, the light passes through the lens, a...
Once through the pupil, the light passes through the lens, a...
589