相关实验视频
Updated: Jul 10, 2025
06:42
Generation and Coherent Control of Pulsed Quantum Frequency Combs
Published on: June 8, 2018
9.0K
控制量子混沌:依赖时间的转子了转子
Steven Tomsovic1,2, Juan Diego Urbina1, Klaus Richter1
1Institut für Theoretische Physik, Universität Regensburg, D-93040 Regensburg, Germany.
Physical review. E
|November 18, 2023

概括
研究人员为混乱系统开发了一种更简单的量子控制方法. 这种技术利用系统的灵敏度来达到目标状态,而不需要抵消量子状态扩散,使其在实验上更可行.
科学领域:
- 量子力学就是量子力学.
- 混沌理论是一个混乱理论.
- 动态系统是动态系统.
背景情况:
- 经典的混乱系统对初始条件表现出极度的敏感性.
- 控制这些系统包括引导它们到目标状态.
- 之前的工作是通过对抗状态扩散来概括量子控制.
研究的目的:
- 为了提供更多关于混沌系统量子控制的细节.
- 建立量子状态定位的一般扩展.
- 开发一种更简单,更实验可行的控制方法.
主要方法:
- 引入了用于连贯控制动态的替代方法.
- 利用一种依赖时间的,局部稳定的控制哈密尔顿式.
- 采用混乱的异临界轨道,而无需对抗量子状态的扩散.
主要成果:
- 为量子转子开发了一种明显简单的近似控制技术.
- 这种新方法在实验中比以前的方法更容易实现.
- 简单方法的误差在 ħ→0.0 的极限内消失.
结论:
- 扩展量子控制方法提供了一个更实用的方法来准量子状态.
- 这种技术简化了实验实施,同时保持了理论有效性.
- 这些发现为更容易访问的量子混乱系统的实验控制铺平了道路.

相关概念视频
 01:07
Time-Domain Interpretation of PD Control
119
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
119
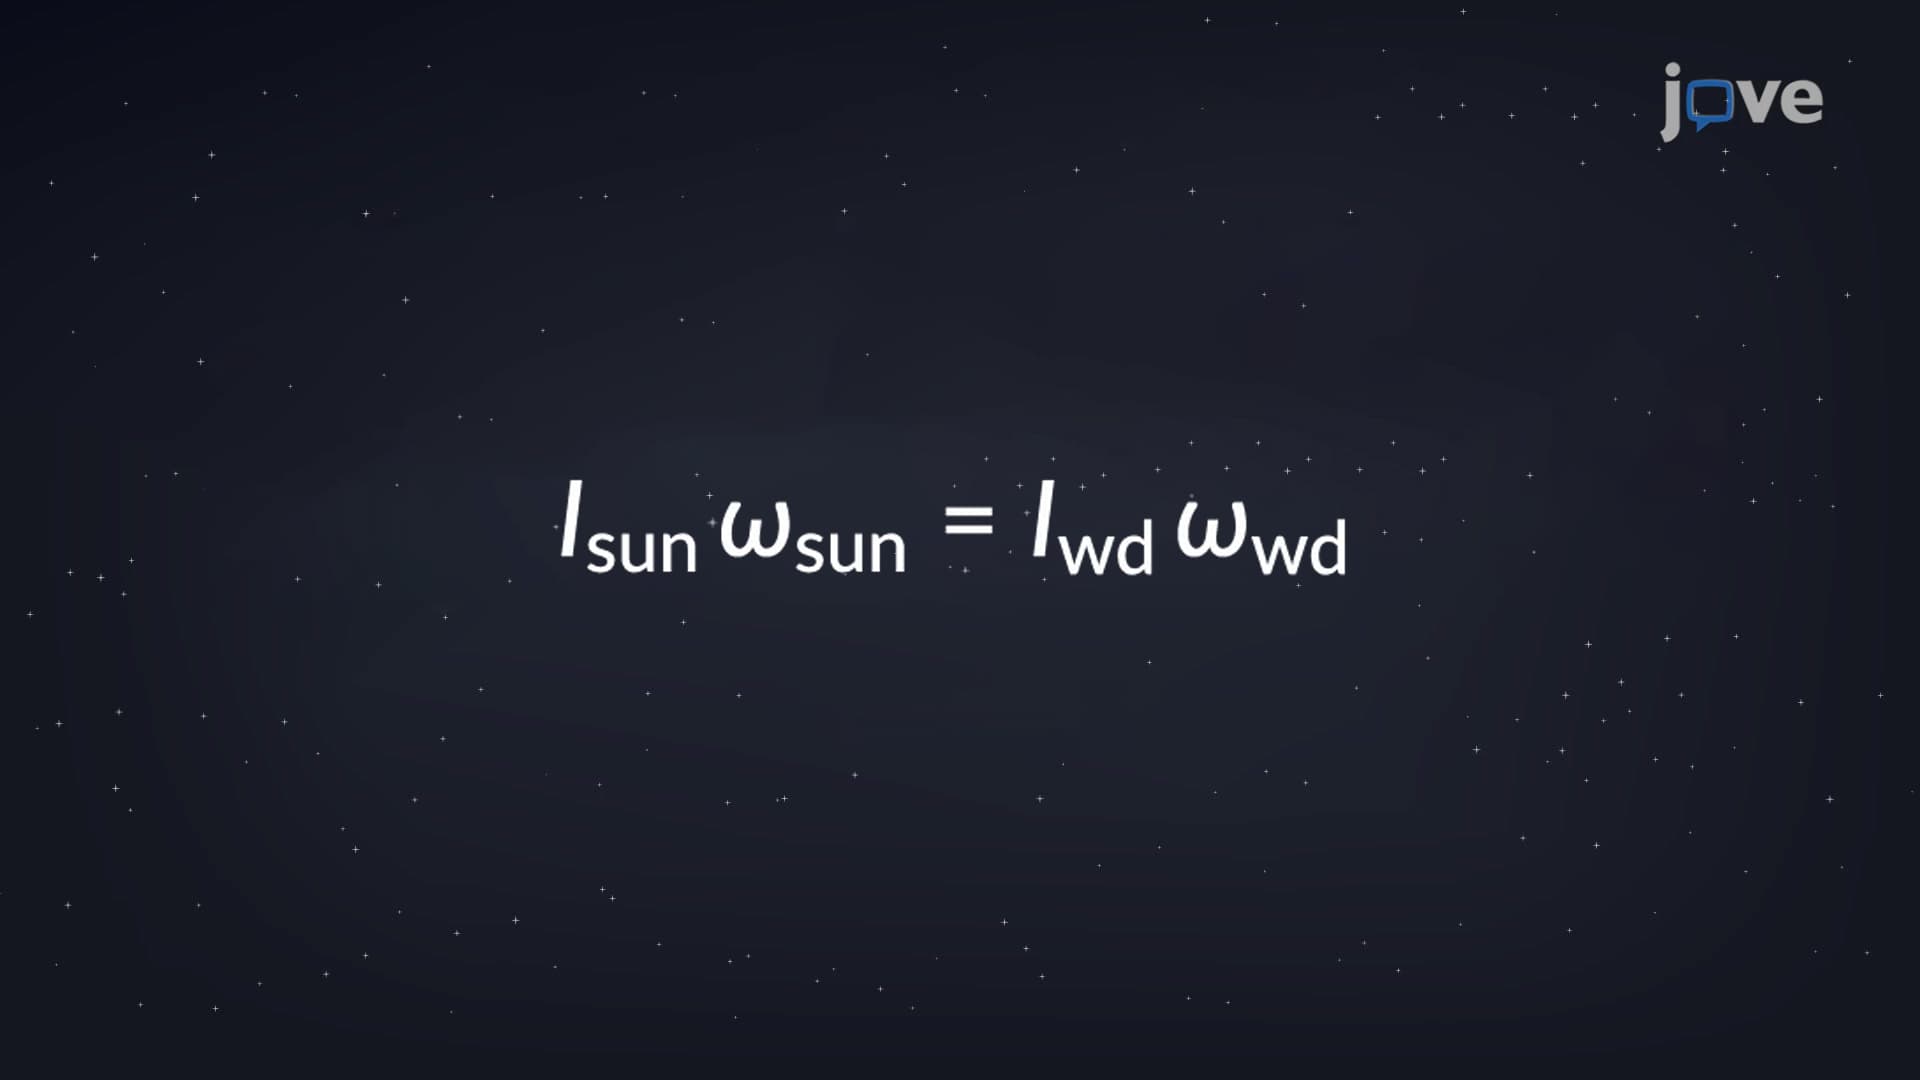 01:18
Conservation of Angular Momentum: Application
10.9K
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Examples of such systems include a freely spinning bicycle tire that slows over time due to torque arising from friction, or the slowing of Earth's rotation over millions of years due to frictional forces exerted on tidal deformations. However in the absence of a net external torque, the angular momentum remains conserved. The conservation of angular momentum principle requires a...
10.9K
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
99
Phase-lag controllers are widely used in control systems to improve stability and reduce steady-state errors. A dimmer switch controlling the brightness of a light bulb serves as a practical example of phase-lag control, gradually adjusting the bulb's brightness. Mathematically, phase-lag control or low-pass filtering is represented when the factor 'a' is less than 1.
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
99
 01:09
Conservation of Angular Momentum
10.3K
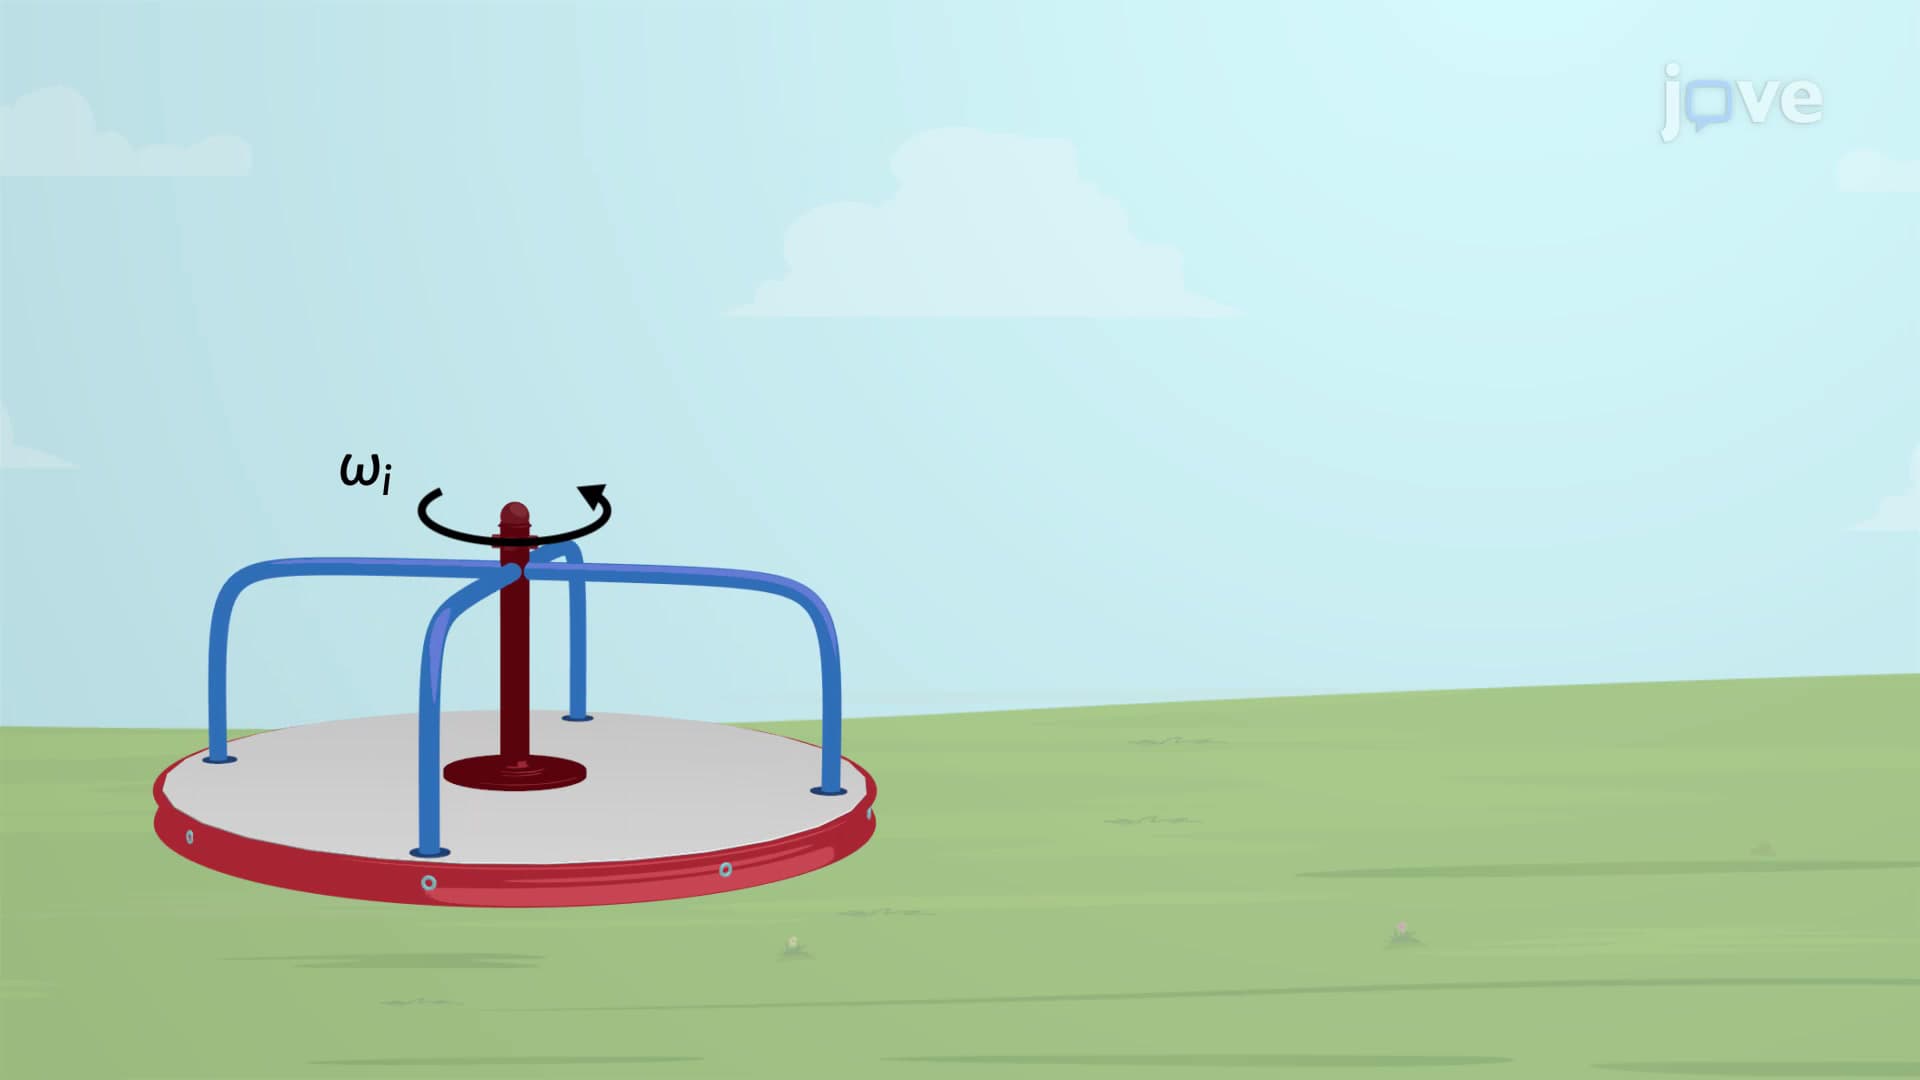
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Considering a system that consists of n tiny particles, the angular momentum of any tiny particle may change, but the system's total angular momentum would remain constant. The principle of conservation of angular momentum only considers the net external torque acting on the system. While there are internal forces exerted by different particles within the system that also produce...
10.3K
 01:06
Forced Oscillations
6.6K
When an oscillator is forced with a periodic driving force, the motion may seem chaotic. The motions of such oscillators are known as transients. After the transients die out, the oscillator reaches a steady state, where the motion is periodic, and the displacement is determined.
6.6K
 01:14
Conservation of Energy in Control Volume
842
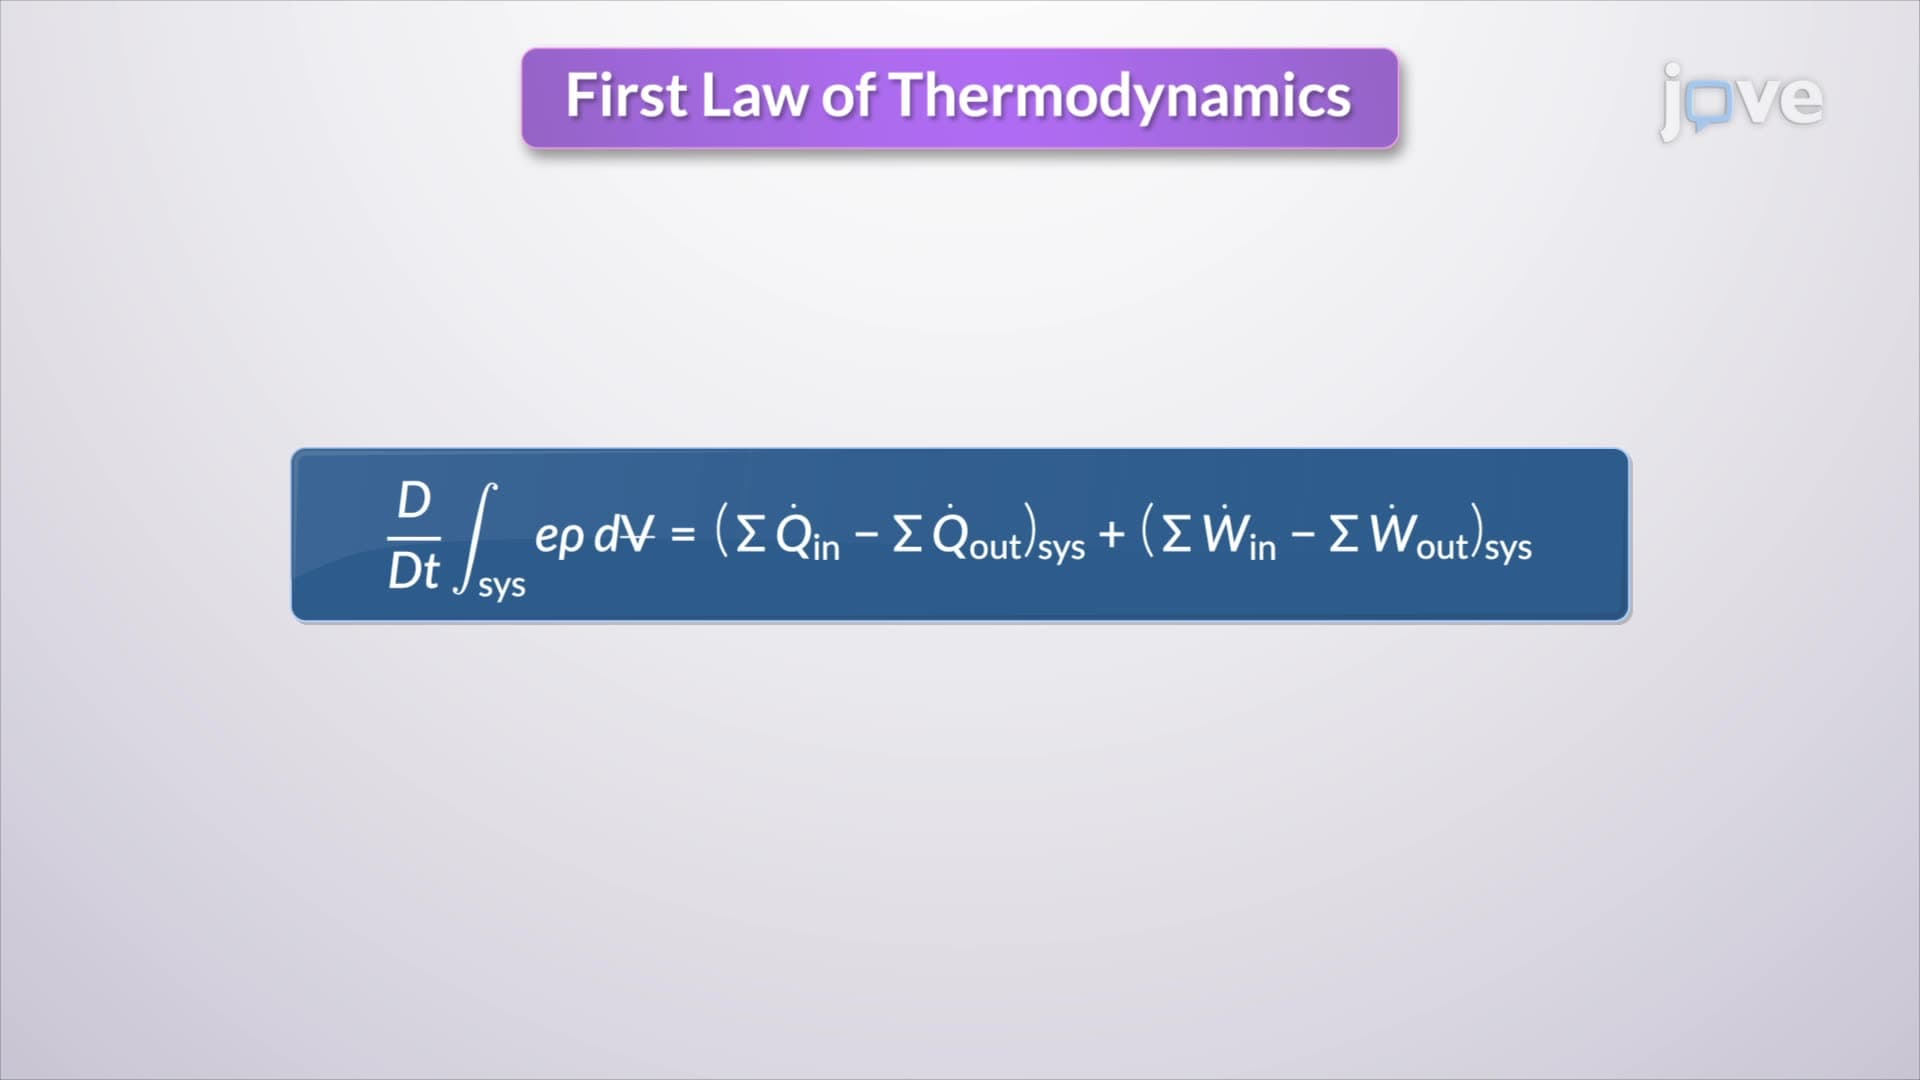
Consider a turbine operating under steady-flow conditions. The control volume is drawn around the turbine, with fluid entering at one point and exiting at another. The turbine extracts energy from the fluid, which performs mechanical work (shaft work).
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
842