

模糊的超扭曲模式控制的刚性-灵活的机器人手臂,基于近似的惯性多重体缩小维度的控制
Xiaoshan Qian1, Lisha Xu2, Xinmei Yuan1
1College of Physical Science and Engineering Technology, Yichun University, Yichun, China.
Frontiers in neurorobotics
|November 29, 2023

概括
这项研究引入了一种新的模糊控制方法,用于刚性-灵活的机器人手臂,提高控制质量和简化硬件. 这种方法确保稳定性和有效的性能,即使有干扰.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统工程 控制系统工程
- 应用数学 应用数学 应用数学
背景情况:
- 控制无限维度的刚性-柔性机器人手臂是一个挑战.
- 切断模式模型导致控制质量差或硬件复杂.
- 现有的方法在性能和实施复杂性方面扎.
研究的目的:
- 为刚性-灵活的机器人手臂提出一种新的模糊超扭转模式控制方法.
- 为了提高控制质量和简化硬件实现.
- 为了解决现有的模式模型截断技术的局限性.
主要方法:
- 开发了一个模糊的超级扭转模式控制策略.
- 使用了近似的惯性多元体维度缩小.
- 包含一个可调节的指数非单元滑动表面和一个稳定的连续超扭曲算法.
- 实施了一个模糊策略,用于实时优化滑动表面系数.
主要成果:
- 拟议的方法在模拟和实验中表现优于直接截断的第一阶段和第二阶段的模拟模型.
- 在有界的外部干扰下证明有效的跟踪性能.
- 展示了对系统变化的稳定性.
- 通过利亚普诺夫理论实现了有限时间的融合,并证实了系统的稳定性.
结论:
- 新的模糊控制方法显著提高了刚性-灵活机器人手臂的控制质量.
- 与二级模型相比,这种方法简化了硬件实现.
- 有限时间融合和经过验证的稳定性提供可靠的机器人手臂控制.


相关概念视频
 01:24
One-Degree-of-Freedom System
491
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
491
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
406
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
406
 01:30
Three-Dimensional Force System:Problem Solving
671
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
671
 01:25
Relative Motion Analysis using Rotating Axes
469
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
469
 01:21
Linear Approximation in Time Domain
83
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
83
 01:30
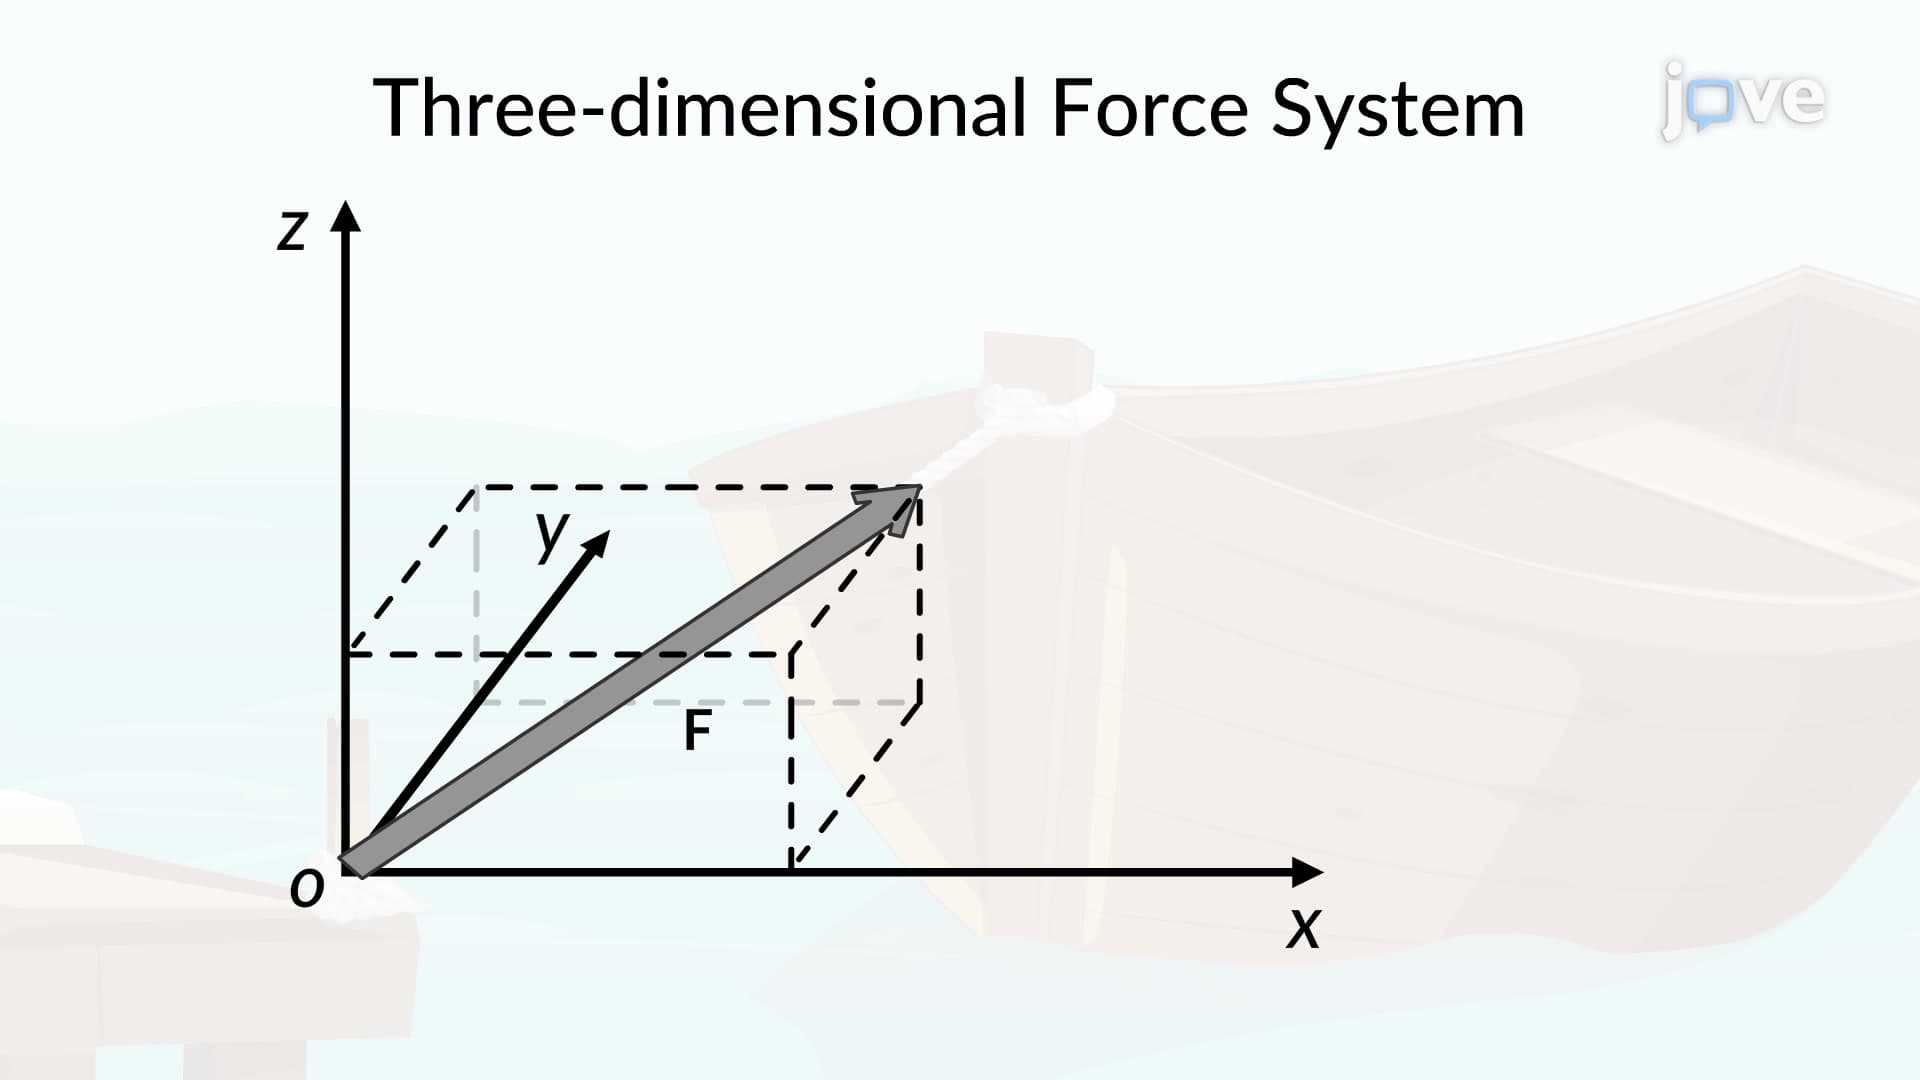
Three-Dimensional Force System
2.0K
In mechanical engineering, a three-dimensional force system is a system of forces acting in three dimensions, with forces applied along the x, y, and z coordinate axes. The three-dimensional force system is an important concept in mechanical engineering, as it allows engineers to understand and analyze the behavior of objects and structures in three dimensions. By understanding the forces acting on a system, engineers can design more efficient and effective mechanical systems that can withstand...
2.0K