洛克网 (LocNet):基于深度学习的本地化在一个旋转点扩展函数上,有望远镜成像应用
相关实验视频
Updated: Aug 14, 2026
10:04
Sample Drift Correction Following 4D Confocal Time-lapse Imaging
Published on: April 12, 2014
16.5K
Optics express
|December 2, 2023

概括
这项研究引入了一种新的卷积神经网络 (CNN) 方法,用于从二维图像中定位3D空间碎片. 该方法使用旋转点扩散函数 (PSF),在精度上优于现有技术.
科学领域:
- 天体物理学和太空科学 天体物理学和太空科学
- 计算机视觉和机器学习
背景情况:
- 从二维 (2D) 数据中准确地定位三维 (3D) 点源对于单分子显微镜和空间碎片跟踪等应用至关重要.
- 点差函数 (PSF) 工程为解决3D本地化挑战提供了一个有希望的途径.
- 传统的基于模型的优化方法可能是计算密集的,并且可能无法有效地扩展实时应用程序.
研究的目的:
- 开发一种使用二维成像进行空间碎片3D定位的自动化和高效方法.
- 利用卷积神经网络 (CNN) 进行增强的点源恢复,克服基于模型的方法的局限性.
- 为了提高3D空间碎片定位的精度和回忆率.
主要方法:
- 实现一个卷积神经网络 (CNN) 从2D图像数据直接3D定位点源.
- 使用旋转点扩散函数 (PSF),其中深度信息被编码为单叶PSF的旋转角度.
- 引入一个硬样本训练策略,以提高CNN的性能和稳定性.
主要成果:
- 提出的基于CNN的方法实现了空间碎片的自动3D定位.
- 与当前最先进的技术相比,该方法表现出卓越的性能,精度提高了11%以上.
- 在召回率上观察到相似的改善,这表明了强大的本地化能力.
结论:
- 开发的基于CNN的技术为2D图像的3D空间碎片定位提供了高效和准确的解决方案.
- 硬样本训练策略显著提高了CNN的性能,使其适合复杂的场景.
- 这种方法为传统的基于模型的方法提供了可行的替代方案,推进了空间局势意识领域.
更多相关视频
 11:57
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016
10.8K
 11:06
Multi-color Localization Microscopy of Single Membrane Proteins in Organelles of Live Mammalian Cells
Published on: June 30, 2018
8.5K
相关概念视频
 01:23
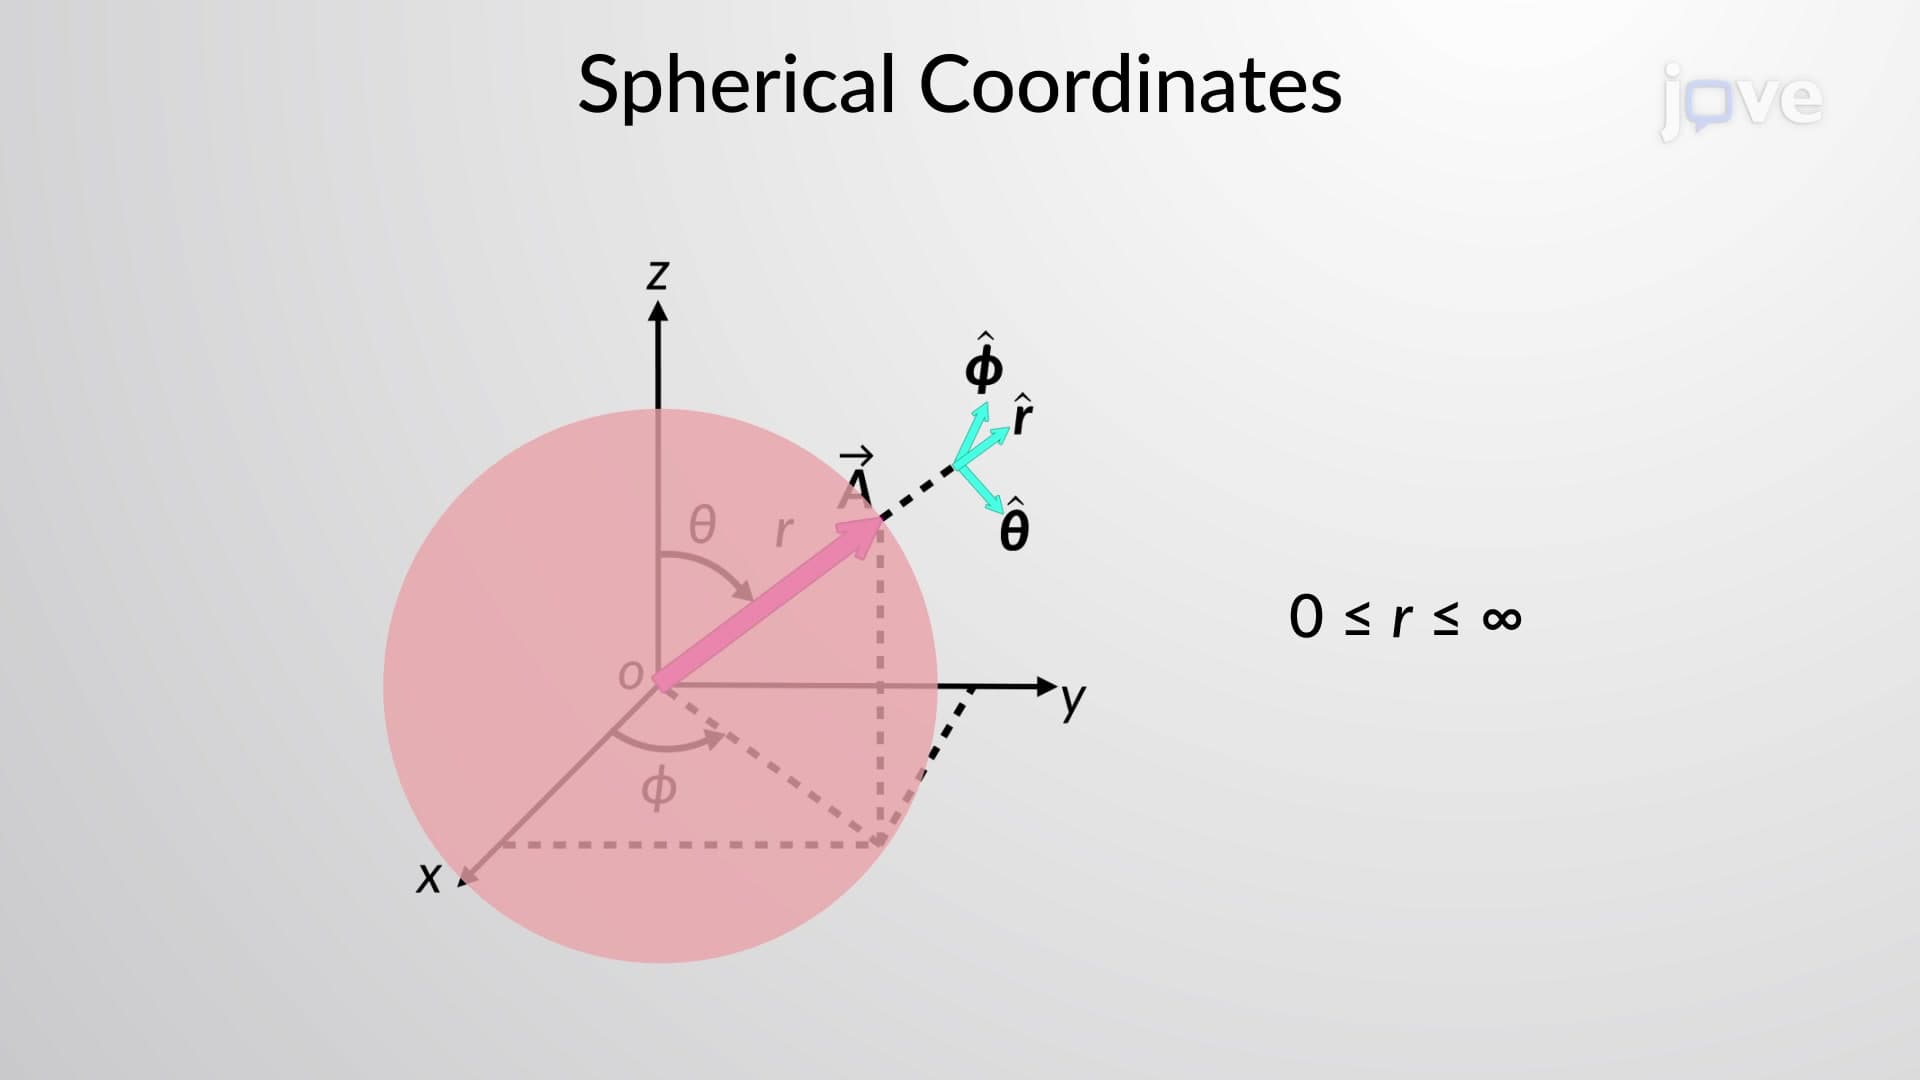
Spherical Coordinates
Spherical coordinate systems are preferred over Cartesian, polar, or cylindrical coordinates for systems with spherical symmetry. For example, to describe the surface of a sphere, Cartesian coordinates require all three coordinates. On the other hand, the spherical coordinate system requires only one parameter: the sphere's radius. As a result, the complicated mathematical calculations become simple. Spherical coordinates are used in science and engineering applications like electric and...
 01:25
Relative Motion Analysis using Rotating Axes
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...