
放松振荡的零碎-平滑-缓慢-快速巴齐金模型与霍林格类型I功能响应
Xiao Wu1, Shuying Lu1, Feng Xie1
1College of Science, Donghua University, Shanghai 201620, China.
Mathematical biosciences and engineering : MBE
|December 5, 2023

概括
这项研究分析了一个缓慢快速的Bazykinkin.
科学领域:
- 数学生物学 数学生物学
- 动态系统 动态系统
- 生态建模 生态建模
背景情况:
- 巴齐金模型是一个基本的生态模型,描述了捕食者-猎物动态.
- 研究不同时间尺度和功能反应的模型对于理解复杂的生态相互作用至关重要.
- 零碎平滑的功能反应引入了非线性,这可能导致复杂的行为.
研究的目的:
- 分析一个缓慢-快速的巴齐金模型的动态行为,结合一块-平滑的霍林格I型功能响应.
- 为了在这个特定的模型配置中识别分叉和限制周期.
- 探索诸如捕食者竞争率和初始密度等参数对模型动态的影响.
主要方法:
- 对分叉的理论分析,包括结和边界平衡分叉.
- 调查同临床和异临床循环的存在.
- 数字模拟生成相位肖像,说明不同的动态行为.
主要成果:
- 该模型显示了 Saddle-node 和 Boundary 的平衡分叉.
- 根据参数值,模型可以显示同临床周期,异临床周期或两个放松振荡周期.
- 数字模拟证实了复杂的动态,包括不同周期类型和放松振荡的共存.
结论:
- 缓慢-快速的巴齐金模型具有零碎-平滑的霍林格I型响应,比其平滑或非缓慢-快速对应物显示出明显更丰富和更复杂的动态.
- 动态行为对捕食者竞争和最初的人口密度非常敏感.
- 这些发现强调了在生态建模中考虑非光滑性和时间尺度分离的重要性.
相关概念视频
 01:20
Types of Damping
6.5K
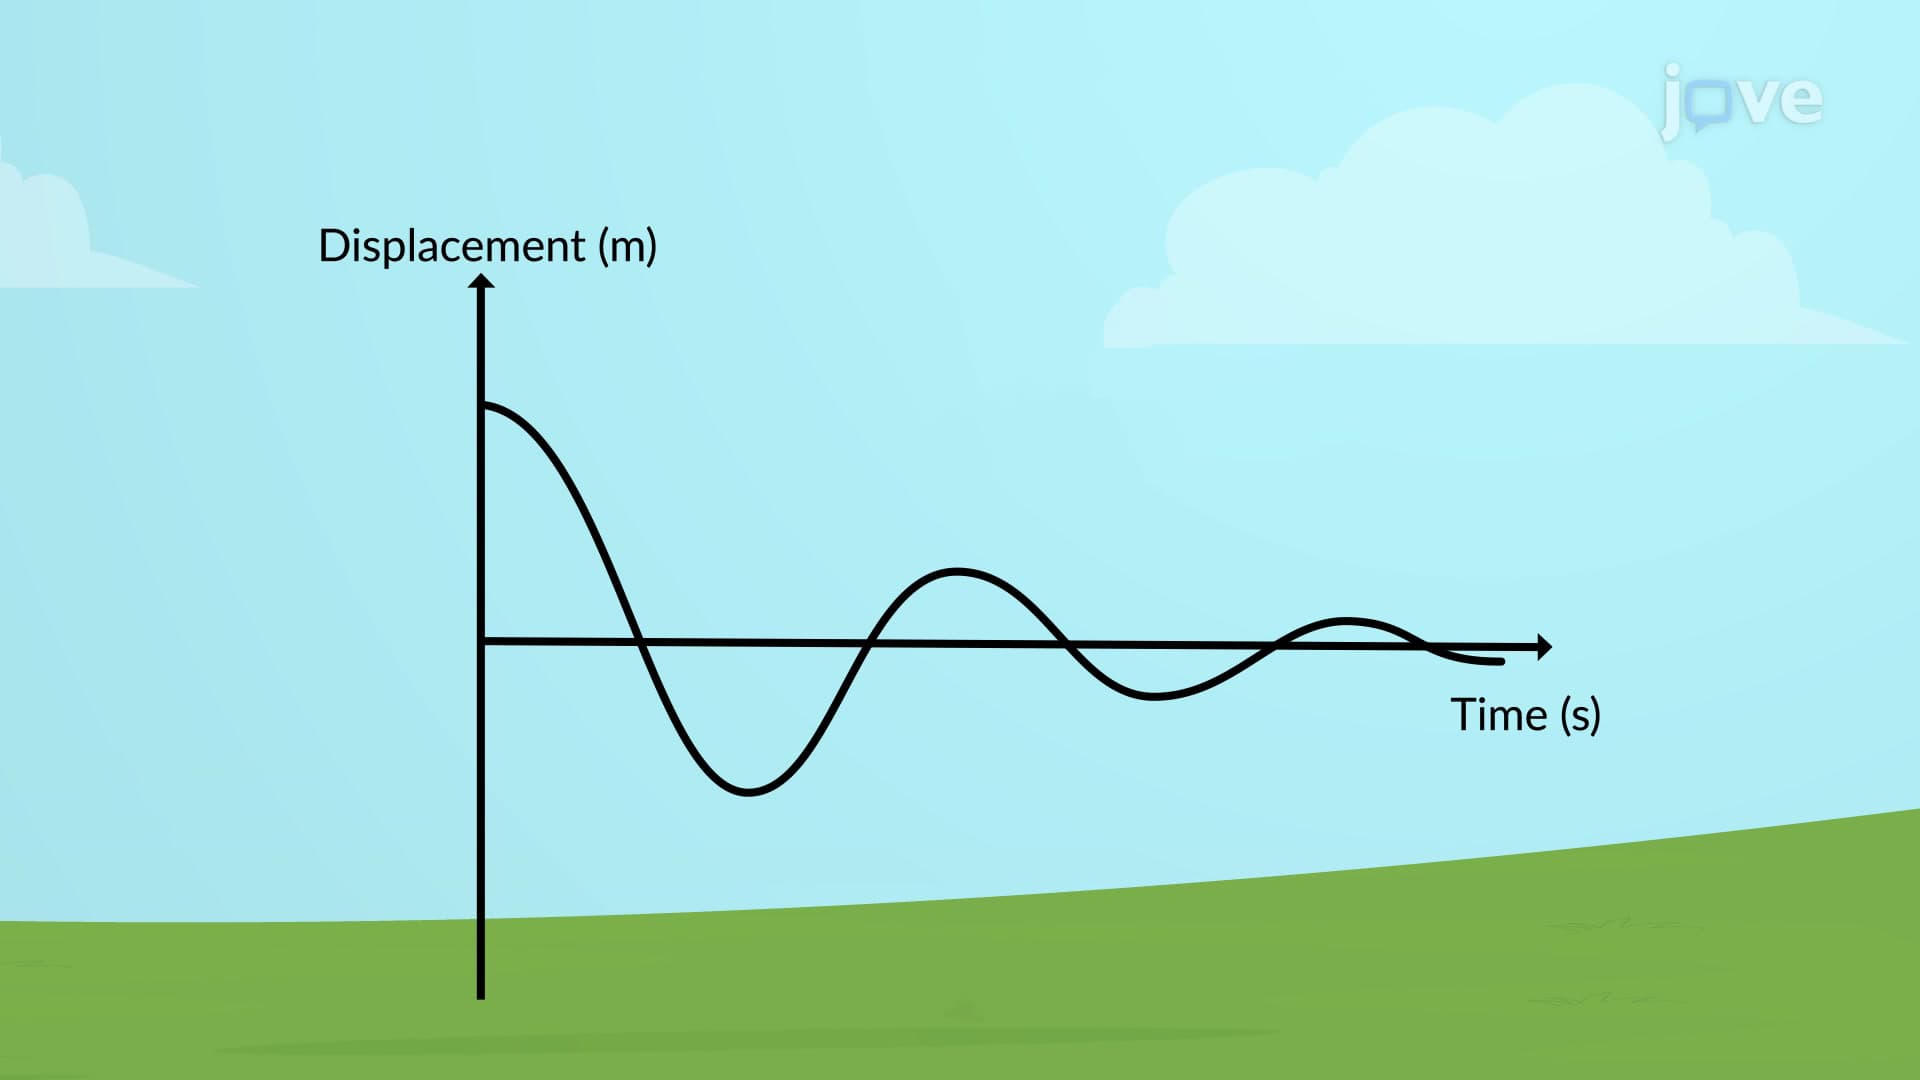
If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
6.5K
 01:07
Damped Oscillations
5.7K
In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Although friction and other non-conservative...
5.7K
 01:04
Oscillations about an Equilibrium Position
5.4K
Stability is an important concept in oscillation. If an equilibrium point is stable, a slight disturbance of an object that is initially at the stable equilibrium point will cause the object to oscillate around that point. For an unstable equilibrium point, if the object is disturbed slightly, it will not return to the equilibrium point. There are three conditions for equilibrium points—stable, unstable, and half-stable. A half-stable equilibrium point is also unstable, but is named so...
5.4K
 01:18
Second Order systems II
113
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
113
 01:11
Types of Responses of Series RLC Circuits
894
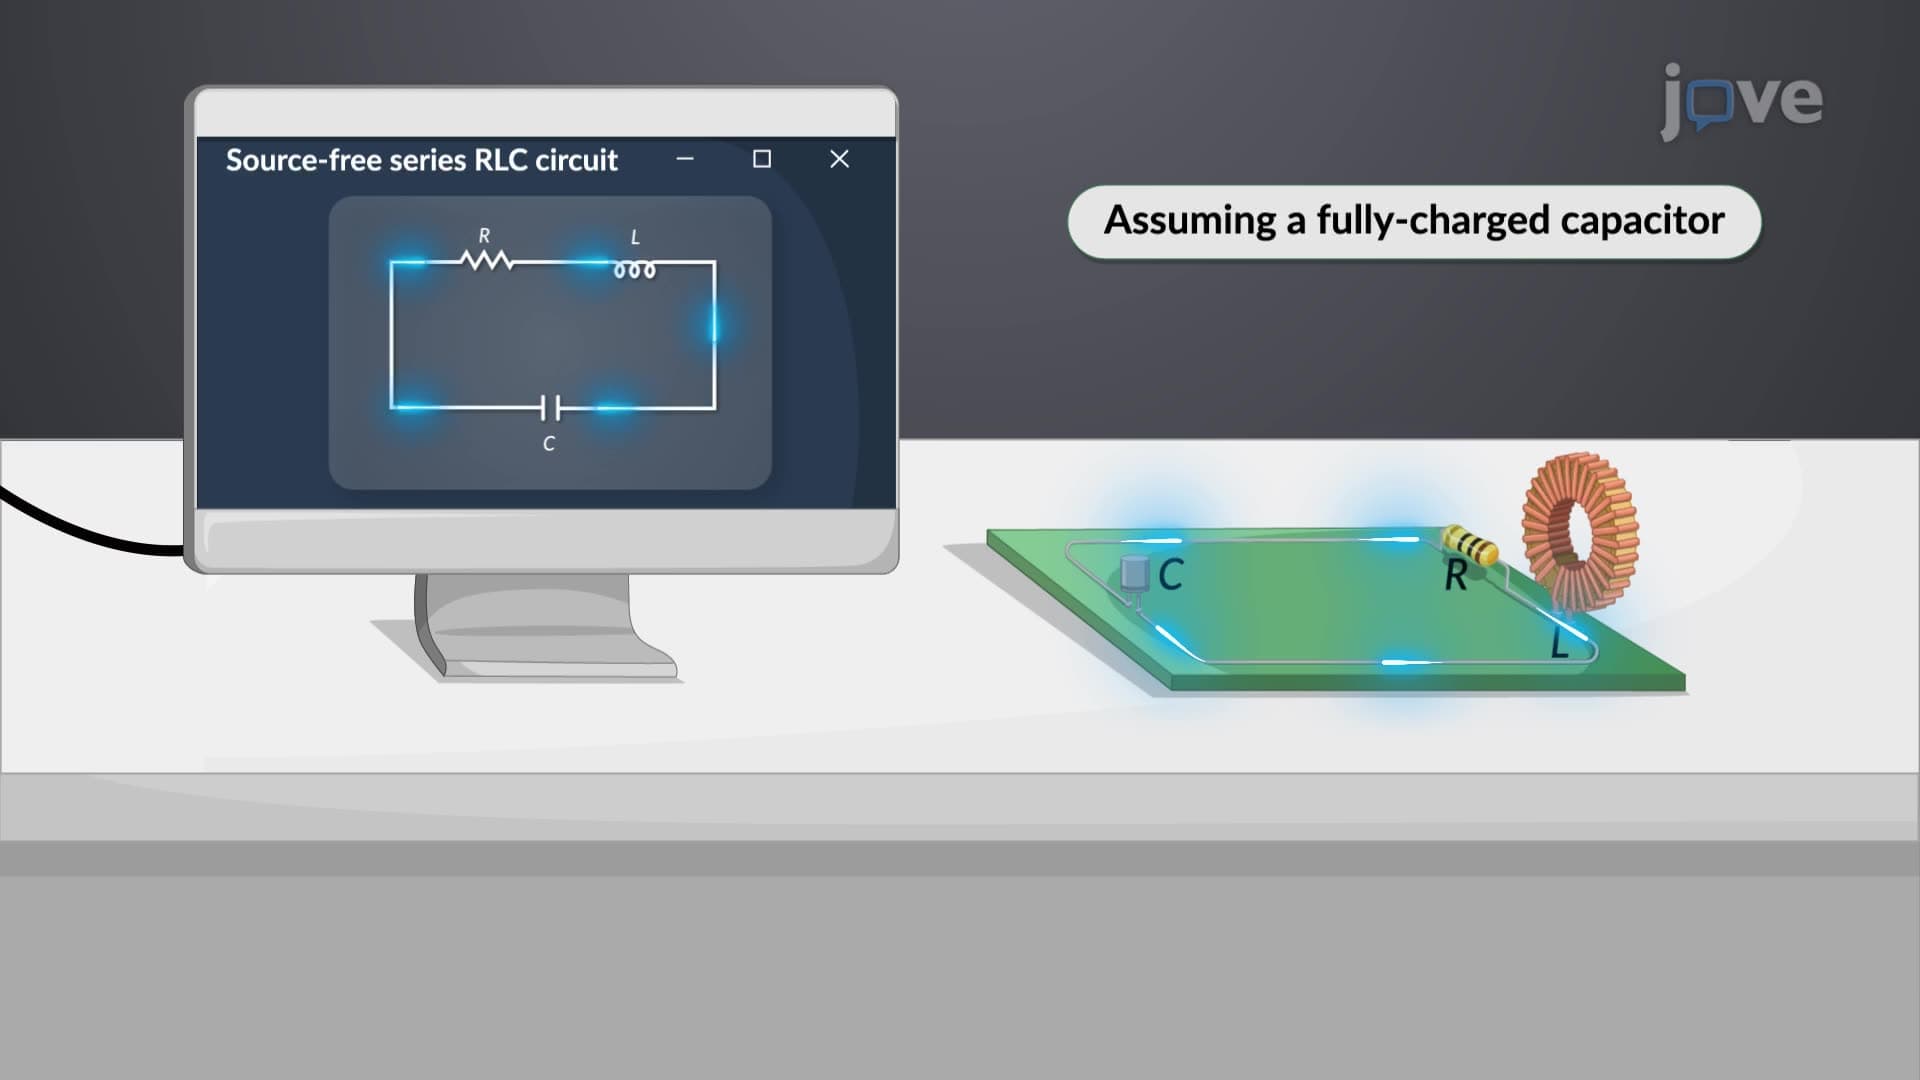
A second-order differential equation characterizes a source-free series RLC circuit, marking its distinct mathematical representation. The complete solution of this equation is a blend of two unique solutions, each linked to the circuit's roots expressed in terms of the damping factor and resonant frequency.
894
 01:24
BIBO stability of continuous and discrete -time systems
401
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
401