
利亚普诺夫指数是检测帕金森病的动态稳定性的可靠指标吗?

概括
研究人员使用最大利亚普诺夫指数 (LLE) 探索了帕金森病 (PD) 的步态稳定性. 来自传感器的长期LLE表明,健康的个体表现出比PD患者更大的稳定性.
科学领域:
- 神经退行性疾病 神经退行性疾病
- 生物医学工程 生物医学工程
- 步态分析 步态分析
背景情况:
- 帕金森病 (PD) 是一种流行的神经退行性疾病,影响运动功能.
- 患PD的临床诊断通常依赖于主观评估和感知尺度.
- 步行稳定性是PD的关键运动标志,但由于不清楚的指标和高可变性,无法量化.
研究的目的:
- 在临床环境中确定可靠和客观的指标,用于评估帕金森病患者的步行稳定性.
- 评估最大莱普诺夫指数 (LLE) 作为步态稳定的潜在客观测量.
主要方法:
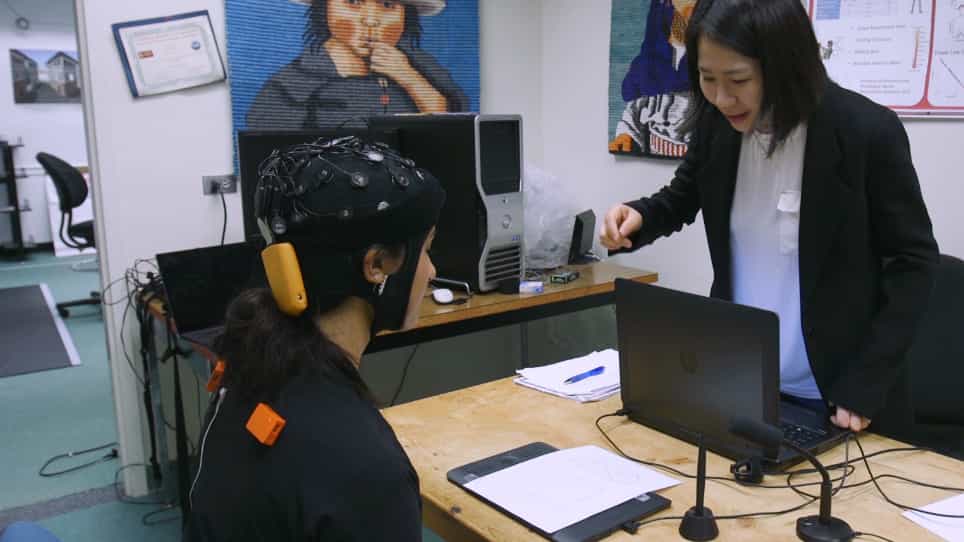
- 在42名患有PD的参与者和34名健康对照者 (HC) 中计算了短期和长期最大的Lyapunov指标 (LLE).
- 利用来自胸部,右臂和右脚的传感器数据来计算LLE.
- 进行统计分析,以比较PD患者和HC患者之间的LLE值.
主要成果:
- 来自胸部,右臂和右脚传感器的长期LLE显示了PD患者和HC患者之间的显著差异.
- 与PD患者相比,健康对照组显示出更大的步行稳定性 (较低的长期LLE).
- 短期LLE产生了相反的结果,表明PD患者的短期不稳定性增加.
结论:
- 长期的LLE显示出作为评估帕金森病中步态稳定的客观指标的潜力.
- 需要进一步的研究来确认LLE的可靠性,以检测和分类PD的步行稳定性问题.
- 这项研究是向开发客观的方法来评估临床实践中行走障碍的基本步骤.

相关概念视频
 01:07
Time-Domain Interpretation of PD Control
118
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
118
 01:37
Neural Regulation
39.5K
Digestion begins with a cephalic phase that prepares the digestive system to receive food. When our brain processes visual or olfactory information about food, it triggers impulses in the cranial nerves innervating the salivary glands and stomach to prepare for food.
39.5K
 01:24
Pole and System Stability
300
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
300
 01:19
Plotting and Calibrating the Root Locus
118
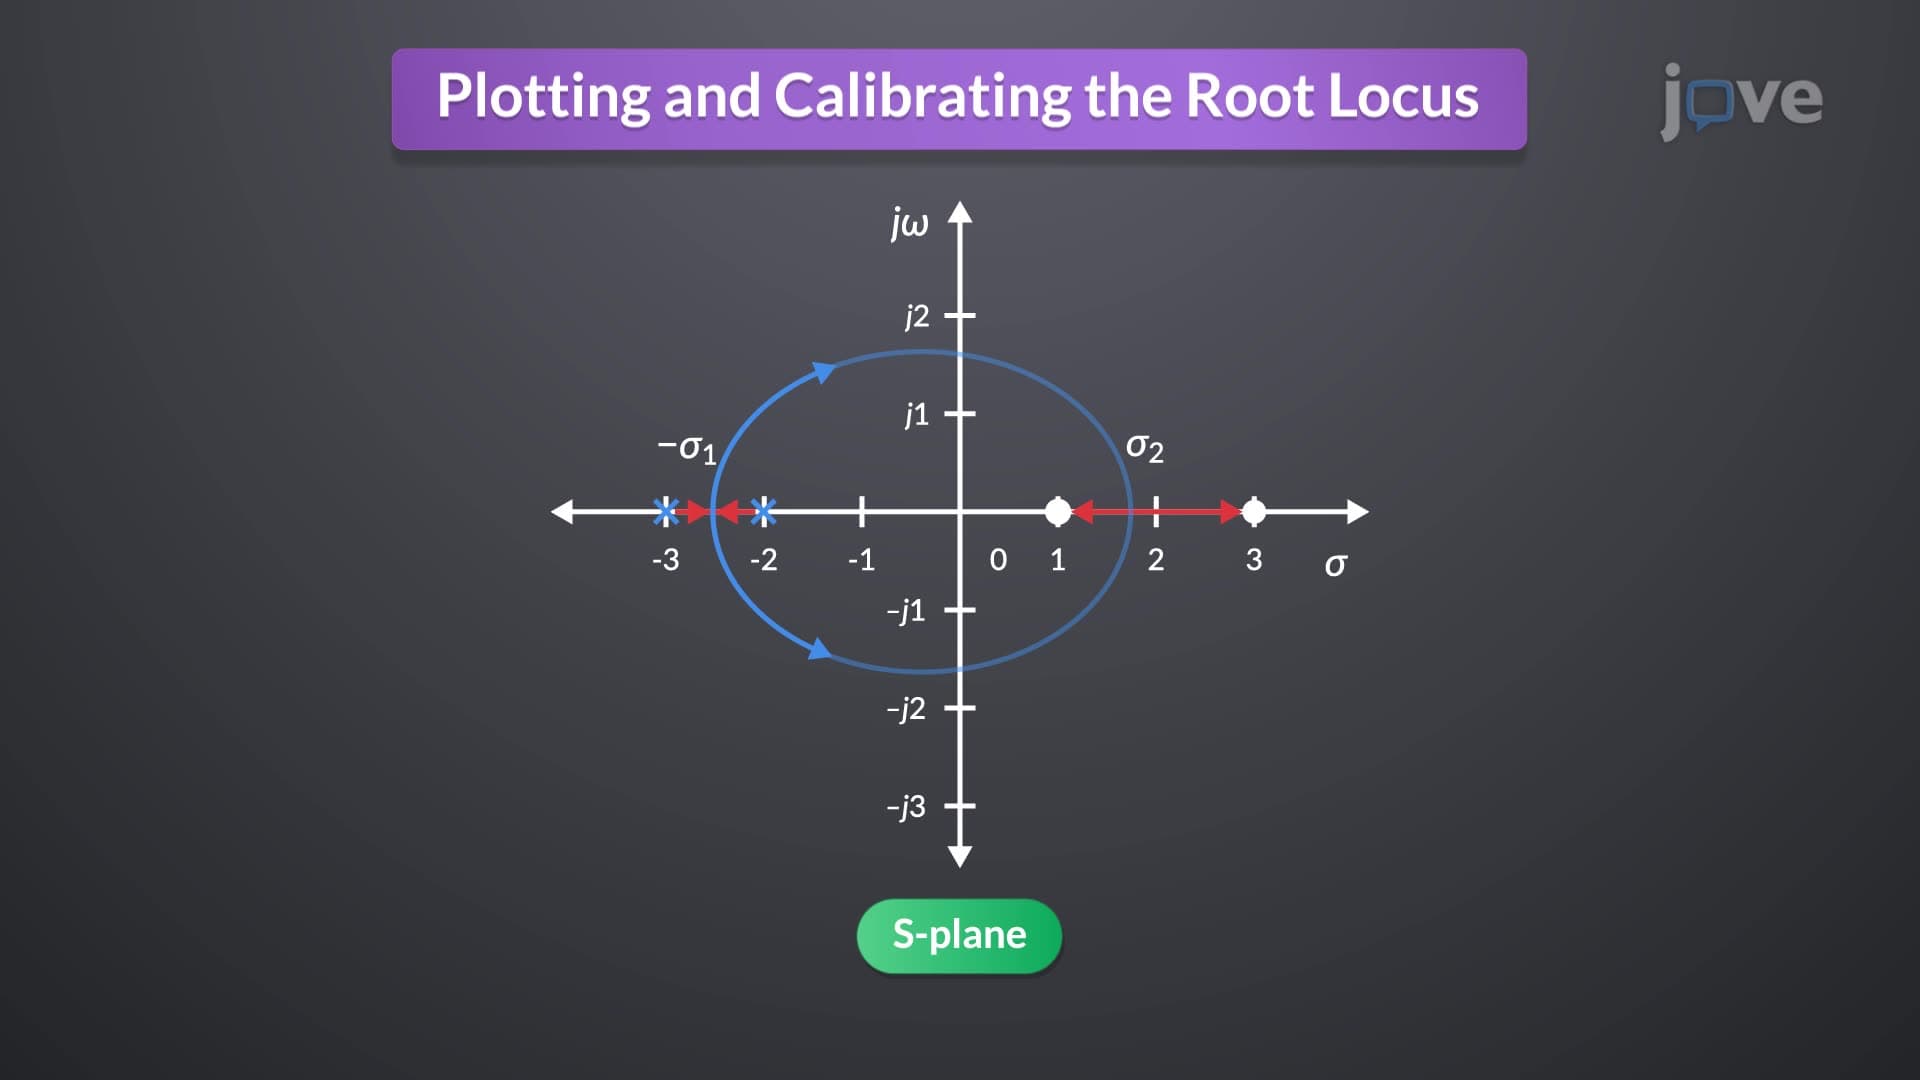
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
118
 01:24
Parkinson's Disease: Treatment
274
Neurodegenerative disorders, such as Parkinson's Disease (PD), involve the gradual and irreversible destruction of neurons in particular brain areas. These disorders exhibit standard features like proteinopathies, selective vulnerability of some neurons, and an interaction of intrinsic properties, genetics, and environmental influences in neural injury.
Parkinson's Disease is primarily a result of the loss of dopaminergic neurons in the substantia nigra pars compacta. The cornerstone of...
Parkinson's Disease is primarily a result of the loss of dopaminergic neurons in the substantia nigra pars compacta. The cornerstone of...
274
 01:28
Stability
129
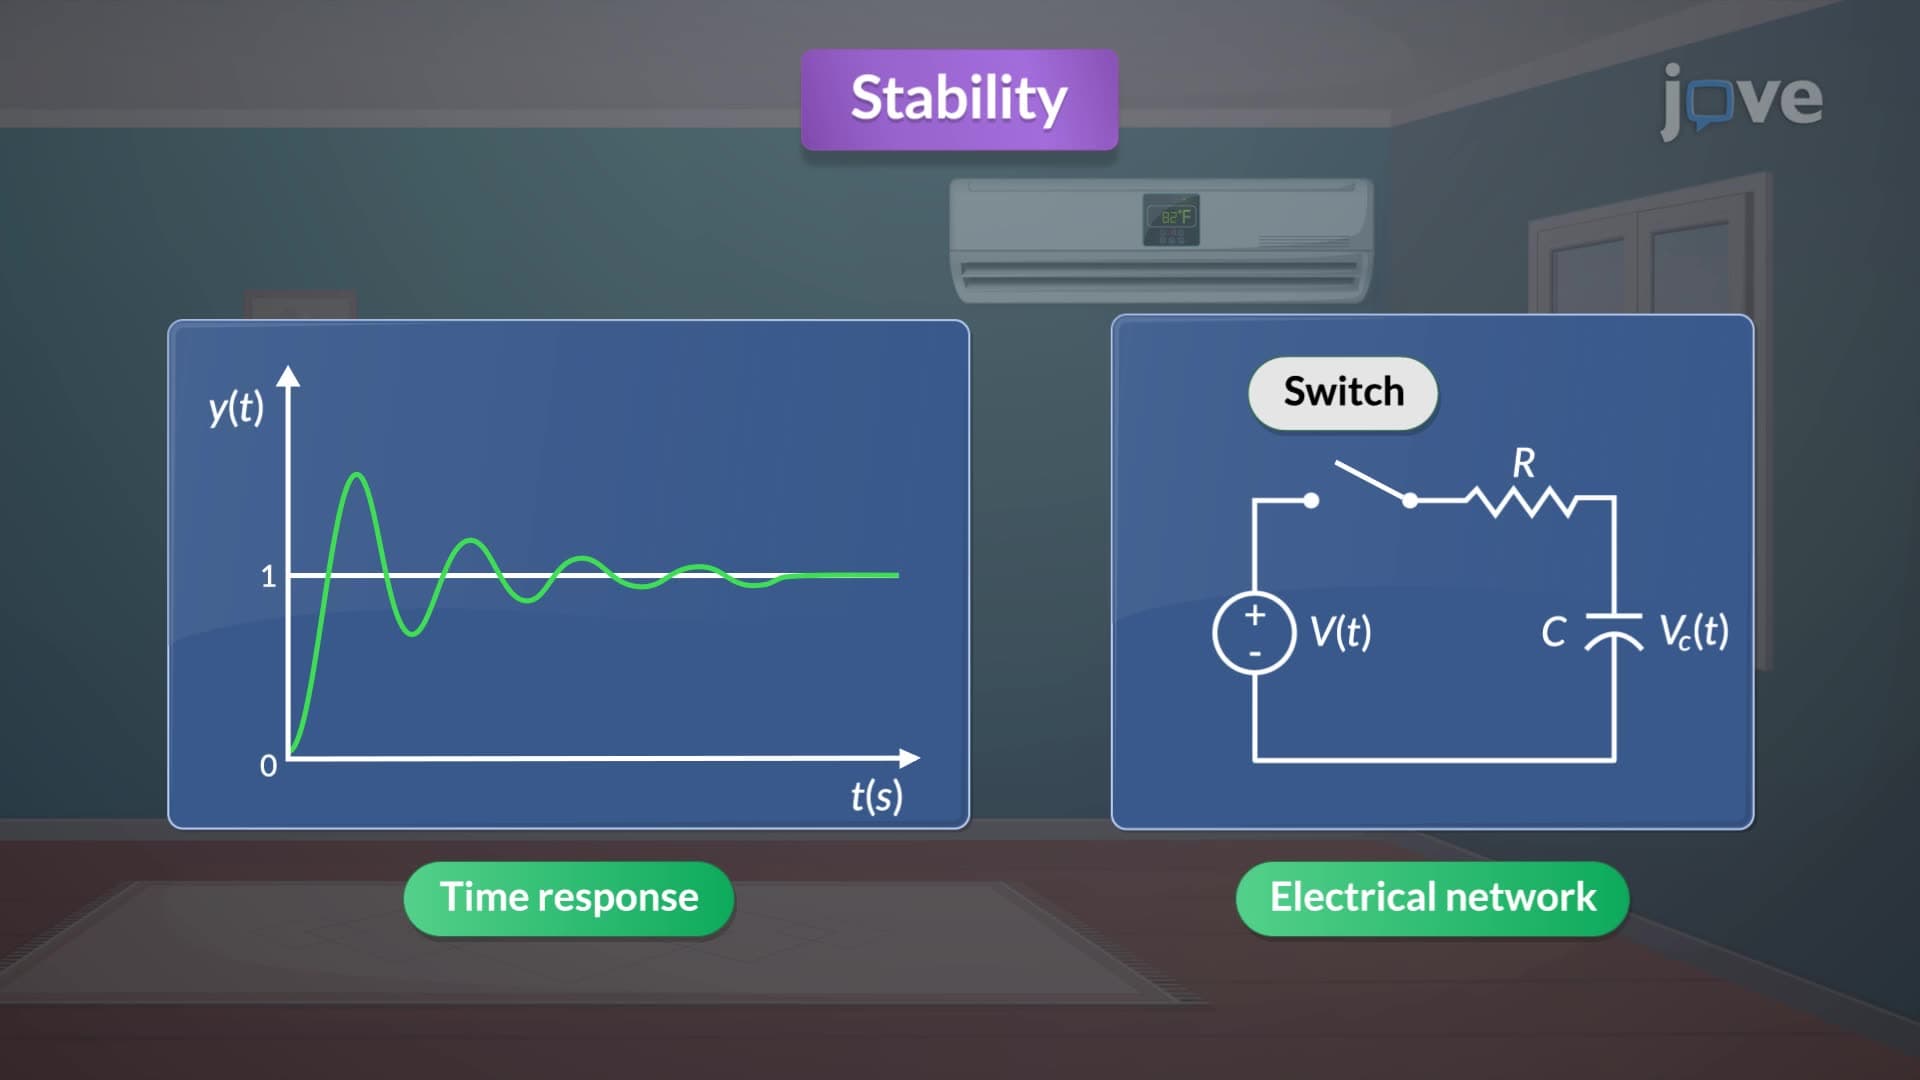
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
129