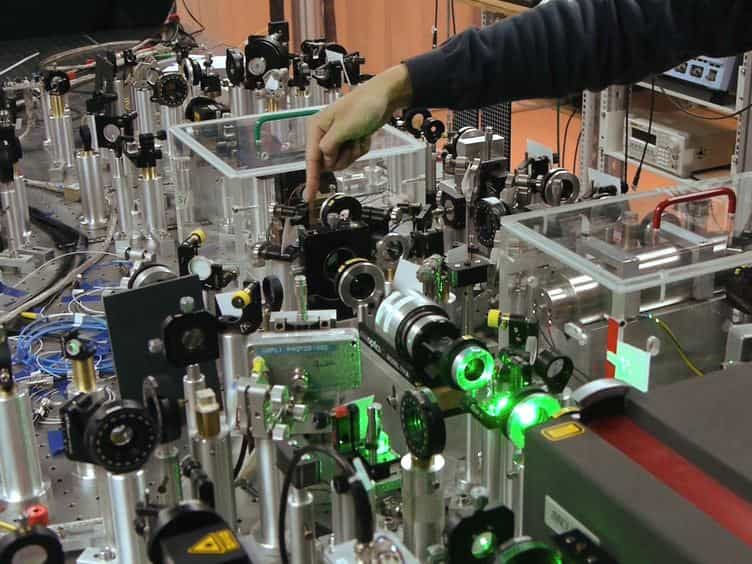

超低PM和AM噪声产生与一组相相一致振荡器
IEEE transactions on ultrasonics, ferroelectrics, and frequency control
|December 13, 2023

概括
这项研究表明,相连贯功率组合振荡器 (PPO) 显著减少相调制 (PM) 和振幅调制 (AM) 噪声. 该方法实现了7.8dB的改进,为信号生成设定了新的低噪声基准.
科学领域:
- 电气工程 电气工程
- 信号处理 信号处理
- 射频和微波工程 射频和微波工程
背景情况:
- 相连贯功率组合振荡器 (PPO) 对于实现低噪声信号生成至关重要.
- 在各种电子系统中,最小化相调制 (PM) 和振幅调制 (AM) 噪声是必不可少的.
- 以前的方法在降噪和相位对齐方面存在局限性.
研究的目的:
- 为了研究六振荡器PPO阵列在减少AM和PM噪声方面的性能.
- 量化通过连贯的功率组合实现的降噪.
- 探索优化相位对齐和最小化转换效应的方法.
主要方法:
- 构建了一个PPO阵列,由六个个别的振荡器模块组成,运行在10 MHz,100 MHz和1 GHz.
- 采用细致的相位调整技术,以实现连贯的功率组合.
- 利用载体抑制噪声测量,并提出了一种新的相位对齐优化方法.
主要成果:
- 在AM和PM噪声的白噪声区域观察到大约7.8dB的改善,与理论预测相匹配 (10log10(k)).
- 实现的单侧带 (SSB) 白相噪声水平为-182 dBc/Hz (10 MHz),191 dBc/Hz (100 MHz) 和-168 dBc/Hz (1 GHz).
- 报告的白色AM噪声水平为191dBc/Hz (10MHz),194dBc/Hz (100MHz) 和-182dBc/Hz (1GHz). 报告中的白色AM噪声水平为191dBc/Hz (10MHz),194dBc/Hz (100MHz) 和-182dBc/Hz (1GHz). 报告中的白色AM噪声水平为191dBc/Hz (10MHz),194dBc/Hz (100MHz) 和-182dBc/Hz (1GHz).
结论:
- 相连贯功率组合为超低噪声信号生成提供了重要的途径.
- 取得的噪声水平是这些频率报告中最低的.
- 有效的相位对齐对于充分实现理论降噪效益和最大限度地减少有害的PM-AM/AM-PM转换至关重要.
相关概念视频
 01:30
Oscillations In An LC Circuit
2.3K
An idealized LC circuit of zero resistance can oscillate without any source of emf by shifting the energy stored in the circuit between the electric and magnetic fields. In such an LC circuit, if the capacitor contains a charge q before the switch is closed, then all the energy of the circuit is initially stored in the electric field of the capacitor. This energy is given by
2.3K
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
98
Phase-lag controllers are widely used in control systems to improve stability and reduce steady-state errors. A dimmer switch controlling the brightness of a light bulb serves as a practical example of phase-lag control, gradually adjusting the bulb's brightness. Mathematically, phase-lag control or low-pass filtering is represented when the factor 'a' is less than 1.
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
98
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
86
Phase-lead controllers are commonly used in various control systems to enhance response speed and stability. Adjusting the brightness on a television screen offers a practical example of phase-lead control. When contrast is enhanced, a phase-lead controller is employed. Mathematically, phase-lead control is identified when the first parameter is smaller than the second.
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
86
 00:53
Sound Waves: Interference
3.8K
Sound waves can be modeled either as longitudinal waves, wherein the molecules of the medium oscillate around an equilibrium position, or as pressure waves. When two identical waves from the same source superimpose on each other, the combination of two crests or two troughs results in amplitude reinforcement known as constructive interference. If two identical waves, that are initially in phase, become out of phase because of different path lengths, the combination of crests with troughs...
3.8K
 01:04
Oscillations about an Equilibrium Position
5.4K
Stability is an important concept in oscillation. If an equilibrium point is stable, a slight disturbance of an object that is initially at the stable equilibrium point will cause the object to oscillate around that point. For an unstable equilibrium point, if the object is disturbed slightly, it will not return to the equilibrium point. There are three conditions for equilibrium points—stable, unstable, and half-stable. A half-stable equilibrium point is also unstable, but is named so...
5.4K
 01:06
Forced Oscillations
6.6K
When an oscillator is forced with a periodic driving force, the motion may seem chaotic. The motions of such oscillators are known as transients. After the transients die out, the oscillator reaches a steady state, where the motion is periodic, and the displacement is determined.
6.6K