
效率高的尼斯特罗姆式方法用于解决第二种高度振荡的沃尔特拉积分方程
1Hunan University of Science and Engineering, Yongzhou, Hunan, China.
PloS one
|December 14, 2023

概括
本研究介绍了一种优化的尼斯特罗姆型方法,用于解决高度振荡的沃尔特拉积分方程. 这种新的方法提高了工程应用中的计算效率和准确性.
科学领域:
- 数字分析 数字分析
- 计算数学 计算数学 计算数学
- 应用工程 应用工程 应用工程
背景情况:
- 高度振荡的沃尔特拉积分方程在工程中很普遍.
- 尼斯特罗姆类型的方法是这些方程的标准数值技术.
- 现有的尼斯特罗姆方法需要进一步优化效率.
研究的目的:
- 开发一种新且高效的尼斯特罗姆型方法.
- 为了加快第二种伏尔特拉整方程与振荡子核的近似解决方案.
- 在速度和准确性方面改进现有的数值方法.
主要方法:
- 在切比舍夫点上对未知函数的插入.
- 应用Nyström类型的方法来将积分方程转换为线性系统.
- 拉格朗奇多项式的新矩阵表示.
- 使用Fejér方程和扩展技术计算矩阵元素.
主要成果:
- 对于高度振荡的沃尔特拉积分方程,一种新的尼斯特罗姆式方法.
- 有效计算涉及振荡整数的矩阵元素.
- 与最近的文献方法相比,证明了更高的效率.
- 数字示例证实了该方法的准确性和效率.
结论:
- 提出的尼斯特罗姆型方法为高度振荡的沃尔特拉积分方程提供了高效和准确的解决方案.
- 矩阵配方和正方形技术是该方法性能的关键.
- 这一进步对工程应用需要此类数值解决方案具有重大意义.

相关概念视频
 01:18
Second Order systems II
113
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
113
 01:22
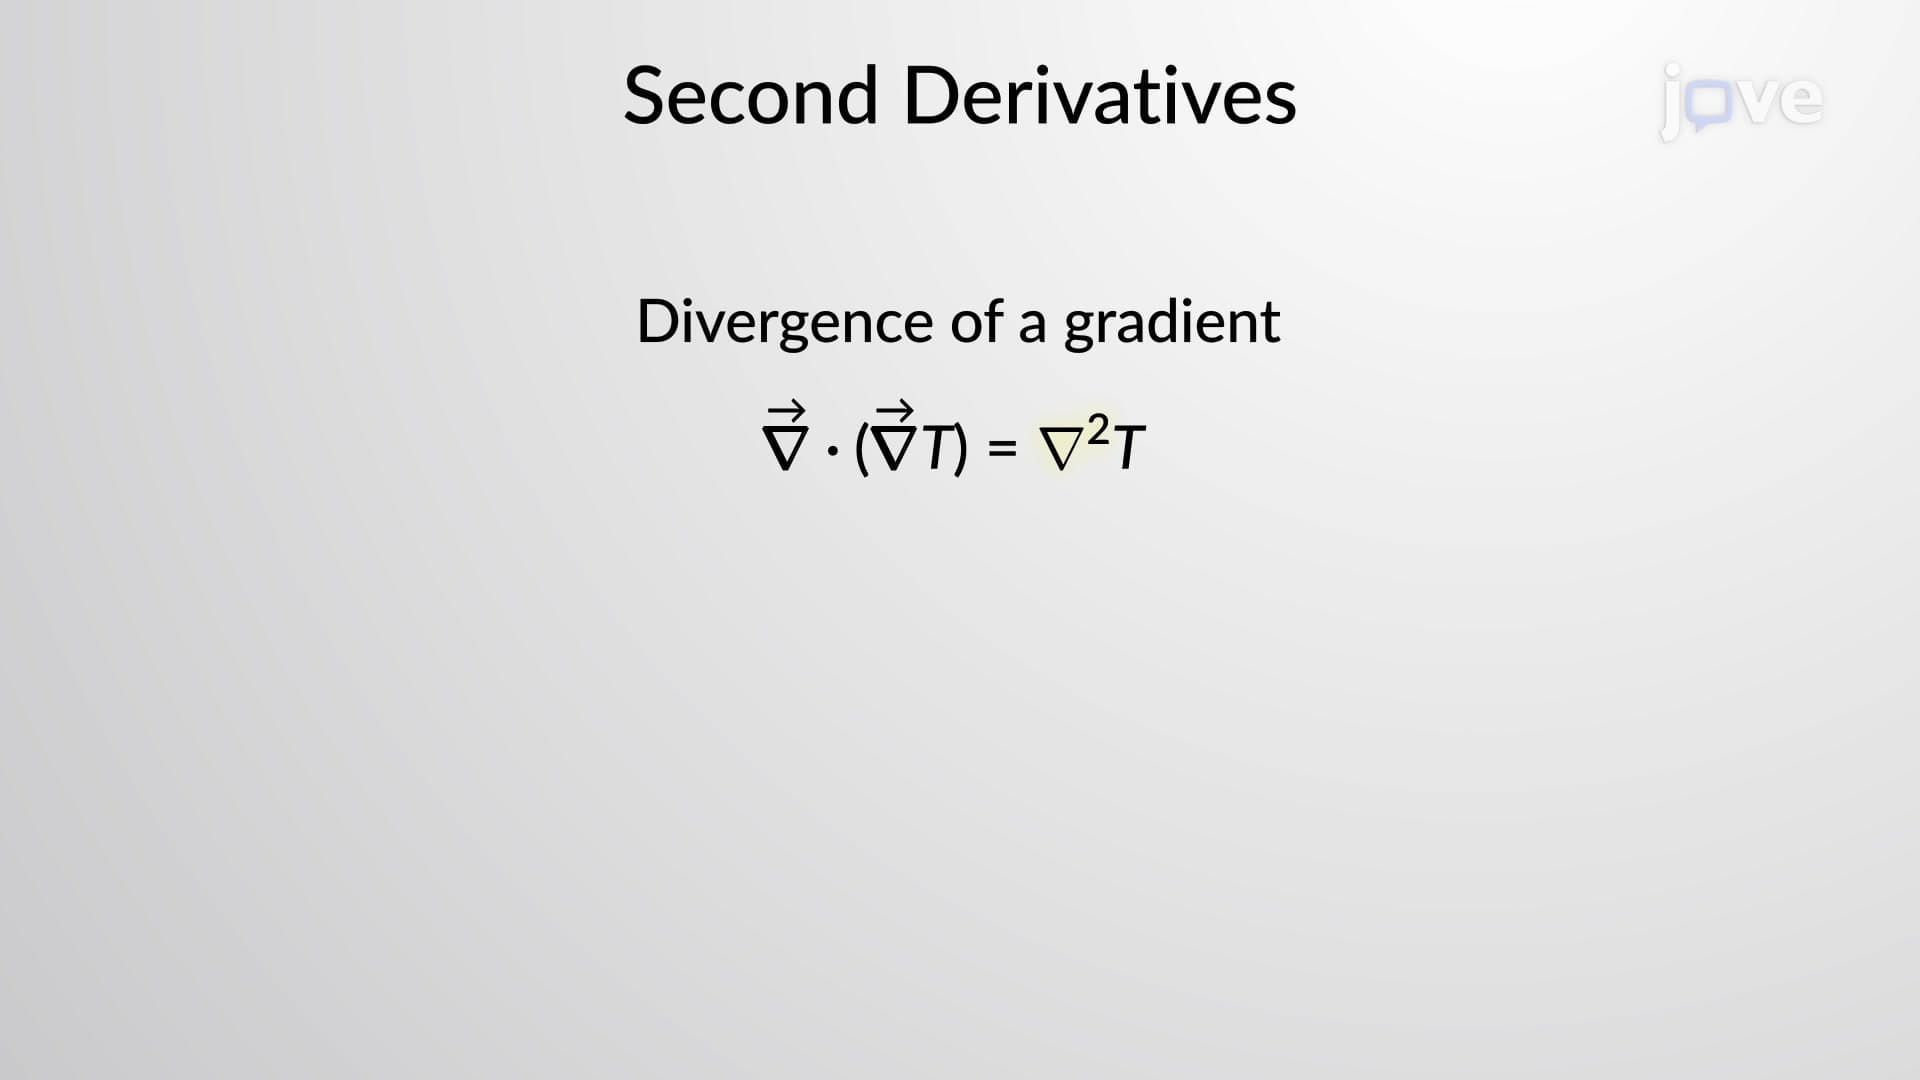
Second Derivatives and Laplace Operator
1.3K
The first order operators using the del operator include the gradient, divergence and curl. Certain combinations of first order operators on a scalar or vector function yield second order expressions. Second-order expressions play a very important role in mathematics and physics. Some second order expressions include the divergence and curl of a gradient function, the divergence and curl of a curl function, and the gradient of a divergence function.
Consider a scalar function. The curl of its...
Consider a scalar function. The curl of its...
1.3K
 01:04
Oscillations about an Equilibrium Position
5.4K
Stability is an important concept in oscillation. If an equilibrium point is stable, a slight disturbance of an object that is initially at the stable equilibrium point will cause the object to oscillate around that point. For an unstable equilibrium point, if the object is disturbed slightly, it will not return to the equilibrium point. There are three conditions for equilibrium points—stable, unstable, and half-stable. A half-stable equilibrium point is also unstable, but is named so...
5.4K
 01:21
Linear Approximation in Time Domain
83
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
83
 01:07
Damped Oscillations
5.7K
In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Although friction and other non-conservative...
5.7K
 01:26
Linear Approximation in Frequency Domain
91
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
91