
合作时间变化的形成模糊跟踪控制多种异质不确定的海上表面车辆的执行器故障
IEEE transactions on cybernetics
|December 21, 2023

概括
本研究提出了一种新的合作控制策略,用于船舶车辆,尽管存在未知的非线性和执行器故障,但可以实现时间变化的组成. 该方法确保了异质车辆集群的稳定跟踪和形成控制.
科学领域:
- 机器人和控制系统 机器人和控制系统
- 海洋工程 海洋工程
- 人工智能的人工智能
背景情况:
- 海洋表面车辆需要先进的控制合作任务.
- 不同质的车辆集群面临着未知的非线性和执行器故障的挑战.
- 实现动态,时间变化的阵列对于协调行动至关重要.
研究的目的:
- 制定一套对异质船舶的合作控制方案.
- 为了应对未知的非线性和执行器故障在形成控制的挑战.
- 为了实现不对称的稳定跟踪和时间变化的形成控制.
主要方法:
- 一个分布式的时间变化的形成观测器被设计为实现预定义的形成模式.
- 使用模糊逻辑系统开发了一个分散的自适应模糊跟踪控制器.
- 使用Lyapunov函数来保证跟踪错误的稳定性.
主要成果:
- 拟议的观察者在定向通信拓下成功实现了所需的时间变化的形成.
- 分散控制器确保了车辆集群的稳定跟踪和形成控制.
- 模拟结果验证了合作控制方法的有效性.
结论:
- 开发的控制方案有效地管理了对异质船舶的合作时间变化的形成控制.
- 该方法可稳定处理未知的非线性和执行器故障.
- 该方法确保了跟踪错误的非对称稳定性,使得准确的形成机动.
更多相关视频
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
1.7K
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
5.0K
相关概念视频
 01:18
Uniform Depth Channel Flow: Problem Solving
66
To calculate the flow rate for a trapezoidal channel, first, identify the bottom width, side slope, and flow depth of the channel. The cross-sectional area (A) corresponding to the depth of flow (y), channel bottom width (B), and side slope (θ) is determined by:Next, calculate the wetted perimeter, which includes the bottom width and the sloped side lengths in contact with the water. Using the values of the cross-sectional area and the wetted perimeter, determine the hydraulic radius by...
66
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
1.8K
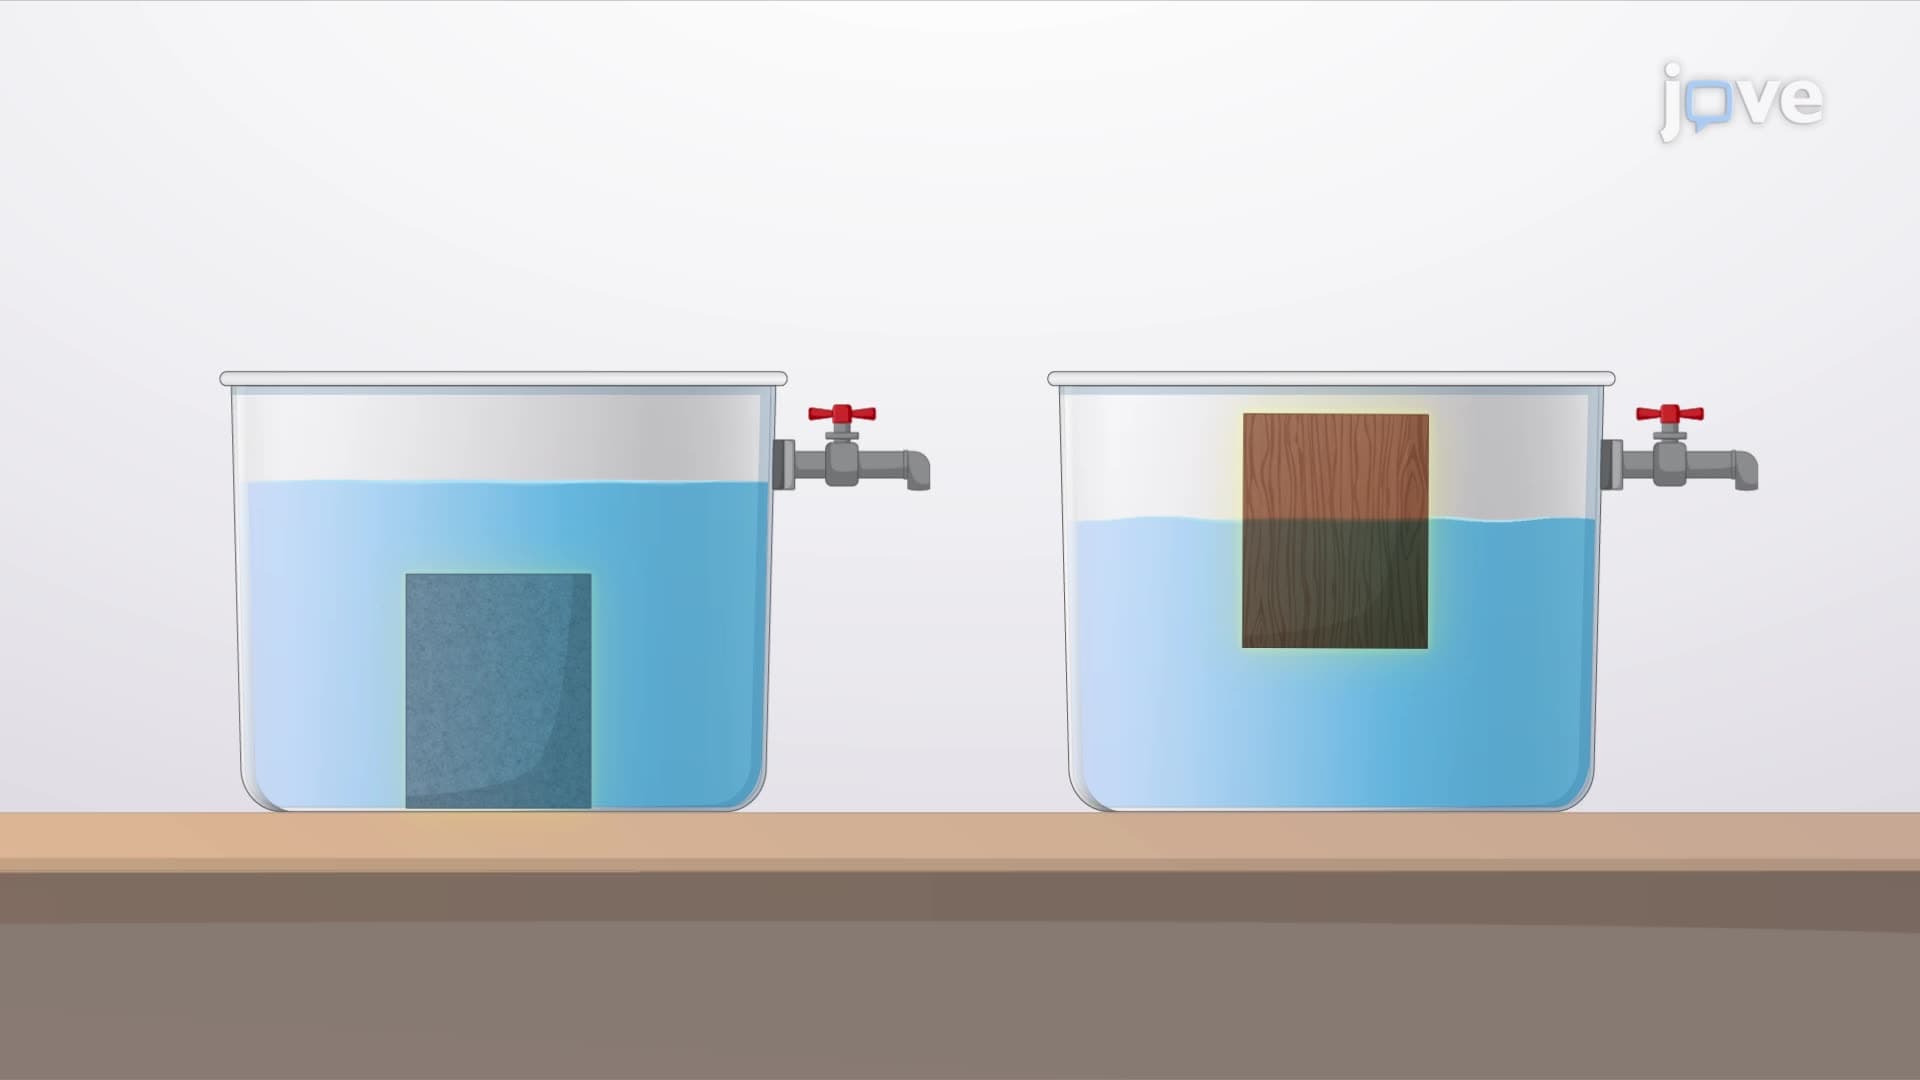
In fluid mechanics, buoyancy and stability are key concepts for understanding the behavior of submerged and floating bodies. When a stationary body is fully or partially submerged in a fluid, the fluid exerts a force on the body known as the buoyant force. This force acts vertically upward through a point called the center of buoyancy, which is the center of the displaced fluid volume. According to Archimedes' principle, the magnitude of the buoyant force is equal to the weight of the fluid...
1.8K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
406
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
406
 01:22
Multi-input and Multi-variable systems
106
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
106
 01:09
Turbulent Flow: Problem Solving
132
Carbonation is a process used to dissolve carbon dioxide gas in a liquid, commonly used in the production of carbonated beverages. Achieving efficient carbonation requires careful control of temperature, pressure, and flow conditions. By adjusting these parameters, carbonation efficiency can be maximized, producing a higher concentration of CO2 in the liquid.
Temperature is a key factor in CO2 solubility. In this case, the CO2 gas and the liquid are cooled to 20°C. Lower temperatures...
Temperature is a key factor in CO2 solubility. In this case, the CO2 gas and the liquid are cooled to 20°C. Lower temperatures...
132
 01:24
One-Degree-of-Freedom System
490
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
490