卷积交叉视图位置估计
IEEE transactions on pattern analysis and machine intelligence
|December 25, 2023

概括
这项研究引入了一种用于交叉视图姿势估计的新方法,通过地面和空中图像准确确定相机位置和方向. 这种方法显著提高了准确性,超过了精确定位的现有方法.
科学领域:
- 计算机视觉 计算机视觉
- 机器人技术 机器人技术 机器人技术
- 地理空间分析的研究.
背景情况:
- 交叉视图姿势估计对于自动驾驶和机器人等应用至关重要.
- 现有的方法经常在准确性和处理本地化模两可方面扎.
研究的目的:
- 开发一种端到端的方法,使用地面和空中图像进行准确的3度自由度 (3DoF) 摄像头姿势估计.
- 为了提高本地化准确度,并在交叉视图场景中处理模糊性.
主要方法:
- 使用通过翻译等价卷积编码器和对比学习生成的定向感知图像描述器.
- 采用一种新的局部化解码器与局部化匹配的抽样模块,用于粗细的概率分布.
- 集成一个定向解码器,以在定位上进行定向估计.
主要成果:
- 在VIGOR和KITTI数据集上实现了卓越的性能,在中位数定位错误方面超过了最先进的基线72%,36%.
- 在牛津机器人汽车数据集上展示了可靠的自我车辆姿势估计,具有次米定位和14FPS的1度定位精度.
- 该方法通过预测的概率分布有效地表示和拒绝本地化模糊性.
结论:
- 拟议的方法为交叉视图姿势估计提供了强大而准确的解决方案.
- 该方法表现出多功能性,适应不同的图像视野,并利用未经再培训的导向先验.
- 这种技术在机器人技术和自主导航领域的现实应用中具有显著的潜力.
更多相关视频
 06:32
Author Spotlight: Automated Deep Brain Stimulation for Parkinson's Disease - Exploring the Possibilities and Challenges of Home Monitoring
Published on: July 14, 2023
1.3K
 05:49
Author Spotlight: Deciphering Electrical Networks Behind Complex Brain Activities and Disorders
Published on: November 1, 2024
808
相关概念视频
 01:25
Cross Product
249
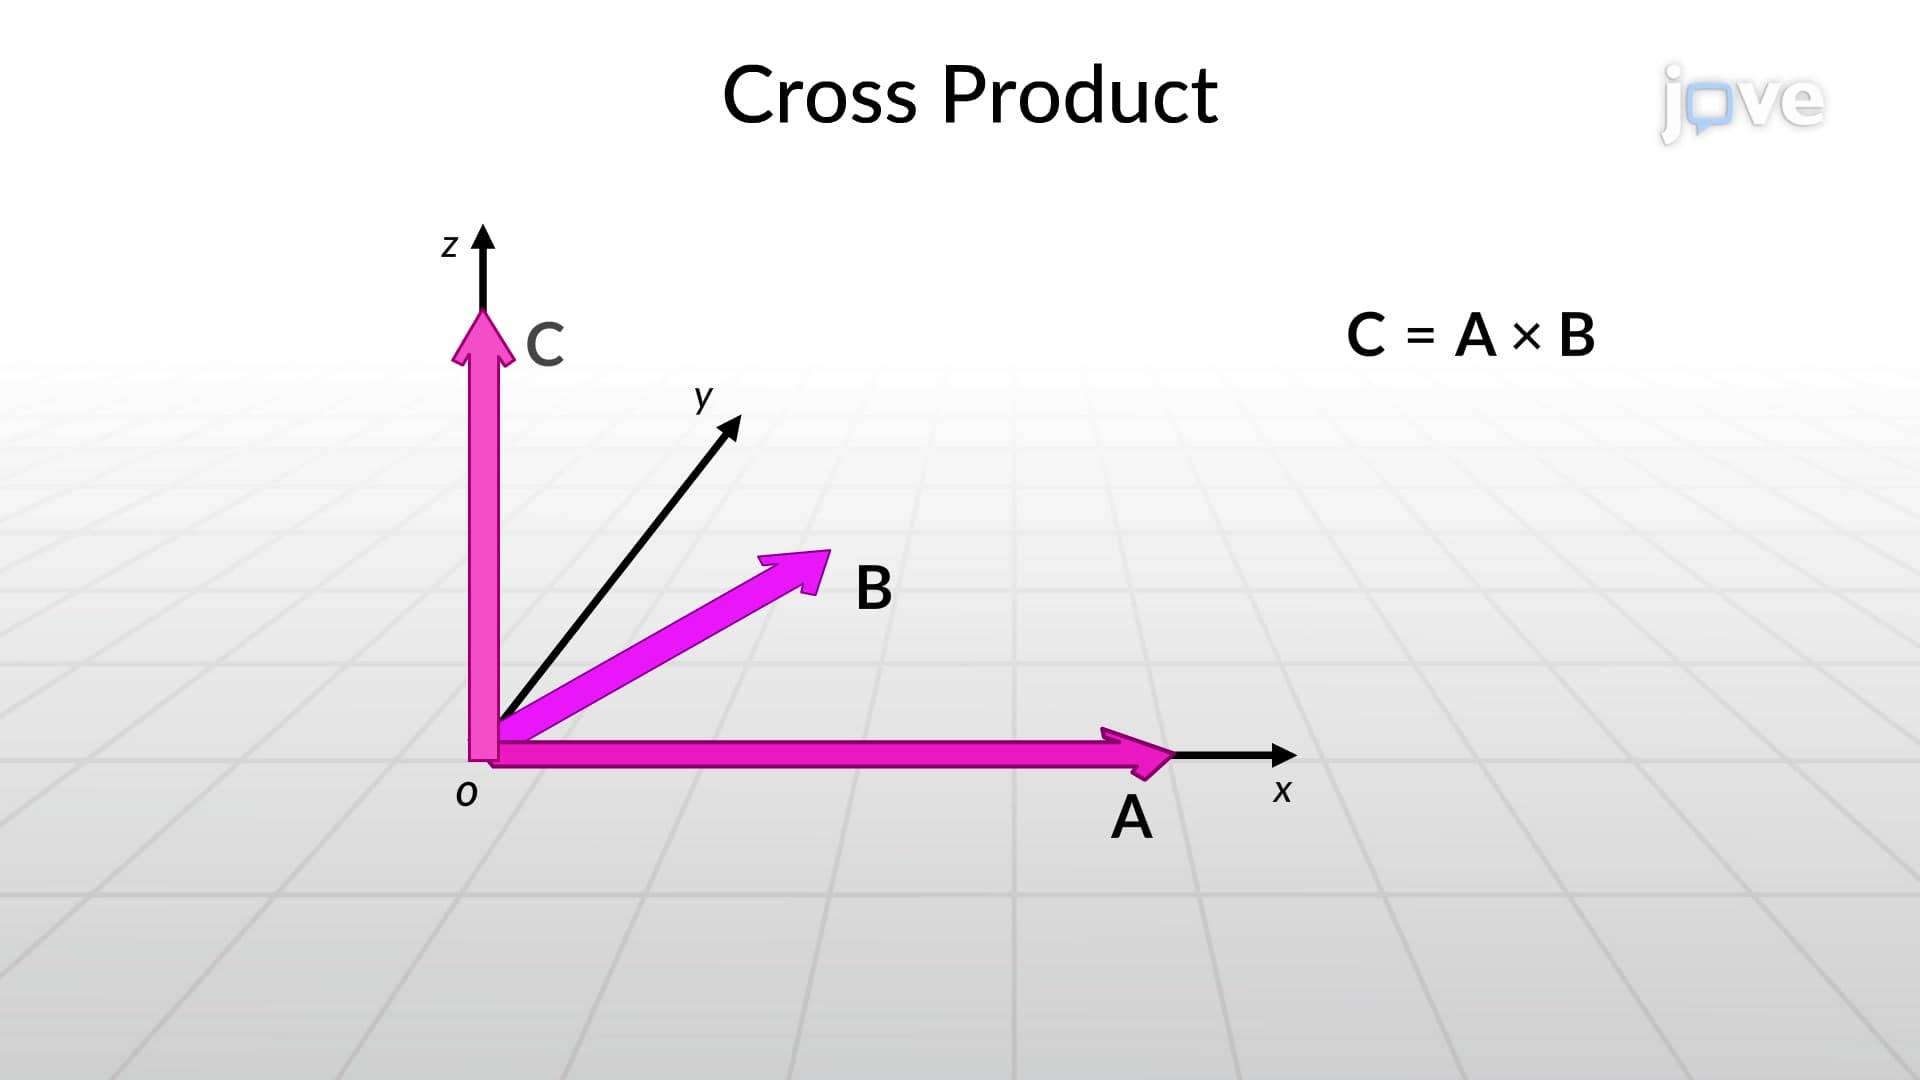
The cross product is a fundamental concept in vector algebra that is a vector operation on two different vectors to obtain a third vector. Unlike the scalar product, the cross product results in a vector quantity perpendicular to both the original vectors.
The magnitude of the cross product is obtained by multiplying the magnitude of both the vectors and the sine of the angle between them. This means that a larger angle between the vectors will lead to a greater magnitude of the cross product.
The magnitude of the cross product is obtained by multiplying the magnitude of both the vectors and the sine of the angle between them. This means that a larger angle between the vectors will lead to a greater magnitude of the cross product.
249
 01:20
Convolution Properties I
153
Convolution computations can be simplified by utilizing their inherent properties.
The commutative property reveals that the input and the impulse response of an LTI (Linear Time-Invariant) system can be interchanged without affecting the output:
The commutative property reveals that the input and the impulse response of an LTI (Linear Time-Invariant) system can be interchanged without affecting the output:
153
 01:17
Convolution Properties II
208
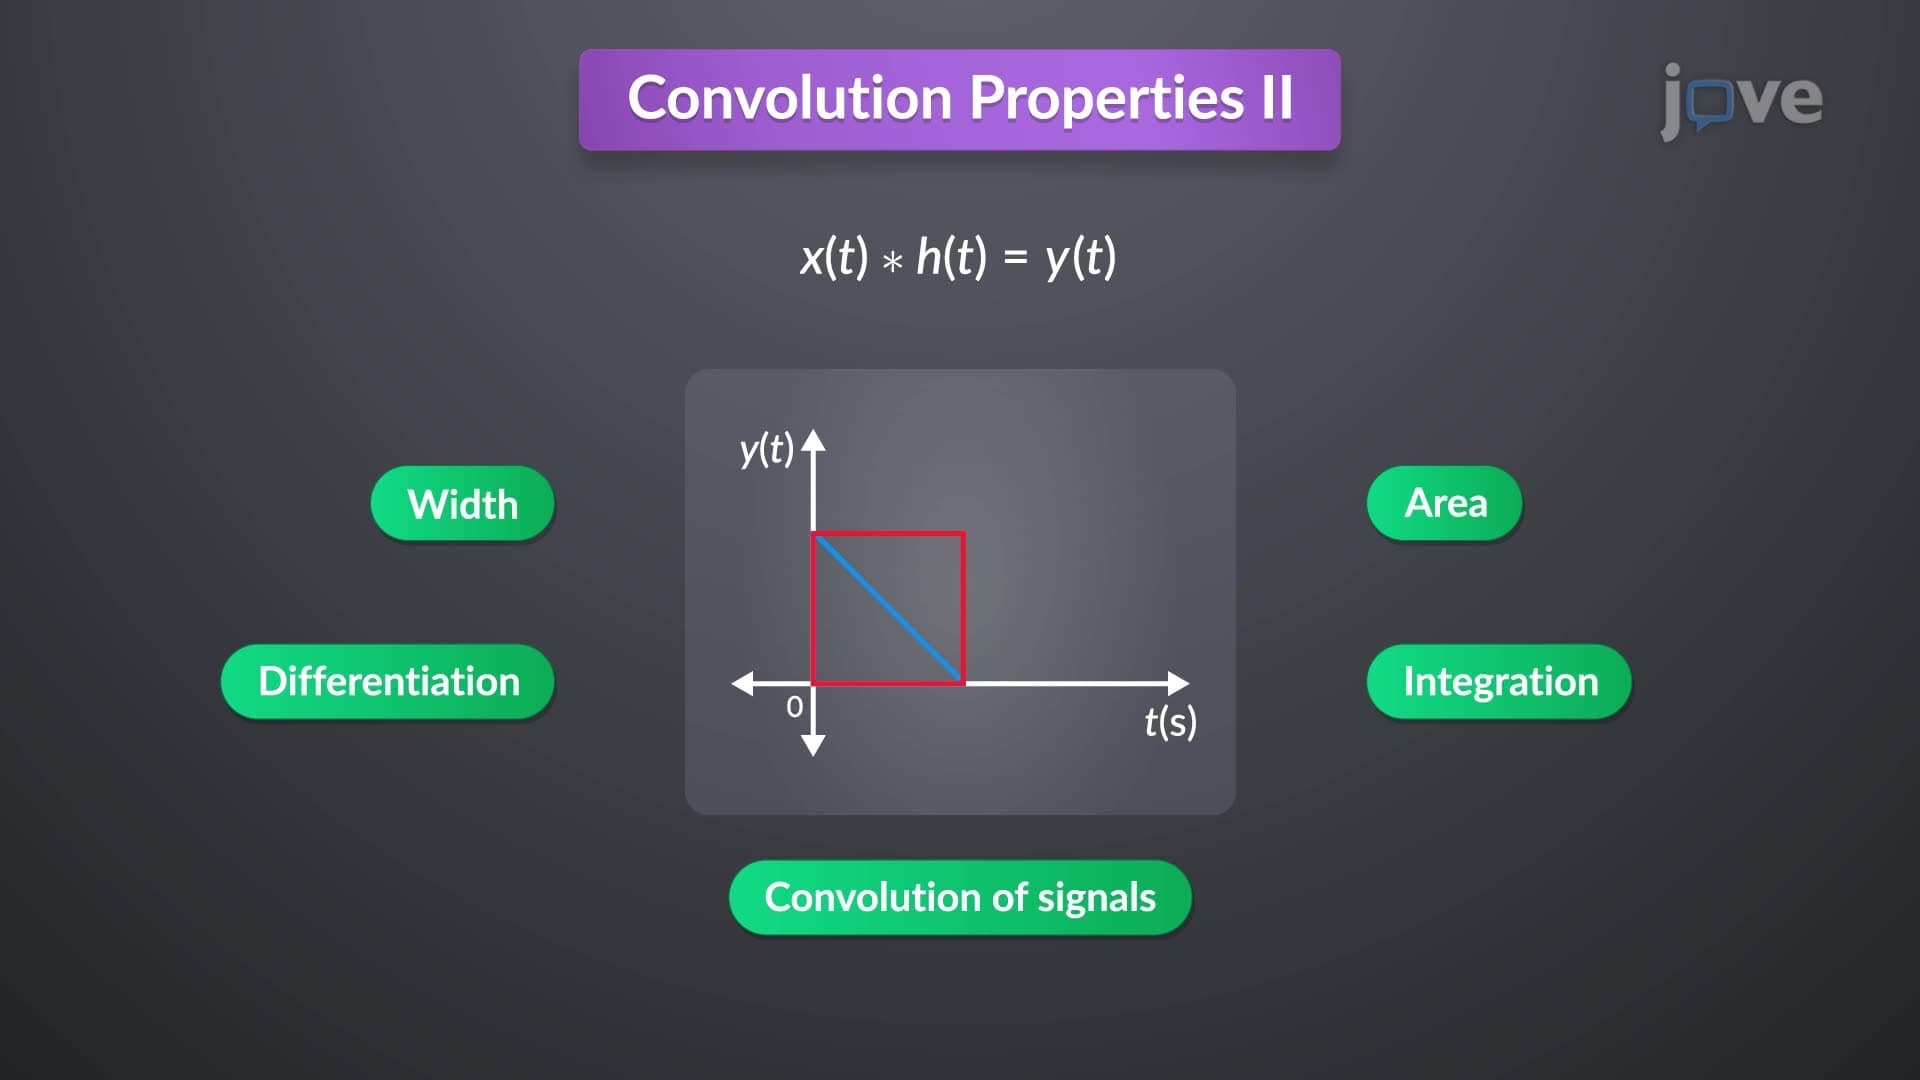
The important convolution properties include width, area, differentiation, and integration properties.
The width property indicates that if the durations of input signals are T1 and T2, then the width of the output response equals the sum of both durations, irrespective of the shapes of the two functions. For instance, convolving two rectangular pulses with durations of 2 seconds and 1 second results in a function with a width of 3 seconds.
The area property asserts that the area under the...
208
 01:20
Deconvolution
162
Deconvolution, also known as inverse filtering, is the process of extracting the impulse response from known input and output signals. This technique is vital in scenarios where the system's characteristics are unknown, and they must be inferred from the observable signals.
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
162
 01:23
Curvilinear Motion: Rectangular Components
460
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
460
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
406
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
406