

从多个未指定的角度进行无监督的以对象为中心的学习
IEEE transactions on pattern analysis and machine intelligence
|January 3, 2024

概括
本研究介绍了一种深度生成模型,用于从多个角度学习构成场景的表现,而无需监督. 该模型通过将视角独立和依赖特征分开来实现对象常数,从而实现高效的视觉学习.
科学领域:
- 计算机视觉 计算机视觉
- 机器学习 机器学习
- 人工智能的人工智能
背景情况:
- 视觉场景由于对象组合和视角变化而具有固有的多样性.
- 人类表现出了非凡的对象恒定性,在没有明确标签的情况下,在不同的视角上识别对象.
- 这种能力对于有效的视觉学习和在运动过程中对象识别至关重要.
研究的目的:
- 为了应对学习来自多个,未指定的观点的构成性场景表现的挑战.
- 开发一种能够在没有监督的情况下实现对象常数的模型.
- 使机器能够像人类一样高效地从视觉数据中学习.
主要方法:
- 提出了一种新的深度生成模型,用于无监督的构成场景表示学习.
- 该模型将潜伏的表征分解为视角独立和视角依赖的组件.
- 采用了一种代推理过程,通过使用神经网络在多个观点之间整合信息来更新隐藏的表示.
主要成果:
- 证明了模型在从多个未指定的观点学习中的有效性.
- 成功实现了创作场景理解和对象恒定性.
- 在合成数据集上的实验验验证了拟议的方法.
结论:
- 开发的深度生成模型为无监督学习构造场景表示提供了一个有希望的解决方案.
- 该方法有效地处理多个未指定的观点,模仿人类对象恒定性.
- 这项工作有助于提高AI解释复杂视觉环境的能力.
相关概念视频
 01:06
Collisions in Multiple Dimensions: Problem Solving
4.2K
In multiple dimensions, the conservation of momentum applies in each direction independently. Hence, to solve collisions in multiple dimensions, we should write down the momentum conservation in each direction separately. To help understand collisions in multiple dimensions, consider an example.
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
4.2K
 01:12
Observational Learning
179
Albert Bandura's observational learning, also known as imitation or modeling, occurs when a person observes and imitates another's behavior. It is a quicker process than operant conditioning. A well-known example is the Bobo doll study, where children who saw an adult acting aggressively towards the doll were more likely to act aggressively when left alone, compared to those who observed a nonaggressive adult. Many psychologists view observational learning as a form of latent learning...
179
 01:05
Collisions in Multiple Dimensions: Introduction
5.4K
It is far more common for collisions to occur in two dimensions; that is, the initial velocity vectors are neither parallel nor antiparallel to each other. Let's see what complications arise from this. The first idea is that momentum is a vector. Like all vectors, it can be expressed as a sum of perpendicular components (usually, though not always, an x-component and a y-component, and a z-component if necessary). Thus, when the statement of conservation of momentum is written for a...
5.4K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
406
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
406
 01:15
Depth Perception and Spatial Vision
661
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
661
 01:03
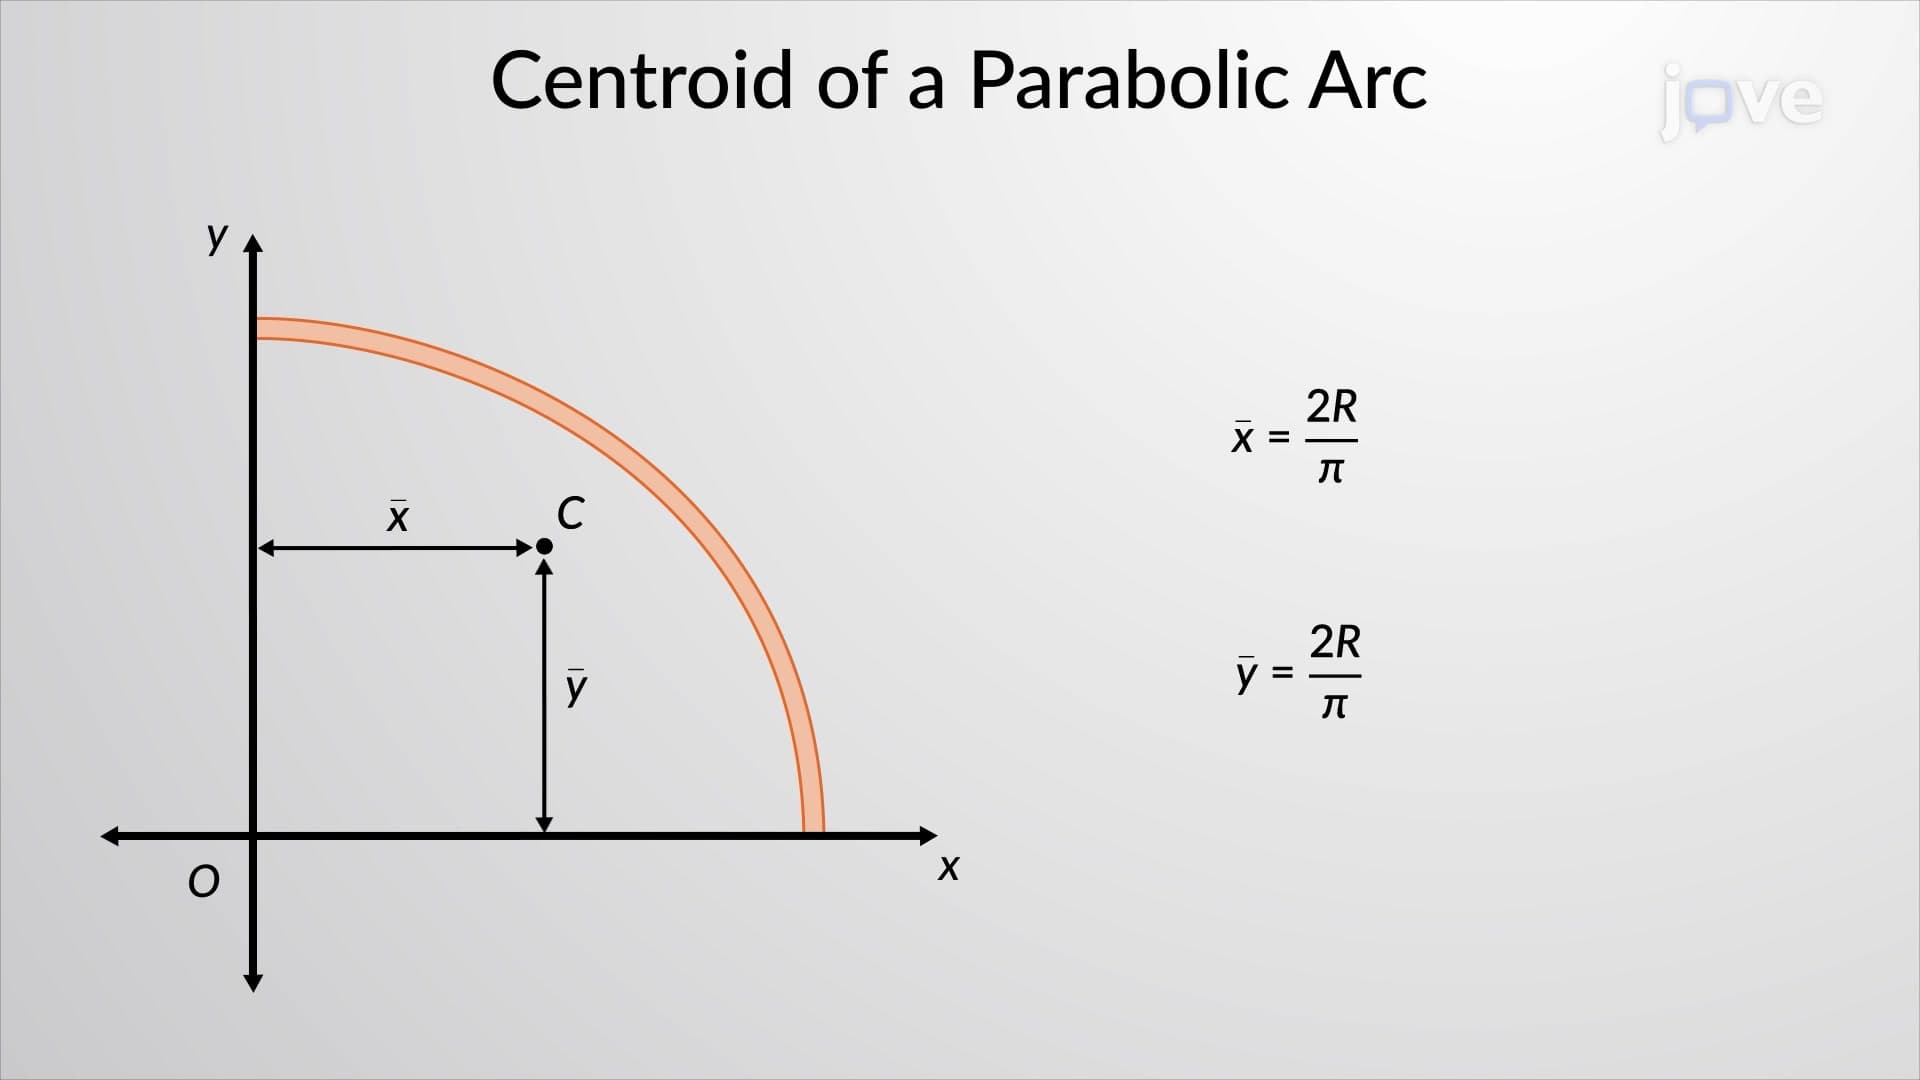
Centroid of a Body: Problem Solving
1.2K
The centroid of a body is a crucial concept in engineering and physics. Finding the centroid of a body can help determine its stability, its balance point, and even its design. In this context, consider a thin wire bent in the form of a quarter circular arc. Polar coordinates are used to calculate the centroid. The wire is first divided into small differential elements of a length equal to the radius multiplied by the differential angle.
The x-coordinates and y-coordinates of each element's...
The x-coordinates and y-coordinates of each element's...
1.2K