

概括
本研究介绍了一种新的6DOF运动跟踪系统,用于并行操纵器 (PM). 几何误差识别显著提高了姿势测量准确度,降低了98.7%的位置误差和90.2%的方向误差.
科学领域:
- 机器人与机械工程 机器人与机械工程
- 计量学和测量科学 计量学和测量科学
背景情况:
- 准确的姿势测量对于平行操纵器 (PM) 的性能至关重要.
- 测量系统中的几何错误可以显著降低姿势准确性.
- 现有的方法可能无法准确地在线测量PM.
研究的目的:
- 设计和验证一种新的集成6DOF运动跟踪系统,用于对平行操纵器进行精确的在线姿势测量.
- 开发一种方法来识别和补偿影响姿势测量的几何错误.
- 为了显著提高并行操纵器姿势测量的准确性.
主要方法:
- 一个6-DOF运动跟踪系统,使用六个格子统治器来提供位移信息.
- 向前动力学从位移数据中获得测量姿势.
- 与立体视觉对错误采集的比较.
- 建立基于闭环矢量动力学模型和错误模型.
- 使用最小平方法识别几何错误.
主要成果:
- 在几何校准后,测量精度显著提高.
- 平均位置误差从3.148毫米减少到0.036毫米.
- 平均定位误差从0.225°降低到0.022°.
结论:
- 开发的集成运动跟踪系统有效地测量了并行操纵器的姿势.
- 拟议的几何误差识别方法显著提高了测量精度.
- 该系统展示了高精度和机器人实时应用的潜力.

相关概念视频
 01:24
One-Degree-of-Freedom System
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
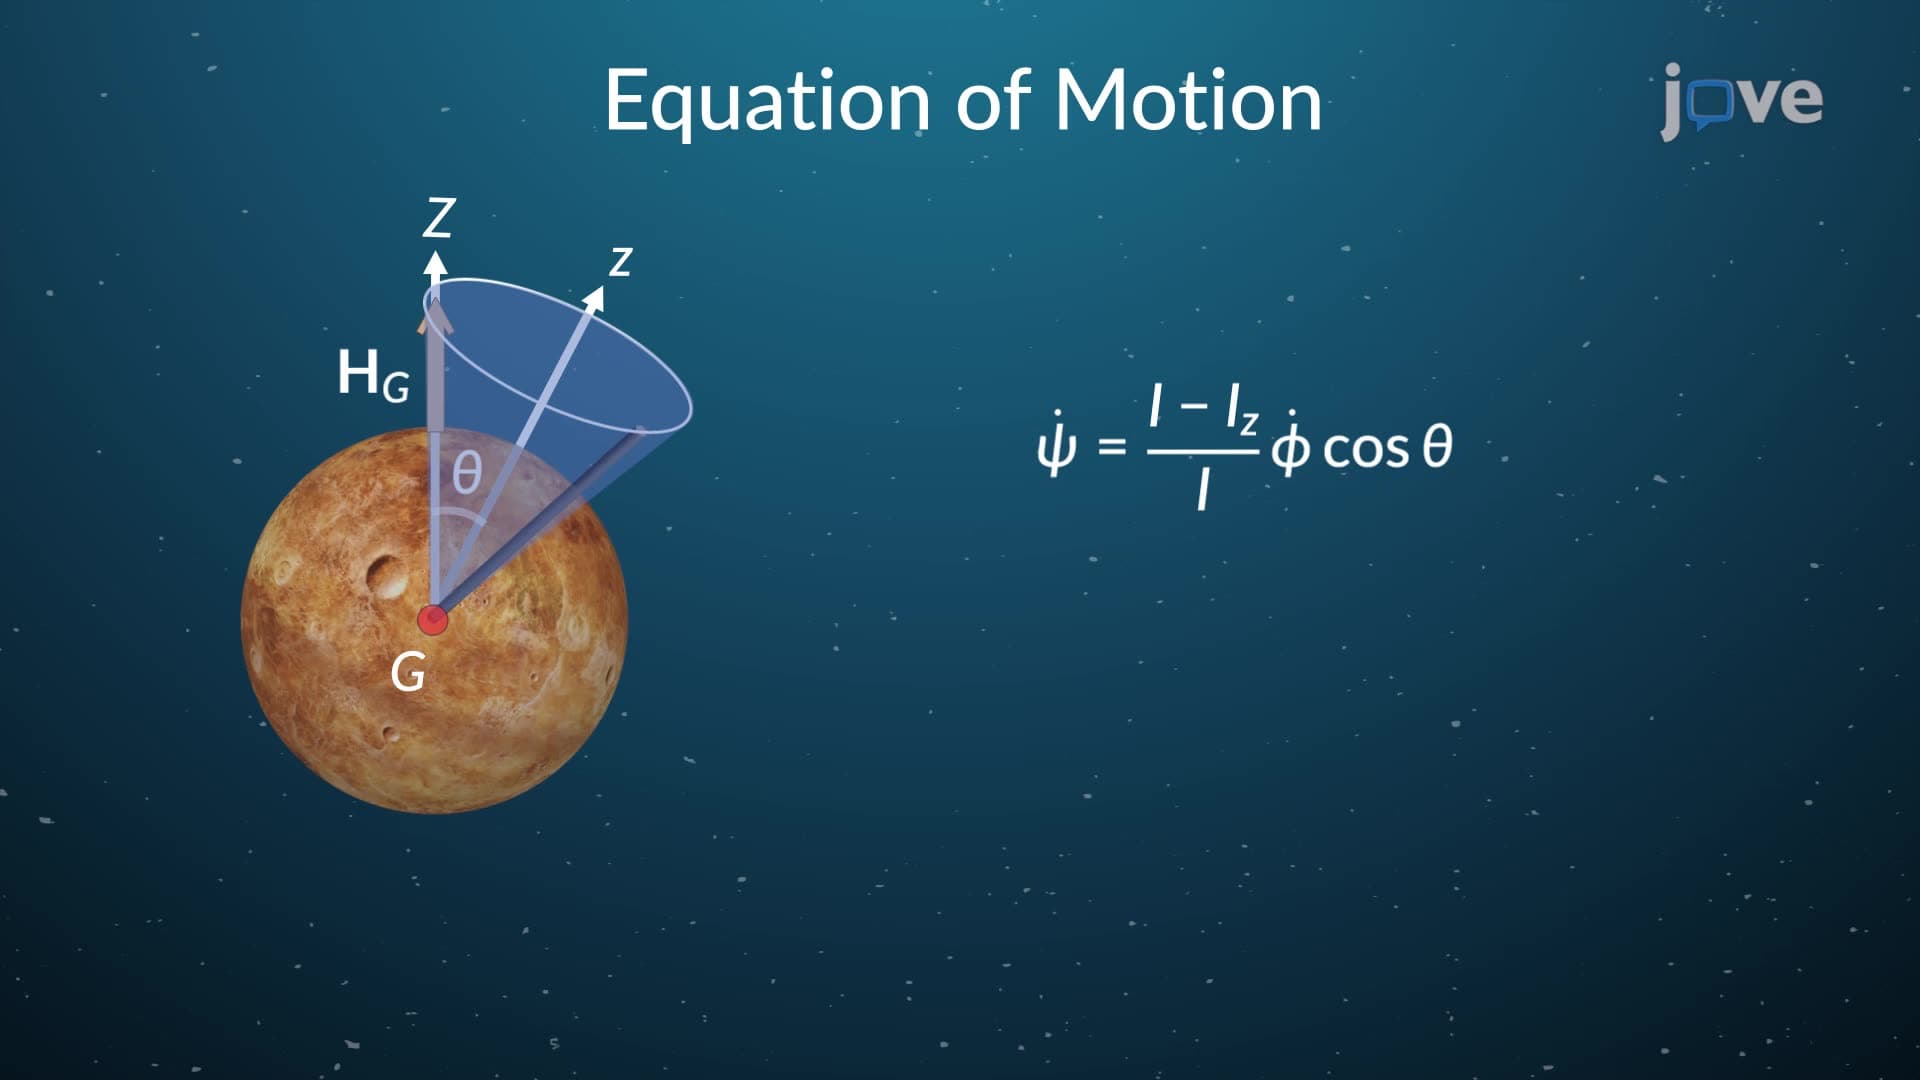
Torque Free Motion
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...