
关键考夫曼模型中的吸引数是指数的
1London Institute for Mathematical Sciences, Royal Institution, 21 Albemarle Street, London W1S 4BS, United Kingdom.
Physical review letters
|January 12, 2024

概括
研究人员证明,在关键考夫曼模型中,吸引子的数量随着网络的大小呈指数增长. 这一发现提升了对生物系统中遗传计算和关键性的理解.
科学领域:
- 计算生物学是一种计算生物学.
- 系统生物学 系统生物学
- 理论计算机科学理论计算机科学
背景情况:
- 考夫曼模型是遗传调节网络的基础模型.
- 许多生物系统都表现出关键性,即在秩序和混乱之间平衡的状态.
- 了解关键网络中的吸引力动态对于生物见解至关重要.
研究的目的:
- 确定关键考夫曼模型中吸引力的精确增长率.
- 为吸引子数量缩放提供了明确的数学证明.
主要方法:
- 考夫曼模型的数学分析与连接一.
- 在关键状态中引力数的边界的导出.
主要成果:
- 在关键考夫曼模型中,具有连接性为 1 的吸引子的数量至少和最多增长为 (2/sqrt[e]) ^N.
- 这就建立了这个模型中吸引子的第一个指数增长证明.
结论:
- 在关键的考夫曼网络中,吸引子的数量随着网络大小N而呈指数变大.
- 这为遗传调节系统的复杂性提供了定量理解.
- 这些发现支持了生物计算中关键性的重要性.
更多相关视频
 10:21
Quantifying Spatiotemporal Parameters of Cellular Exocytosis in Micropatterned Cells
Published on: September 16, 2020
6.2K
 09:23
Methodology for Developing Life Tables for Sessile Insects in the Field Using the Whitefly, Bemisia tabaci, in Cotton As a Model System
Published on: November 1, 2017
11.9K
相关概念视频
 01:19
Routh-Hurwitz Criterion II
252
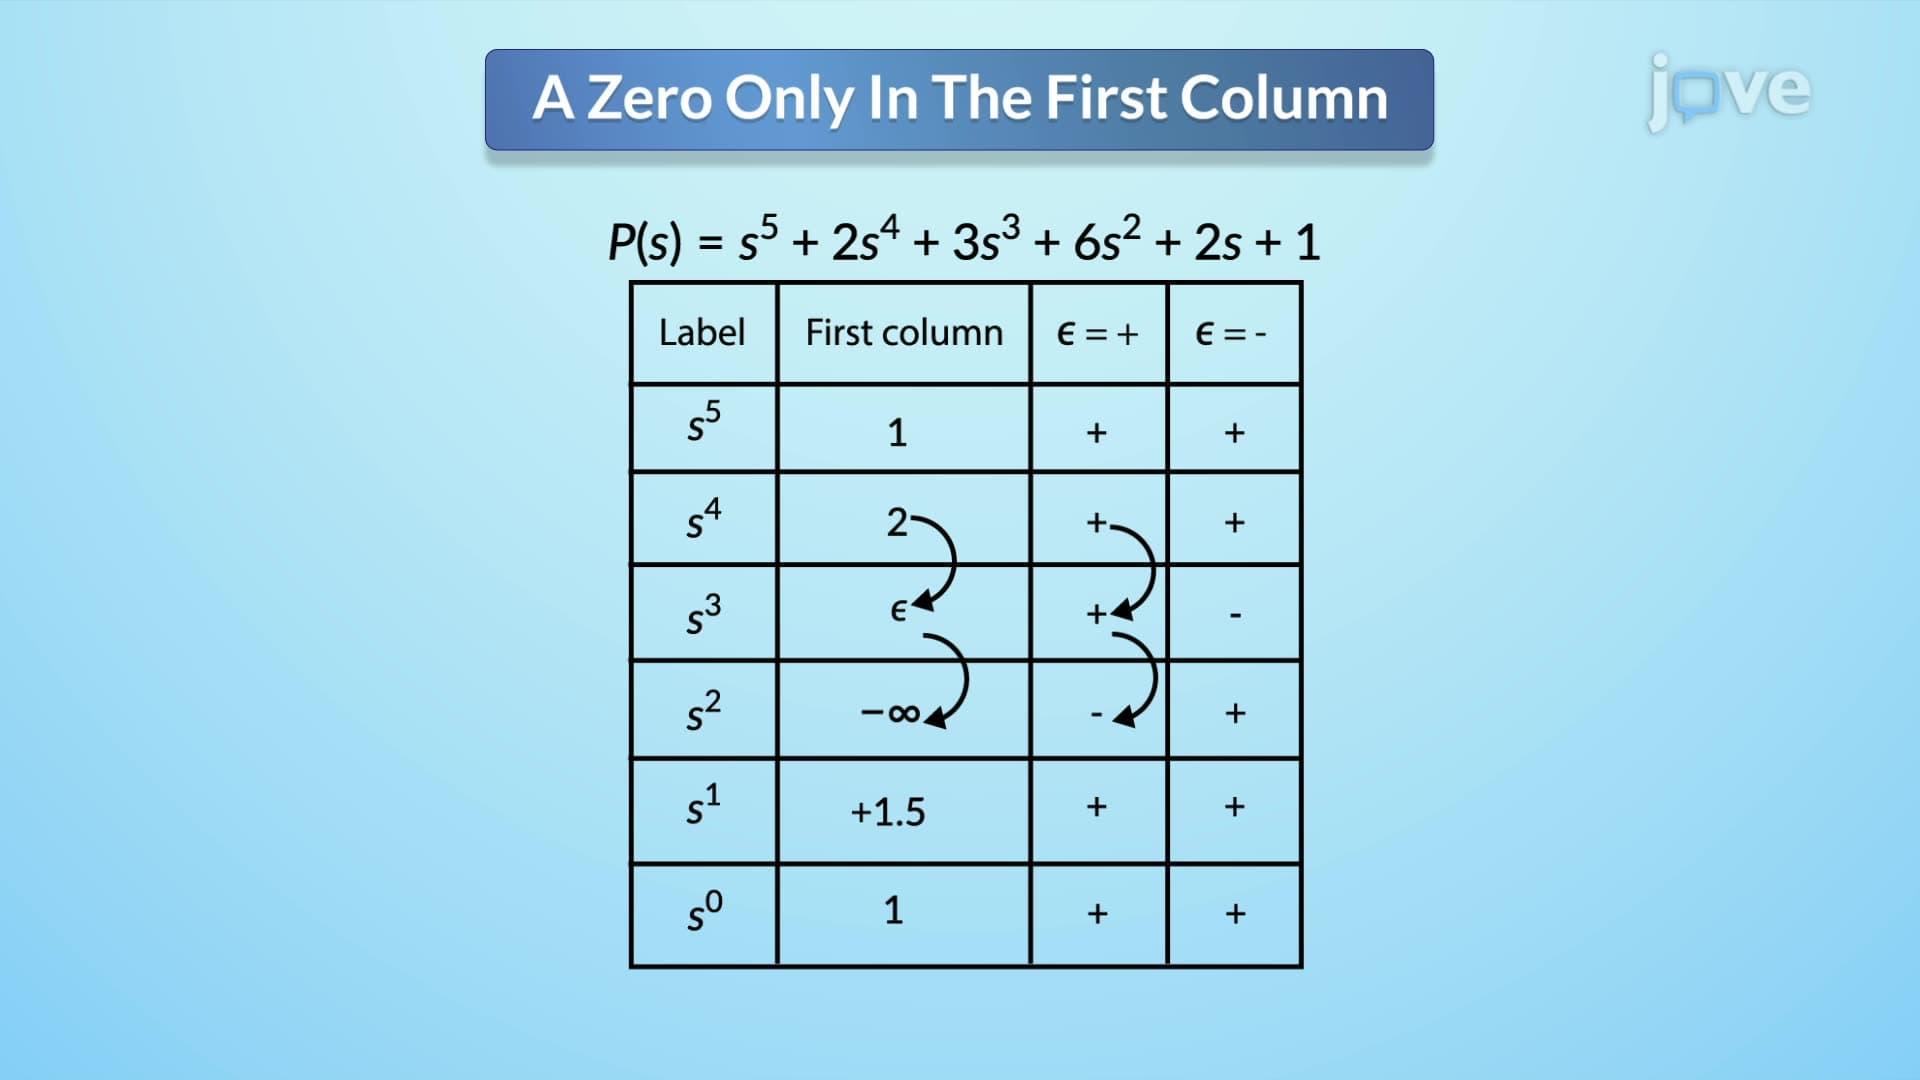
In the application of the Routh-Hurwitz criterion, two specific scenarios can arise that complicate stability analysis.
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
252
 01:15
Construction of Root Locus
121
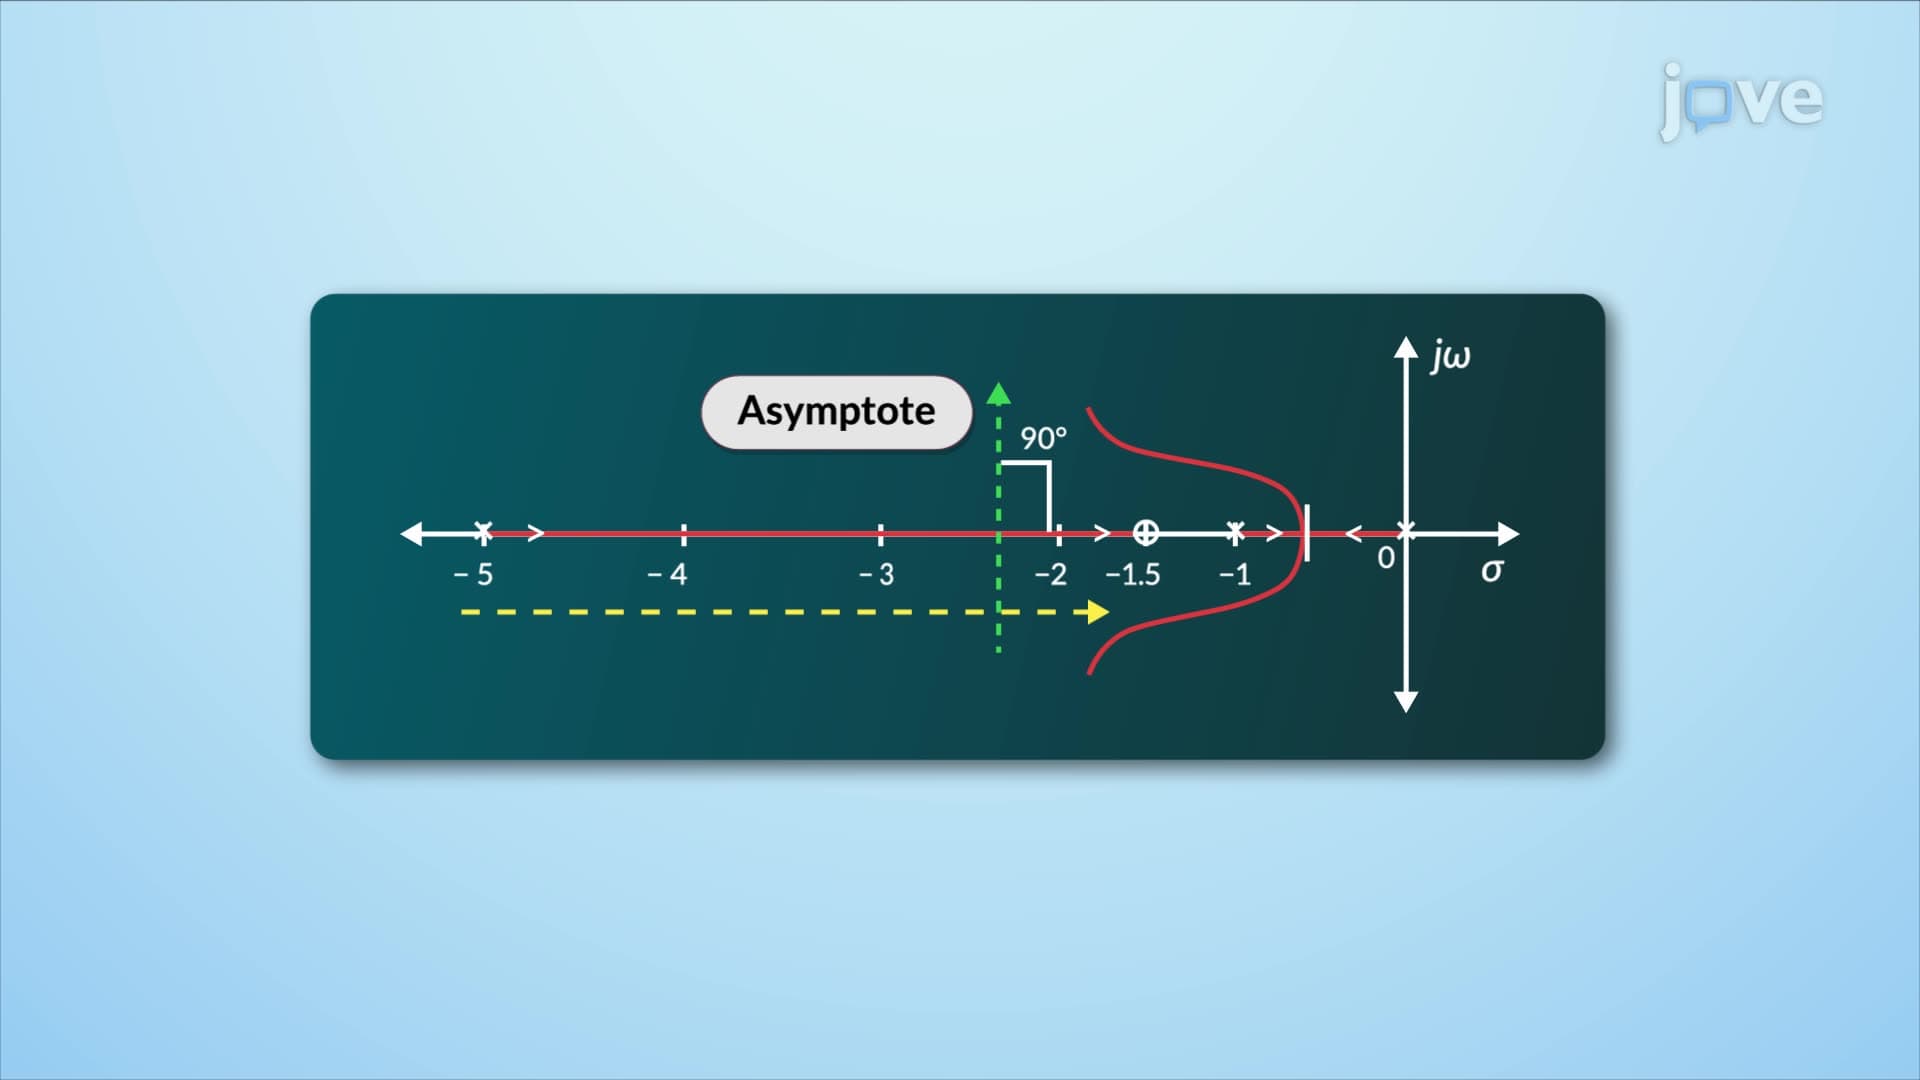
The construction of a root locus involves several key steps to analyze and visualize the behavior of a system's poles with varying gain. The number of branches in the root locus equals the number of closed-loop poles and is symmetrical about the real axis.
For positive gain values, the root locus exists on the real axis to the left of an odd number of finite open-loop poles or zeros. The root locus starts at the open-loop poles and traces the paths of the closed-loop poles as the gain...
For positive gain values, the root locus exists on the real axis to the left of an odd number of finite open-loop poles or zeros. The root locus starts at the open-loop poles and traces the paths of the closed-loop poles as the gain...
121
 01:14
Stability of structures
168
In mechanical engineering, the stability of systems under various forces is critical for designing durable and efficient structures. One fundamental way to explore these concepts is by analyzing systems like two rods connected at a pivot point, O, with a torsional spring of spring constant k at the pivot point. This system is similar in appearance to a scissor jack used to change tires on a car. In this case, the arms of the linkage (equivalent to the rods in this system) are entirely vertical,...
168
 01:23
Root Loci for Positive-Feedback Systems
122
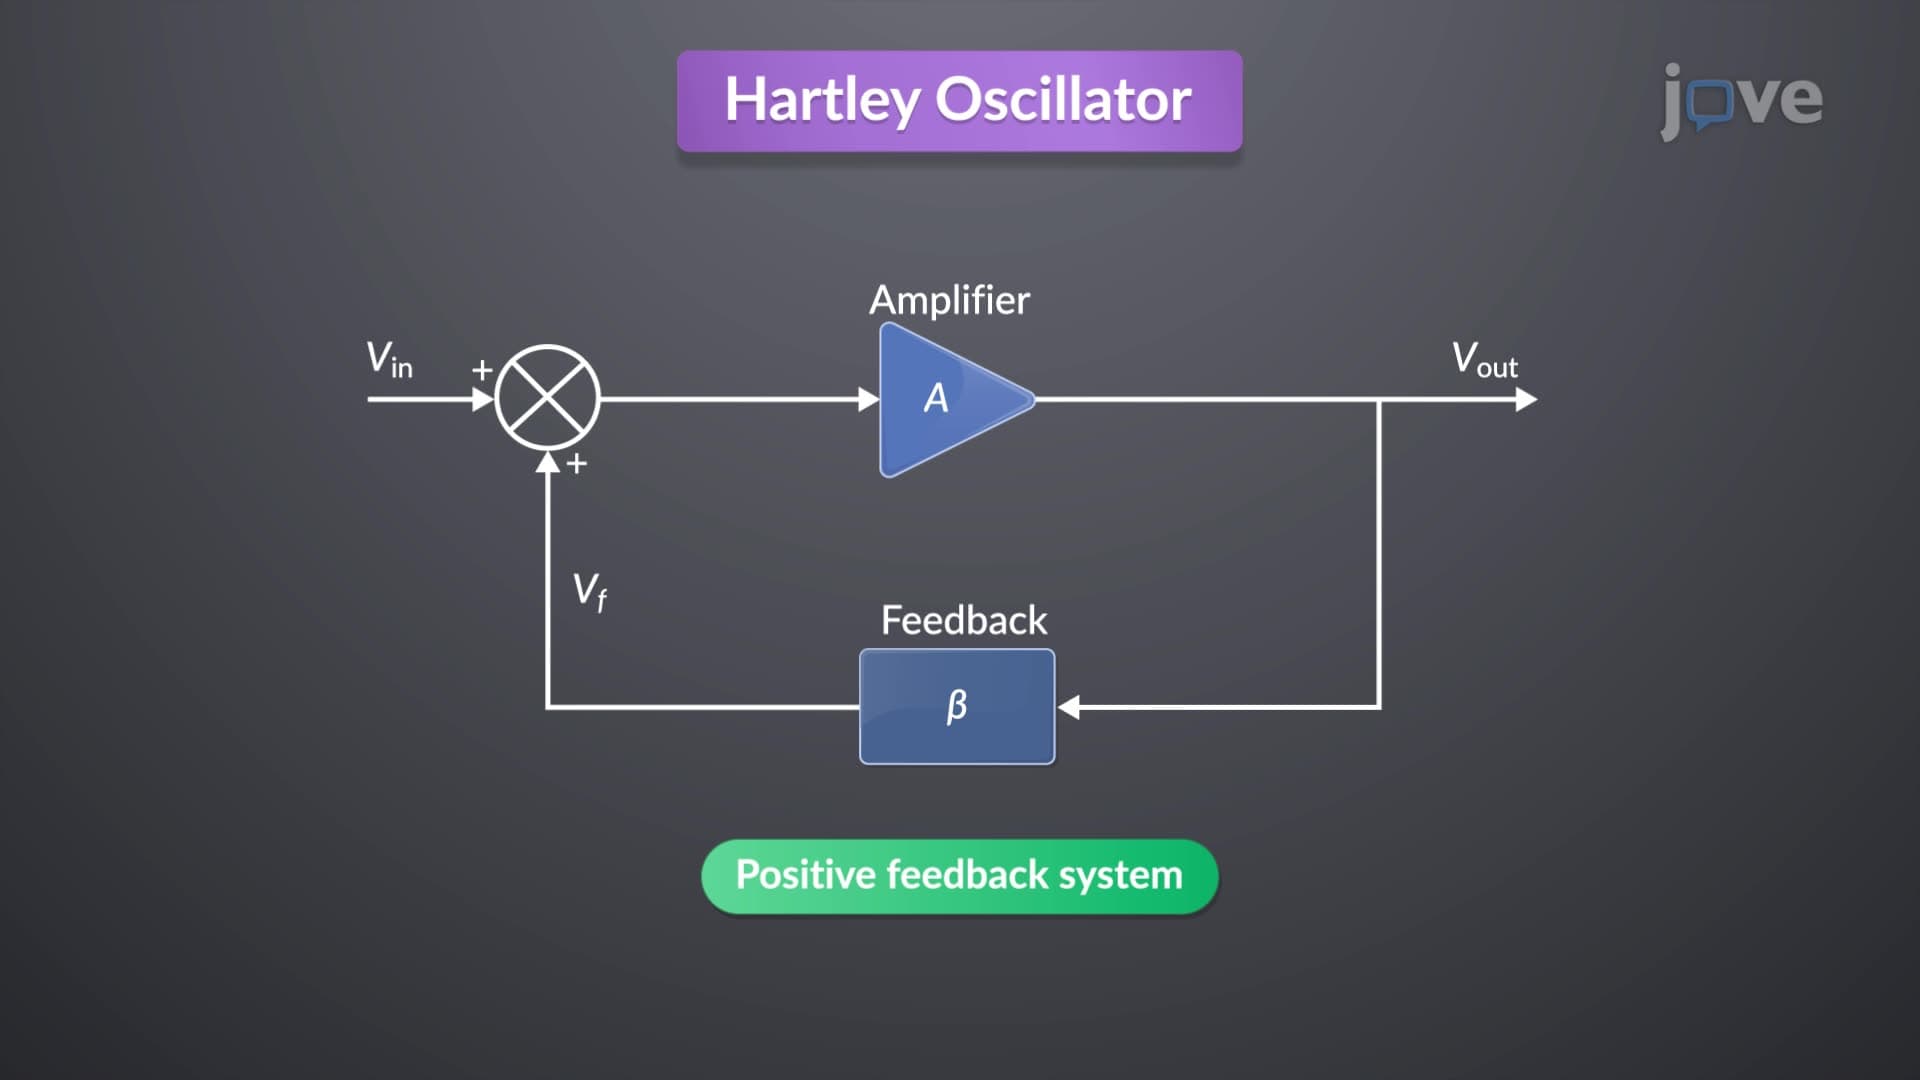
The Hartley oscillator is a positive feedback system that sustains oscillations by feeding the output back to the input in phase, thereby reinforcing the signal. Positive feedback systems can be viewed as negative feedback systems with inverted feedback signals. In these systems, the root locus encompasses all points on the s-plane where the angle of the system transfer function equals 360 degrees.
The construction rules for the root locus in positive feedback systems are similar to those in...
The construction rules for the root locus in positive feedback systems are similar to those in...
122
 01:24
Pole and System Stability
298
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
298
 01:23
Stability of Equilibrium Configuration
448
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
448