

概括
这项研究引入了一种用于实时幽灵成像的新算法,使可调节的率和移动物体的增强视频质量成为可能. 该方法克服了DMD刷新率的限制,提高了视觉舒适性和光滑性.
科学领域:
- 计算机成像成像技术
- 数字信号处理是数字信号处理.
- 光学和光子学 在光学和光子学.
背景情况:
- 实时幽灵成像面临着固定率和不均速的挑战,特别是对于移动的物体.
- 现有的方法受到显示器更新速率的限制,影响视频流性和用户舒适性.
- 改善空间信息和时间动态对于舒适,高质量的幽灵成像至关重要.
研究的目的:
- 开发一个实时时空算法用于幽灵成像,可调节的率和质量.
- 解决固定速率和DMD刷新速率在移动物体幽灵成像中的局限性.
- 为了增强幽灵成像视频的视觉舒适性和光滑性.
主要方法:
- 利用多维向量矩阵沃尔什转换用于图像重建.
- 采用时间和空间的相关性,以免费和可调节的视频率.
- 应用空间插值来增强图像的细节性和光滑性.
- 开发了适应性无参数评估算法 (APEA和APVCEA),用于客观和主观的视频质量评估.
主要成果:
- 实现了独立于DMD刷新率的可调节率.
- 演示了改进的幽灵成像视频流性和视觉舒适度.
- 客观上增加了12%的峰值信号噪声比 (PSNR).
- 主观地提高了13%的结构保留,并减少了70%的Brisque.
- 与传统方法相比,主观视频舒适度提高了14%.
结论:
- 拟议的算法有效地克服了实时幽灵成像中的DMD刷新率限制.
- 该方法显著提高了幽灵成像视频质量,流性和用户舒适度.
- 开发的评估算法为图像和视频质量评估提供了可靠的措施.
相关概念视频
 01:06
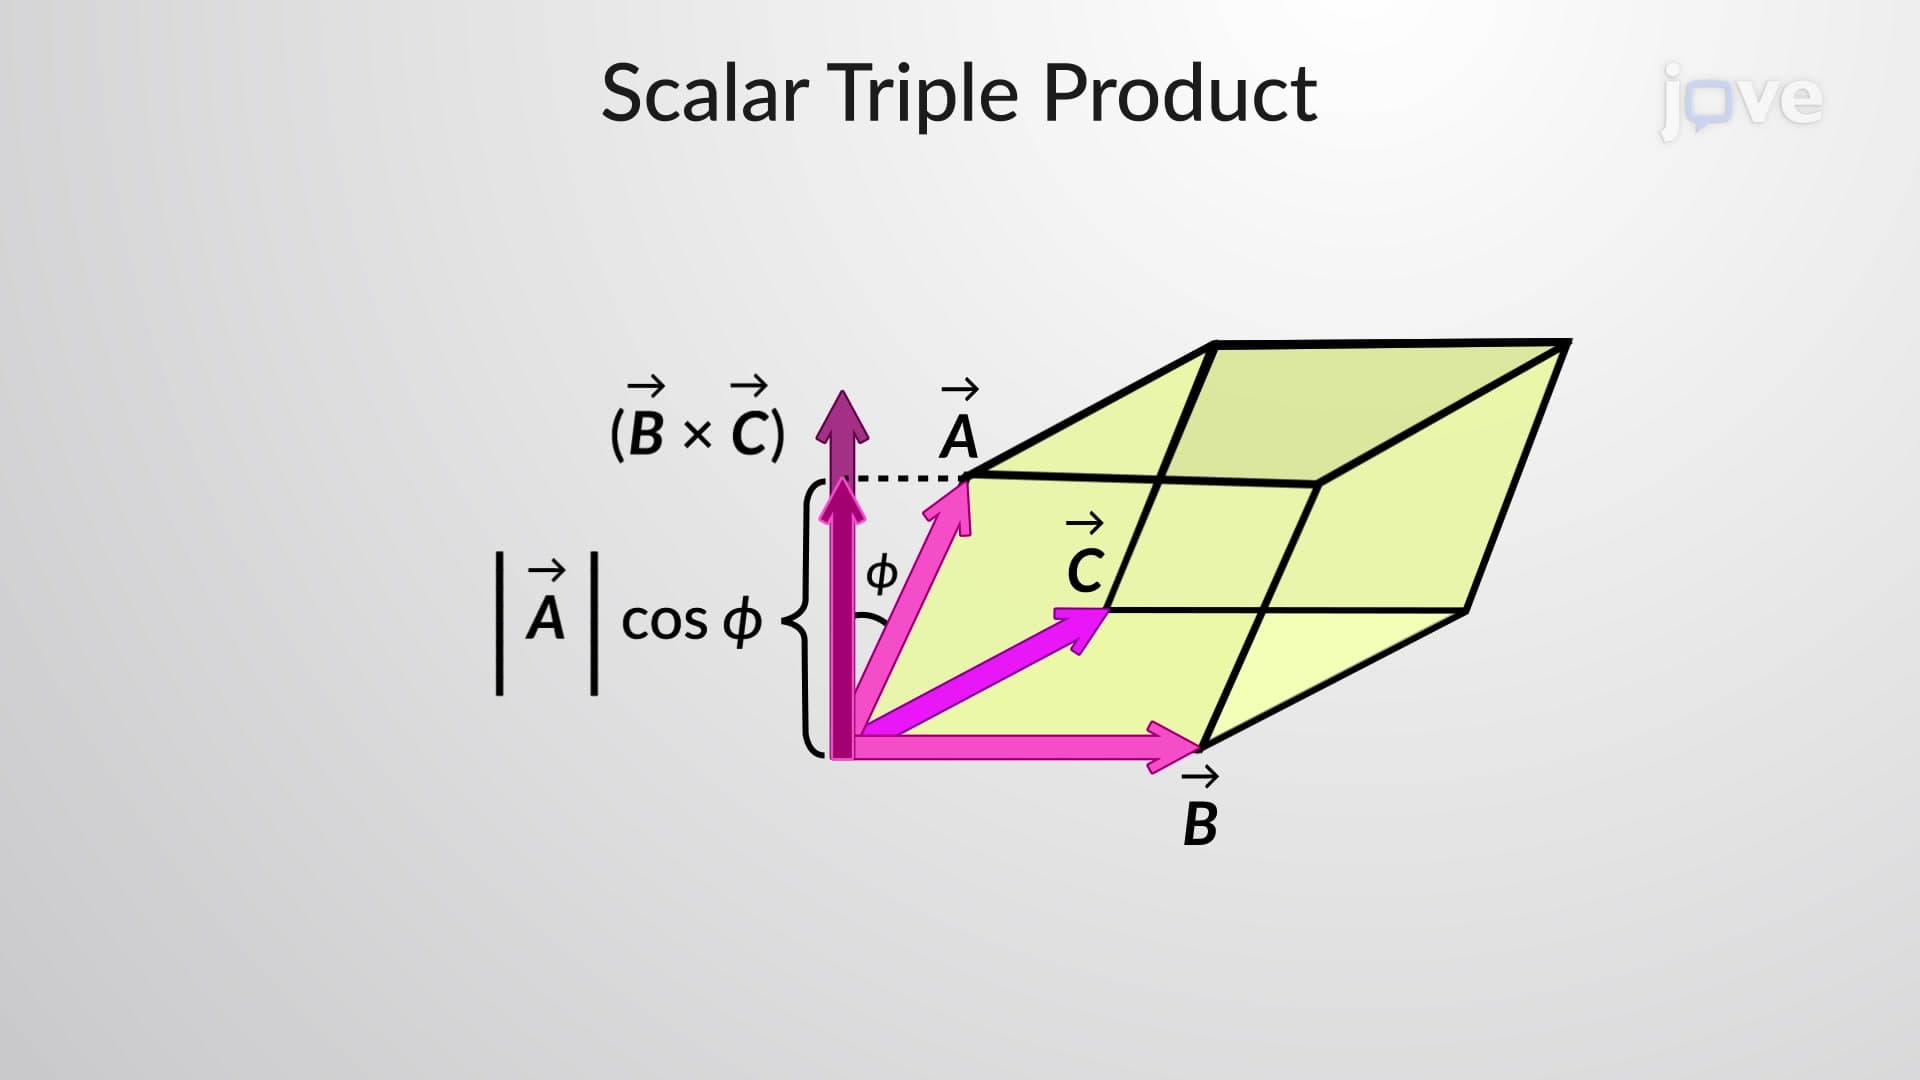
Scalar and Vector Triple Products
Two vectors can be multiplied using a scalar product or a vector product. The resultant of a scalar product is scalar, while with vector products, the resultant is a vector. These rules of the scalar or vector product between two vectors can be applied to multiple vectors to obtain meaningful combinations. The scalar triple product is the dot product of a vector with the cross product of two vectors.
The scalar triple product is the dot product of a vector with the cross product of two vectors.
The scalar triple product is the dot product of a vector with the cross product of two vectors.
 01:16
Vector Transformation in Rotating Coordinate Systems
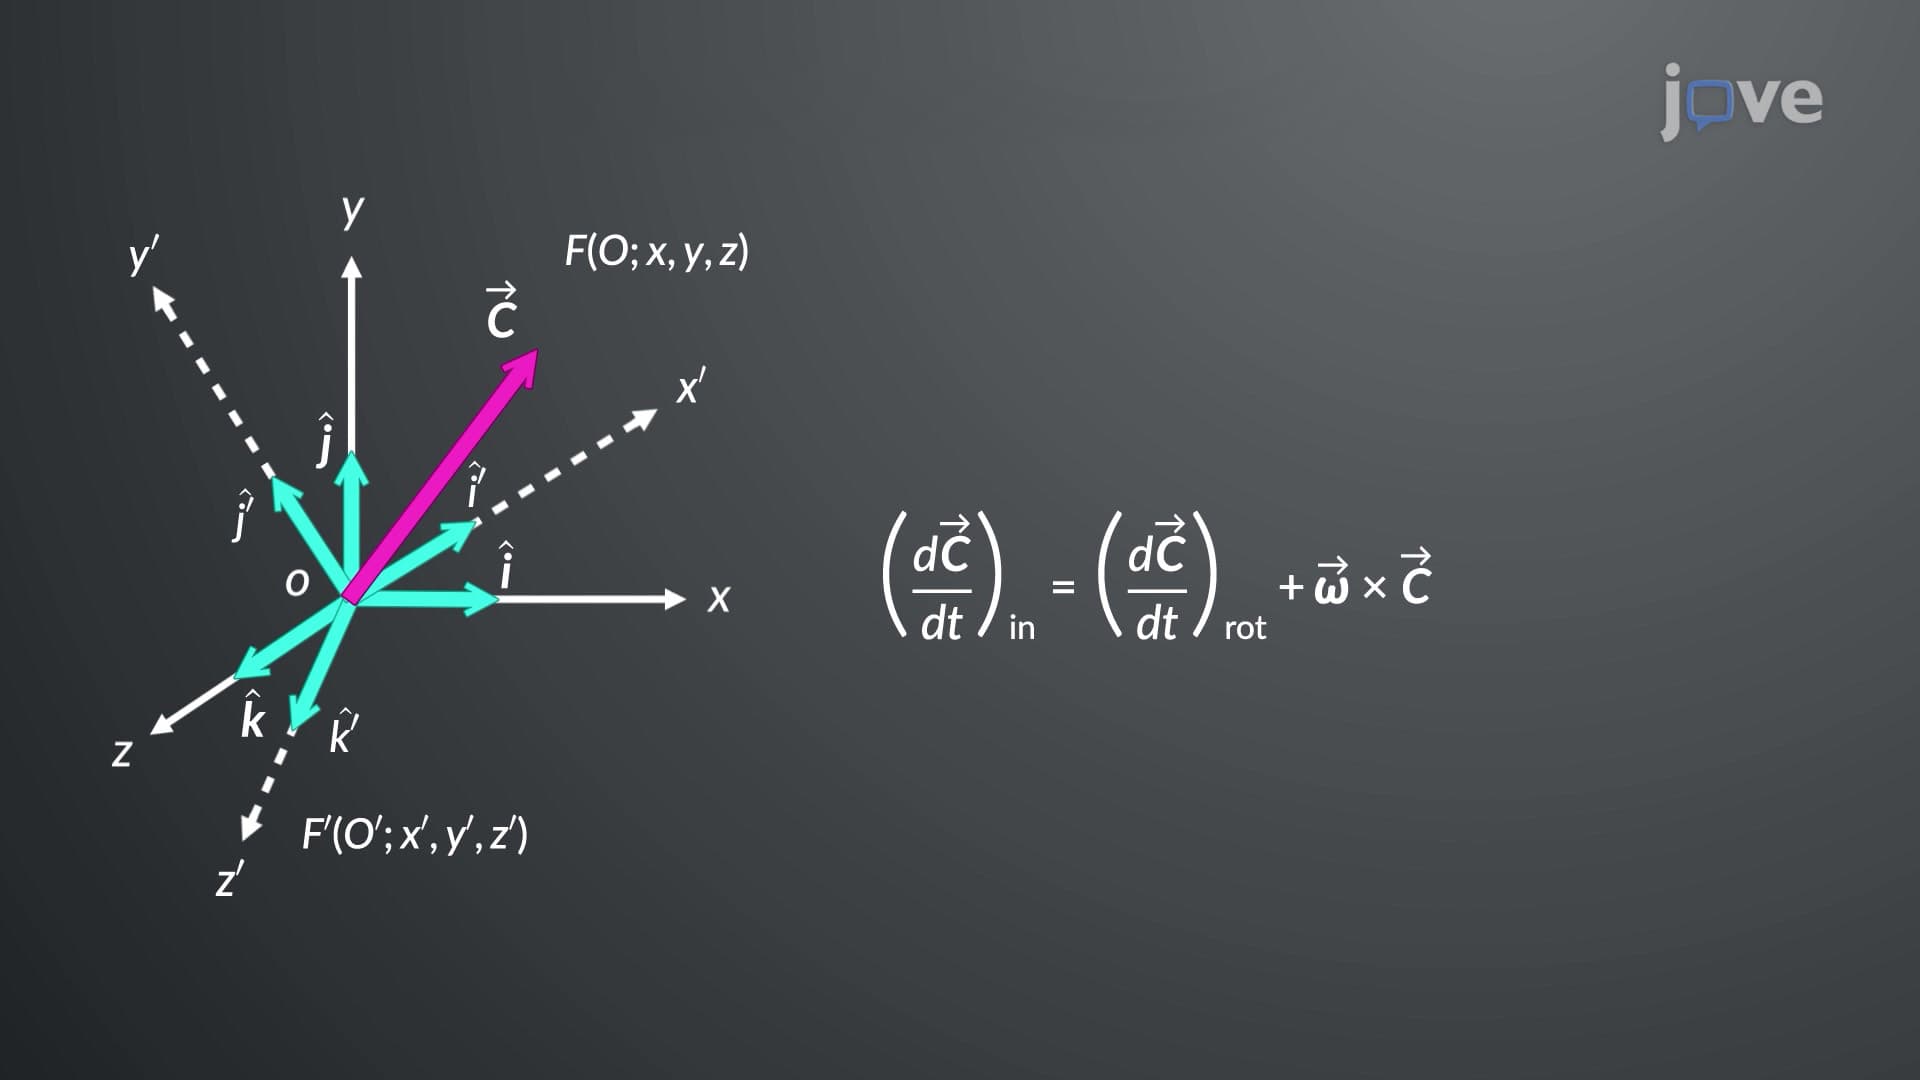
Consider a vector rotating about an axis with an angular velocity, such that its tip sweeps a circular path.
 01:25
Relative Motion Analysis using Rotating Axes
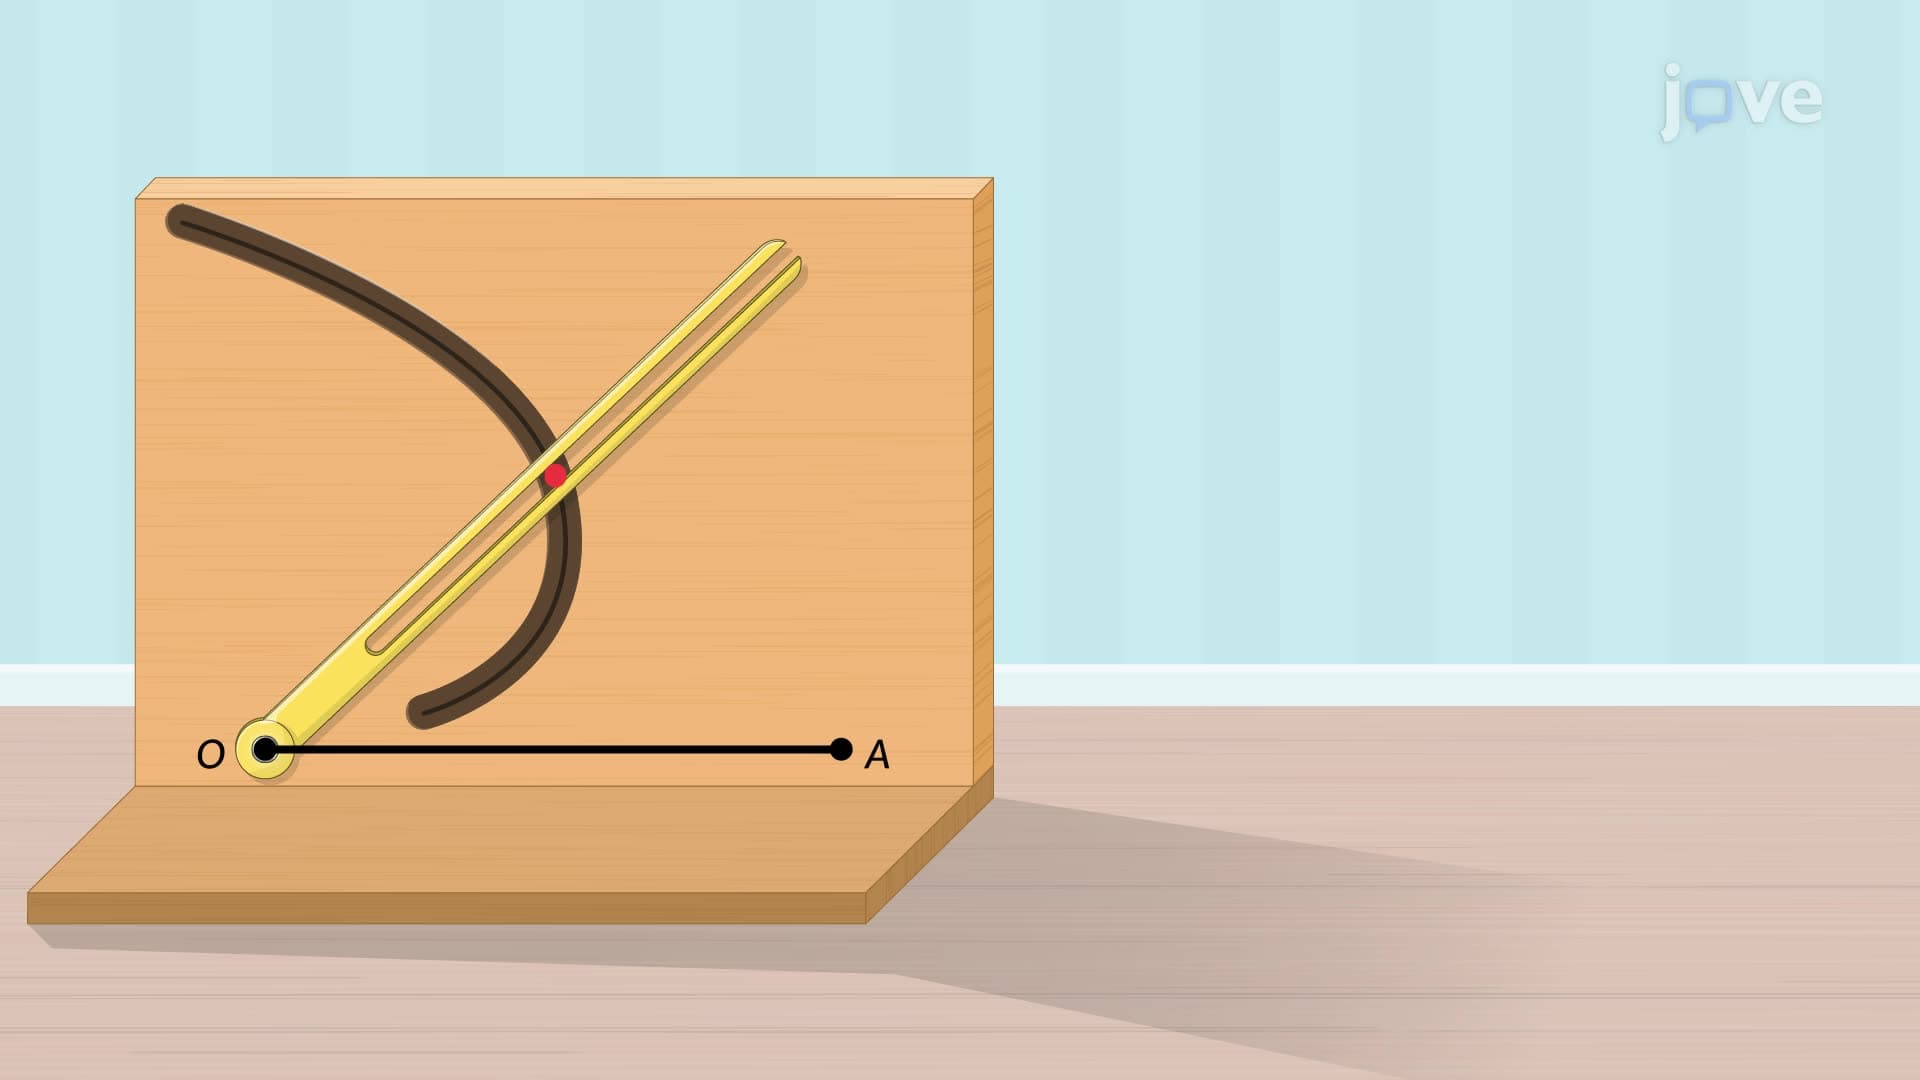
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:27
Curvilinear Motion: Polar Coordinates
In polar coordinates, the motion of a particle follows a curvilinear path. The radial coordinate symbolized as 'r,' extends outward from a fixed origin to the particle, while the angular coordinate, 'θ,' measured in radians, represents the counterclockwise angle between a fixed reference line and the radial line connecting the origin to the particle.
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
 01:16
Vector Representation of Complex Numbers
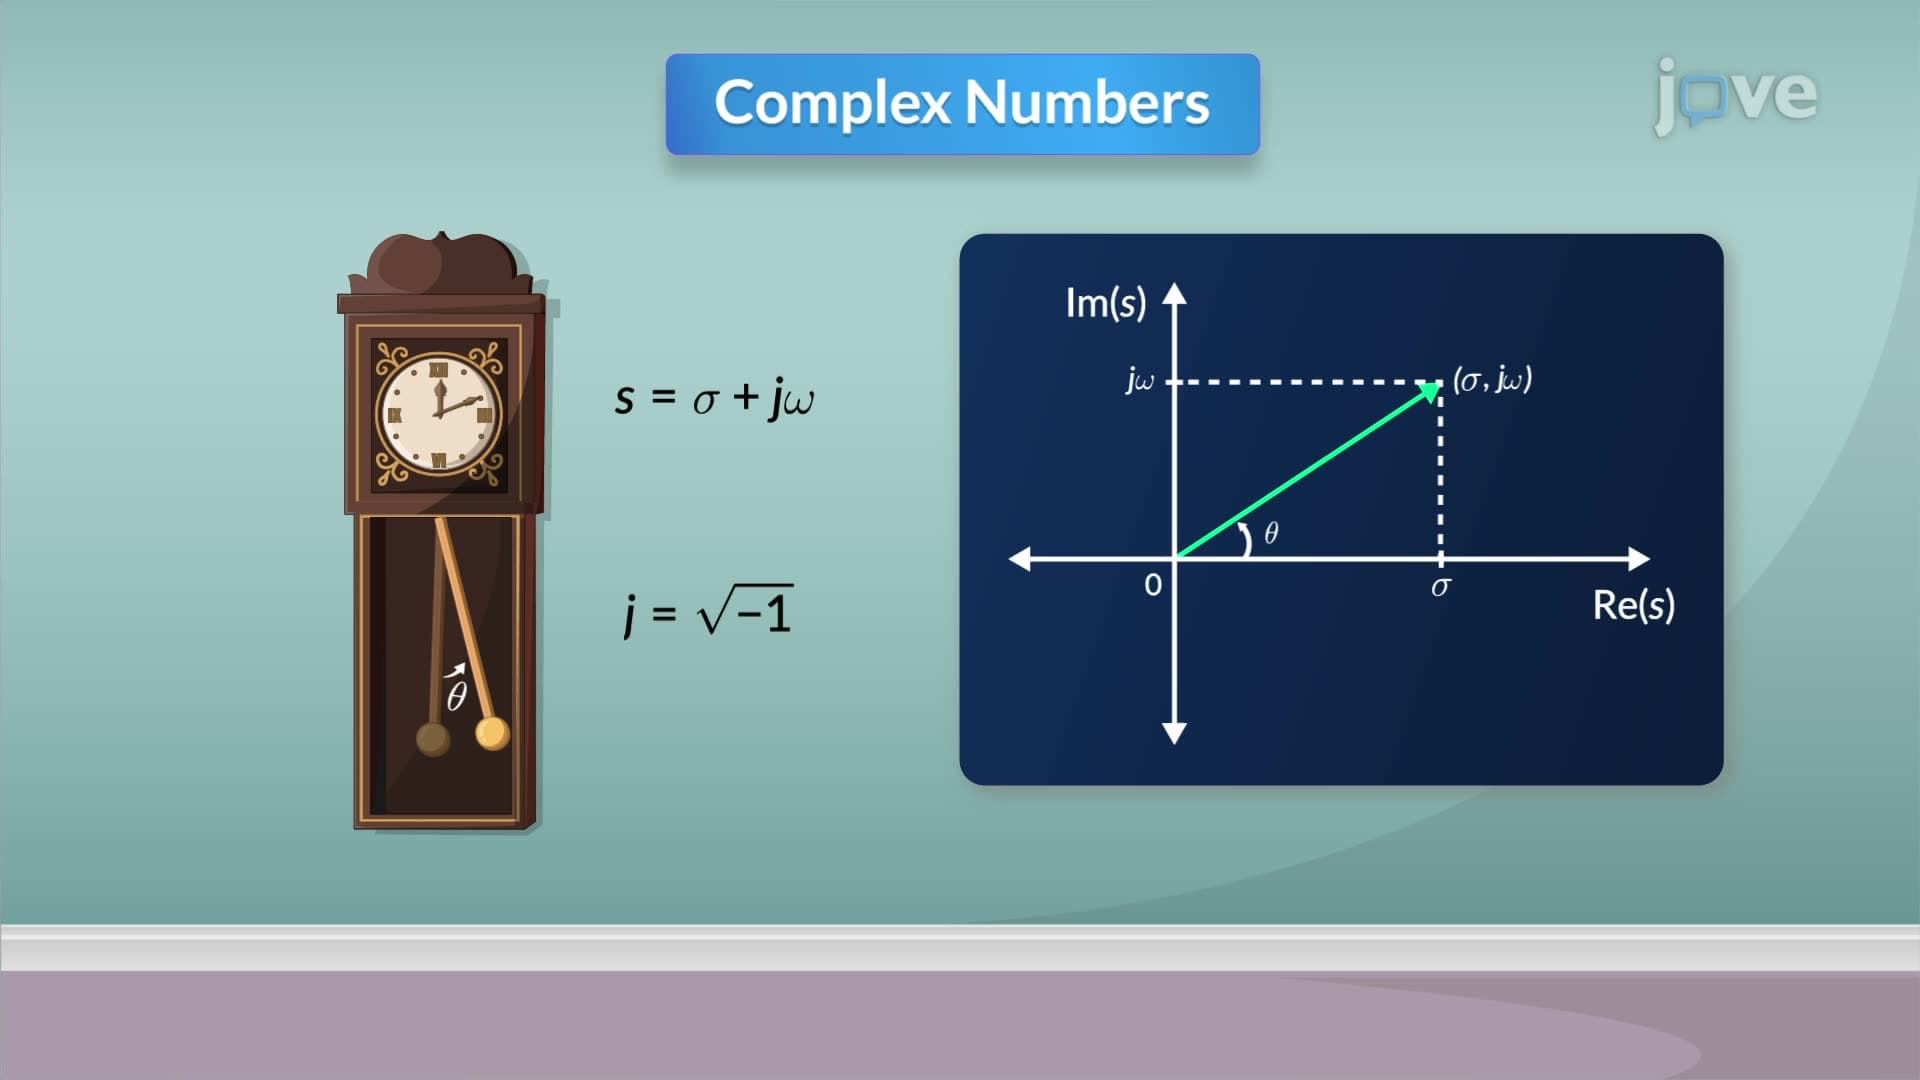
Complex numbers, represented in Cartesian coordinates, can also be visualized as vectors. These vectors can be expressed in polar form, emphasizing their magnitude and angle. When a complex number is input into a function, the output is another complex number, highlighting the function's zero point from which the vector representation can originate.
Consider a function defined as the product of the complex factors in the numerator divided by the product of the complex factors in the denominator.
Consider a function defined as the product of the complex factors in the numerator divided by the product of the complex factors in the denominator.