

因果解 域名 时间序列信号故障诊断的泛化
Linshan Jia1, Tommy W S Chow1, Yixuan Yuan2
1Department of Electrical Engineering, City University of Hong Kong, 999077, Hong Kong Special Administrative Region of China.

概括
本研究介绍了因果解域泛化 (CDDG) 用于在没有目标域数据的情况下进行故障诊断. 在时间序列数据中,CDDG有效地将因果因素和域因素分开,改善了跨不同条件的概括性.
科学领域:
- 机器学习 机器学习
- 人工智能的人工智能
- 信号处理 信号处理
背景情况:
- 基于域泛化的故障诊断 (DGFD) 旨在识别无法访问目标域数据的故障.
- 现有的DGFD方法通常依赖于表面的统计建模,并且仅限于振动数据集.
研究的目的:
- 提出一种新的DGFD方法,即因果解域泛化 (CDDG),可以重新建立数据生成过程.
- 通过在时间序列数据中解脱因果和域特定因素来解决现有方法的局限性.
主要方法:
- CDDG使用结构性因果模型将时间序列数据分解成与故障相关 (因果) 和与域相关 (非因果) 的表示.
- 关键组件包括因果聚合损失,重建损失和冗余减少损失,以实现强大的特征学习.
主要成果:
- 在5个跨机器振动故障诊断案例和3个跨环境声学异常检测案例中,CDDG表现出卓越的性能.
- 该方法在概括能力方面表现优于八种最先进的DGFD方法.
结论:
- 通过使用因果推理,CDDG可以更深入地了解DGFD的数据生成过程.
- 该研究验证了DGFD超越振动数据的广泛适用性,并为未来的研究引入了一个基准.


相关概念视频
 01:18
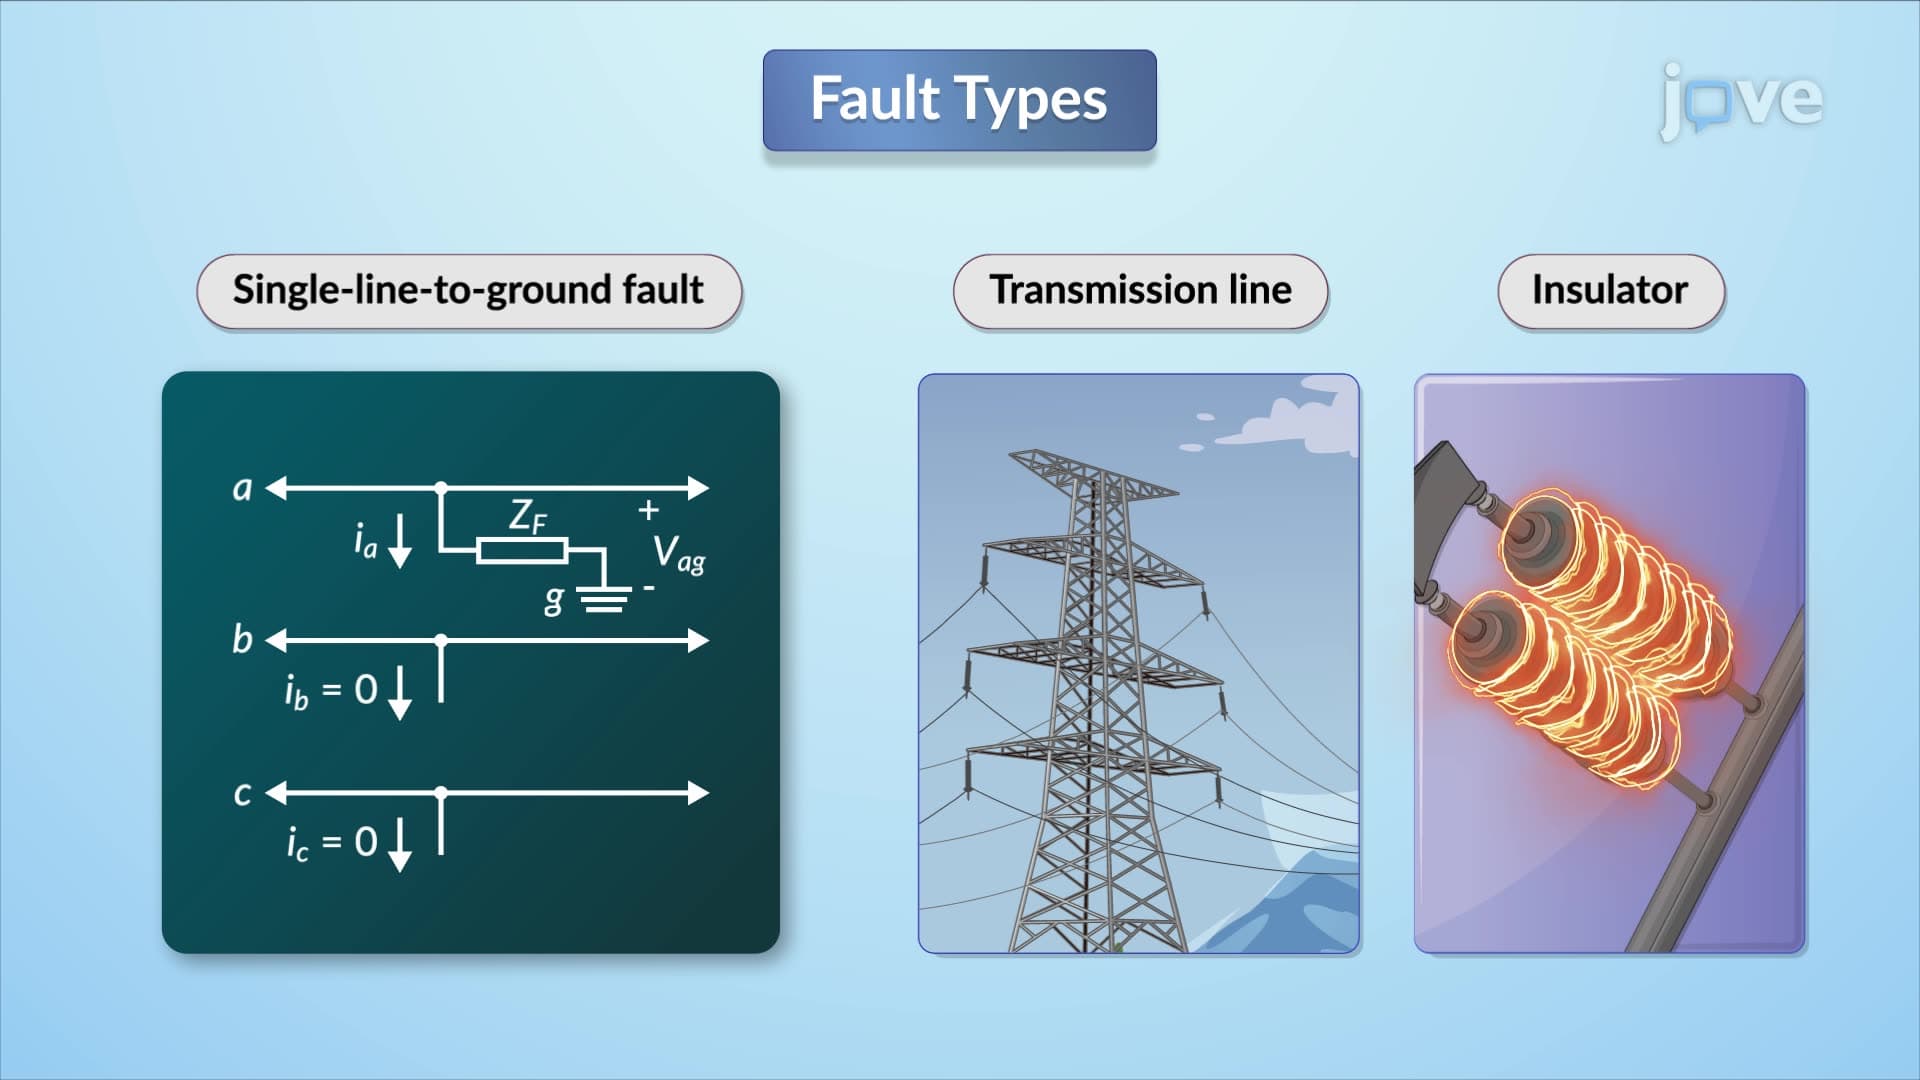
Fault Types
89
When analyzing a single line-to-ground fault from phase A to ground at a three-phase bus, it is important to consider the fault impedance. This impedance is zero for a bolted fault, equal to the arc impedance for an arcing fault, and represents the total fault impedance for a transmission-line insulator flashover. To derive sequence and phase currents, fault conditions are translated from the phase domain to the sequence domain.
For line-to-line faults occurring between phases B and C, the...
For line-to-line faults occurring between phases B and C, the...
89
 01:30
Classification of Signals
466
In signal processing, signals are classified based on various characteristics: continuous-time versus discrete-time, periodic versus aperiodic, analog versus digital, and causal versus noncausal. Each category highlights distinct properties crucial for understanding and manipulating signals.
A continuous-time signal holds a value at every instant in time, representing information seamlessly. In contrast, a discrete-time signal holds values only at specific moments, often denoted as x(n), where...
A continuous-time signal holds a value at every instant in time, representing information seamlessly. In contrast, a discrete-time signal holds values only at specific moments, often denoted as x(n), where...
466
 01:21
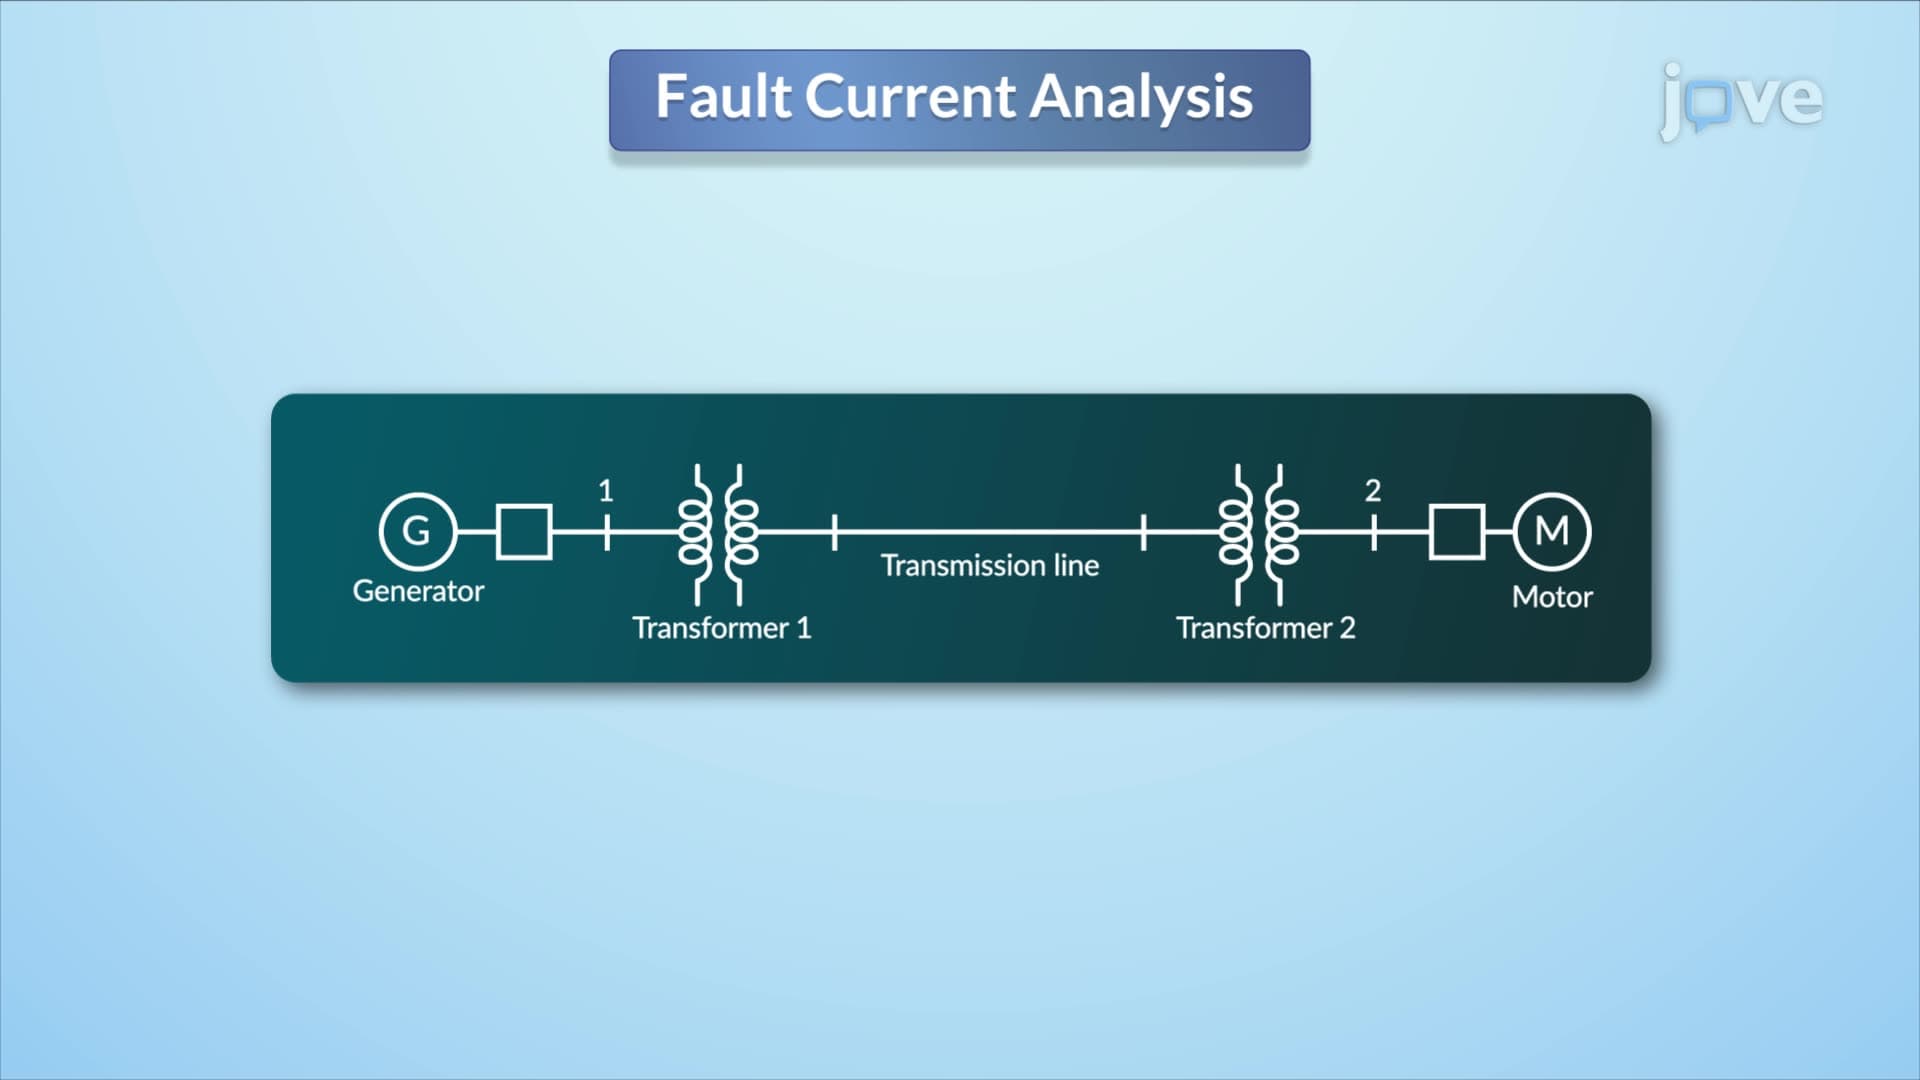
Power System Three-Phase Short Circuits
88
Determining the subtransient fault current in a power system involves representing transformers by their leakage reactances, transmission lines by their equivalent series reactances, and synchronous machines as constant voltage sources behind their subtransient reactances. In this analysis, certain elements are excluded, such as winding resistances, series resistances, shunt admittances, delta-Y phase shifts, armature resistance, saturation, saliency, non-rotating impedance loads, and small...
88
 01:20
Discrete-Time Fourier Series
272
The Discrete-Time Fourier Series (DTFS) is a fundamental concept in signal processing, serving as the discrete-time counterpart to the continuous-time Fourier series. It allows for the representation and analysis of discrete-time periodic signals in terms of their frequency components. Unlike its continuous counterpart, which utilizes integrals, the calculation of DTFS expansion coefficients involves summations due to the discrete nature of the signal.
For a discrete-time periodic signal x[n]...
For a discrete-time periodic signal x[n]...
272
 01:21
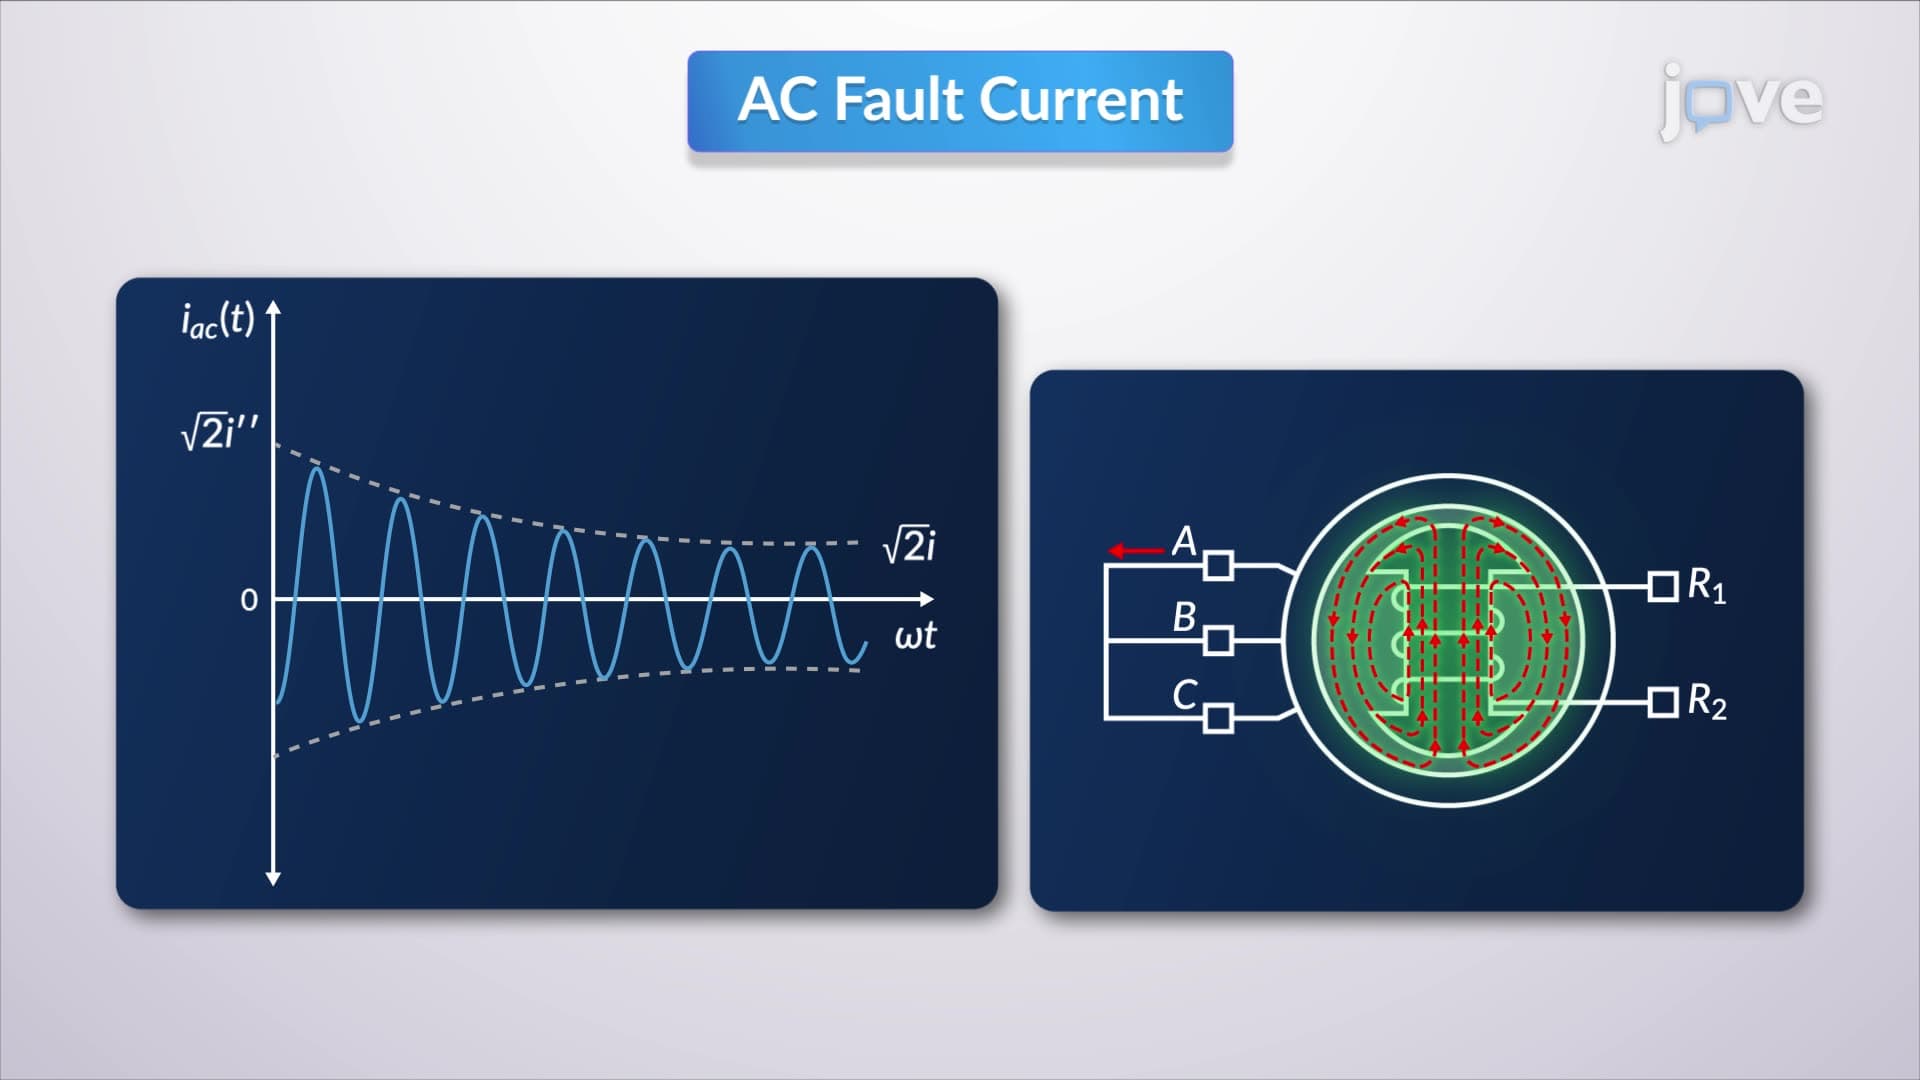
Three-Phase Short Circuit—Unloaded Synchronous Machine
147
Conducting a three-phase short circuit test on an unloaded synchronous machine helps understand its impact on the system. The AC fault current's oscillogram, with the DC offset removed, reveals that the waveform amplitude decreases from an initially high value to a steady-state level for one phase of the machine.
This behavior occurs due to the magnetic flux produced by the short-circuit armature currents. Initially, these currents follow high-reluctance paths but eventually shift to...
This behavior occurs due to the magnetic flux produced by the short-circuit armature currents. Initially, these currents follow high-reluctance paths but eventually shift to...
147
 01:22
Series R—L Circuit Transients
102
In a series resistor-inductor (R-L) circuit, closing the switch at the start of the time period simulates a three-phase short circuit, a fault condition where all three phases of an unloaded synchronous machine are short-circuited. When there is no fault impedance and no initial current, the initial voltage is determined by the phase angle of the source voltage.
Using Kirchhoff's Voltage Law (KVL) to analyze this circuit helps determine the total asymmetrical fault current, which consists...
Using Kirchhoff's Voltage Law (KVL) to analyze this circuit helps determine the total asymmetrical fault current, which consists...
102