
一个随机近似-Langevinized Ensemble Kalman过算法,用于状态空间模型的未知参数
Tianning Dong1, Peiyi Zhang1, Faming Liang1
1Department of Statistics, Purdue University, West Lafayette, IN.
Journal of computational and graphical statistics : a joint publication of American Statistical Association, Institute of Mathematical Statistics, Interface Foundation of North America
|January 19, 2024

概括
这项研究引入了一种新方法,即对具有未知参数的动态系统的随机近似-Langevinized合体卡尔曼波器 (SA-LEnKF). 它准确地估计复杂,大规模,长串数据中的状态和参数,超过现有算法.
科学领域:
- 数据科学数据科学数据科学
- 统计推理 统计推理
- 动态系统 动态系统
背景情况:
- 对高维,大规模和长序列动态系统的推理提出了重大挑战.
- 像粒子过器和顺序重要性采样器这样的现有方法与可扩展性和样本退化性作斗争.
- 朗格维纳集成卡尔曼波器 (LEnKF) 提高了可扩展性,但无法处理未知的系统参数.
研究的目的:
- 开发一种新的算法,用于联合估计动态系统中的状态和未知参数.
- 解决处理复杂,高维和长序列数据的现有方法的局限性.
- 为了使具有挑战性的动态系统的不确定性量化.
主要方法:
- 建议使用随机近似-Langevinized 整体卡尔曼波器 (SA-LEnKF).
- 集成状态估计 (通过LEnKF) 与参数估计使用随机近似马尔科夫链蒙特卡洛 (MCMC).
- 采用SA-LEnKF用于使用长短期内存 (LSTM) 网络进行状态空间建模.
主要成果:
- 在温和条件下的状态变量模拟中显示参数估计和ergodicity的一致性.
- 数值结果显示出对复杂动态系统的现有算法的优越性.
- 在海洋表面温度数据的状态空间建模中成功应用.
结论:
- 在高维,大规模,长序列的动态系统中,SA-LEnKF有效地处理联合状态和参数估计.
- 该算法为复杂数据中的不确定性量化提供了强大的解决方案.
- 显示了现代数据科学应用中的统计分析的巨大潜力.
相关概念视频
 01:21
Linear Approximation in Time Domain
83
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
83
 01:27
State Space Representation
209
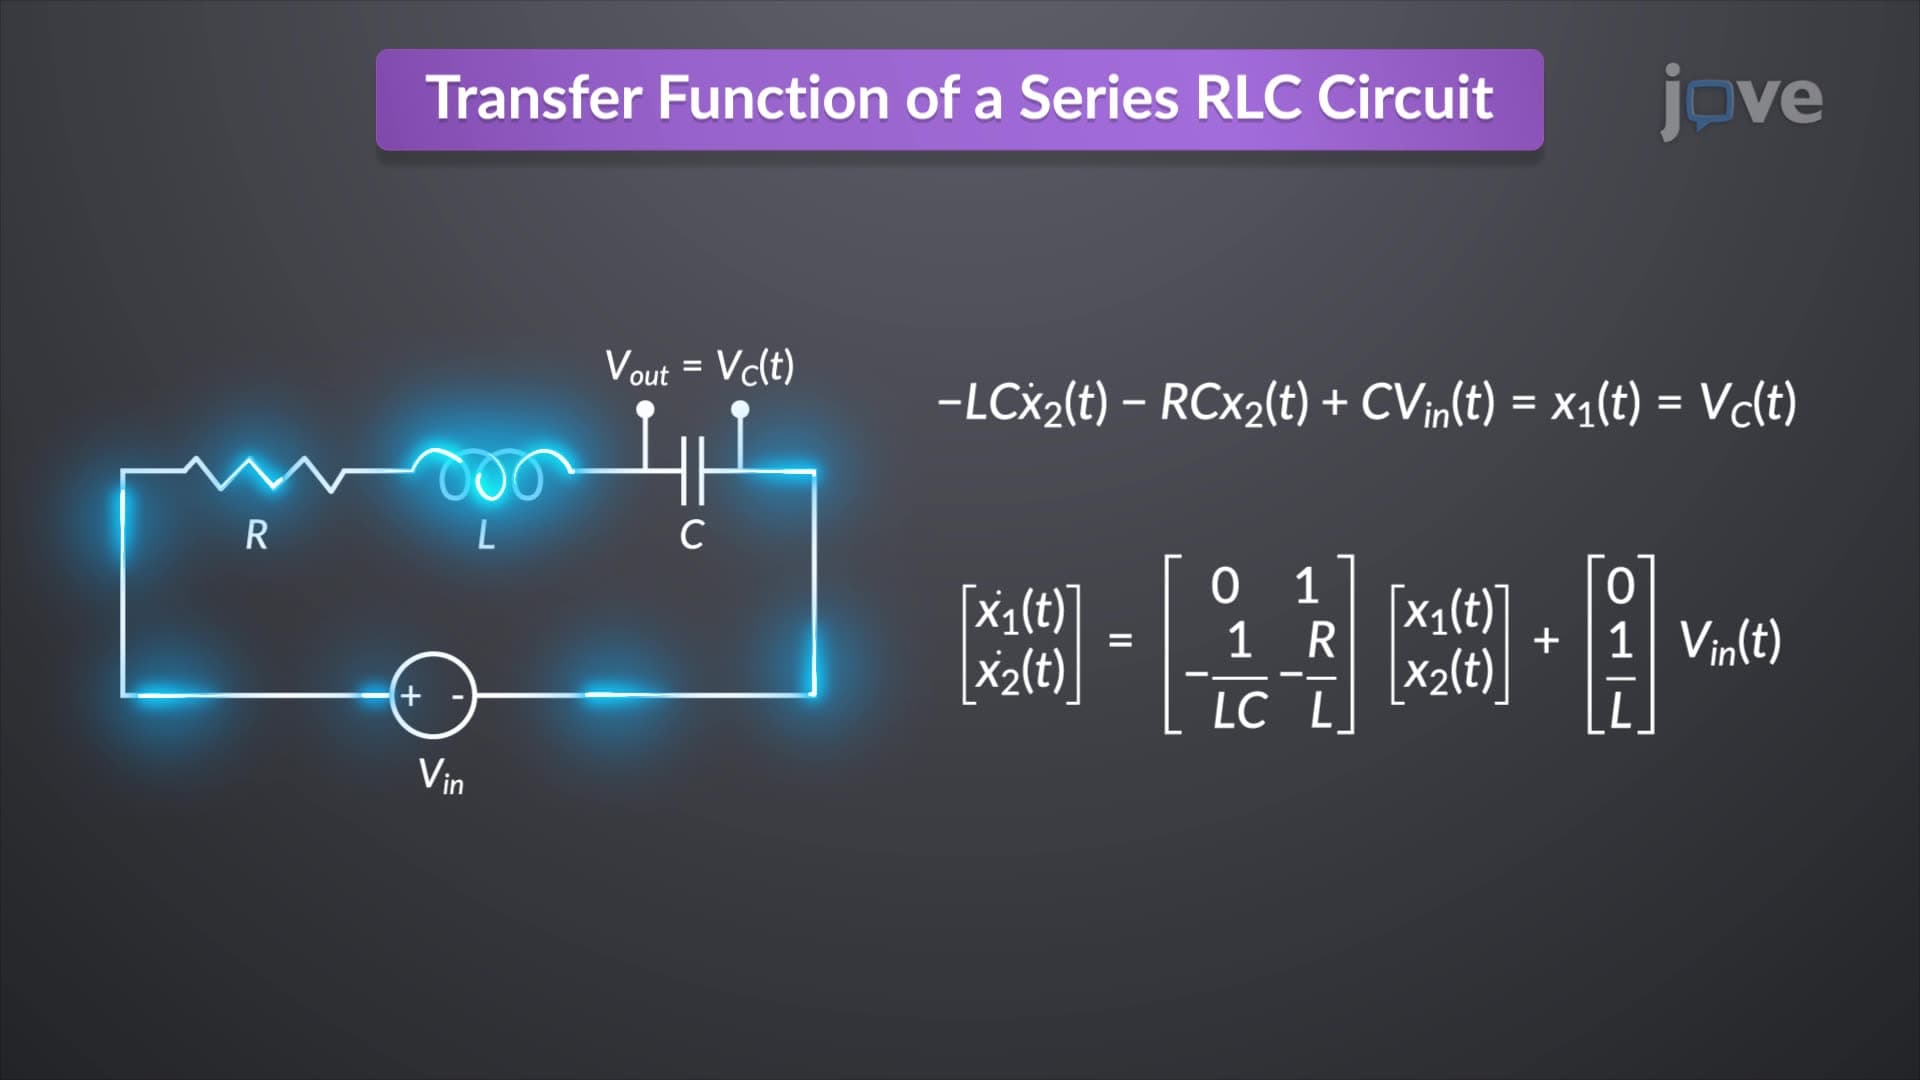
The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Consider an RLC circuit, a...
209
 01:23
Transfer Function to State Space
260
State-space representation is a powerful tool for simulating physical systems on digital computers, necessitating the conversion of the transfer function into state-space form. Consider an nth-order linear differential equation with constant coefficients, like those encountered in an RLC circuit. The state variables are selected as the output and its n−1 derivatives. Differentiating these variables and substituting them back into the original equation produces the state equations.
In an...
In an...
260
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
56
Mechanistic models play a crucial role in algorithms for numerical problem-solving, particularly in nonlinear mixed effects modeling (NMEM). These models aim to minimize specific objective functions by evaluating various parameter estimates, leading to the development of systematic algorithms. In some cases, linearization techniques approximate the model using linear equations.
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
56
 01:21
State Space to Transfer Function
208
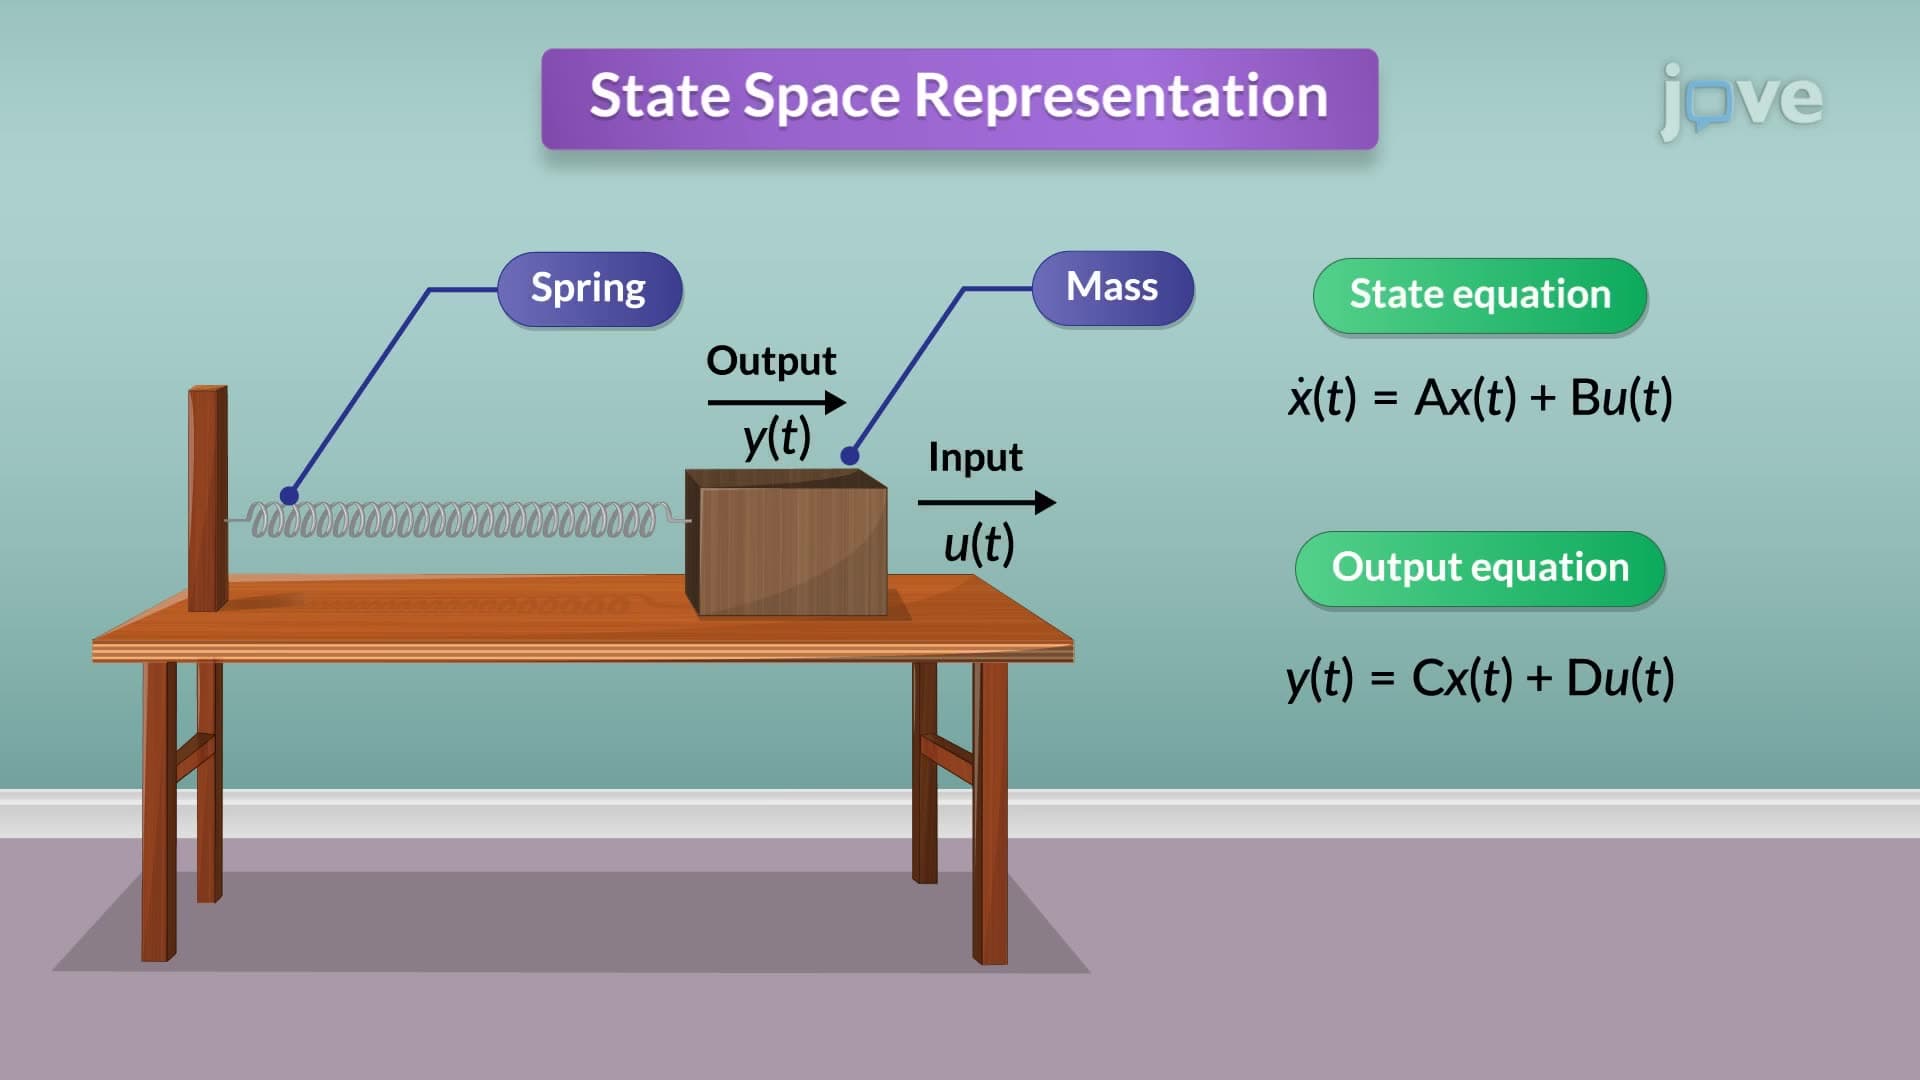
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
208
 01:26
Linear Approximation in Frequency Domain
91
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
91