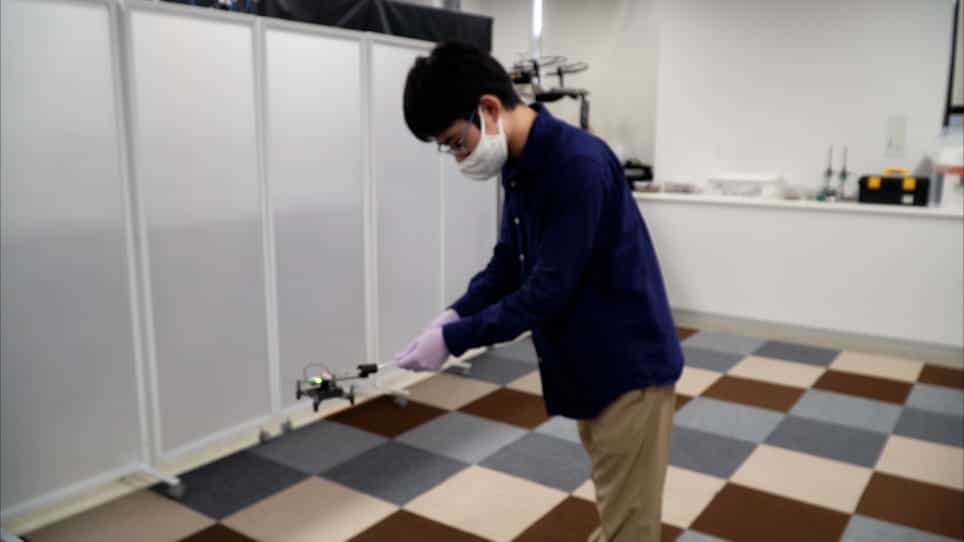
一个基于角加速的浮动探测器,用于移动无人机
Jiannan Zhao1, Quansheng Xie1, Feng Shuang1
1Guangxi Key Laboratory of Intelligent Control and Maintenance of Power Equipment, School of Electrical Engineering, Guangxi University, Nanning 530004, China.
Biomimetics (Basel, Switzerland)
|January 22, 2024

概括
一个新的A-LGMD模型使用图像角加速,以在无人机 (UAV) 中更快,更准确地检测迫在眉的物体. 这种方法通过减少虚假警报和预警延迟,改善了避开障碍的方法,这对于快速的无人机移动至关重要.
科学领域:
- 计算机视觉 计算机视觉
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
背景情况:
- 无人机依靠视觉感知来避开障碍物.
- 快速的无人机移动挑战了当前的算法,导致错误报警和延迟警告,因为难以提取碰撞特征.
- 现有的方法在精确的特征提取和动态环境的时间序列建模方面扎.
研究的目的:
- 开发一种新型模型,用于在无人机中准确和快速检测迫在眉的物体.
- 解决当前算法在处理快速自动运动和视野变化的局限性.
- 提高微型和小型无人机中避障系统的可靠性.
主要方法:
- 提出了一种简洁的角球巨型运动探测器 (A-LGMD) 模型,其灵感来源于生物运动探测.
- 该模型利用图像角加速和更高阶的角大小信息来探测迫在眉的物体.
- 集成多个视野角度特征,以提高对背景运动干扰的稳定性.
主要成果:
- 该A-LGMD模型有效地检测图像的角加速,并过背景运动.
- 在合成和现实数据上的实验表明了早期预警能力.
- 该模型显示,与现有方法相比,精度提高,响应延迟减少.
结论:
- A-LGMD模型为无人机嵌入式碰撞检测提供了一个有希望的解决方案.
- 编码更高阶的角大小信息有效地解决了响应延迟问题.
- 该模型集成多种视觉线索的能力提高了其对运动干扰的抵抗力,这对于自主导航至关重要.
相关概念视频
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
338
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
338
 01:24
Absolute Motion Analysis- General Plane Motion
222
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
222
 01:10
Relative Motion Analysis - Acceleration
360
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
360
 01:25
Relative Motion Analysis using Rotating Axes
464
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
464
 01:16
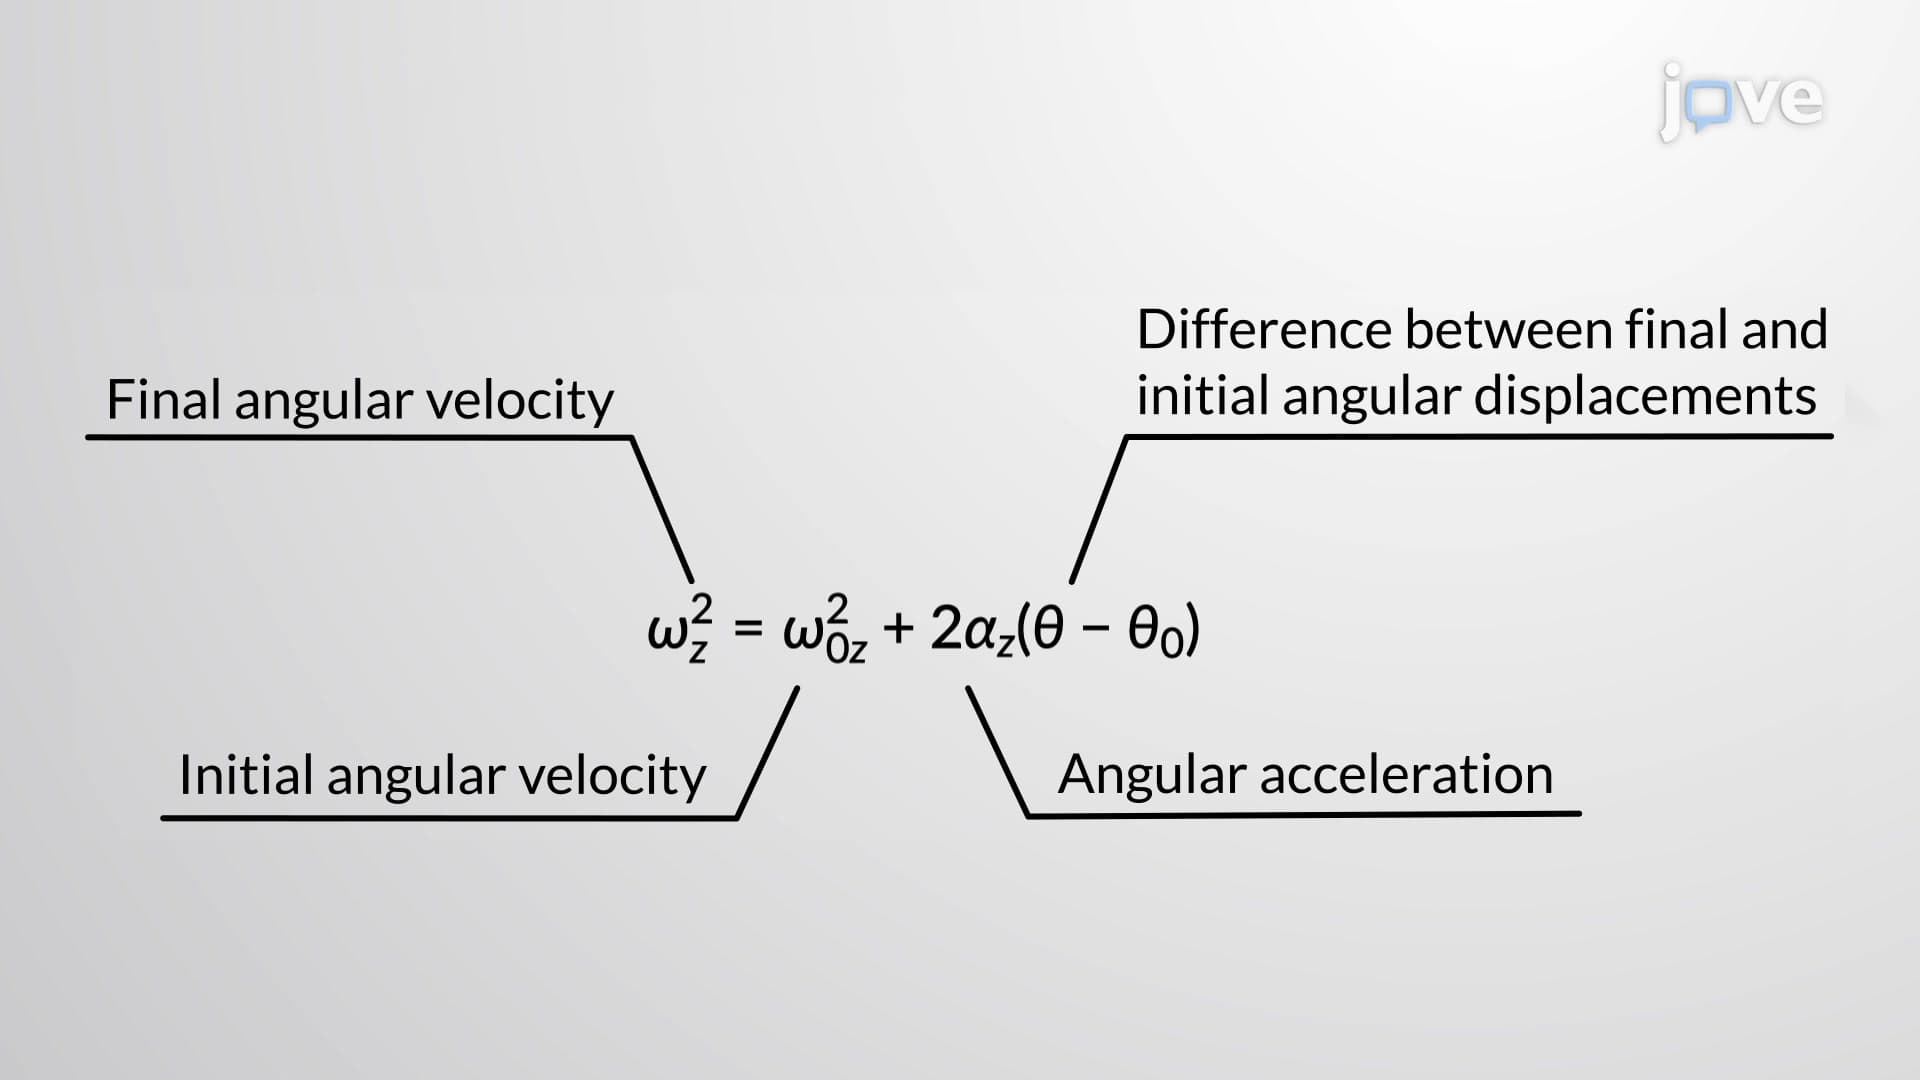
Rotation with Constant Angular Acceleration - II
6.0K
Kinematics is the description of motion. The kinematics of rotational motion discusses the relationships between rotation angle, angular velocity, angular acceleration, and time. One can describe many things with great precision using kinematics, but kinematics does not consider causes. For example, a large angular acceleration describes a very rapid change in angular velocity without any consideration of its cause. Thus, rotational kinematics does not represent the laws of nature.
The first...
The first...
6.0K
 01:37
Rotation with Constant Angular Acceleration - I
6.8K
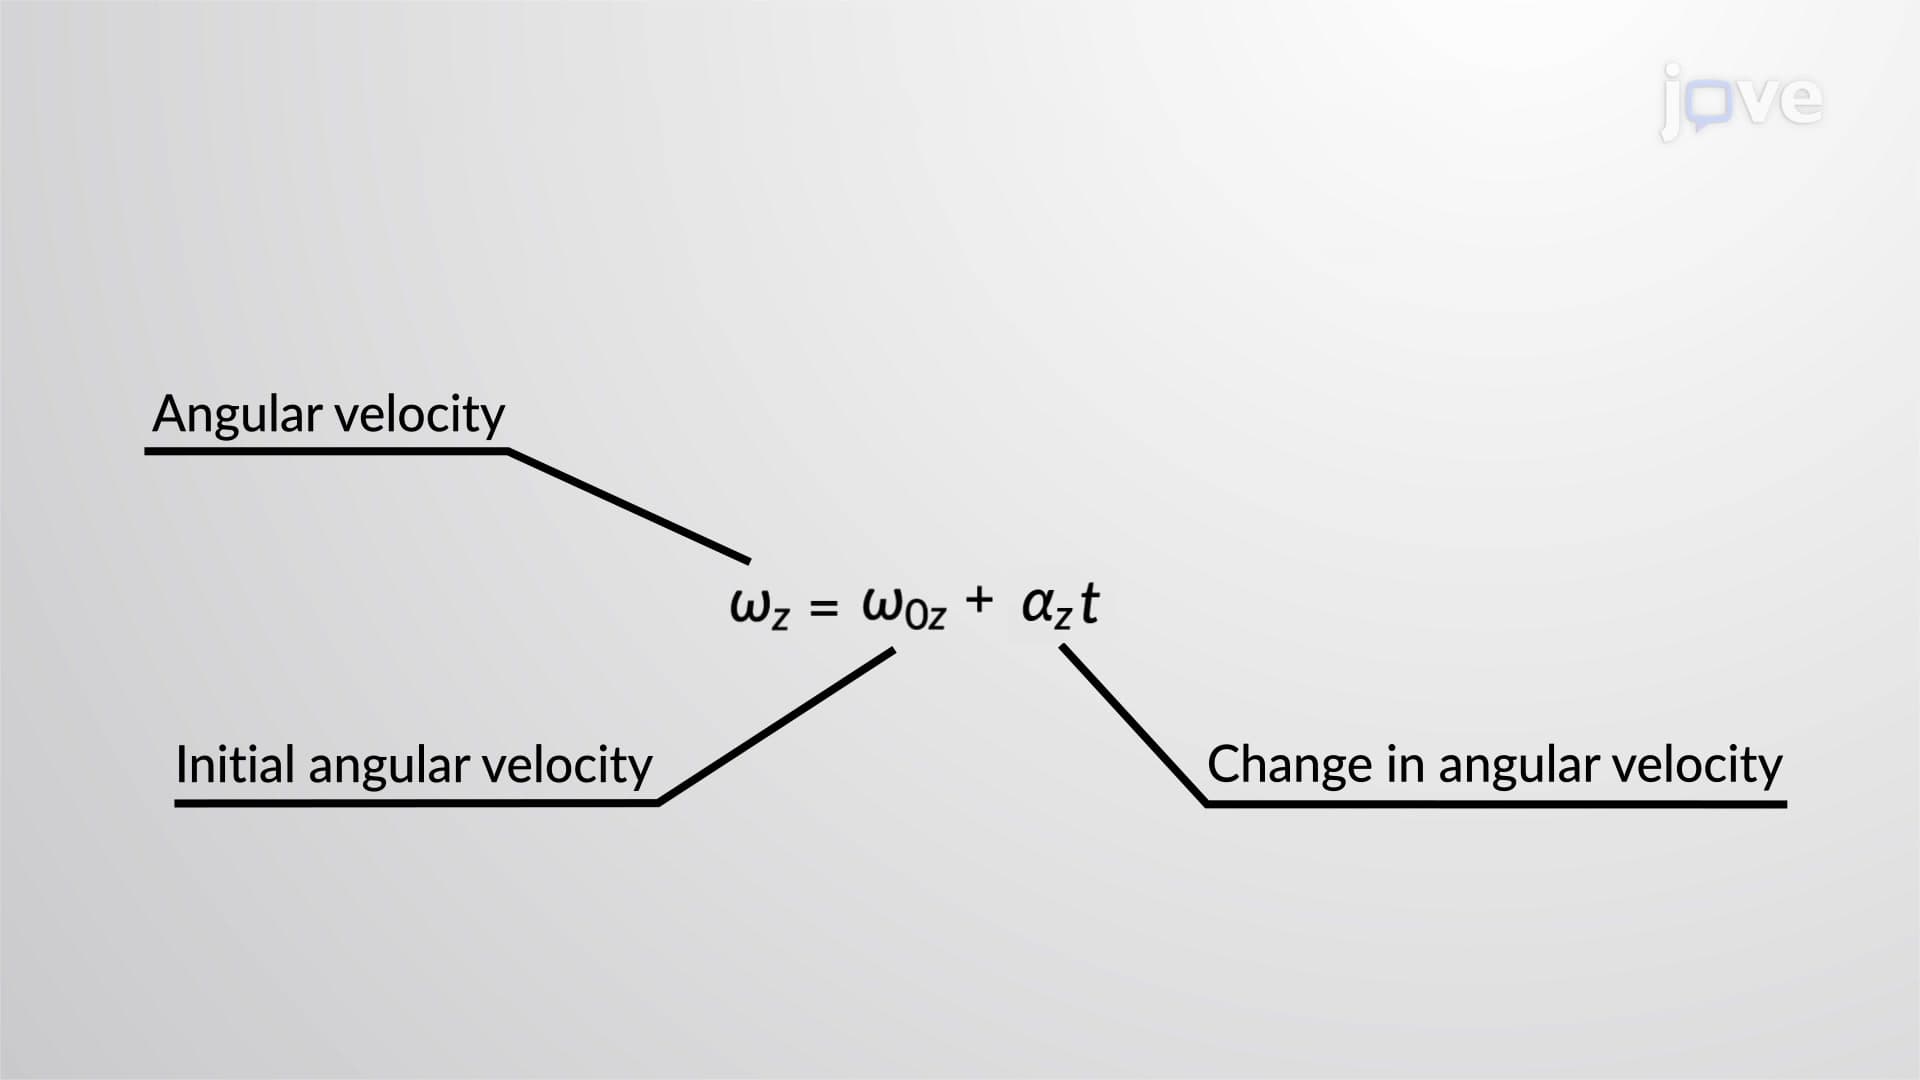
If angular acceleration is constant, then we can simplify equations of rotational kinematics, similar to the equations of linear kinematics. This simplified set of equations can be used to describe many applications in physics and engineering where the angular acceleration of a system is constant.
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
6.8K