

惯性测量单元位置的0.05米变化会在运行过程中改变时间和频率域指标
Dovin Kiernan1, Zachary David Katzman2,3, David A Hawkins1,2
1Biomedical Engineering Graduate Group, University of California Davis, Davis, CA 95616, USA.
Sensors (Basel, Switzerland)
|January 26, 2024

概括
惯性测量单元 (IMU) 的位置准确性对于可靠的运行生物力学至关重要. 即使是IMU位置的小变化也可以显著改变步态分析数据,影响力和时间测量.
科学领域:
- 生物力学 生物力学
- 运动科学 运动科学 运动科学
- 可穿戴技术可穿戴技术
背景情况:
- 惯性测量单元 (IMU) 提供了有价值的现实世界运行数据.
- 由于位置变化或在使用期间的移动,IMU信号的准确性可能会受到损害.
研究的目的:
- 量化IMU错位对运行生物力学数据的影响.
- 评估下游对步态参数的影响,并确定潜在的错误来源.
主要方法:
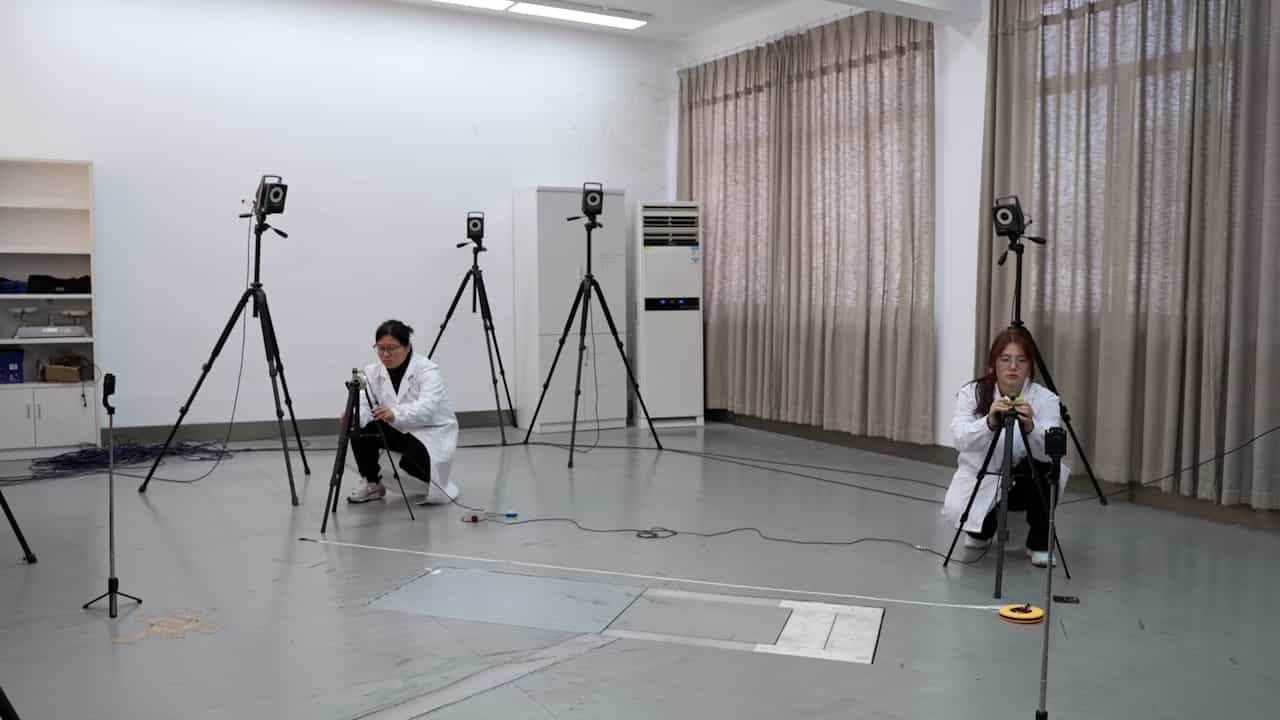
- 在74名跑步者的腿部,骨盆或十字骨上比较了参考和"错位"IMU (0.05米偏移) 的数据.
- 使用根平均平方误差 (RMSEs),峰值大小/时间差异和频率域分析分析差异.
- 从两个IMU位置得出的初始/终端接触时间和垂直地面反应力.
主要成果:
- RMSE低于1g和1rad/s,但峰值差异达到了2.45g和2.48rad/s.
- 接触时间和力量的平均差异分别达到 -10.08 ms 和 95.06 N.
- 观察到高连贯性 (≤10 Hz),在可穿戴与分段坐标系统中误差放大.
结论:
- IMU的放置和移动在运行生物力学数据中引发了重大潜在错误.
- 准确的IMU放置对于有效的现实世界步态分析至关重要.
- 坐标系统的选择可以影响观察到的IMU放置错误的幅度.

相关概念视频
 01:12
Measuring Acceleration Due to Gravity
567
Consider a coffee mug hanging on a hook in a pantry. If the mug gets knocked, it oscillates back and forth like a pendulum until the oscillations die out.
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
567
 01:03
Inertial Frames of Reference
7.1K
Newton’s first law is usually considered to be a statement about reference frames. It provides a method for identifying a special type of reference frame: the inertial reference frame. In principle, we can make the net force on a body zero. If its velocity relative to a given frame is constant, then that frame is said to be inertial. So, by definition, an inertial reference frame is a reference frame where Newton's first law holds valid. Newton's first law applies to objects with...
7.1K
 01:34
Velocity and Position by Graphical Method
7.4K
Velocity and position can be calculated from the known function of acceleration as a function of time. The total area under the acceleration-time graph and the velocity-time graph gives the change in velocity and position, respectively. In the case of an airplane, its acceleration is tracked using the inertial navigation system. The pilot provides the input of the airplane's initial position and velocity before takeoff. The inertial navigation system then uses the acceleration data to...
7.4K
 01:10
Relative Motion Analysis - Acceleration
359
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
359
 01:27
Non-inertial Frames of Reference
5.9K
A reference frame accelerating or decelerating relative to an inertial frame is a non-inertial frame. To help understand this, consider what taking off in an airplane, turning a corner in a car, riding a merry-go-round, and the circular motion of a tropical cyclone all have in common. All these systems are accelerating, decelerating, or rotating relative to the Earth; hence, they all are non-inertial frames. All these systems exhibit inertial forces, which merely seem to arise from motion,...
5.9K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
337
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
337