
集体学习方法用于连续解码手关节角度
Hai Wang1, Qing Tao1, Xiaodong Zhang1,2
1School of Mechanical Engineering, Xinjiang University, Urumqi 830017, China.
Sensors (Basel, Switzerland)
|January 26, 2024

概括
本研究引入了一种集体学习模型,用于从表面肌电图 (sEMG) 信号中解码手关节角度,以改善假肢控制. 最好的模型实现了高精度,为在假肢中实现先进的同时和比例控制 (SPC) 铺平了道路.
科学领域:
- 生物医学工程 生物医学工程
- 机器学习 机器学习
- 康复技术 康复技术 康复技术
背景情况:
- 人机界面 (HMI) 假肢技术受到动作解码精度的限制.
- 同时和比例控制 (SPC) 对于提高智能假肢的灵巧性和功能至关重要.
- 从表面电肌图 (sEMG) 信号中精确解码关节角度是一个关键的挑战.
研究的目的:
- 开发和评估一个集体学习方法来从sEMG信号中解码元手腕关节 (MCP) 关节角度.
- 为了比较各种集合模型的性能与传统方法 (如高斯过程模型) 的性能.
- 通过集体学习建立一个全面的管道,用于高性能手动识别.
主要方法:
- 设计并测试了七种不同的集体学习模型,用于从sEMG数据中解码角度.
- 在功能任务期间记录的sEMG信号,以估计五个MCP连接角度的动力学.
- 使用皮尔森相关系数 (CC) 和根平均平方误差 (RMSE) 评估模型性能.
主要成果:
- 一个结合的CatBoost和LightGBM组合模型表现出卓越的性能,平均CC为0.897和RMSE为7.09.
- 整体学习方法在所有测试场景中在解码准确性方面明显优于高斯过程模型.
- 与深度学习相比,拟议的管道提供了一个强大的手动识别系统,其参数和数据要求较低.
结论:
- 合体学习提供了一种强大而有效的方法,用于从sEMG信号中高精度的角度解码.
- 开发的系统具有显著的潜力,可以在下一代假肢手中实现同时和比例控制 (SPC).
- 这项研究为工程师和研究人员提供了实施先进假肢控制系统的实际框架.

相关概念视频
 01:09
Functional Classification of Joints
4.1K
Functional Classification of Joints
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An...
4.1K
 01:20
Structural Classification of Joints
3.4K
Joints, also known as articulations, are classified based on their structural characteristics, i.e., based on whether the articulating surfaces of the adjacent bones are directly connected by fibrous connective tissue or cartilage, or whether the articulating surfaces contact each other within a fluid-filled joint cavity. These differences serve to divide the joints of the body into three structural classifications.
A fibrous joint is where the adjacent bones are united by fibrous connective...
A fibrous joint is where the adjacent bones are united by fibrous connective...
3.4K
 01:30
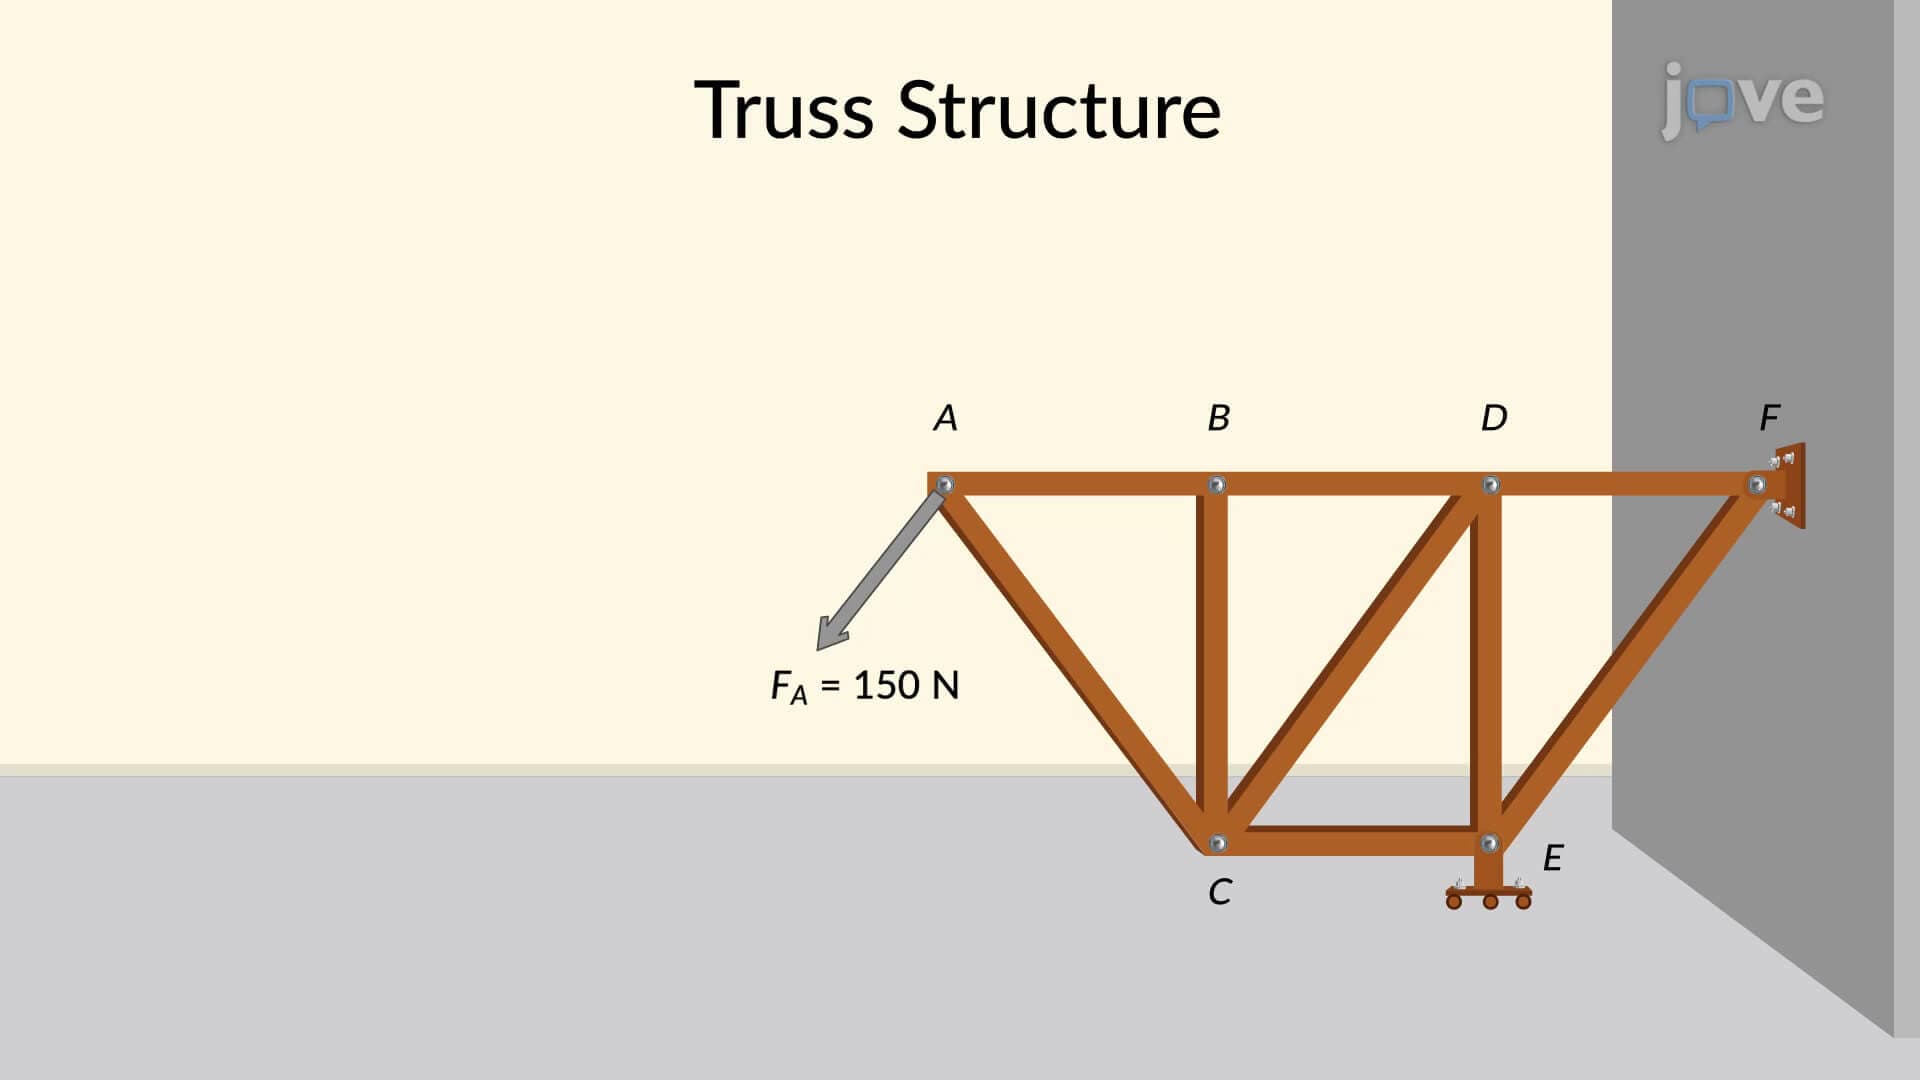
Method of Joints: Problem Solving II
580
Consider a truss structure with frictionless joints fixed to a wall and roller support. If a force of 150 N is applied to joint A, the forces in each member of the truss can be determined using the method of joints.
580
 01:22
Multi-input and Multi-variable systems
106
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
106
 01:27
Associative Learning
370
Associative learning is a fundamental concept in behavioral psychology, wherein a connection is established between two stimuli or events, leading to a learned response. This process is critical in understanding how behaviors are acquired and modified. Conditioning, the mechanism through which associations are formed, can be divided into two main types: classical conditioning and operant conditioning, each elucidating different aspects of associative learning.
Classical conditioning, also known...
Classical conditioning, also known...
370
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
404
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
404