基于愿景的集体运动:一种以虫为灵感的减少主义模型
David L Krongauz1, Amir Ayali2, Gal A Kaminka1
1Computer Science Department, Bar-Ilan Univeristy, Israel.
PLoS computational biology
|January 29, 2024

概括
这项研究使用有限的单眼视觉来模拟虫的集体运动,表明即使有视觉遮蔽,也可以出现有序的群. 不同的策略会影响实现这一订单的速度.
科学领域:
- 集体动议是一项集体动议.
- 动物行为 动物行为
- 机器人技术 机器人技术 机器人技术
背景情况:
- 许多理论模型的蜂群假设完美的感知,忽视现实世界的局限性.
- 生物视力,就像虫的生物视力一样,往往是单眼和非立体视觉,导致估计错误.
- 同龄人对视觉的遮蔽进一步复杂化了群体中的感知.
研究的目的:
- 用有限的,非立体视觉来探索有序集体运动的条件.
- 在具有特定视觉限制的虫类药物中建模基于视觉的集体运动.
- 调查解释部分封闭视觉信息的策略.
主要方法:
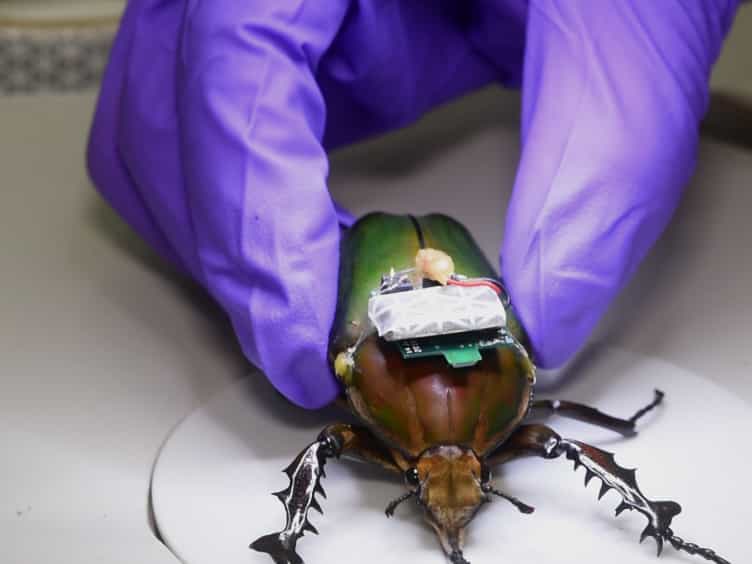
- 开发了一种用于具有单眼,非立体视觉的虫类药物的计算模型.
- 解决了非立体距离/速度估计和视觉阻塞的问题.
- 对比了在模拟环境中处理视觉信息的三种策略.
主要成果:
- 在各种领域的模拟表明了有序或近乎有序状态的出现.
- 在测试的策略中,实现顺序的速度在测试策略之间有所不同.
- 代理延长和环境几何学影响了结果.
结论:
- 即使有有限的非立体视力和闭塞,也可以实现有序的集体运动.
- 不同的视觉解释策略会影响订单形成的速度.
- 这些发现为生物学研究和机器人控制群体系统提供了洞察力.
相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
461
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
461
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
404
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
404
 01:23
Curvilinear Motion: Rectangular Components
455
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
455
 01:22
Planar Rigid-Body Motion
446
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
446
 01:24
Absolute Motion Analysis- General Plane Motion
220
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
220
 01:24
One-Degree-of-Freedom System
490
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
490