

通过随机共振在一块不对称的双稳定系统中进行增强的故障诊断
Yongge Li1, Qixiao Zhu1, Yong Xu1,2
1School of Mathematics and Statistics, Northwestern Polytechnical University, Xi'an 710072, China.
Chaos (Woodbury, N.Y.)
|January 29, 2024

概括
这项研究引入了一种新的零碎不对称的随机共振系统,以改善噪音环境中的弱故障信号检测. 该方法提高了信号与噪声比 (SNR) 以实现更可靠的故障诊断,即使在变化速度的情况下也是如此.
科学领域:
- 机械工程 机械工程
- 信号处理 信号处理
- 错误诊断 错误诊断 错误诊断 错误诊断 错误诊断 错误诊断
背景情况:
- 软弱的故障信号往往会被噪声所掩盖,阻碍了准确的故障诊断.
- 经典的双稳定随机共振 (CBSR) 有 output 和和不完美的优化等局限性.
- 从噪音数据中提取有用的故障特征是一个关键的挑战.
研究的目的:
- 提出一种新的零碎不对称的随机共振系统,以克服CBSR的局限性.
- 为了增强在强噪声的情况下提取弱故障信号.
- 提高故障诊断技术的准确性和可靠性.
主要方法:
- 开发一个零碎不对称的随机共振系统.
- 理论推导的输出信号与噪声比率 (SNR) 使用一个两个状态模型在波激发.
- 拟议方法应用于故障数据分析.
主要成果:
- 拟议的系统在输出SNR方面,与CBSR相比,表现优越.
- 在故障特征频率/顺序下达到更高的光谱峰值.
- 在固定的速度和时间变化的速度条件下有效的性能.
结论:
- 断片不对称的随机共振系统为弱故障信号处理提供了一个有前途的方法.
- 提供了新的理论指导,以提高故障诊断的准确性和可靠性.
- 在从噪音数据中提取故障特征方面优于经典方法.
更多相关视频
相关概念视频
 01:18
Second Order systems II
113
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
113
 01:25
Multimachine Stability
158
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
158
 01:24
Pole and System Stability
297
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
297
 01:23
Root Loci for Positive-Feedback Systems
120
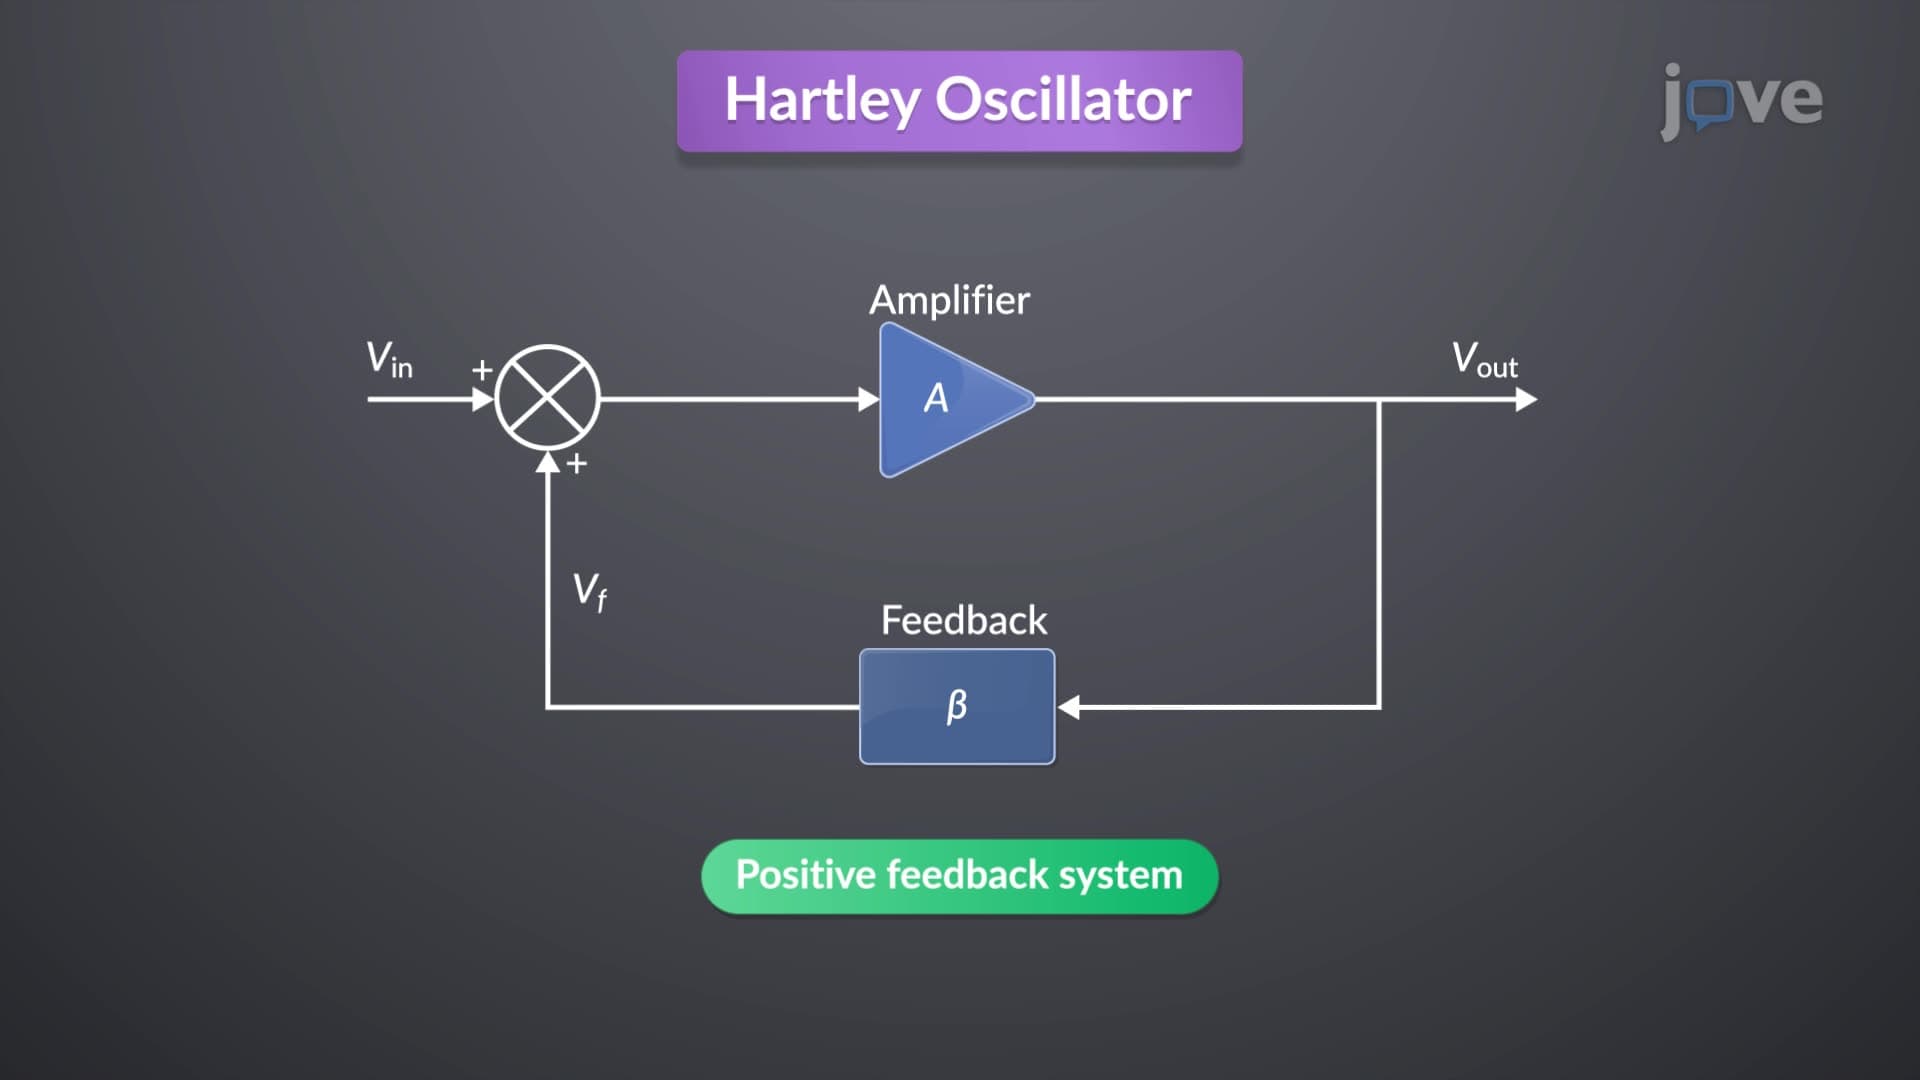
The Hartley oscillator is a positive feedback system that sustains oscillations by feeding the output back to the input in phase, thereby reinforcing the signal. Positive feedback systems can be viewed as negative feedback systems with inverted feedback signals. In these systems, the root locus encompasses all points on the s-plane where the angle of the system transfer function equals 360 degrees.
The construction rules for the root locus in positive feedback systems are similar to those in...
The construction rules for the root locus in positive feedback systems are similar to those in...
120
 01:24
BIBO stability of continuous and discrete -time systems
397
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
397
 01:26
Linear Approximation in Frequency Domain
91
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
91