
动态萨卡德上下文触发了更稳定的对象位置绑定
1Department of Psychology, Ohio State University.
Journal of experimental psychology. General
|February 1, 2024

概括
动态的眼睛运动,而不是静态的眼睛运动,可以实现以世界为中心 (空间) 的物体位置绑定. 这项研究揭示了动态萨卡德语境如何改善视觉稳定性和对象表示.
科学领域:
- 认知神经科学 认知神经科学
- 视觉感知 视觉感知 视觉感知
- 人类视觉 人类视觉
背景情况:
- 视觉系统迅速整合了对象的身份和位置.
- 关于在眼睛运动过程中实现以世界为中心 (spatiotopic) 的对象表示存在争论.
- 以前的研究经常显示以眼为中心 (视网膜) 的效应,可能是由于静态实验设置.
研究的目的:
- 为了调查动态萨卡德语境是否有助于空间类型对象位置绑定.
- 在静态与动态眼动场景中比较对象位置绑定.
- 为了确定影响视网膜和空间膜结合的因素.
主要方法:
- 在健康成年人中采用空间一致性偏差范式.
- 在静态 (单次) 和动态 (多次,频繁) 环境中比较了对象位置绑定.
- 分析了对视网膜和空间膜结合的调节因子.
主要成果:
- 在静态环境中观察到纯粹的视网膜类结合,与之前的研究一致.
- 强大的空间拓结合在动态萨卡德环境中出现.
- 影响两种结合类型的特定因素被成功分离出来.
结论:
- 动态的萨卡德上下文促进稳定,以世界为中心的 (spatiotopic) 对象位置绑定.
- 这表明,在动态条件下,更灵活的大脑状态可以提高视觉稳定性.
- 研究结果支持这样一个观点,即生态相关的动态环境对于理解视觉绑定至关重要.
相关概念视频
 01:03
Inertial Frames of Reference
7.1K
Newton’s first law is usually considered to be a statement about reference frames. It provides a method for identifying a special type of reference frame: the inertial reference frame. In principle, we can make the net force on a body zero. If its velocity relative to a given frame is constant, then that frame is said to be inertial. So, by definition, an inertial reference frame is a reference frame where Newton's first law holds valid. Newton's first law applies to objects with...
7.1K
 01:27
Non-inertial Frames of Reference
5.9K
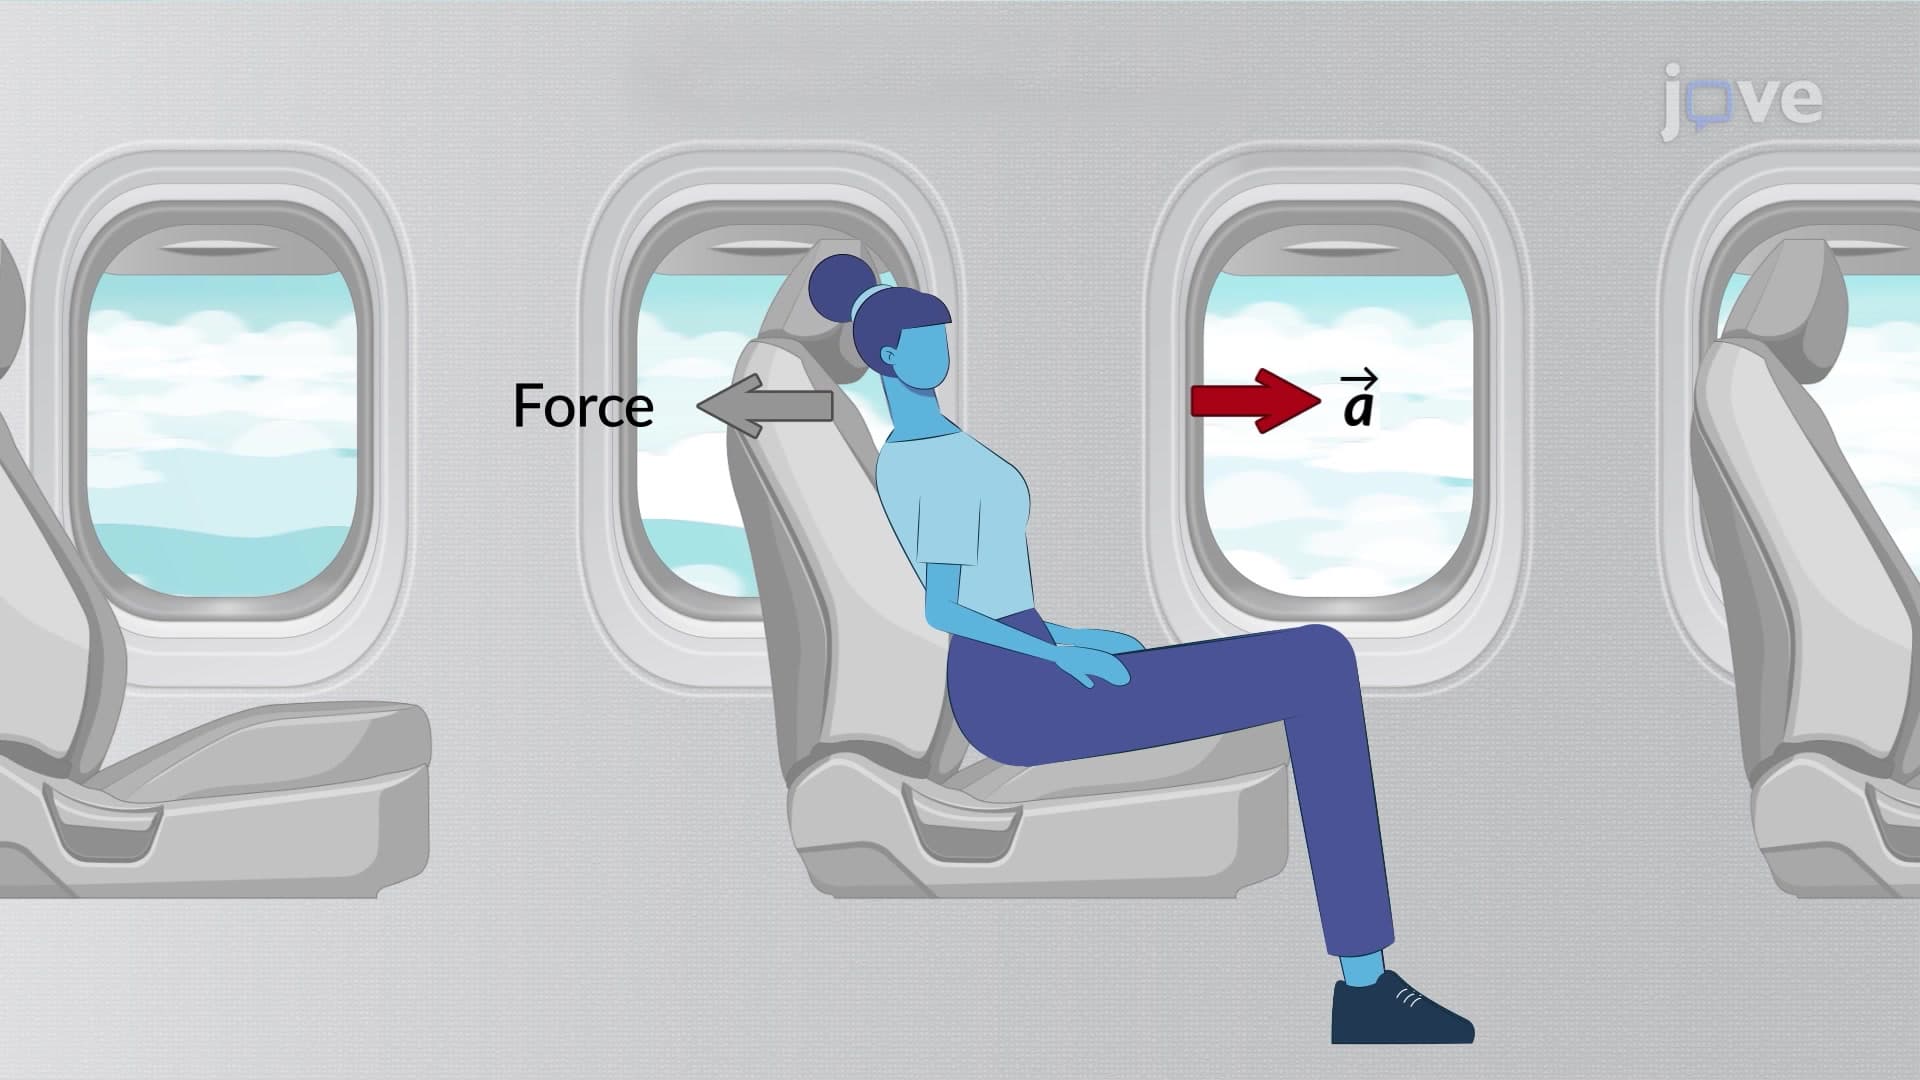
A reference frame accelerating or decelerating relative to an inertial frame is a non-inertial frame. To help understand this, consider what taking off in an airplane, turning a corner in a car, riding a merry-go-round, and the circular motion of a tropical cyclone all have in common. All these systems are accelerating, decelerating, or rotating relative to the Earth; hence, they all are non-inertial frames. All these systems exhibit inertial forces, which merely seem to arise from motion,...
5.9K
 01:10
Relative Motion Analysis - Acceleration
359
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
359
 01:24
Relative Motion Analysis - Velocity
362
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
362
 01:25
Relative Motion Analysis using Rotating Axes
461
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
461
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
404
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
404