相关实验视频
Updated: Jul 4, 2025
06:42

Magnetically Induced Rotating Rayleigh-Taylor Instability
Published on: March 3, 2017
9.6K
对于非局部Lotka-Volterra模型的移动波解决方案的稳定性
Xixia Ma1, Rongsong Liu2, Liming Cai1
1School of Mathematics and Statistics, Xinyang Normal University, Xinyang, China, 464000.
Mathematical biosciences and engineering : MBE
|February 2, 2024

概括
本研究分析了在两种Lotka-Volterra竞争模型中移动波解决方案的稳定性. 研究人员证明了统一的上限,并为具有大波速的移动波确定了非对称稳定性.
科学领域:
- 数学生物学 数学生物学
- 生态生态学 生态生态学
- 动态系统 动态系统
背景情况:
- 洛特卡-沃尔特拉竞争模式是一个基本的生态模型.
- 反应-扩散方程用于建模空间扩散和人口动态.
- 移动波的解决方案在生态模型中代表稳定的空间模式.
研究的目的:
- 为了研究两个物种的Lotka-Volterra竞争模型的移动波解决方案的稳定性.
- 用非局部竞争术语分析一个反应-扩散方程系统.
- 为了建立这些空间解决方案的非对称稳定性的条件.
主要方法:
- 证明模型的解决方案的统一上限.
- 使用反权重方法.
- 使用能量估计来分析稳定性.
主要成果:
- 解决方案的统一上限被成功证明.
- 大波速的移动波的非对称稳定性被确立.
- 该研究提供了对竞争物种的持久性和空间动态的见解.
结论:
- 在这种竞争模式中的移动波解决方案在某些条件下是稳定的.
- 非局部竞争和反应扩散动态在人口稳定中起着至关重要的作用.
- 这项研究有助于理解复杂的生态相互作用和空间模式的形成.
相关概念视频
 01:27
Traveling Waves: Lossless Lines
140
The provided content explores the behavior of traveling waves on single-phase lossless transmission lines. It begins with a single-phase two-wire lossless transmission line of length Δx, characterized by a loop inductance LH/m and a line-to-line capacitance C F/m. These parameters result in a series inductance LΔx and a shunt capacitance CΔx.
140
 01:28
Stability
128
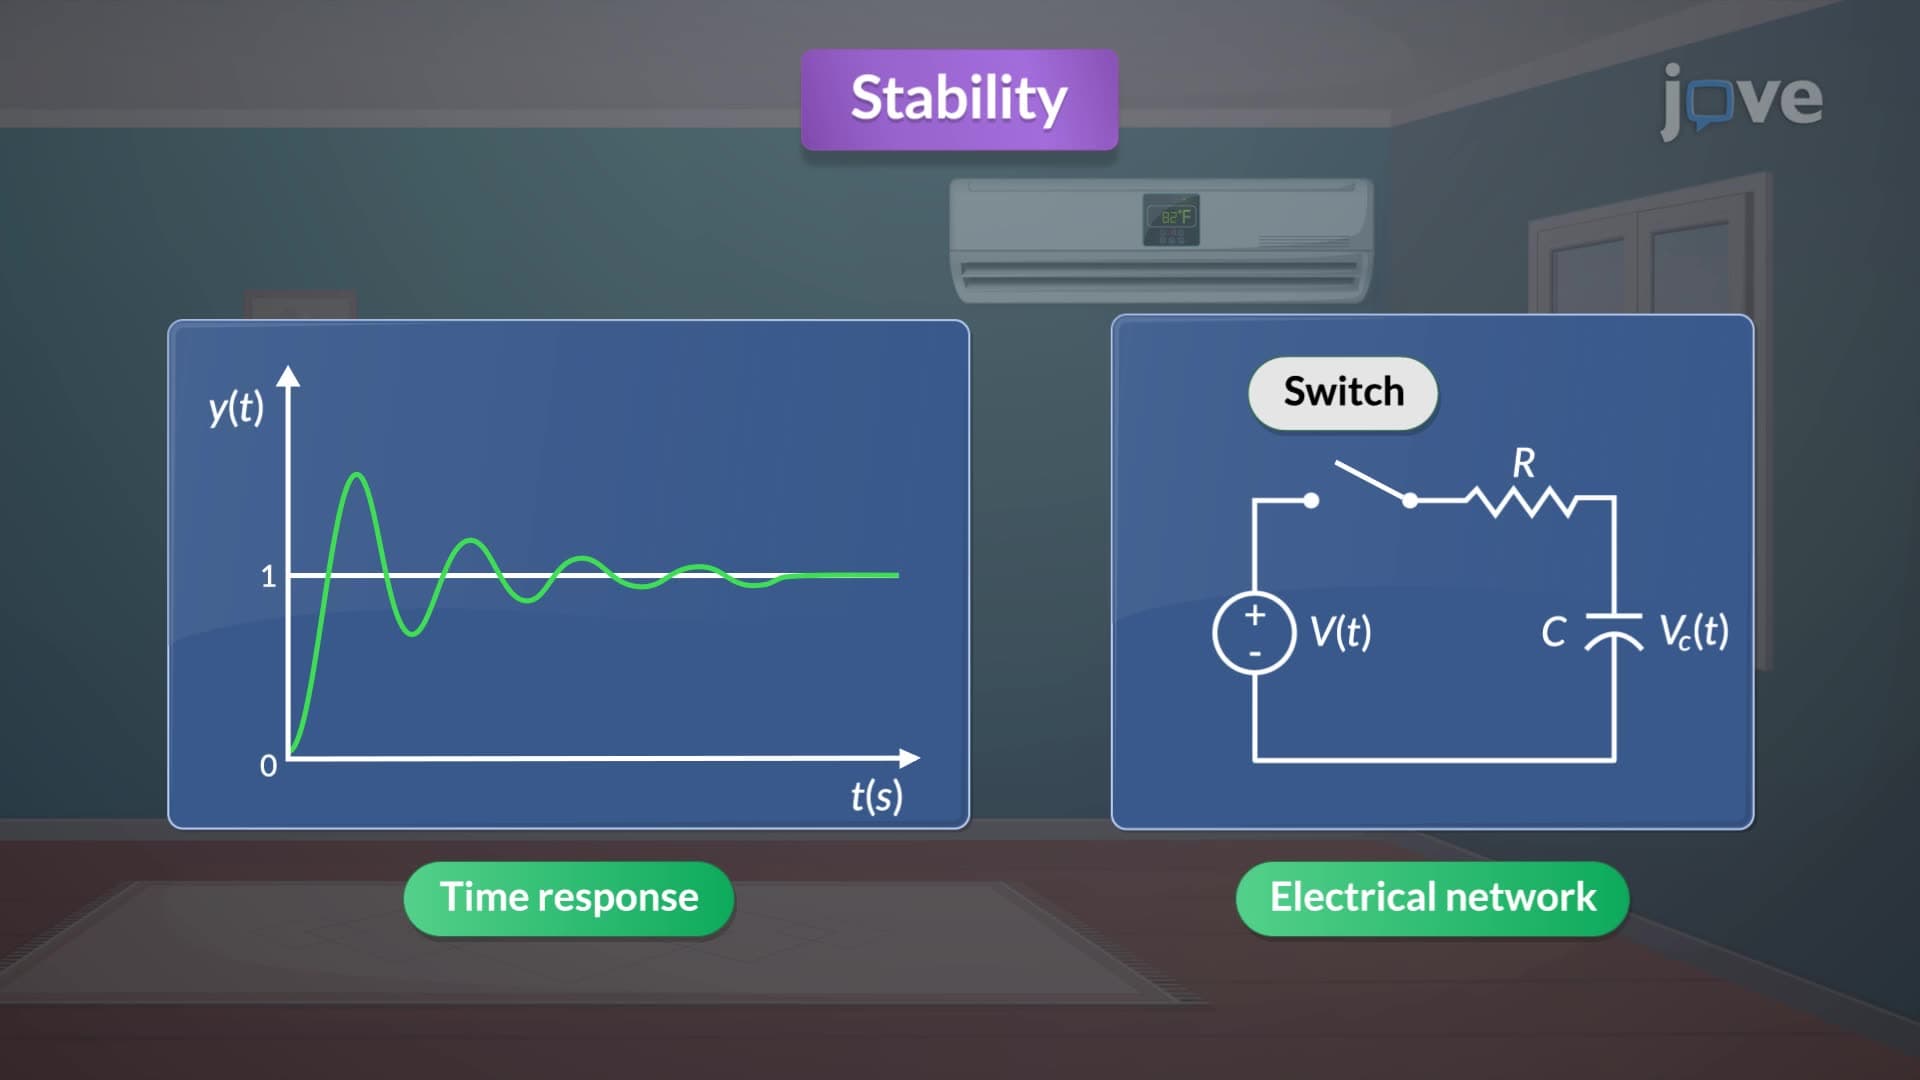
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
128
 01:04
Oscillations about an Equilibrium Position
5.4K
Stability is an important concept in oscillation. If an equilibrium point is stable, a slight disturbance of an object that is initially at the stable equilibrium point will cause the object to oscillate around that point. For an unstable equilibrium point, if the object is disturbed slightly, it will not return to the equilibrium point. There are three conditions for equilibrium points—stable, unstable, and half-stable. A half-stable equilibrium point is also unstable, but is named so...
5.4K
 01:21
Linear Approximation in Time Domain
81
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
81
 01:26
Linear Approximation in Frequency Domain
91
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
91
 01:23
Stability of Equilibrium Configuration
448
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
448