
埃伦费斯特动态中的总角动量保存,以亚底动态状态的截断基础
Zhen Tao1, Xuezhi Bian1, Yanze Wu1
1Department of Chemistry, University of Pennsylvania, Philadelphia, Pennsylvania 19104, USA.
The Journal of chemical physics
|February 4, 2024

概括
标准的埃伦费斯特动力学未能在截断的亚亚动态状态下保持动量. 有效的埃伦费斯特方程,结合非阿贝尔贝里力,成功地保持量子动力学的动量保护.
科学领域:
- 量子化学 是一个量子化学.
- 理论化学 理论化学
- 化学物理 化学物理
背景情况:
- 波恩-奥本海默近似是初始电子结构理论的基石.
- 处理具有未配对电子自旋自由度的系统存在挑战.
- 标准的埃伦费斯特动态可以在保存基本物理量方面表现出局限性.
研究的目的:
- 为了研究在标准埃伦费斯特动力学中线性和角动量的保存.
- 评估有效的埃伦费斯特方程的有效性,涉及非阿贝尔贝里力,以保持动量.
- 为了证明使用Ehrenfest动力学来证明对不配对电子旋转系统的改进,质量正确的结果.
主要方法:
- 标准的埃伦费斯特动态的分析,使用截断的亚亚巴特状态的基础.
- 应用之前提出的有效的埃伦费斯特运动方程,并纳入非阿贝尔贝里力.
- 使用一般化Hartree-Fock与自旋轨道合的方法,对甲氧基的克莱默斯双倍数的数值研究.
主要成果:
- 标准的埃伦费斯特动力学被证明不保留线性和角动量与截断的亚流动态状态.
- 证明了涉及非阿贝尔贝里力的有效Ehrenfest方程可以保持动量维护.
- 用适当的运动方程证实了 methoxy 基的角运动量保存.
结论:
- 标准的埃伦费斯特动力学在使用截断的亚底动态状态时存在局限性,特别是在动量保存方面.
- 有效的埃伦费斯特动力学,包括非阿贝尔贝里力,为量子动力学提供了更强大的框架.
- 埃伦费斯特动态为不配对电子旋转的系统提供了改进和质量正确的结果,解决了Born-Oppenheimer近似的局限性.
相关概念视频
 01:09
Conservation of Angular Momentum
10.3K
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Considering a system that consists of n tiny particles, the angular momentum of any tiny particle may change, but the system's total angular momentum would remain constant. The principle of conservation of angular momentum only considers the net external torque acting on the system. While there are internal forces exerted by different particles within the system that also produce...
10.3K
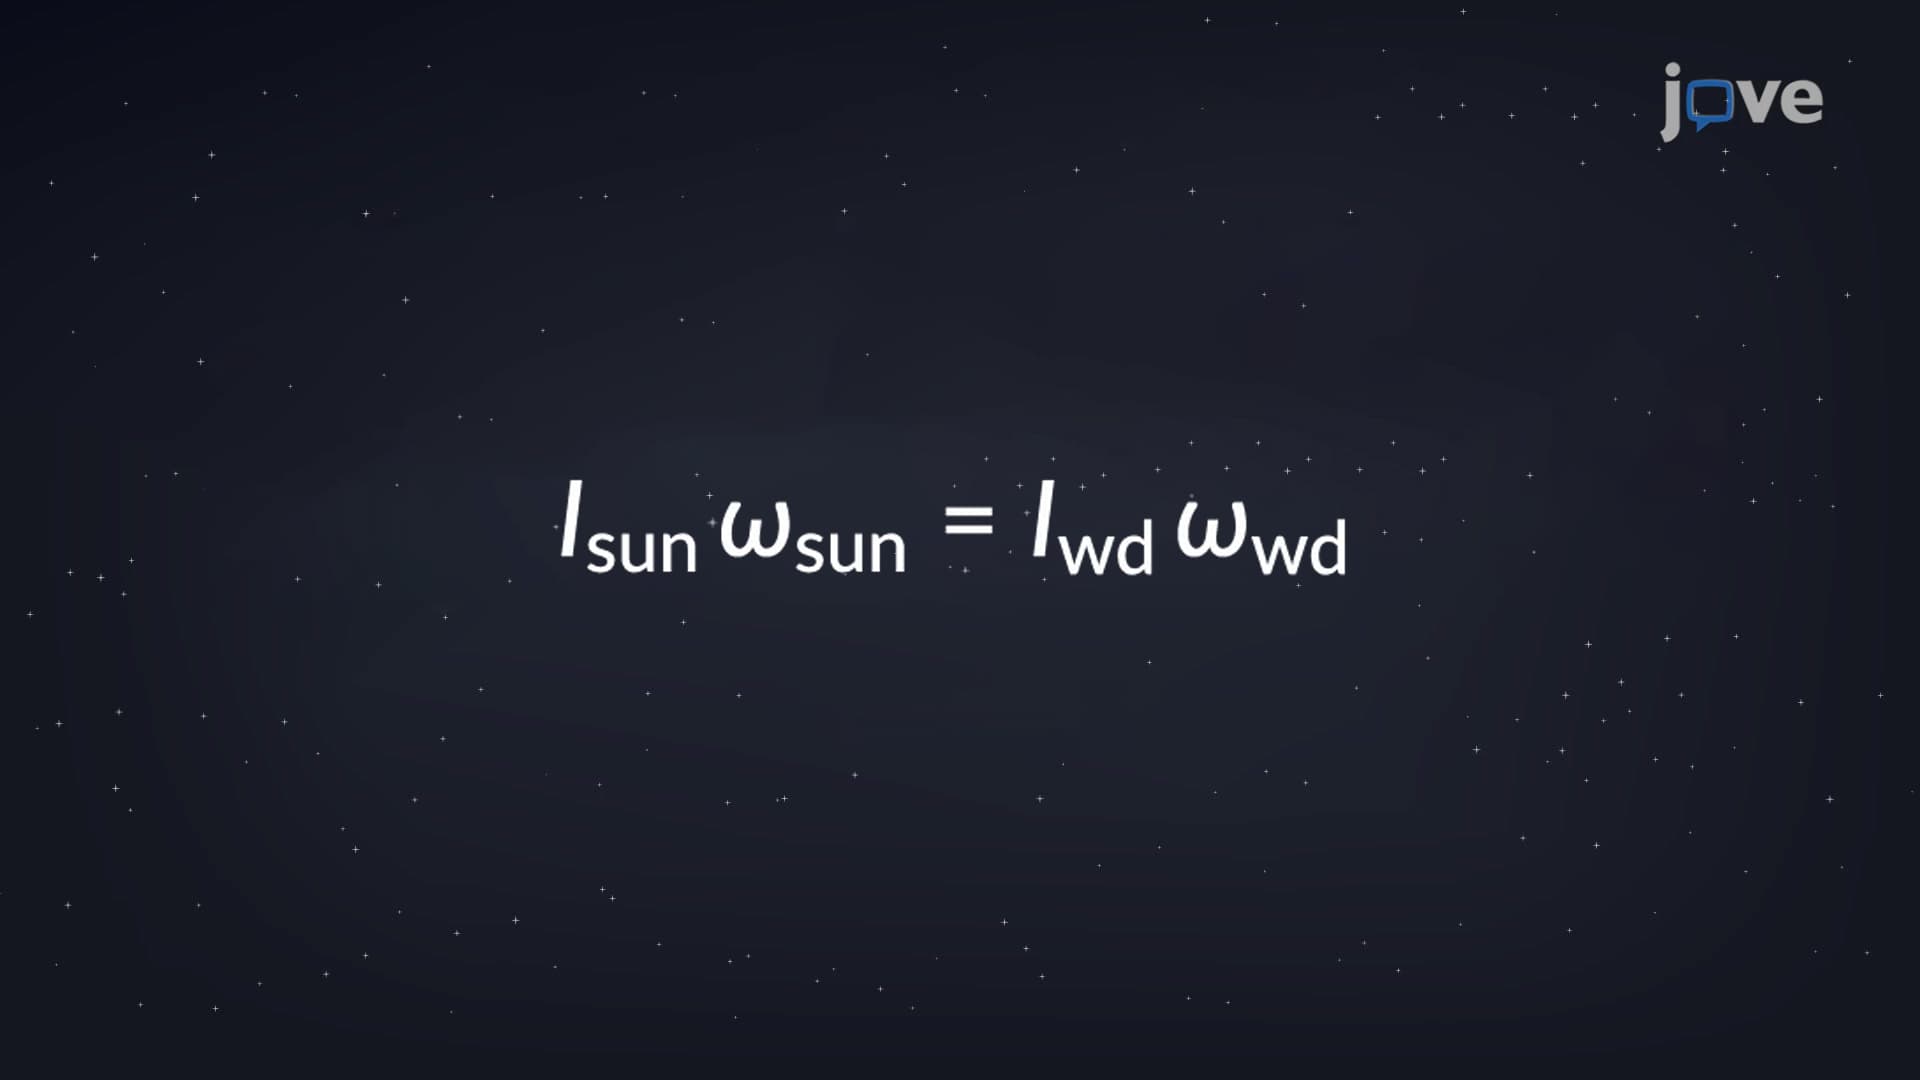 01:18
Conservation of Angular Momentum: Application
10.9K
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Examples of such systems include a freely spinning bicycle tire that slows over time due to torque arising from friction, or the slowing of Earth's rotation over millions of years due to frictional forces exerted on tidal deformations. However in the absence of a net external torque, the angular momentum remains conserved. The conservation of angular momentum principle requires a...
10.9K
 01:19
Euler Equations of Motion
217
Imagine a rigid body that is rotating at an angular velocity of ω within an inertial frame of reference. Along with this, picture a second rotating frame that is attached to the body itself. This frame moves along with the body and possesses an angular velocity of Ω. The total moment about the center of mass is calculated by adding the rate of change of angular momentum about the center of mass in relation to the rotating frame and the cross-product of the body's angular velocity...
217
 01:11
Angular Momentum about an Arbitrary Axis
196
Imagine a rigid body with a mass denoted as 'm', which has its center of mass at point G and is rotating around an inertial reference frame. The angular momentum at an arbitrary point P can be calculated by taking the cross product of the position vector and linear momentum vector for each individual mass element.
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
196
 01:23
Principle of Angular Impulse and Momentum
611
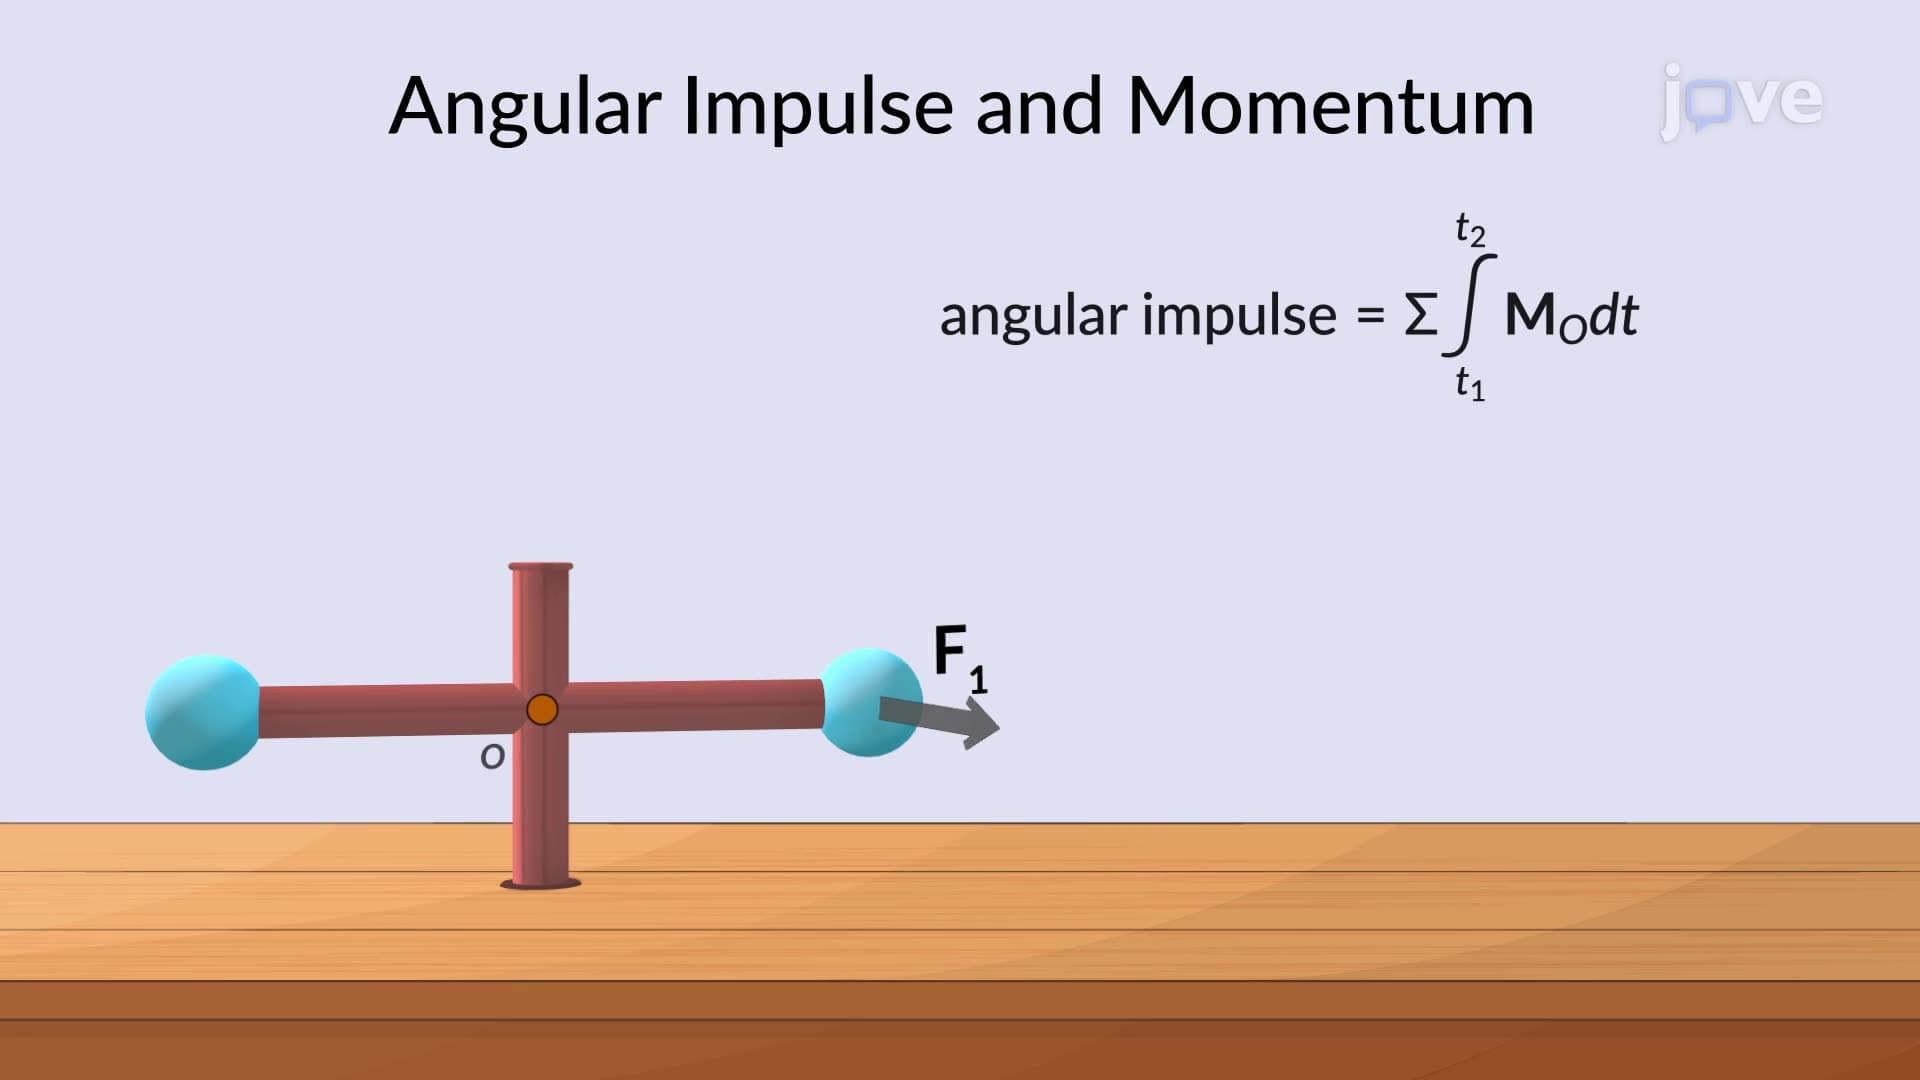
The angular impulse and momentum principle provides insights into how forces applied at a distance from an object's rotational axis influence its angular velocity. It builds upon the crucial relationship between the moment of force and angular momentum. By integrating this equation, substituting the limits for the initial and final times, a comprehensive expression representing the angular impulse and momentum principle is derived.
611
 01:09
Angular Momentum and Principle Axes of Inertia
208
The concept of angular momentum for a solid structure is illustrated as the cumulative result of the cross-product of the position vector of the mass element and the cross-product of the body's angular velocity with the position vector.
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
208