
在斯基拉和哈里比底之间导航:在DLBCL中做得比Pola-RCHP更好的一条路线图
Javier Munoz1, Anagha Deshpande2, Lisa Rimsza3
1Department of Hematology, Mayo Clinic Arizona, Phoenix, AZ, USA.
Cancer treatment reviews
|February 4, 2024

概括
扩散性大B细胞淋巴瘤 (DLBCL) 治疗面临着平衡疾病侵略性和治疗毒性的挑战. 未来的战略重点是针对性治疗和人工智能,使用多omics数据进行个性化治疗方法.
科学领域:
- 在瘤学瘤学.
- 血液学 血液学 血液学
- 基因组学就是基因组学.
- 免疫治疗是一种免疫疗法.
背景情况:
- 扩散性大B细胞淋巴瘤 (DLBCL) 治疗传统上依赖于R-CHOP化疗.
- 在DLBCL治疗中,平衡疾病控制和治疗毒性是DLBCL治疗的一个主要挑战.
- 现有的治疗方案,包括波拉图祖马布维多丁加R-CHP,尚未实现普遍治愈率.
研究的目的:
- 审查扩散性大B细胞淋巴瘤 (DLBCL) 治疗中的挑战.
- 突出需要新的治疗策略,超越传统化疗的骨干.
- 建议整合人工智能和多omics数据,以实现个性化的DLBCL治疗.
主要方法:
- 审查当前DLBCL治疗策略,包括降级,升级和替换.
- 检查基因组和分子技术的进步,以了解DLBCL异质性.
- 探索新型细胞疗法,如仿真抗原受体 (CAR) T细胞疗法.
主要成果:
- 虽然波拉图祖马布维多丁加R-CHP代表了突破,但普遍治愈率仍然难以捉摸.
- 分子技术的进步使得我们能够更深入地了解DLBCL的多样性.
- 像CAR-T细胞疗法这样的新疗法显示出提高疗效和安全性的承诺.
结论:
- 对于DLBCL来说,非常需要超越基于化疗的疗法.
- 针对性,精确和个性化的疗法对于提高DLBCL治愈率至关重要.
- 建议将人工智能与多omics数据分析集成为对DLBCL进行决定性,个性化的攻击.
相关概念视频
 01:19
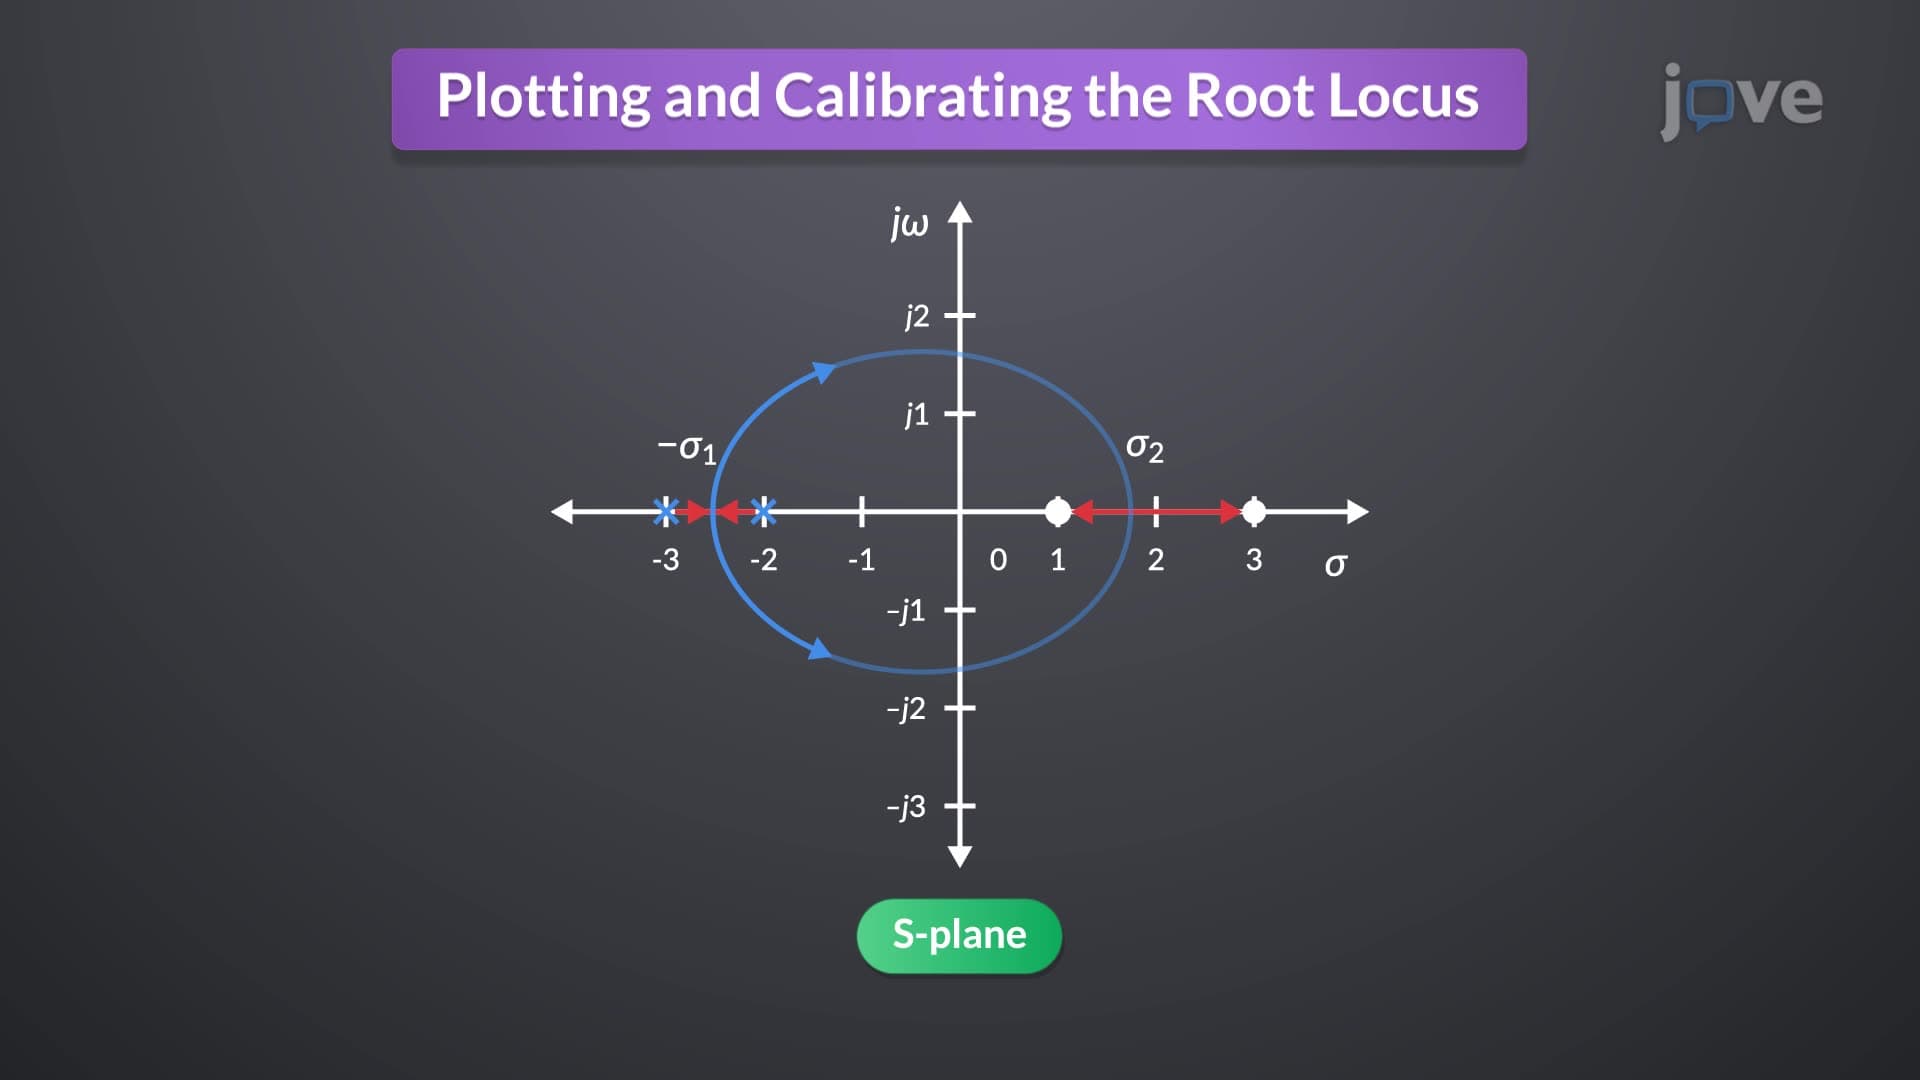
Plotting and Calibrating the Root Locus
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
 01:27
Latitudes and Departures
Latitudes and departures are essential concepts in surveying, providing a systematic way to analyze the projections of traverse lines. These projections allow surveyors to interpret a line's north-south and east-west components, which are crucial for precisely calculating areas, bearings, and lengths. Latitude is the north-south projection of a line, calculated as the product of the line's length and the cosine of its bearing. Departure, conversely, is the east-west projection obtained by...
 01:12
Design Example: Marking Boundaries of a Site Using a Compass
Marking site boundaries using a compass is a precise surveying technique that ensures the accuracy of boundary delineation. The process begins by using provided site details, including the bearings and lengths of each boundary line. The initial step involves calculating latitudes and departures for all sides of the site. This computation verifies that the traverse is free of errors, ensuring a closed and accurate boundary.The process starts at a known point, such as Point A, which is often...
 01:17
Design Example: Alignment of a Road Line Using GIS
The alignment of a road line using Geographic Information Systems (GIS) is a critical process in civil engineering, combining advanced technology with practical decision-making. This methodology begins with the collection of geospatial data, including information on land cover, geomorphology, drainage patterns, slope, and contour details. Such data is typically acquired through satellite imagery and GIS tools, offering a comprehensive understanding of the terrain.Once the data is gathered, it...
 01:17
Graphs of Polar Equations
The polar coordinate system represents points using a distance from a central point (the pole) and an angle from a reference direction (the polar axis). Unlike rectangular coordinates, polar coordinates are ideal for graphing curves with radial symmetry or periodic behavior.Some general forms of graphs in polar coordinates include the following:Equation of a Circle (Centered at the Pole):A graph where the radius remains constant for all angles traces a circle centered at the pole:Equation of a...
 01:26
Integration Applied to Polar Coordinates to Find Arc Lengths
In polar coordinates, a plane curve is described by a radial distance r from a fixed point, called the pole, and an angle θ measured from a reference direction. This system is especially useful for paths that naturally involve rotation, such as an expanding spiral followed by a search drone. If the hiker’s last known position is treated as the pole, then the drone’s location at any instant can be represented by the polar equation r = f(θ), where the distance from the pole changes as the drone...