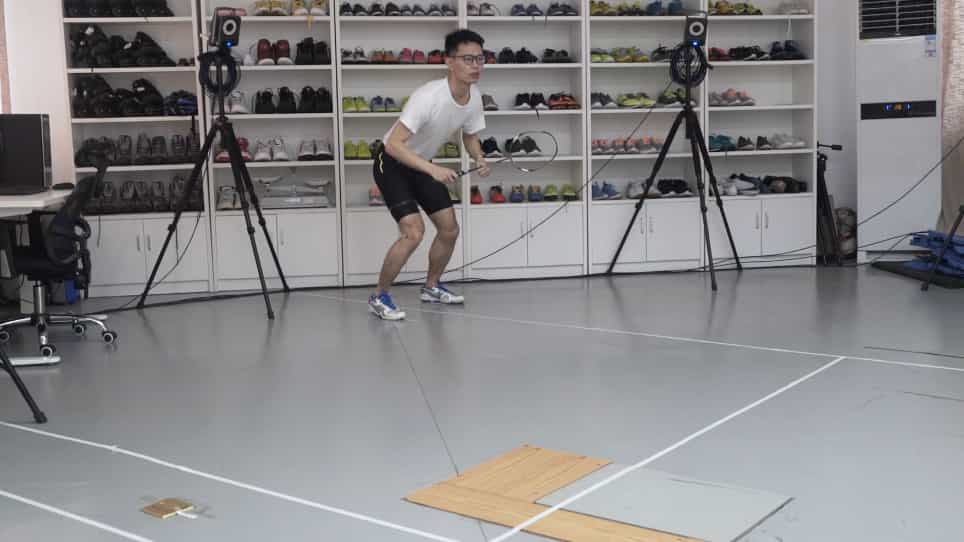

在体育舞蹈舞厅舞蹈中的相反身体运动的动力学评估
1Faculty of Physical Education, Józef Piłsudski University of Physical Education, Warsaw, Poland.
Acta of bioengineering and biomechanics
|February 5, 2024

概括
维也纳华尔兹的身体运动与评委的分数密切相关. 这项研究分析了舞者的骨盆和脊柱旋转,发现运动技巧和表演评估之间存在显著的关系.
科学领域:
- 生物力学 生物力学
- 舞蹈 运动 科学 科学
- 运动分析 运动分析
背景情况:
- 维也纳华尔兹需要复杂的协调.
- 对舞蹈技巧的客观评估是具有挑战性的.
- 了解身体运动对得分的影响至关重要.
研究的目的:
- 分析在维也纳华尔士中相反的身体运动.
- 为了将身体运动与评审者得分相关联.
- 评估技能水平之间的生物力学差异.
主要方法:
- 六个高级别和六个中间级别的情侣表演了维也纳华尔兹.
- 测量了骨盆和胸脊的三轴旋转角速度.
- 评委使用绝对判断系统对技术质量进行了评分.
主要成果:
- 在骨盆和胸脊角速度和评审者得分 (p=0.0240) 之间发现了强烈的关联.
- 这种关系是独立于舞者的技能水平.
- 移动动态显著影响了技术质量评分.
结论:
- 骨盆和胸部运动的测量和分析为评估舞蹈技巧提供了有价值的工具.
- 这种方法提供了快速,有效的定性和定量生物机械评估.
- 它可以用于舞蹈运动中的一般评估和特定组件分析.
更多相关视频
 06:52
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
7.9K
 08:45
Kinematic Analysis Using 3D Motion Capture of Drinking Task in People With and Without Upper-extremity Impairments
Published on: March 28, 2018
10.7K
相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
220
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
220
 01:25
Relative Motion Analysis using Rotating Axes
461
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
461
 01:10
Relative Motion Analysis - Acceleration
359
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
359
 01:30
Kinematic Equations for Rotation
325
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
325
 01:21
Rigid Body Equilibrium Problems - II
7.0K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.0K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
404
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
404