
一种基于标记的方法来确定手指关节的旋转中心
Martina Lapresa1, Eugenio Guglielmelli1, Loredana Zollo1
1Research Unit of Advanced Robotics and Human-Centred Technologies, Università Campus Bio-Medico di Roma, Via Alvaro del Portillo, 21, Roma, 00128, Italy.
Computer methods and programs in biomedicine
|February 6, 2024

概括
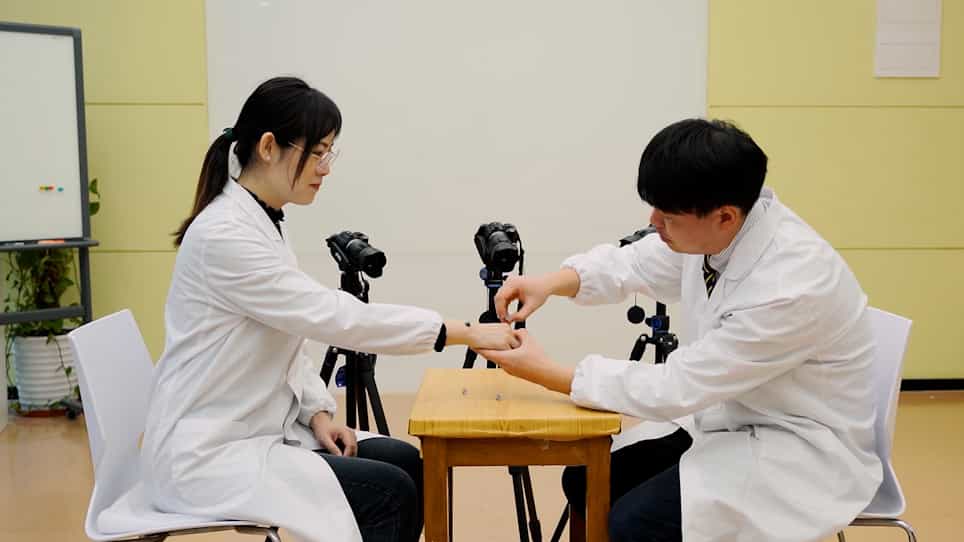
这项研究引入了一种更简单,更快速的方法,使用普拉特圆圈适合从标记数据估计手指关节旋转中心 (CoRs). 新技术实现了高精度和可重复性,与现有方法相比,但使用的标记较少.
科学领域:
- 生物力学 生物力学
- 人类运动分析分析
- 机器人技术 机器人技术 机器人技术
背景情况:
- 估计关节旋转中心 (CoRs) 通常需要复杂的优化和许多标记器.
- 现有的方法往往缺乏通过现实世界的实验收购来验证.
- 目前的方法主要集中在模拟准确性评估上.
研究的目的:
- 提出一种新的,计算效率高的程序,用基于标记的数据来估计2D联合COR.
- 为了利用普拉特圆适合于简化的COR估计.
- 通过实验收购来验证方法的准确性,可重复性和解剖学可信性.
主要方法:
- 使用普拉特圆合算法进行二维COR估计.
- 应用平面和脱的手指关节运动的简化假设.
- 在一个人形机器人手和五名健康志愿者身上验证了该方法.
主要成果:
- 在COR估计中获得了高精度 (x和y坐标中的0.70mm和0.18mm误差).
- 证明了出色的重复性,标准偏差低于2毫米和1毫米.
- 报告的解剖学可信率在80%至100%之间.
结论:
- 基于普拉特的COR估计程序是准确的和可重复的.
- 与现有技术相比,该方法在简单性和减少标记器要求方面具有优势.
- 这种方法为生物力学分析中共同的COR估计提供了一个计算效率高的替代方案.

相关概念视频
 01:30
Kinematic Equations for Rotation
325
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
325
 01:25
Relative Motion Analysis using Rotating Axes
461
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
461
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
404
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
404
 01:26
Rotational Motion about a Fixed Axis
481
A rigid body's rotation around a fixed axis makes every point within it trace a circular path around a specific line or point. The term given to this type of spinning is defined by the angular position, symbolized by the angle θ. This angle is gauged from a static reference line to the revolving object. From this angular position, any variation is referred to as angular displacement, denoted by dθ. The extent of this displacement can be calculated in degrees, radians, or...
481
 01:09
Bones of the Upper Limb: Radius
2.2K
The radius is longer of the two bones that make up the human antebrachium or forearm. At the proximal end, the radius articulates with the capitulum of the humerus and the radial notch of the ulna to form the elbow joint. At the distal end, the radius articulates with the ulna via the ulnar notch, forming the distal radioulnar joint. Distally, the radius also attaches to the carpal wrist bones (scaphoid and lunate) to form the radiocarpal joint.
The radius has a nail-shaped head, and a...
The radius has a nail-shaped head, and a...
2.2K
 01:10
Mohr's Circle for Moments of Inertia
598
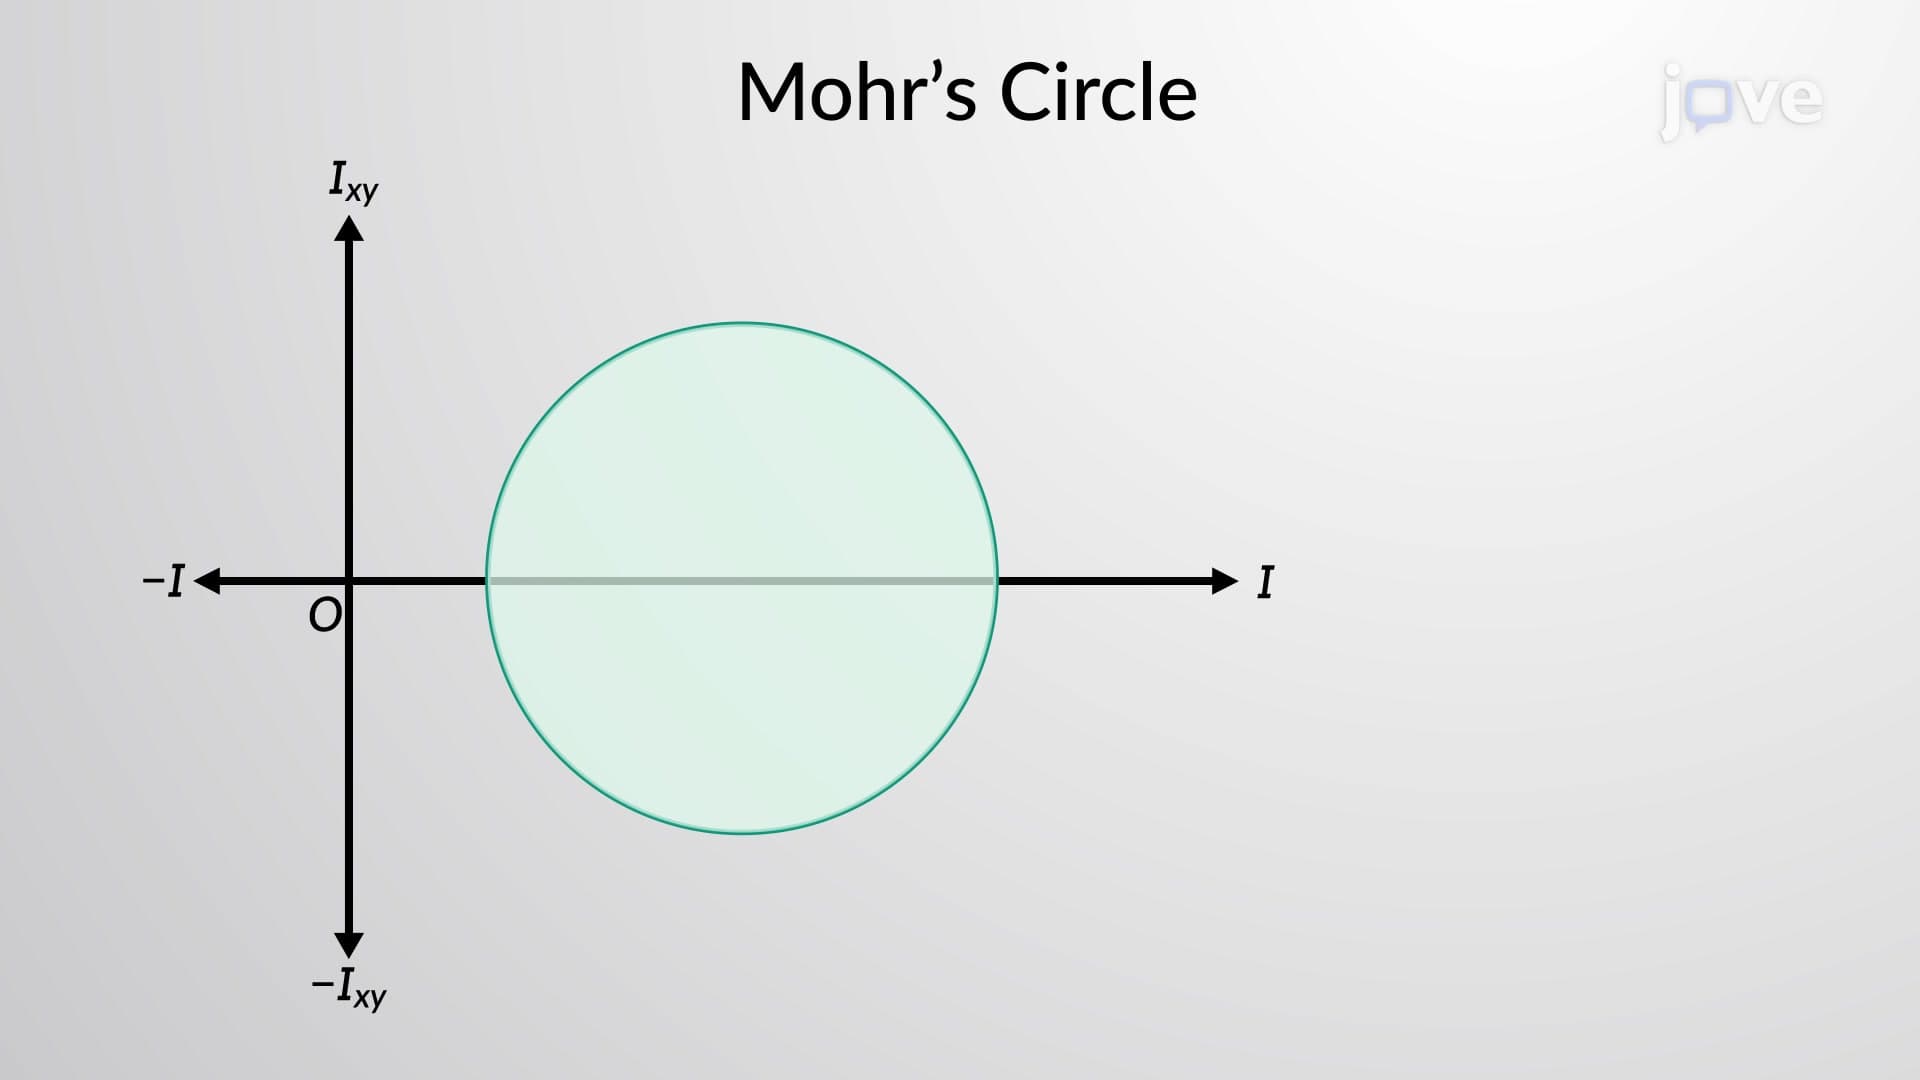
Mohr's circle is a graphical method to determine an area's principal moments of inertia by plotting the moments and product of inertia on a rectangular coordinate system.
598