相关实验视频
Updated: Jul 3, 2025
10:41
Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
17.6K
使用旋转调制技术的MEMS带式惯性态度测量系统
Wei Sun1, Heng Huang1, Peilun Sun1
1School of Geomatics, Liaoning Technical University, Fuxin, China.
PloS one
|February 13, 2024

概括
这项研究介绍了一种基于MEMS的旋转Strapdown惯性态度测量系统 (SIAMS),通过IMU旋转自动补偿传感器偏差. 这种方法提高了姿态准确性,使MEMS系统与战术级单位具有竞争力.
科学领域:
- 导航系统工程 导航系统工程
- 传感器技术 传感器技术
- 机械电子学是什么意思 机械电子学
背景情况:
- 态度的确定对于跟踪移动的物体至关重要.
- 微电机系统 (MEMS) 传感器提供了经济实惠的态度测量,但需要校准.
- 现有的Strapdown惯性态度测量系统 (SIAMS) 需要对错误进行补偿.
研究的目的:
- 开发一个基于MEMS的自动偏差补偿旋转SIAMS.
- 为了实现与战术级惯性测量单元 (IMU) 相当的性能.
- 通过调节和补偿传感器错误来提高MEMS立场准确度.
主要方法:
- 根据错误误调整关系推导出一个MEMS校准模型.
- 应用多位置旋转校准方法来估计确定性传感器错误 (偏差,尺度因子,错位).
- 在SIAMS中通过IMU旋转利用自动传感器偏差补偿.
主要成果:
- 拟议的旋转SIAMS有效调节和补偿MEMS传感器错误.
- 模拟和实验结果表明,立场准确度有所提高.
- 该系统的性能与战术级IMU相当.
结论:
- 开发的基于MEMS的旋转SIAMS提供了一个具有成本效益的解决方案,用于准确的态度确定.
- 通过IMU旋转自动偏差补偿可以显著提高MEMS传感器的性能.
- 这种方法弥合了MEMS和战术级惯性系统之间的性能差距.
相关概念视频
 01:02
Gyroscope
3.0K
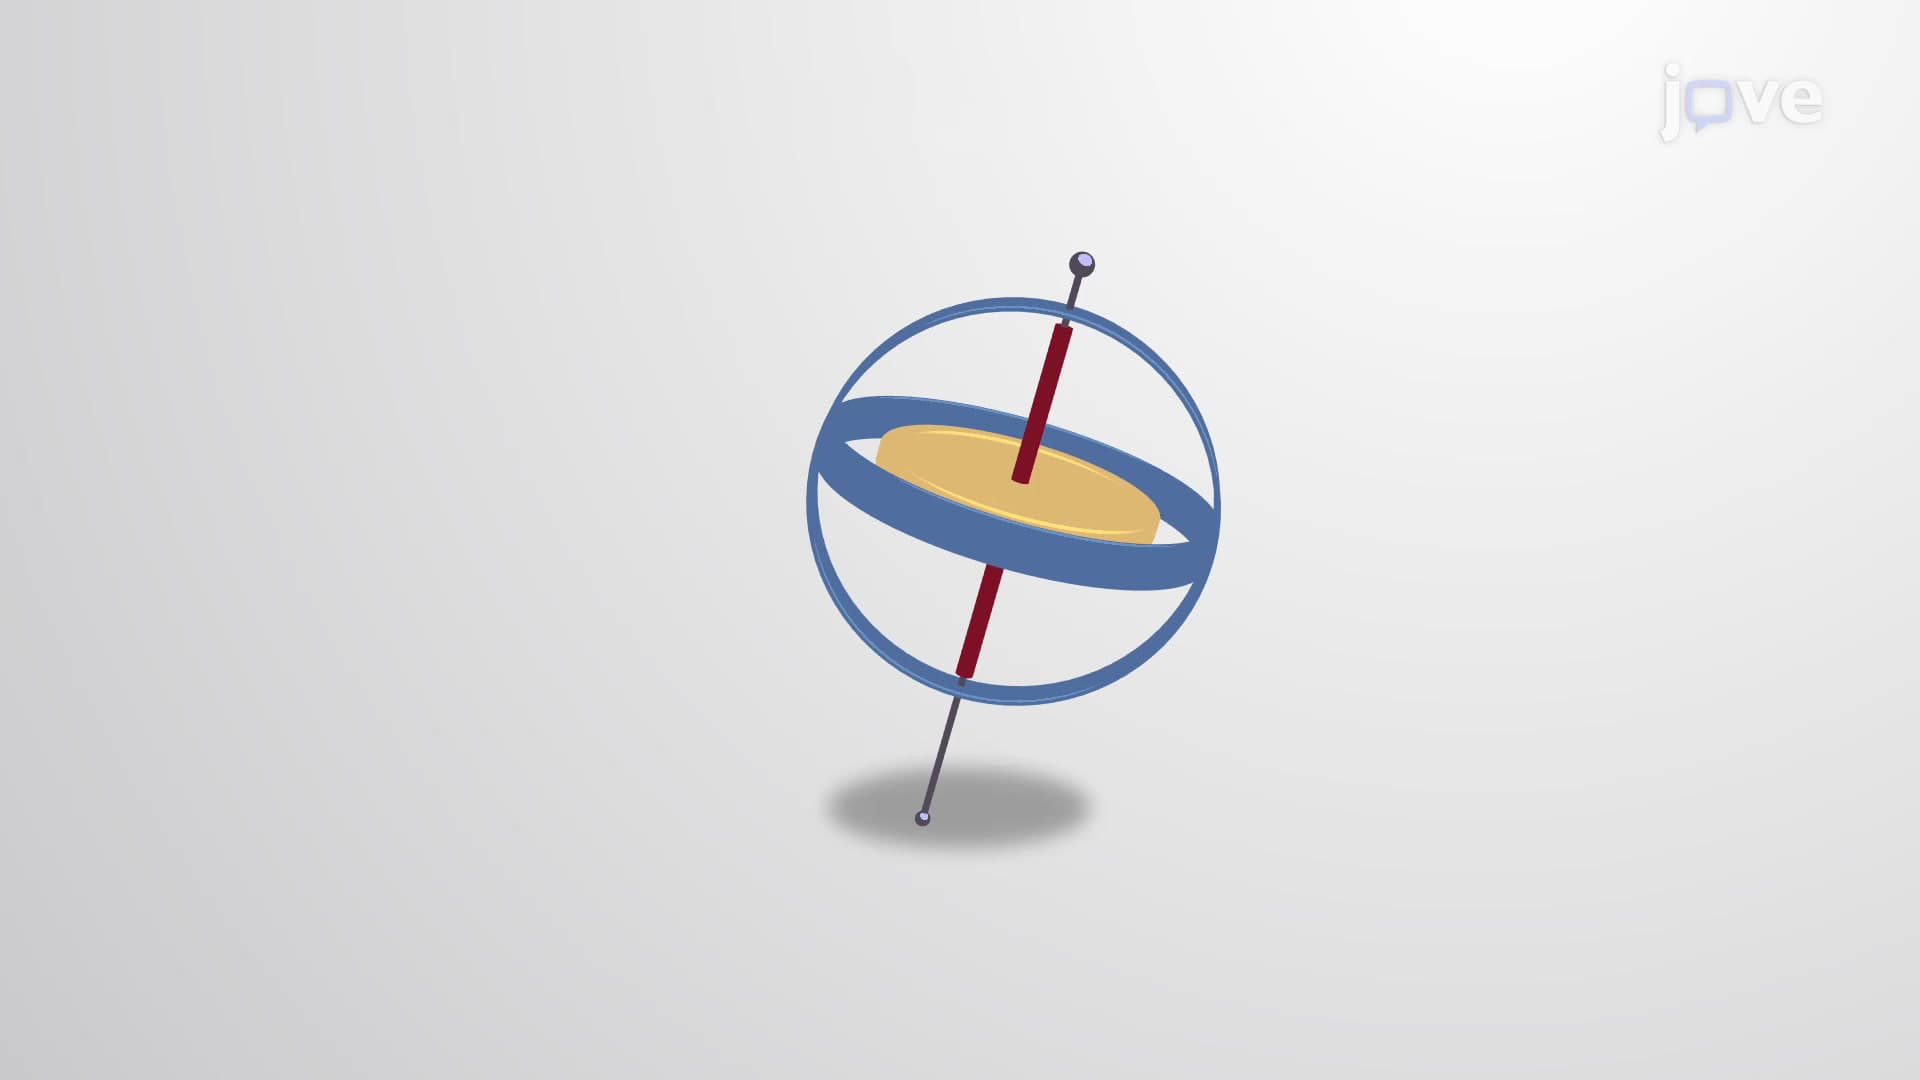
A gyroscope is defined as a spinning disk in which the axis of rotation is free to assume any orientation. When spinning, the orientation of the spin axis is unaffected by the orientation of the body that encloses it. The body or vehicle enclosing the gyroscope can be moved from place to place, while the orientation of the spin axis remains the same. This makes gyroscopes very useful in navigation, especially where magnetic compasses cannot be used, such as in crewed and crewless spacecraft,...
3.0K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
404
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
404
 01:25
Relative Motion Analysis using Rotating Axes
461
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
461