跨任务绑定:在学习连续运动序列时,表达的发展
Stefan Panzer1, Christina Pfeifer2, Luca Daniel2
1Saarland University, Germany; Texas A&M University, USA.
Human movement science
|February 15, 2024

概括
跨任务的绑定链接是任务之间的响应. 这项研究发现,在序列学习中结合视觉和听觉线索并不依赖于以前理论化的多维系统.
科学领域:
- 认知心理学 认知心理学
- 神经科学是一个神经科学.
- 运动学习是指运动学习.
背景情况:
- 跨任务绑定将不同任务之间的刺激/反应连接起来.
- 序列学习涉及开发有序信息的内部表示.
- 两系统理论假设单独的单维和多维系统进行序列表示.
研究的目的:
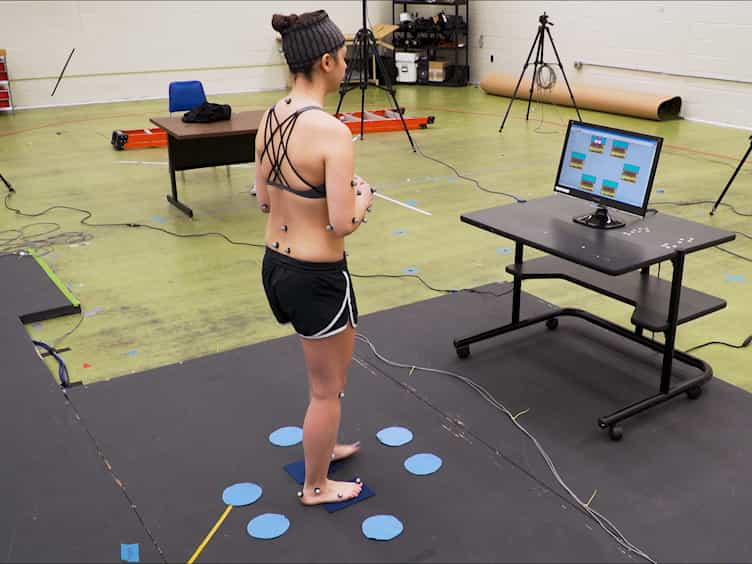
- 在连续运动序列任务中调查跨任务绑定.
- 检查听觉刺激 (音调) 在运动序列表示中的作用.
- 测试序列表示是否依赖于跨任务绑定中的多维系统.
主要方法:
- 采用了手工间传输设计来区分序列表示.
- 参与者执行了一个连续的运动序列任务与听觉音调配对.
- 镜子和非镜子转移测试评估了运动和空间坐标依赖.
主要成果:
- 研究了连续结合视觉空间位置和听觉维度 (音调) 的研究.
- 结果表明,这种组合表示并不依赖于多维系统.
- 这与序列学习的双系统理论的预测相矛盾.
结论:
- 在跨任务绑定语境中开发的表示可能不仅仅取决于一个多维系统.
- 具有集成感官信息的运动序列学习可能利用不同的表示策略.
- 需要进一步的研究来阐明跨任务绑定和序列表示的精确机制.
相关概念视频
 01:18
Hierarchy of Motor Control
2.7K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
2.7K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
402
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
402
 01:27
Associative Learning
362
Associative learning is a fundamental concept in behavioral psychology, wherein a connection is established between two stimuli or events, leading to a learned response. This process is critical in understanding how behaviors are acquired and modified. Conditioning, the mechanism through which associations are formed, can be divided into two main types: classical conditioning and operant conditioning, each elucidating different aspects of associative learning.
Classical conditioning, also known...
Classical conditioning, also known...
362
 01:26
Per-Unit Sequence Models
74
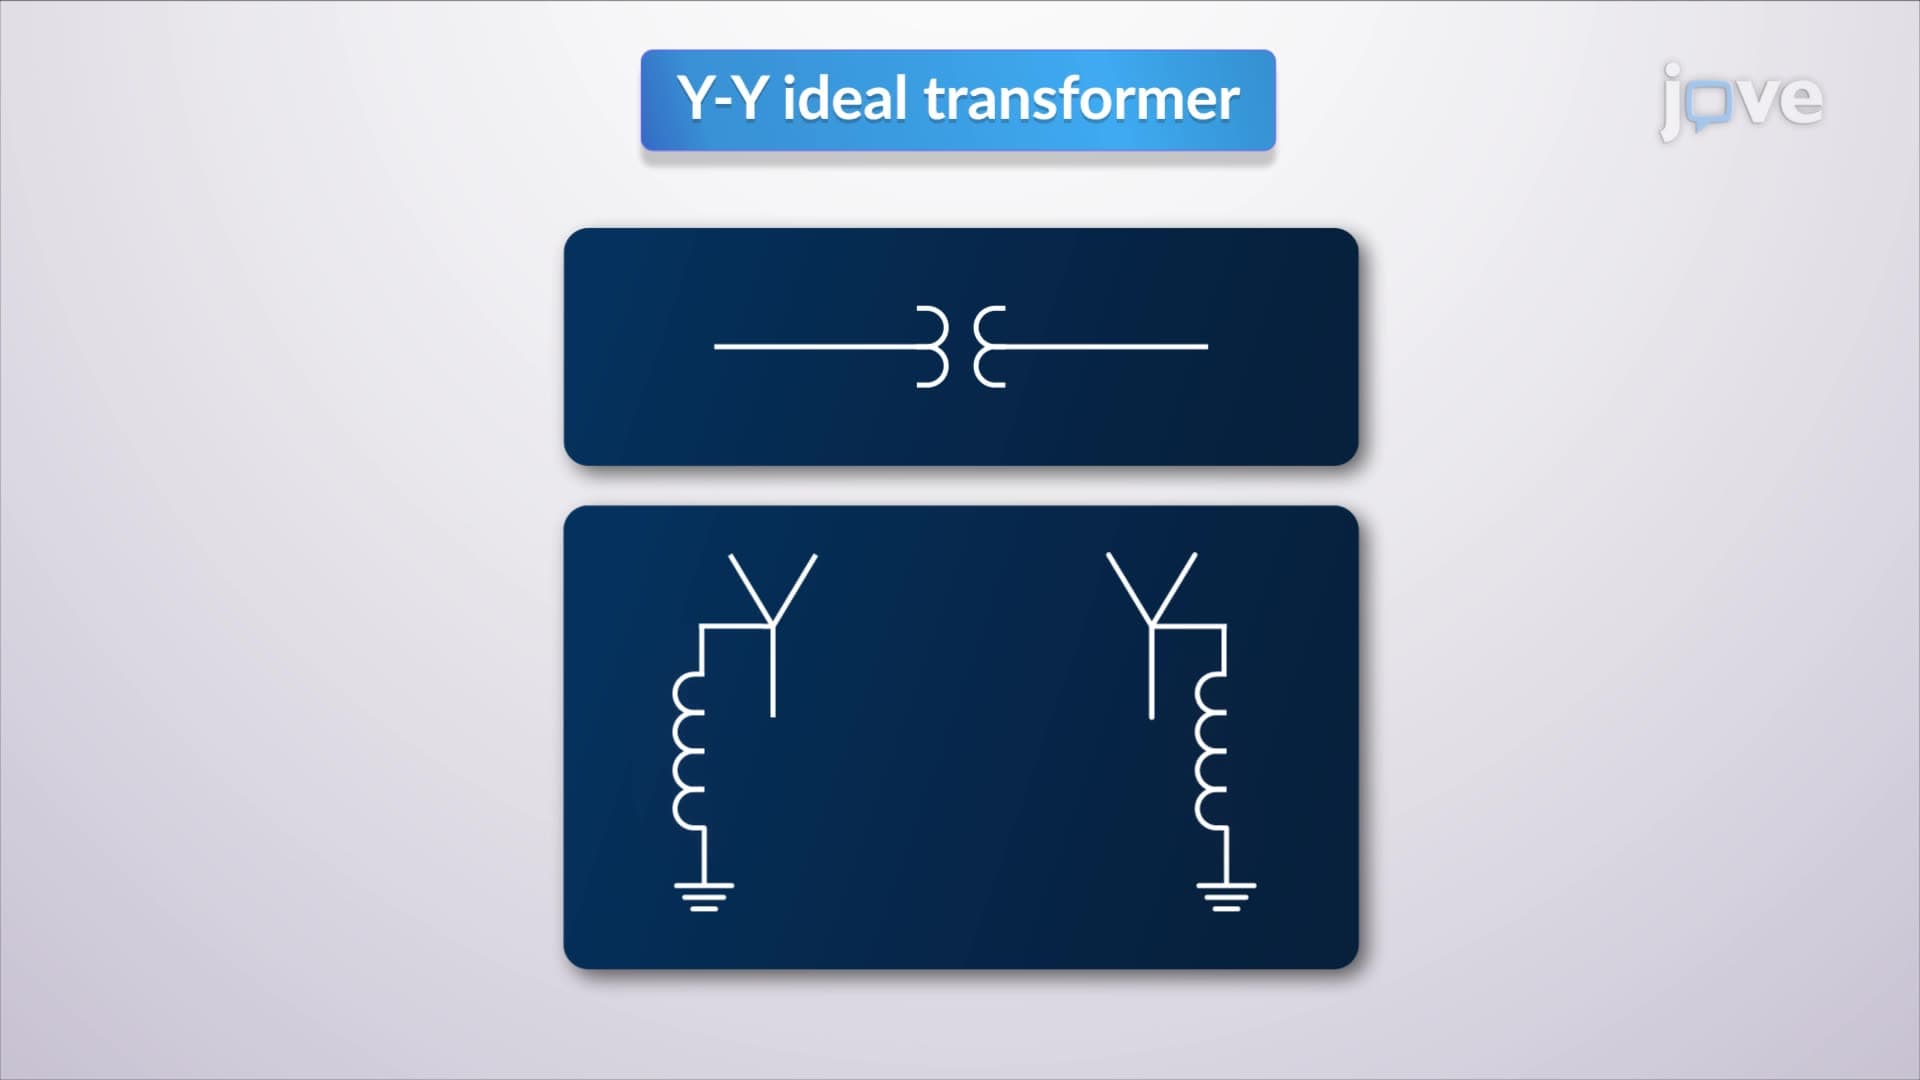
An ideal Y-Y transformer, grounded through neutral impedances, displays per-unit sequence networks akin to those of a single-phase ideal transformer when subjected to balanced positive- or negative-sequence currents. These currents do not produce neutral currents, and their associated voltage drops.
Zero-sequence currents, which are identical in magnitude and phase, generate a neutral current, resulting in voltage drops across the neutral impedance and the low-voltage winding. If the...
Zero-sequence currents, which are identical in magnitude and phase, generate a neutral current, resulting in voltage drops across the neutral impedance and the low-voltage winding. If the...
74
 01:24
Sequence Networks of Rotating Machines
103
A Y-connected synchronous generator, grounded through a neutral impedance, is designed to produce balanced internal phase voltages with only positive-sequence components. The generator's sequence networks include a source voltage that is exclusively in the positive-sequence network. The sequence components of line-to-ground voltages at the generator terminals illustrate this configuration.
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
103
 01:15
Kinematic Equations: Problem Solving
12.4K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
12.4K