
通过光谱图学习马科夫动力学
Jakub Rydzewski1, Tuğçe Gökdemir1
1Institute of Physics, Faculty of Physics, Astronomy and Informatics, Nicolaus Copernicus University, Grudziadzka 5, 87-100 Toruń, Poland.
The Journal of chemical physics
|March 4, 2024

概括
这项研究引入了一种改进的光谱图技术,用于识别关键分子动态描述符,称为集体变量 (CV). 该方法准确地学习缓慢的CV,增强复杂分子系统的分析.
科学领域:
- 计算化学计算化学
- 分子动力学分子动力学
- 机器学习 机器学习
背景情况:
- 复杂的分子系统通常会在由集体变量 (CV) 定义的缓慢子空间中表现出马科维动力学.
- 确定准确的简历是一个重大挑战,传统的方法依赖于直觉或试错.
- 不准确的简历可以导致非马科夫动态,引入复杂分析的记忆效应.
研究的目的:
- 增强光谱图的深度学习技术,用于学习缓慢的集体变量 (CV).
- 提高异质和多尺度自由能源景观的代表性.
- 为分析分子系统的长期行为提供强大的方法.
主要方法:
- 开发和应用一个适应算法来估计过渡概率.
- 使用光谱图技术,通过最大化马尔科夫过渡矩阵的光谱间隙来学习缓慢的CV.
- 采用马尔科夫状态模型分析来验证学习的简历.
主要成果:
- 增强的光谱图成功地学习符合主导放松时间尺度的缓慢CV.
- 该方法有效地区分分子系统中长期存在的转移稳定状态.
- 实现了复杂的自由能源景观的准确表示.
结论:
- 改进的光谱图技术提供了一种强大的数据驱动方法,用于在分子模拟中识别相关的CV.
- 这一进步促进了复杂分子动态的更精确的建模和分析.
- 该方法有望加速化学过程和材料特性研究.
相关概念视频
 01:20
Region of Convergence of Laplace Tarnsform
547
The Region of Convergence (ROC) is a fundamental concept in signal processing and system analysis, particularly associated with the Laplace transform. The ROC represents an area in the complex plane where the Laplace transform of a given signal converges, determining the transform's applicability and utility.
Consider a decaying exponential signal that begins at a specific time. When deriving its Laplace transform, the time-domain variable is replaced with a complex variable. This...
Consider a decaying exponential signal that begins at a specific time. When deriving its Laplace transform, the time-domain variable is replaced with a complex variable. This...
547
 01:23
Linear time-invariant Systems
258
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
258
 01:27
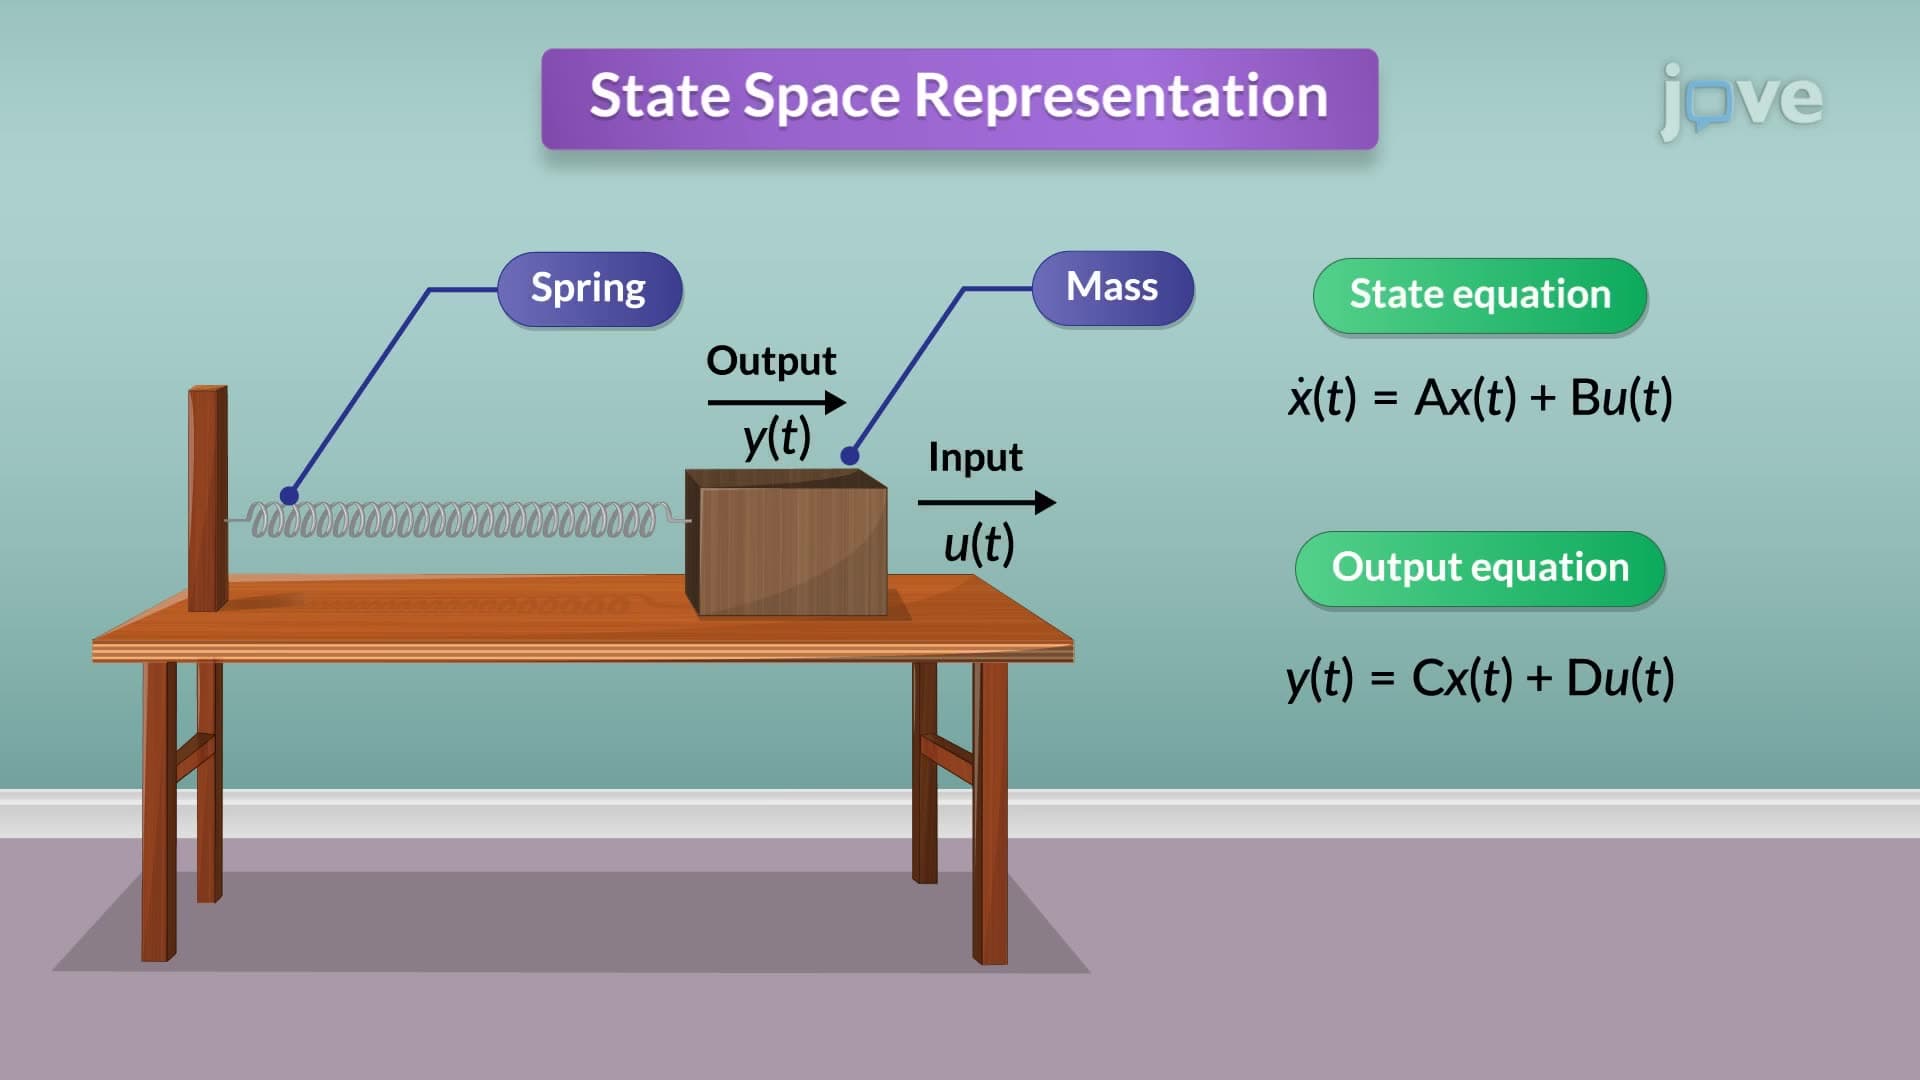
State Space Representation
207
The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Consider an RLC circuit, a...
207
 01:25
Poisson's And Laplace's Equation
2.8K
The electric potential of the system can be calculated by relating it to the electric charge densities that give rise to the electric potential. The differential form of Gauss's law expresses the electric field's divergence in terms of the electric charge density.
2.8K
 01:21
Linear Approximation in Time Domain
81
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
81
 01:21
State Space to Transfer Function
203
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
203