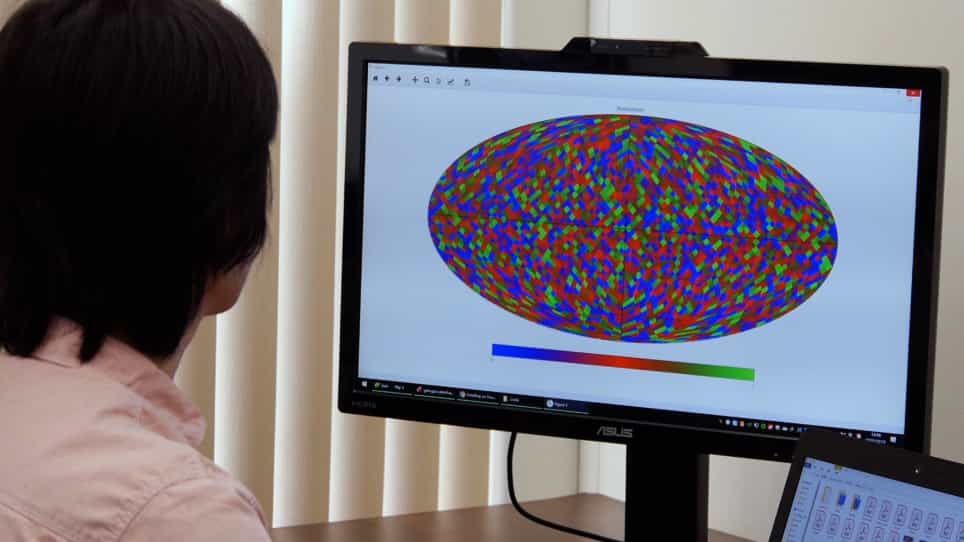

概括
在低光下精确的航天器姿势测量对于太空任务至关重要. 这项研究引入了一个立体视觉系统,使用先进的目标检测和适应性圆圈提取来进行精确的超近距离测量.
科学领域:
- 太空飞船工程 太空飞船工程
- 计算机视觉 计算机视觉 计算机视觉
- 机器人技术 机器人技术 机器人技术
背景情况:
- 精确的航天器姿势测量对于会议和对接等关键太空操作至关重要.
- 低光条件和超近距离范围对现有的测量技术构成重大挑战.
研究的目的:
- 开发一种强大的立体视觉解决方案,用于在低光,超近距离环境中准确地测量航天器的姿势.
- 为了提高特征检测和提取,提高空间测量可靠性.
主要方法:
- 实施了改进的目标检测算法,以加快特征对象识别.
- 开发了一种自适应的循环提取算法,以克服空间环境中的特征提取困难.
- 立体视觉原理用于3D姿势估计.
主要成果:
- 与YOLOv7_tiny.相比,增强的目标检测算法实现了参数数量的66.36%的减少.
- 适应性循环提取算法提高了11.4%的合作目标特征提取精度,同时保持了速度.
- 模拟实验表明实时位置误差低于0.18毫米,角度误差低于0.05°.
结论:
- 拟议的立体视觉系统为太空船在超近距离的姿势测量提供了可行和准确的解决方案,即使在具有挑战性的低光条件下也是如此.
- 开发的算法提高了效率和精度,解决了当前空间机器人感知系统的关键局限性.
相关概念视频
 01:18
Distance Measurements by Taping
38
Tapes are essential in surveying for accurate, durable, and short-distance measurements. Made from lightweight, nylon-coated steel, they offer flexibility and strength for rugged outdoor use. The nylon coating protects against rust and wear, extending the tape's life. Standard lengths, around 30 meters, are marked in meters and millimeters for precision.Surveyors select tapes based on site conditions and accuracy needs. Lightweight, nylon-coated tapes are commonly used for ease of handling and...
38
 01:25
Relative Motion Analysis using Rotating Axes
460
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
460
 01:16
Circular Orbits and Critical Velocity for Satellites
2.9K
The Moon orbits around the Earth. In turn, the Earth (and other planets) orbit the Sun. The space directly above our atmosphere is filled with artificial satellites in orbit. One can examine the circular orbit, the simplest kind of orbit, to understand the relationship between the speed and the period of planets and satellites with respect to their positions and the bodies that they orbit.
Nicolaus Copernicus (1473-1543) first suggested that the Earth and all other planets orbit the Sun in...
Nicolaus Copernicus (1473-1543) first suggested that the Earth and all other planets orbit the Sun in...
2.9K
 01:19
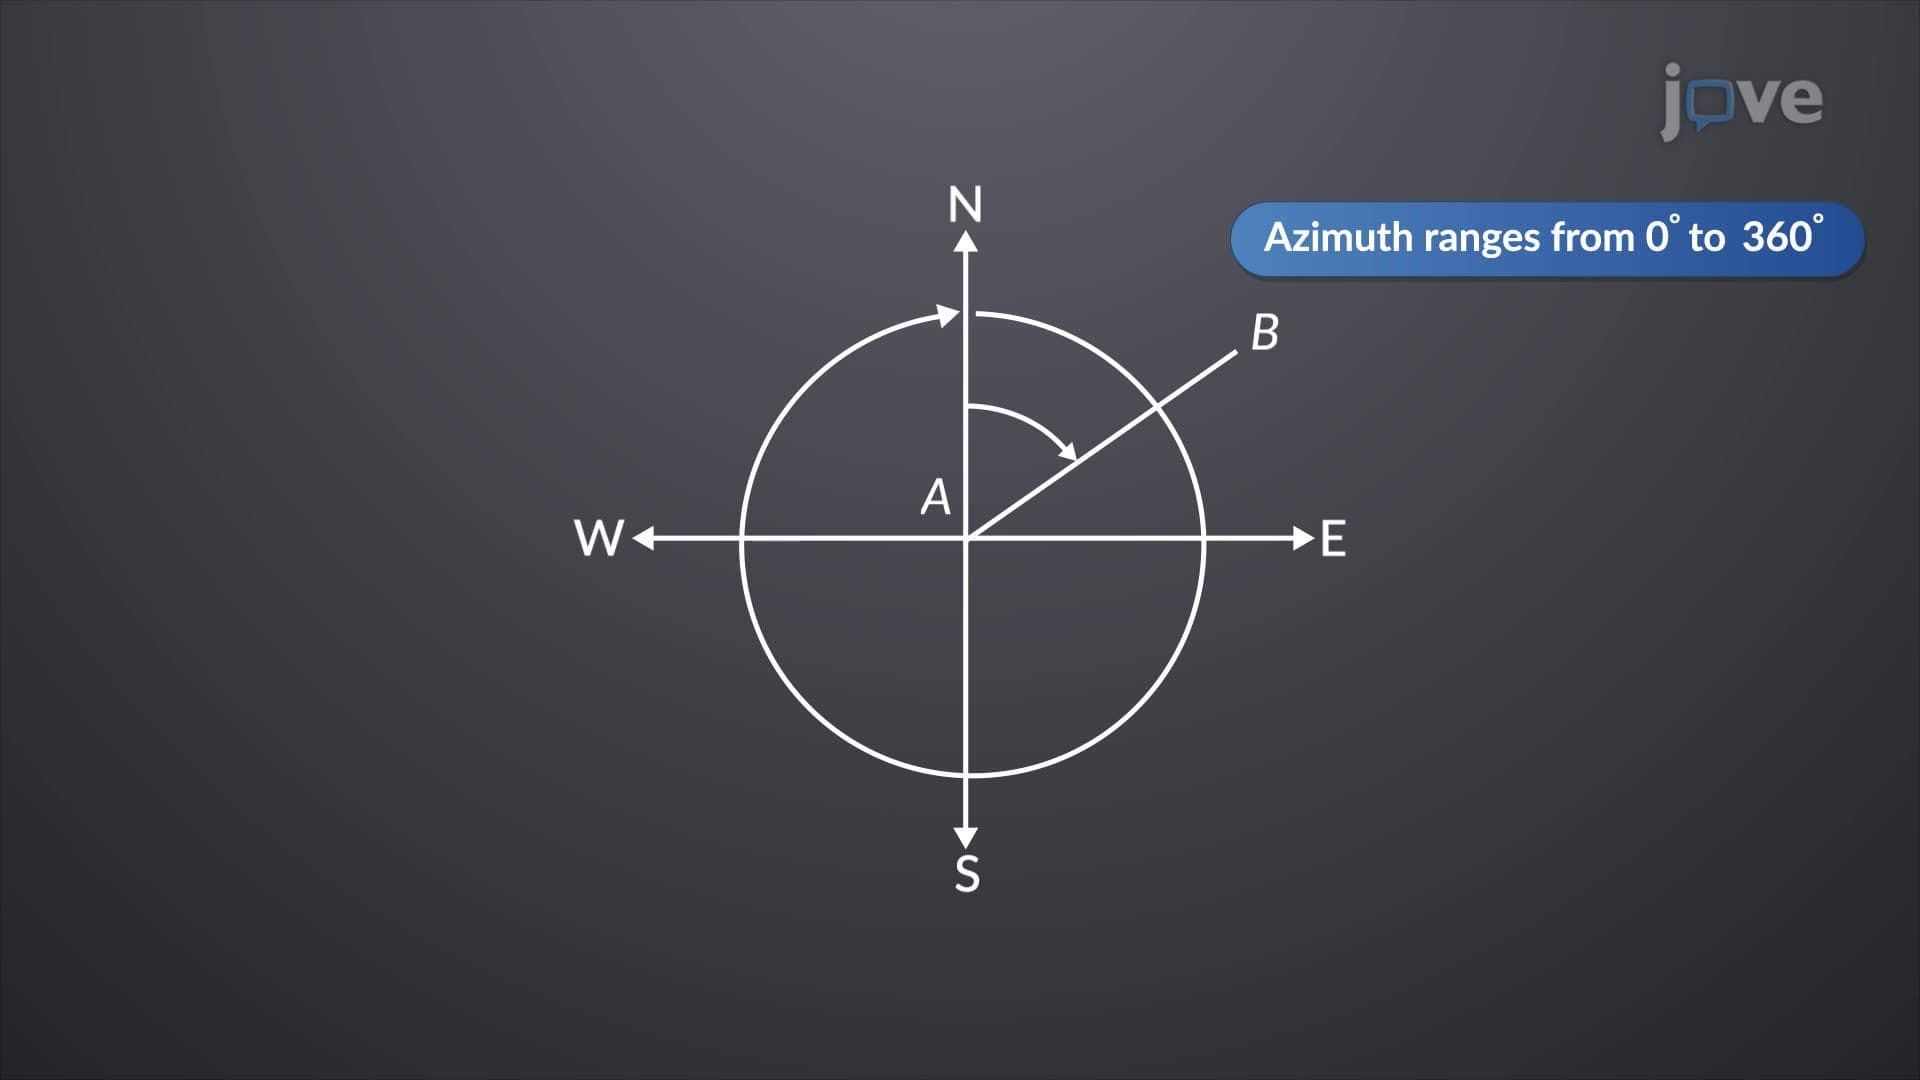
Azimuths and Bearings
120
Azimuths and bearings are essential concepts in surveying, providing methods to express the direction of a line relative to a meridian. Azimuths refer to the clockwise angle measured from the north end of a reference meridian to the given line, ranging from zero to 360 degrees. This method gives a comprehensive directional reference within a full 360-degree circle, making it a straightforward way to communicate direction in various fields, including navigation, cartography, and...
120
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
402
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
402
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
335
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
335