相关实验视频
Updated: Jul 1, 2025

08:12

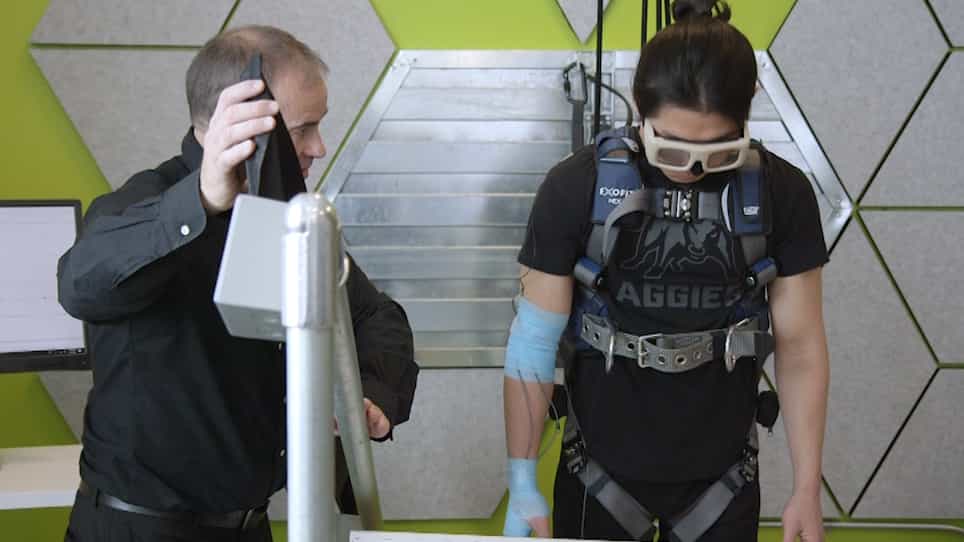
Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
9.5K
适应性状态限制障碍基于斯图尔特平台的利亚普诺夫控制,用于作为脚控制的动员器
Sandra Marlene Cobian-Aquino1, Jose Eduardo Mendoza-Guerrero1, Jorge Danel-Muñoz1
1Escuela de Ingenieria y Ciencias, Tecnologico de Monterrey, Mexico.
ISA transactions
|March 5, 2024

概括
研究人员使用斯图尔特平台和自适应控制开发了一种机器人脚整形,以安全地限制脚损伤患者的运动. 这种新的机械电子设备提供了一种新的治疗方法,通过人类测试来验证.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 生物力学 生物力学
- 控制系统工程 控制系统工程
背景情况:
- 脚损伤显著影响了运动能力.
- 现有的整形器件可能缺乏精确的运动控制.
- 康复需要新的机械机械解决方案.
研究的目的:
- 设计,建造和验证一个机器人活动脚整形.
- 实施具有状态约束的自适应增益控制策略.
- 为了评估关节康复的限制运动的形的有效性.
主要方法:
- 基于六条腿的斯图尔特平台开发了一种闭链机器人活跃脚整形.
- 采用了自适应性增益控制策略,具有状态依赖的增益和类似于Lyapunov的功能.
- 实验验证包括对人类志愿者的测试和与常规对照进行比较.
主要成果:
- 适应性控制策略确保了在状态约束中追踪错误的趋同和局限性.
- 形成功地限制了志愿者在预先定义的区域内的运动范围.
- 拟议的控制器在外部干扰下表现优于常规状态反.
结论:
- 开发的机器人脚整形器具为治疗脚损伤提供了安全有效的机电解决方案.
- 适应性控制策略保证在状态约束下稳定性和性能.
- 这项技术为脚康复和运动管理提供了一种新的方法.
更多相关视频
 07:19
A Modified Lean and Release Technique to Emphasize Response Inhibition and Action Selection in Reactive Balance
Published on: March 19, 2020
5.9K
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
10.5K
相关概念视频
 01:19
Root-Locus Method
151
A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block...
This system can be represented by a block...
151
 01:24
One-Degree-of-Freedom System
488
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
488