
通过对统计数据的观察来过动态系统
Eviatar Bach1,2, Tim Colonius3, Isabel Scherl3
1Department of Environmental Science and Engineering, California Institute of Technology, Pasadena, California 91125, USA.
Chaos (Woodbury, N.Y.)
|March 8, 2024

概括
本研究介绍了整体福克-普朗克波器 (EnFPF),用于从统计观测中估计系统密度. EnFPF为复杂的过问题提供了实用方法,提高了各种动态系统的准确性和融合.
科学领域:
- 动态系统理论 动态系统理论
- 随机过程是指随机的过程.
- 计算统计的计算统计.
背景情况:
- 标准过问题依赖于状态观察,而不是统计观察.
- 从杂的统计数据中估计时间变化的密度在计算上具有挑战性.
- 在密度空间中无限维的过通常是难以处理的.
研究的目的:
- 开发一种可处理的状态空间算法,使用统计观测来过动态系统.
- 介绍整体福克-普朗克波器 (EnFPF) 作为一种新的计算方法.
- 为了证明EnFPF的有效性超越理论限制.
主要方法:
- 制定一个平均场状态空间模型.
- 利用相互作用的粒子系统进行近似.
- 基于这些近似,开发一个集体方法.
主要成果:
- 在特定假设下,EnFPF对福克-普朗克方程的卡尔曼-布西波器进行了近似.
- 数字实验证实了EnFPF在纠正集合统计中的实用性.
- 该方法加速了对自主和非自主系统的不变密度的趋同.
结论:
- 整体福克-普朗克波器 (EnFPF) 提供了一种可行的解决方案,用于使用统计观测在动态系统中的密度估计.
- EnFPF对气候建模和流研究中的应用有希望.
- 该方法将过技术的功能扩展到更广泛的复杂系统中.
相关概念视频
 01:21
Linear Approximation in Time Domain
81
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
81
 01:18
Second Order systems II
109
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
109
 01:31
Classification of Systems-II
146
Continuous-time systems have continuous input and output signals, with time measured continuously. These systems are generally defined by differential or algebraic equations. For instance, in an RC circuit, the relationship between input and output voltage is expressed through a differential equation derived from Ohm's law and the capacitor relation,
146
 01:26
Classification of Systems-I
186
Linearity is a system property characterized by a direct input-output relationship, combining homogeneity and additivity.
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
186
 01:21
First Order Systems
90
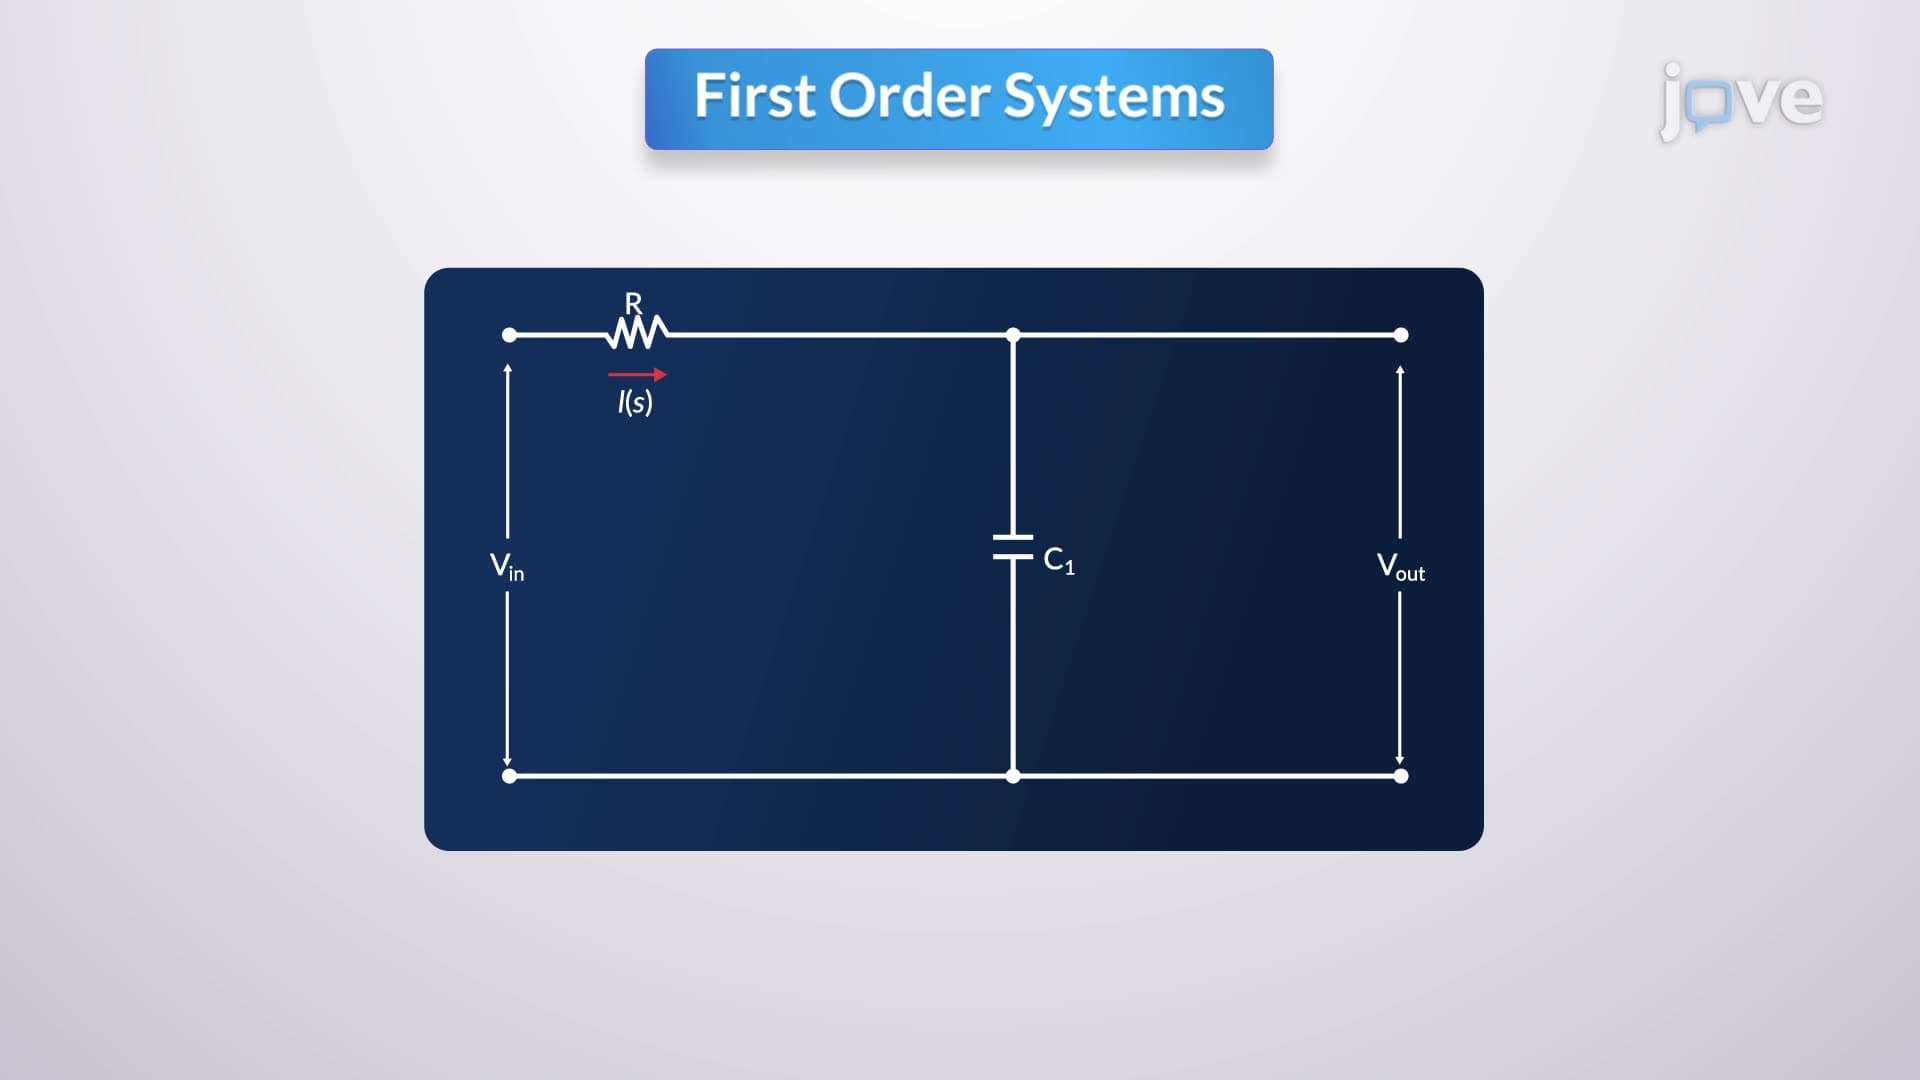
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
90
 01:26
Feedback control systems
308
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
308