
在克罗地亚亚得里亚海沿岸浅的木头海的时空空间分析
Željko Mihaljević1, Šimun Naletilić1, Jasna Jeremić2
1Croatian Veterinary Institute, Savska Cesta 143, 10000 Zagreb, Croatia.
Animals : an open access journal from MDPI
|March 13, 2024

概括
在克罗地亚浅的龙头鱼发现了季节性模式和高风险地区. 渔具和船只碰撞是主要的威胁,需要针对海 (Caretta caretta) 进行有针对性的保护工作.
科学领域:
- 海洋生物学 海洋生物学
- 保护科学 保护科学
- 野生动物生态生态学
背景情况:
- 龙头海 (Caretta caretta) 在海洋环境中面临着许多威胁.
- 了解浅模式对于有效的物种管理和保护至关重要.
研究的目的:
- 为了分析克罗地亚亚得里亚海沿岸木头的时空浅趋势.
- 为了确定鱼的关键息地和主要死亡原因.
主要方法:
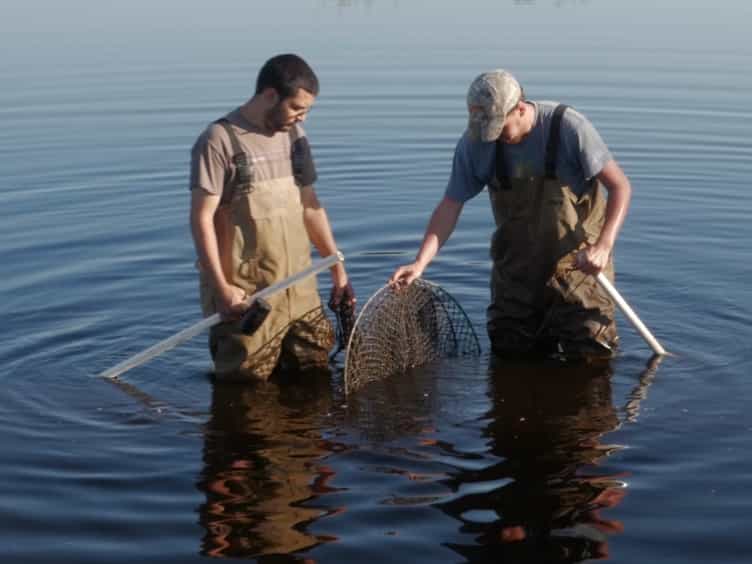
- 分析了2010年至2022年间620只木头乌 (Caretta caretta) 的流浪数据.
- 尸检调查以确定死亡原因.
- 确定高密度的滞留区域.
主要成果:
- 观察到明显的季节性浅变化,其丰度和年龄特定的死亡率具有特定的模式.
- 亚得里亚海东北部和中部的四个关键地区显示出高浅密度.
- 渔业引起的死亡率 (长渔具) 和船只碰撞被确定为年龄特定的重大威胁.
结论:
- 这些发现为区域管理者提供了一种保护鱼的工具.
- 在已识别的高风险地区需要有针对性的保护工作,以减轻人互动.
- 验尸后的调查对于了解死亡原因和改善保护策略至关重要.
相关概念视频
 01:17
Space-Time Curvature and the General Theory of Relativity
In 1905, Albert Einstein published his special theory of relativity. According to this theory, no matter in the universe can attain a speed greater than the speed of light in a vacuum, which thus serves as the speed limit of the universe.
This has been verified in many experiments. However, space and time are no longer absolute. Two observers moving relative to one another do not agree on the length of objects or the passage of time. The mechanics of objects based on Newton's laws of motion,...
This has been verified in many experiments. However, space and time are no longer absolute. Two observers moving relative to one another do not agree on the length of objects or the passage of time. The mechanics of objects based on Newton's laws of motion,...
 01:24
Absolute Motion Analysis- General Plane Motion
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:24
Relative Motion Analysis - Velocity
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:25
Relative Motion Analysis using Rotating Axes
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:17
Graphs of Polar Equations
The polar coordinate system represents points using a distance from a central point (the pole) and an angle from a reference direction (the polar axis). Unlike rectangular coordinates, polar coordinates are ideal for graphing curves with radial symmetry or periodic behavior.Some general forms of graphs in polar coordinates include the following:Equation of a Circle (Centered at the Pole):A graph where the radius remains constant for all angles traces a circle centered at the pole:Equation of a...