

膝盖绑架时刻与体和下肢段加速在运动特定运动中的关系
Mitchell Ekdahl1, Sophia Ulman1,2, Lauren Butler3,4
1Scottish Rite for Children, Frisco, TX 75034, USA.
Sensors (Basel, Switzerland)
|March 13, 2024

概括
可穿戴传感器 (IMU) 通过测量身体段加速来评估前十字带 (ACL) 损伤风险,为测量膝关节绑架时刻 (KAM) 的3D运动分析提供了具有成本效益的替代方案.
科学领域:
- 生物力学 生物力学
- 运动医学 运动医学
- 伤害预防 预防伤害
背景情况:
- 膝盖绑架时刻 (KAM) 是前十字带 (ACL) 损伤风险的一个关键指标.
- 目前的3D动态数据收集是昂贵和耗时的,需要更简单的评估方法.
- 可穿戴惯性测量单元 (IMU) 为伤害风险评估提供了潜在的现场解决方案.
研究的目的:
- 为了研究KAM和体段加速之间的关系.
- 评估使用IMU用于在运动特定运动期间估计KAM的可行性.
主要方法:
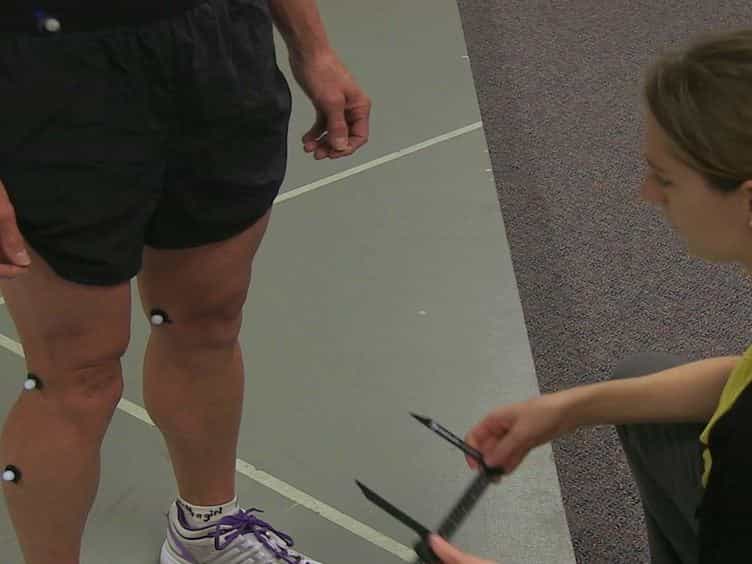
- 试点研究使用光学运动捕捉和力板来测量峰值KAM.
- 使用可穿戴IMU同时测量峰值三轴段加速.
- 对三个功能任务的分析:单脚跳跃,减速和45度切割.
主要成果:
- 在单腿跳跃期间,在峰值KAM和峰值加速之间发现了中等的相关性.
- 在减速过程中与KAM相关的峰值干部,大腿和腿部加速.
- 峰干,骨盆和腿部加速显示在45度切割过程中与KAM有中等的相关性.
结论:
- 可穿戴的IMU显示出在运动活动期间估计峰值KAM的潜力.
- 来自IMU的加速数据可以作为KAM评估的可行代理.
- 这些发现支持进一步研究基于IMU的ACL损伤风险查.
相关概念视频
 01:23
Muscles that Move the Leg
1.7K
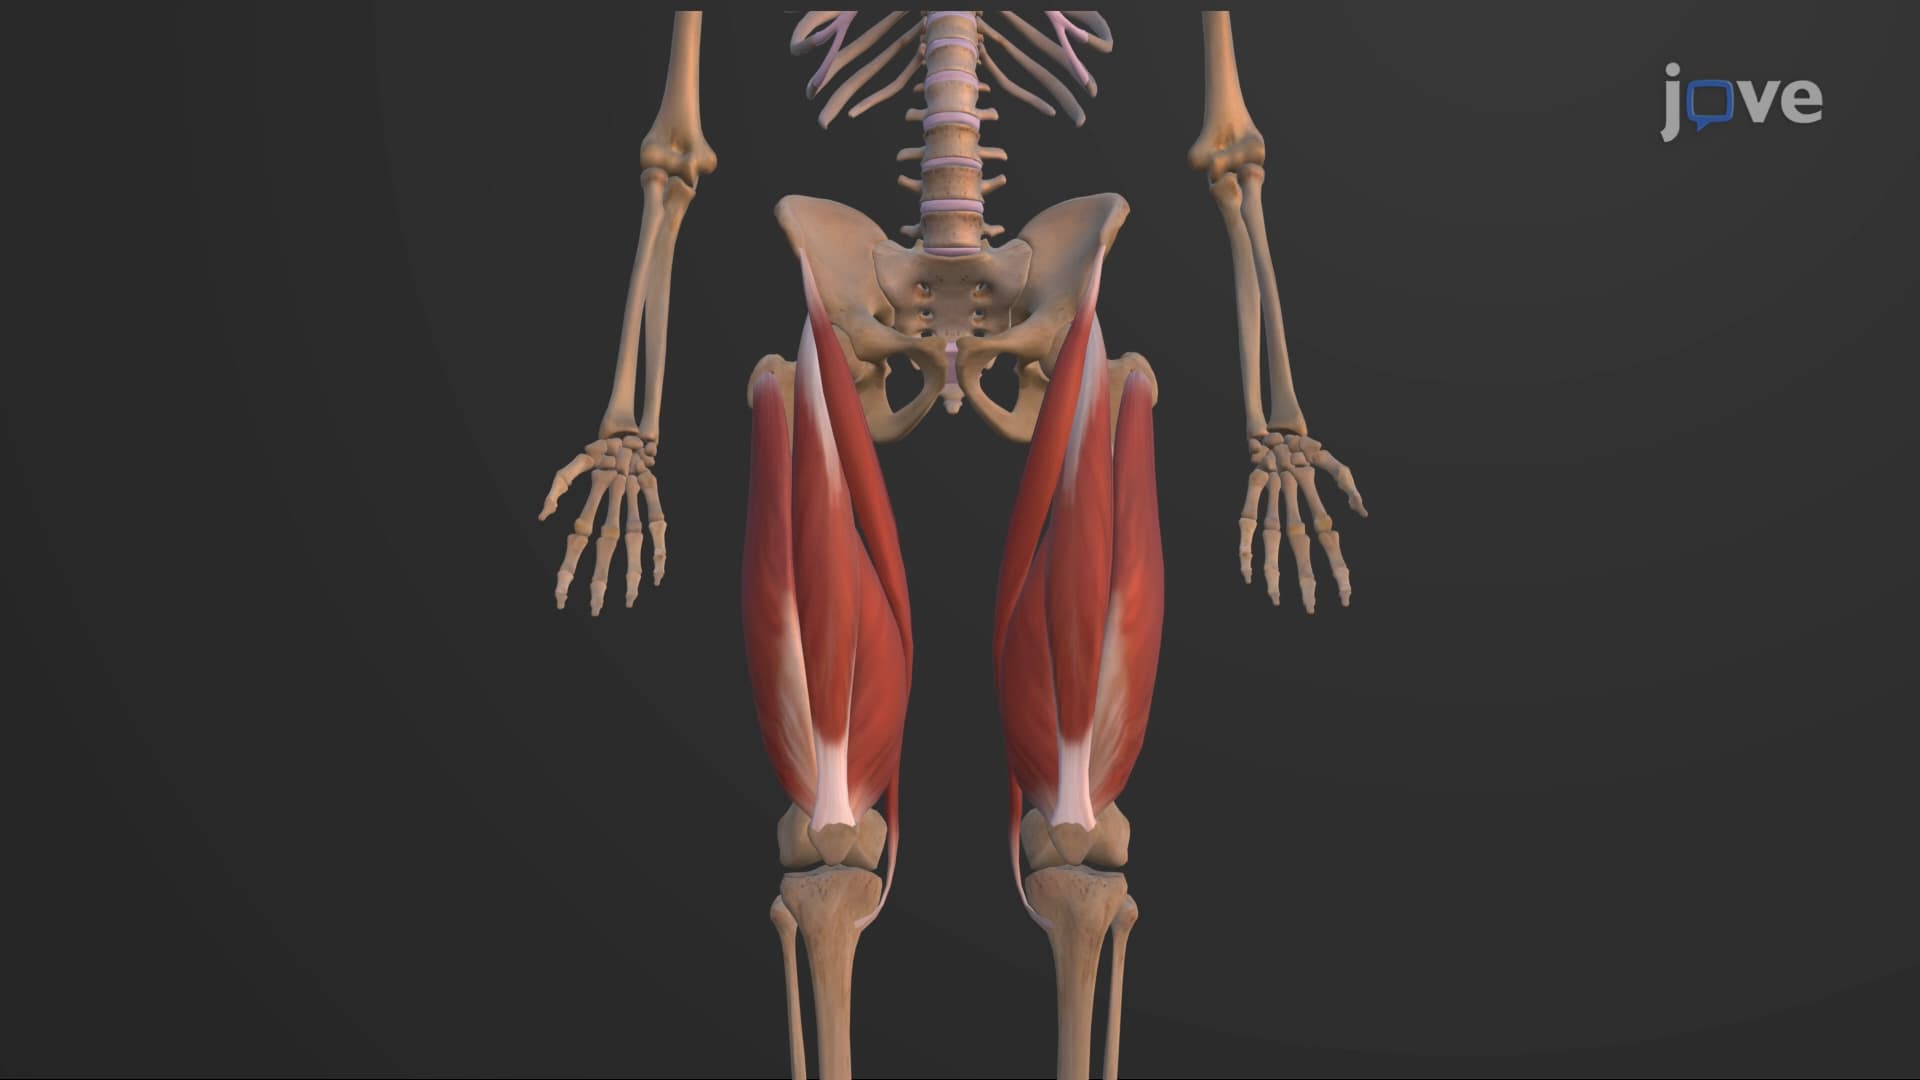
The movement of the legs is facilitated by numerous muscles located within the anterior, medial, and posterior compartments of the thigh.
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
1.7K
 01:16
Bones of the Lower Limb: Femur and Patella
2.5K
The femur is the body's longest and strongest bone spanning the thigh region. Its head articulates with the acetabulum of the hip bone to form the hip joint. A minor indentation on the medial side of the femoral head, called the fovea capitis, serves as the site of attachment for the ligament of the head of the femur. This weak ligament spans the femur and acetabulum and supports the hip joint. The narrowed region below the head is the neck of the femur. The inclination angle between the...
2.5K
 01:10
Relative Motion Analysis - Acceleration
357
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
357
 01:23
Knee Joint
1.8K
The knee joint is the most complicated joint in the body. It consists of three articulations– two tibiofemoral and one patellofemoral. As is characteristic of synovial joints, the knee joint has a thin articular capsule that partially surrounds this joint cavity. Additionally, several ligaments, muscles, and cartilaginous structures support the movement of the knee.
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
1.8K
 00:51
Anatomical Movements
7.1K
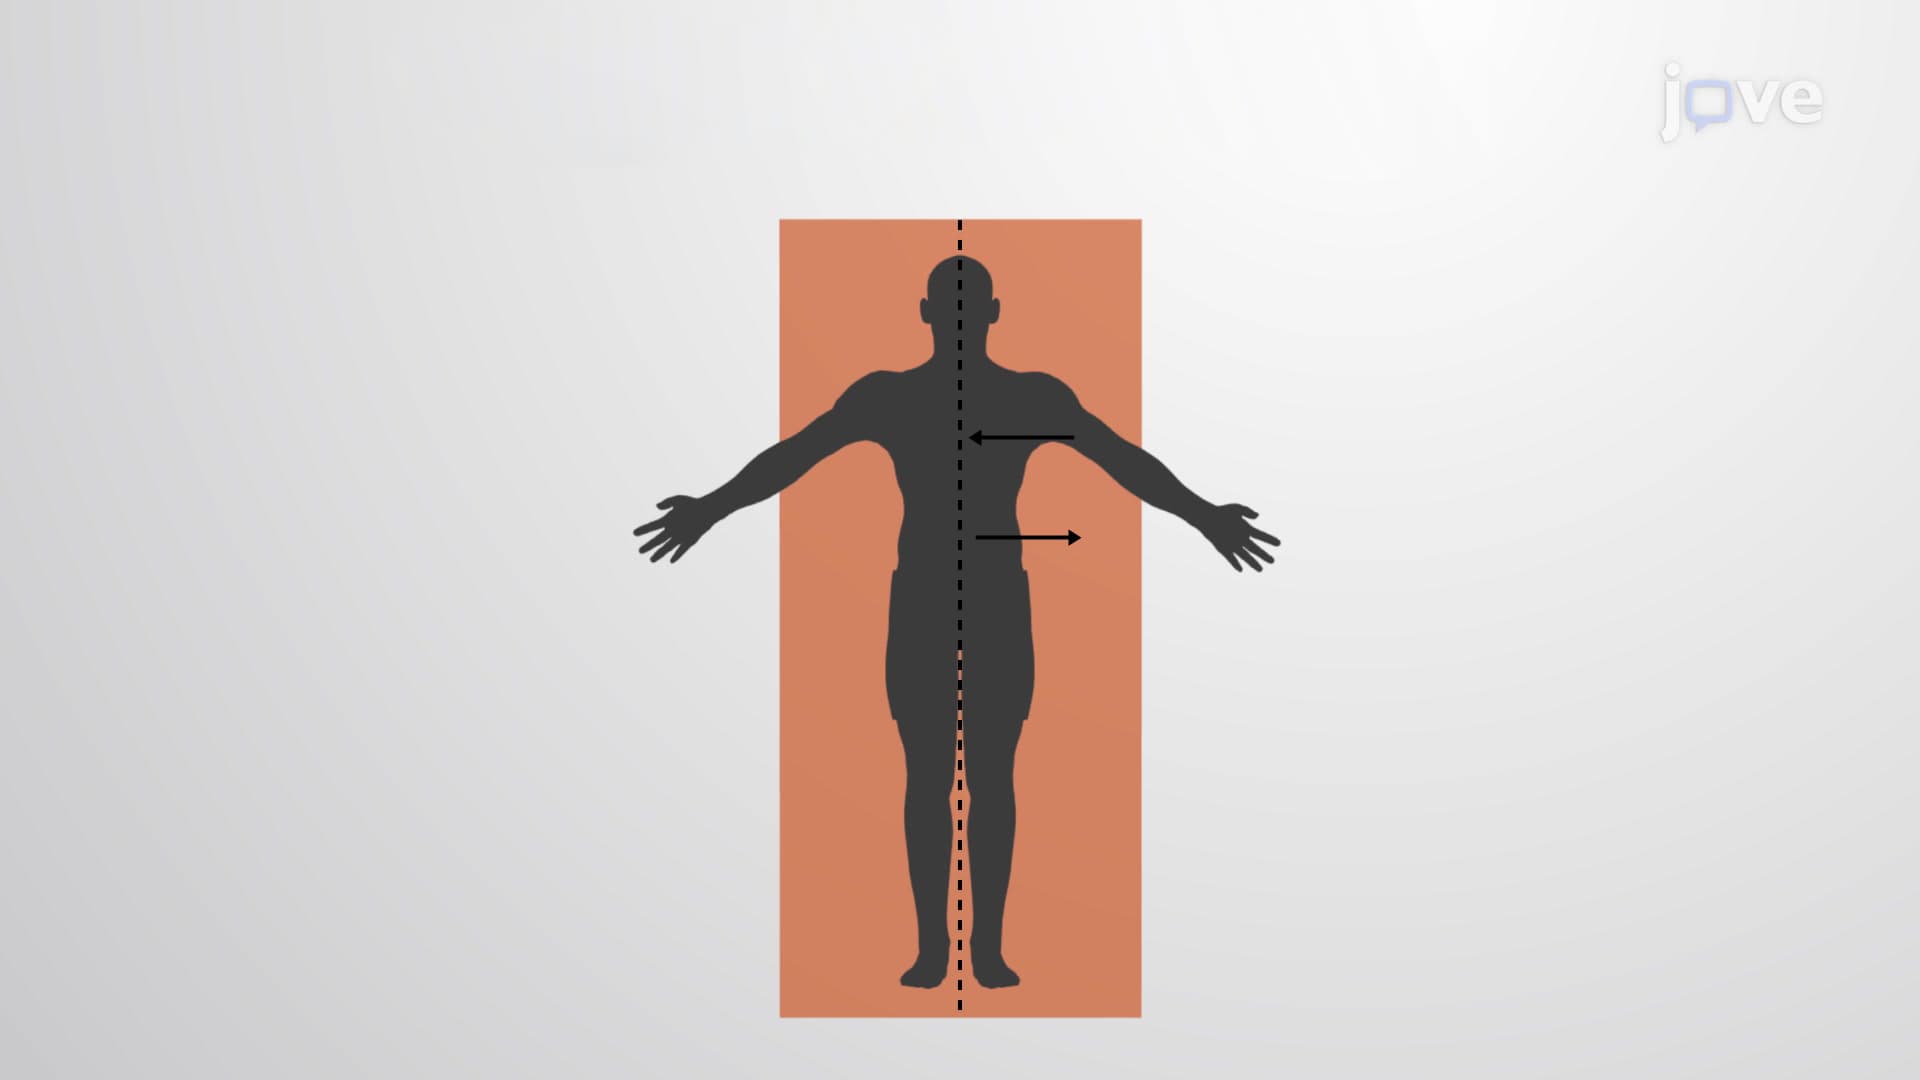
Anatomical movements refer to the various actions or motions that can be performed by the body's joints and muscles. These movements are described using specific terms to provide a standardized way of discussing and understanding the range of motion at different joints.
Here are some common anatomical movements:
Flexion and extension motions are in the sagittal (anterior–posterior) plane of motion. These movements take place at the shoulder, hip, elbow, knee, wrist,...
Here are some common anatomical movements:
Flexion and extension motions are in the sagittal (anterior–posterior) plane of motion. These movements take place at the shoulder, hip, elbow, knee, wrist,...
7.1K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
335
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
335